Introduction
The TB6600 Microstepping Motor Driver, manufactured by DFROBOT (Part ID: TB6600), is a high-performance driver designed for controlling bipolar stepper motors. It supports a wide range of microstepping modes, enabling precise control of motor position and speed. With its robust design and high current-handling capability, the TB6600 is ideal for applications requiring smooth and accurate motor operation, such as CNC machines, 3D printers, robotics, and automated systems.
Common Applications
- CNC machines for precise cutting and engraving
- 3D printers for accurate layer deposition
- Robotics for smooth and controlled motion
- Conveyor systems in industrial automation
- Camera sliders and other motion control systems
Technical Specifications
Key Technical Details
Pin Configuration and Descriptions
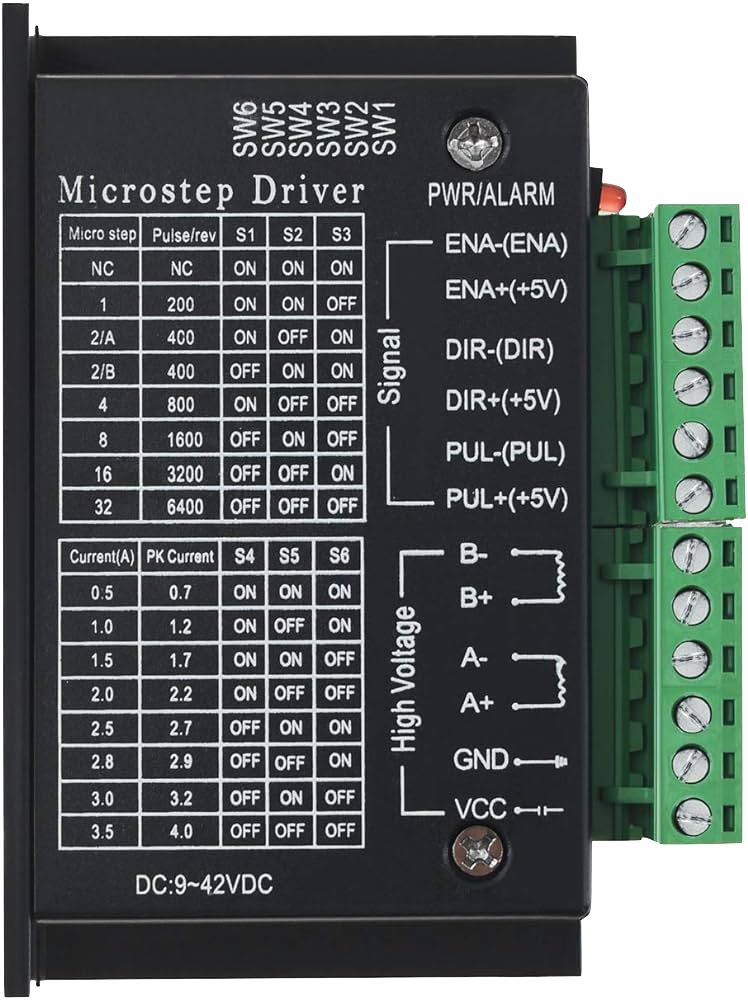
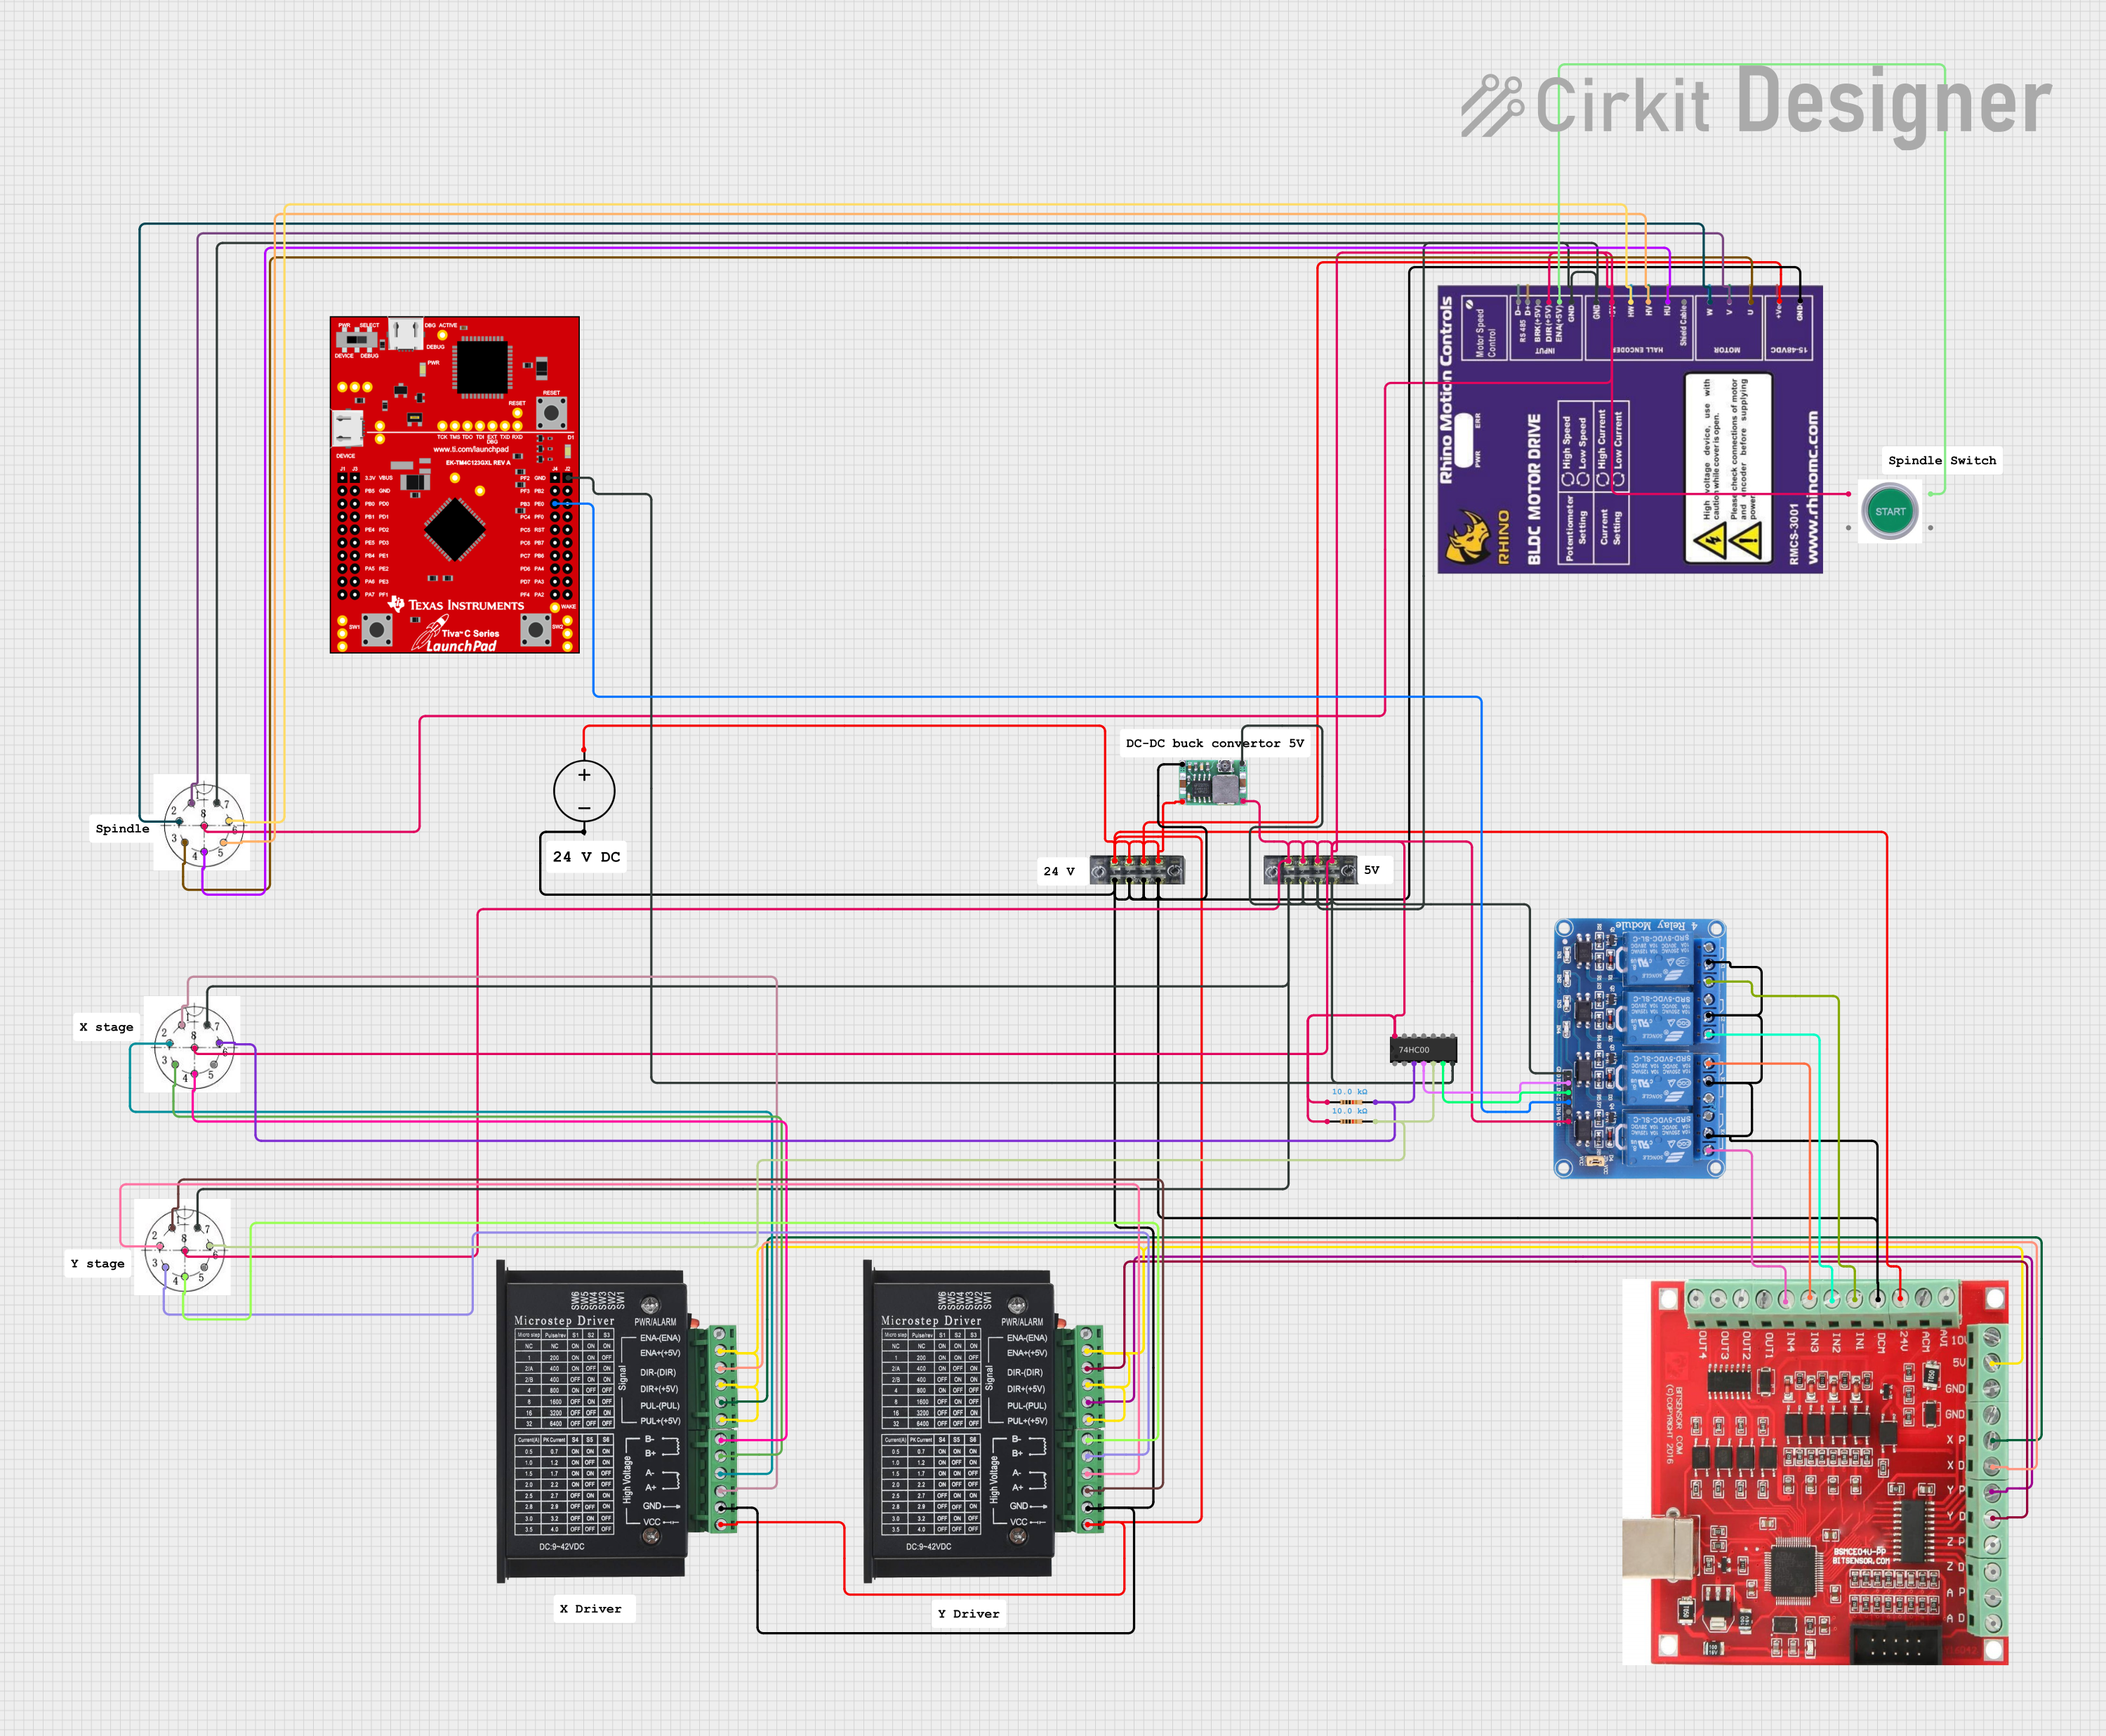
The TB6600 driver has several input and output terminals for connecting to the stepper motor, power supply, and control signals. Below is the pin configuration:
Output Terminals
Usage Instructions
How to Use the TB6600 in a Circuit
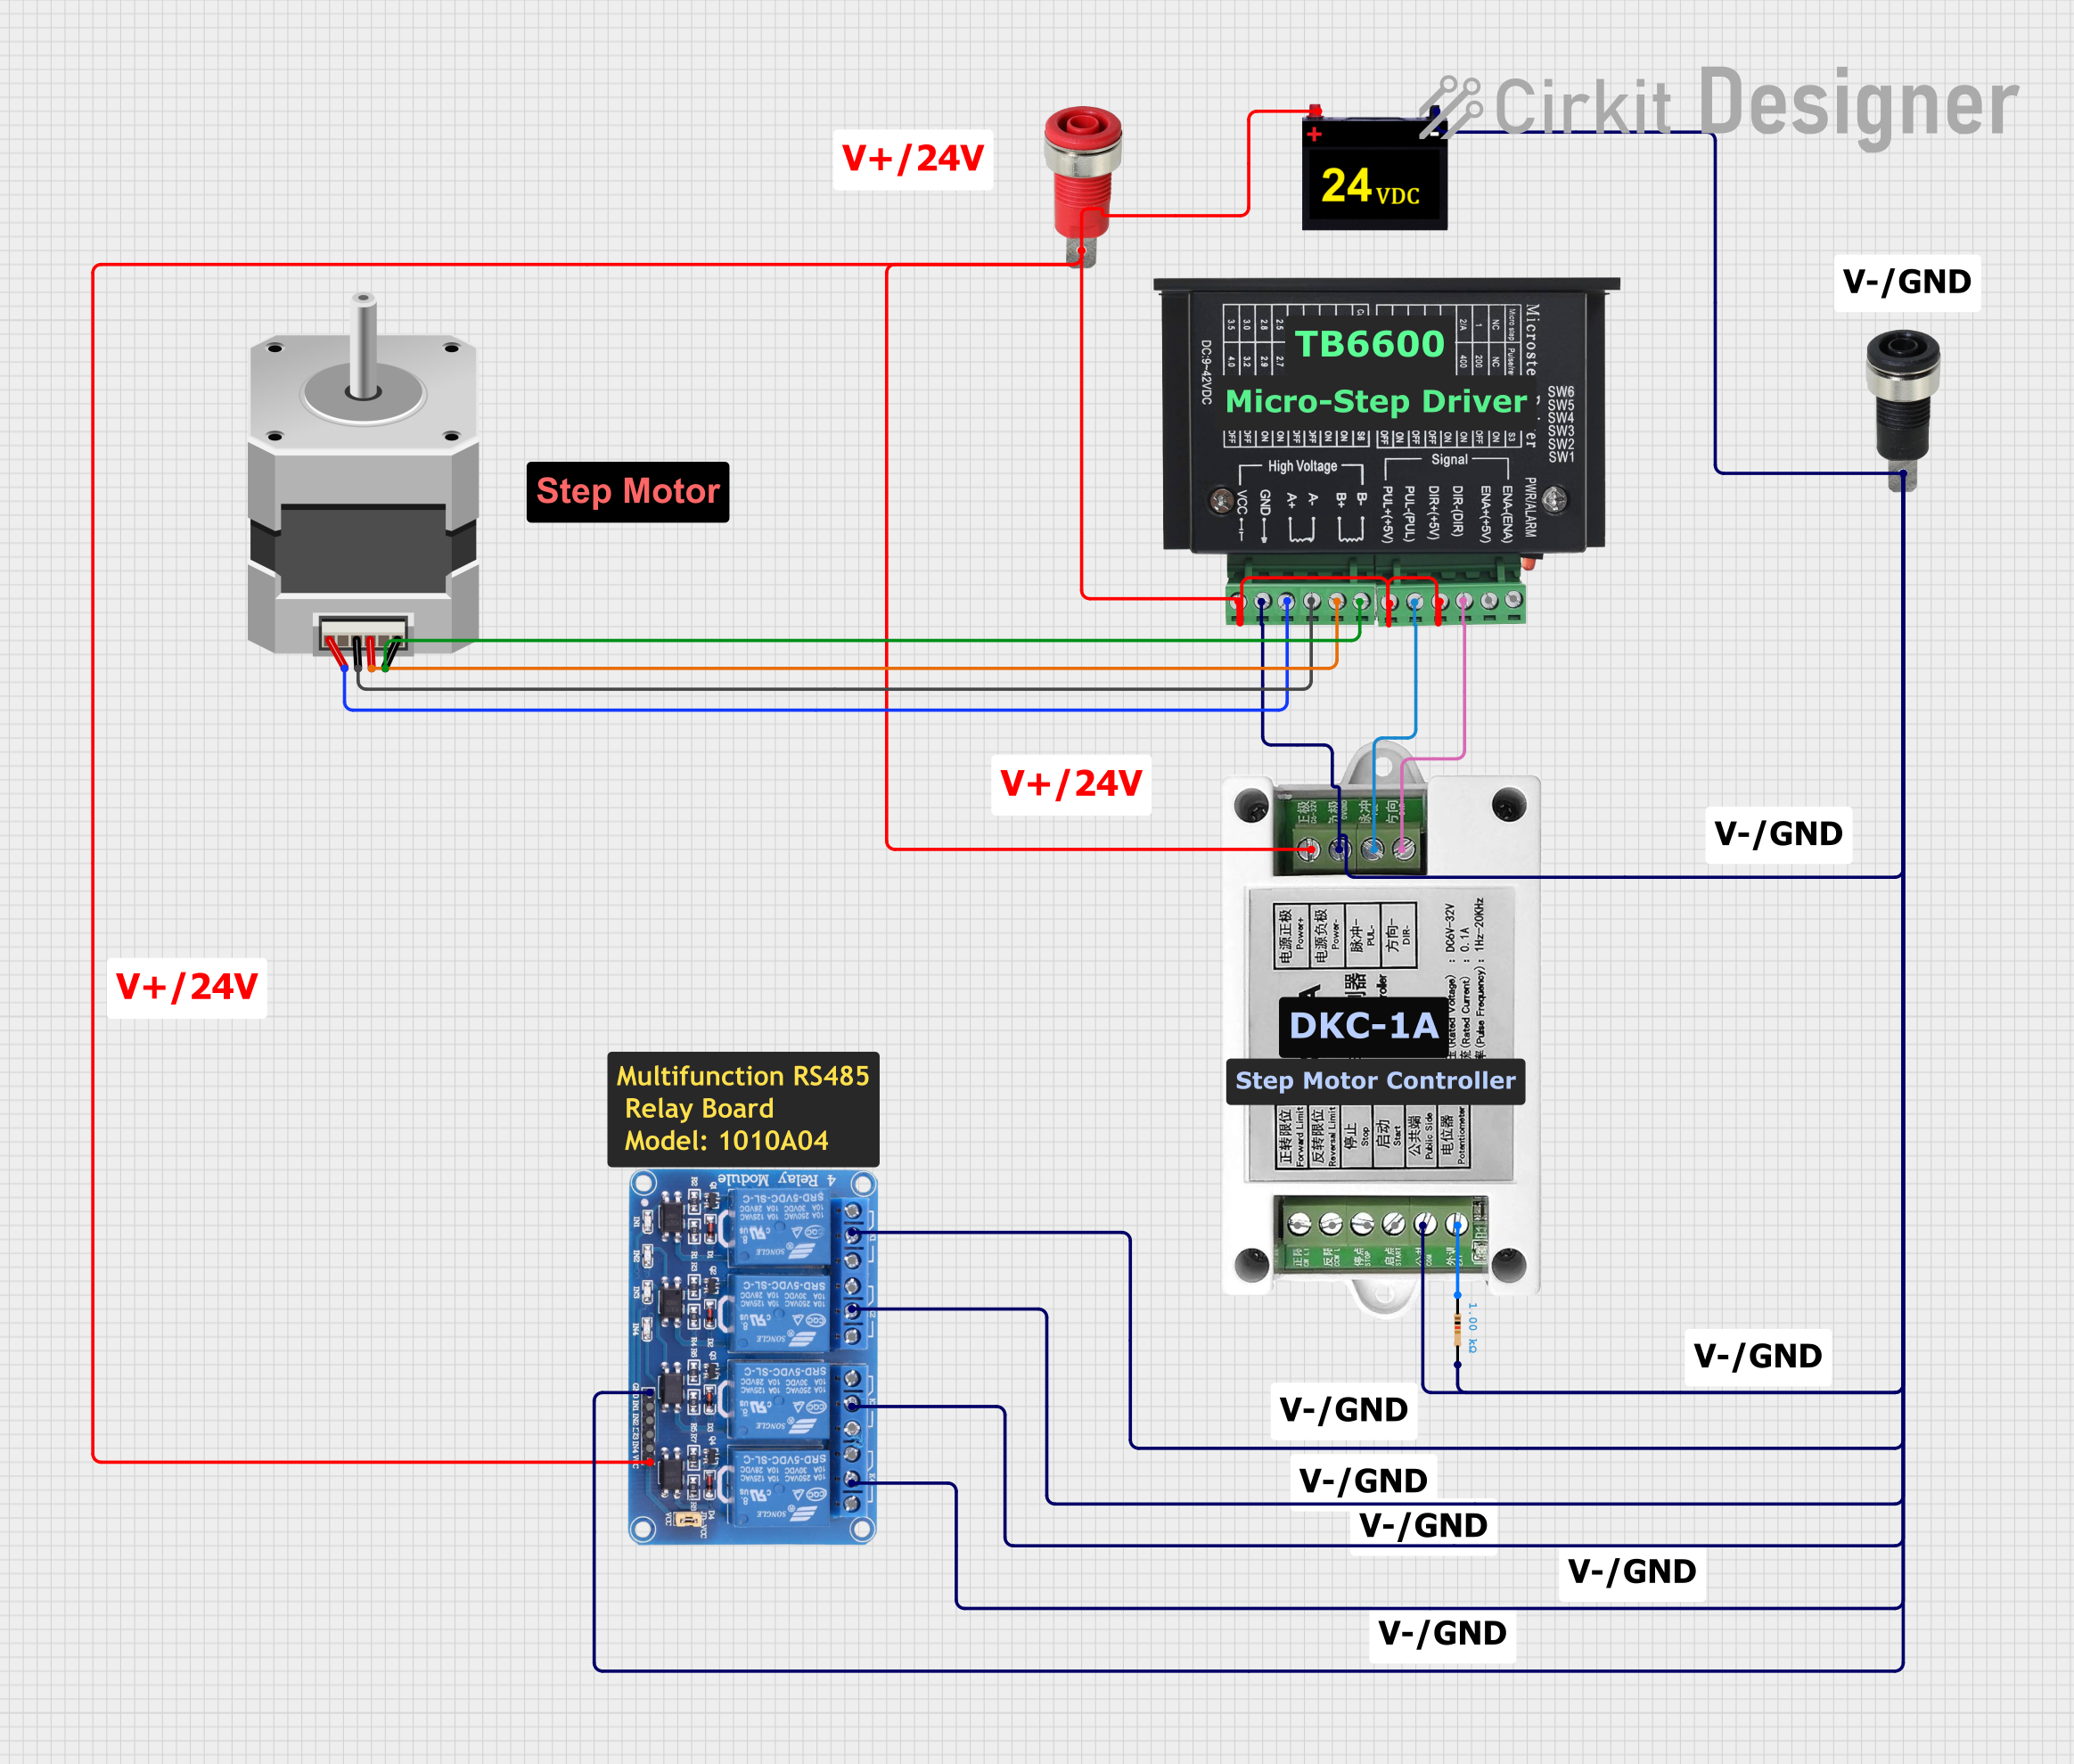
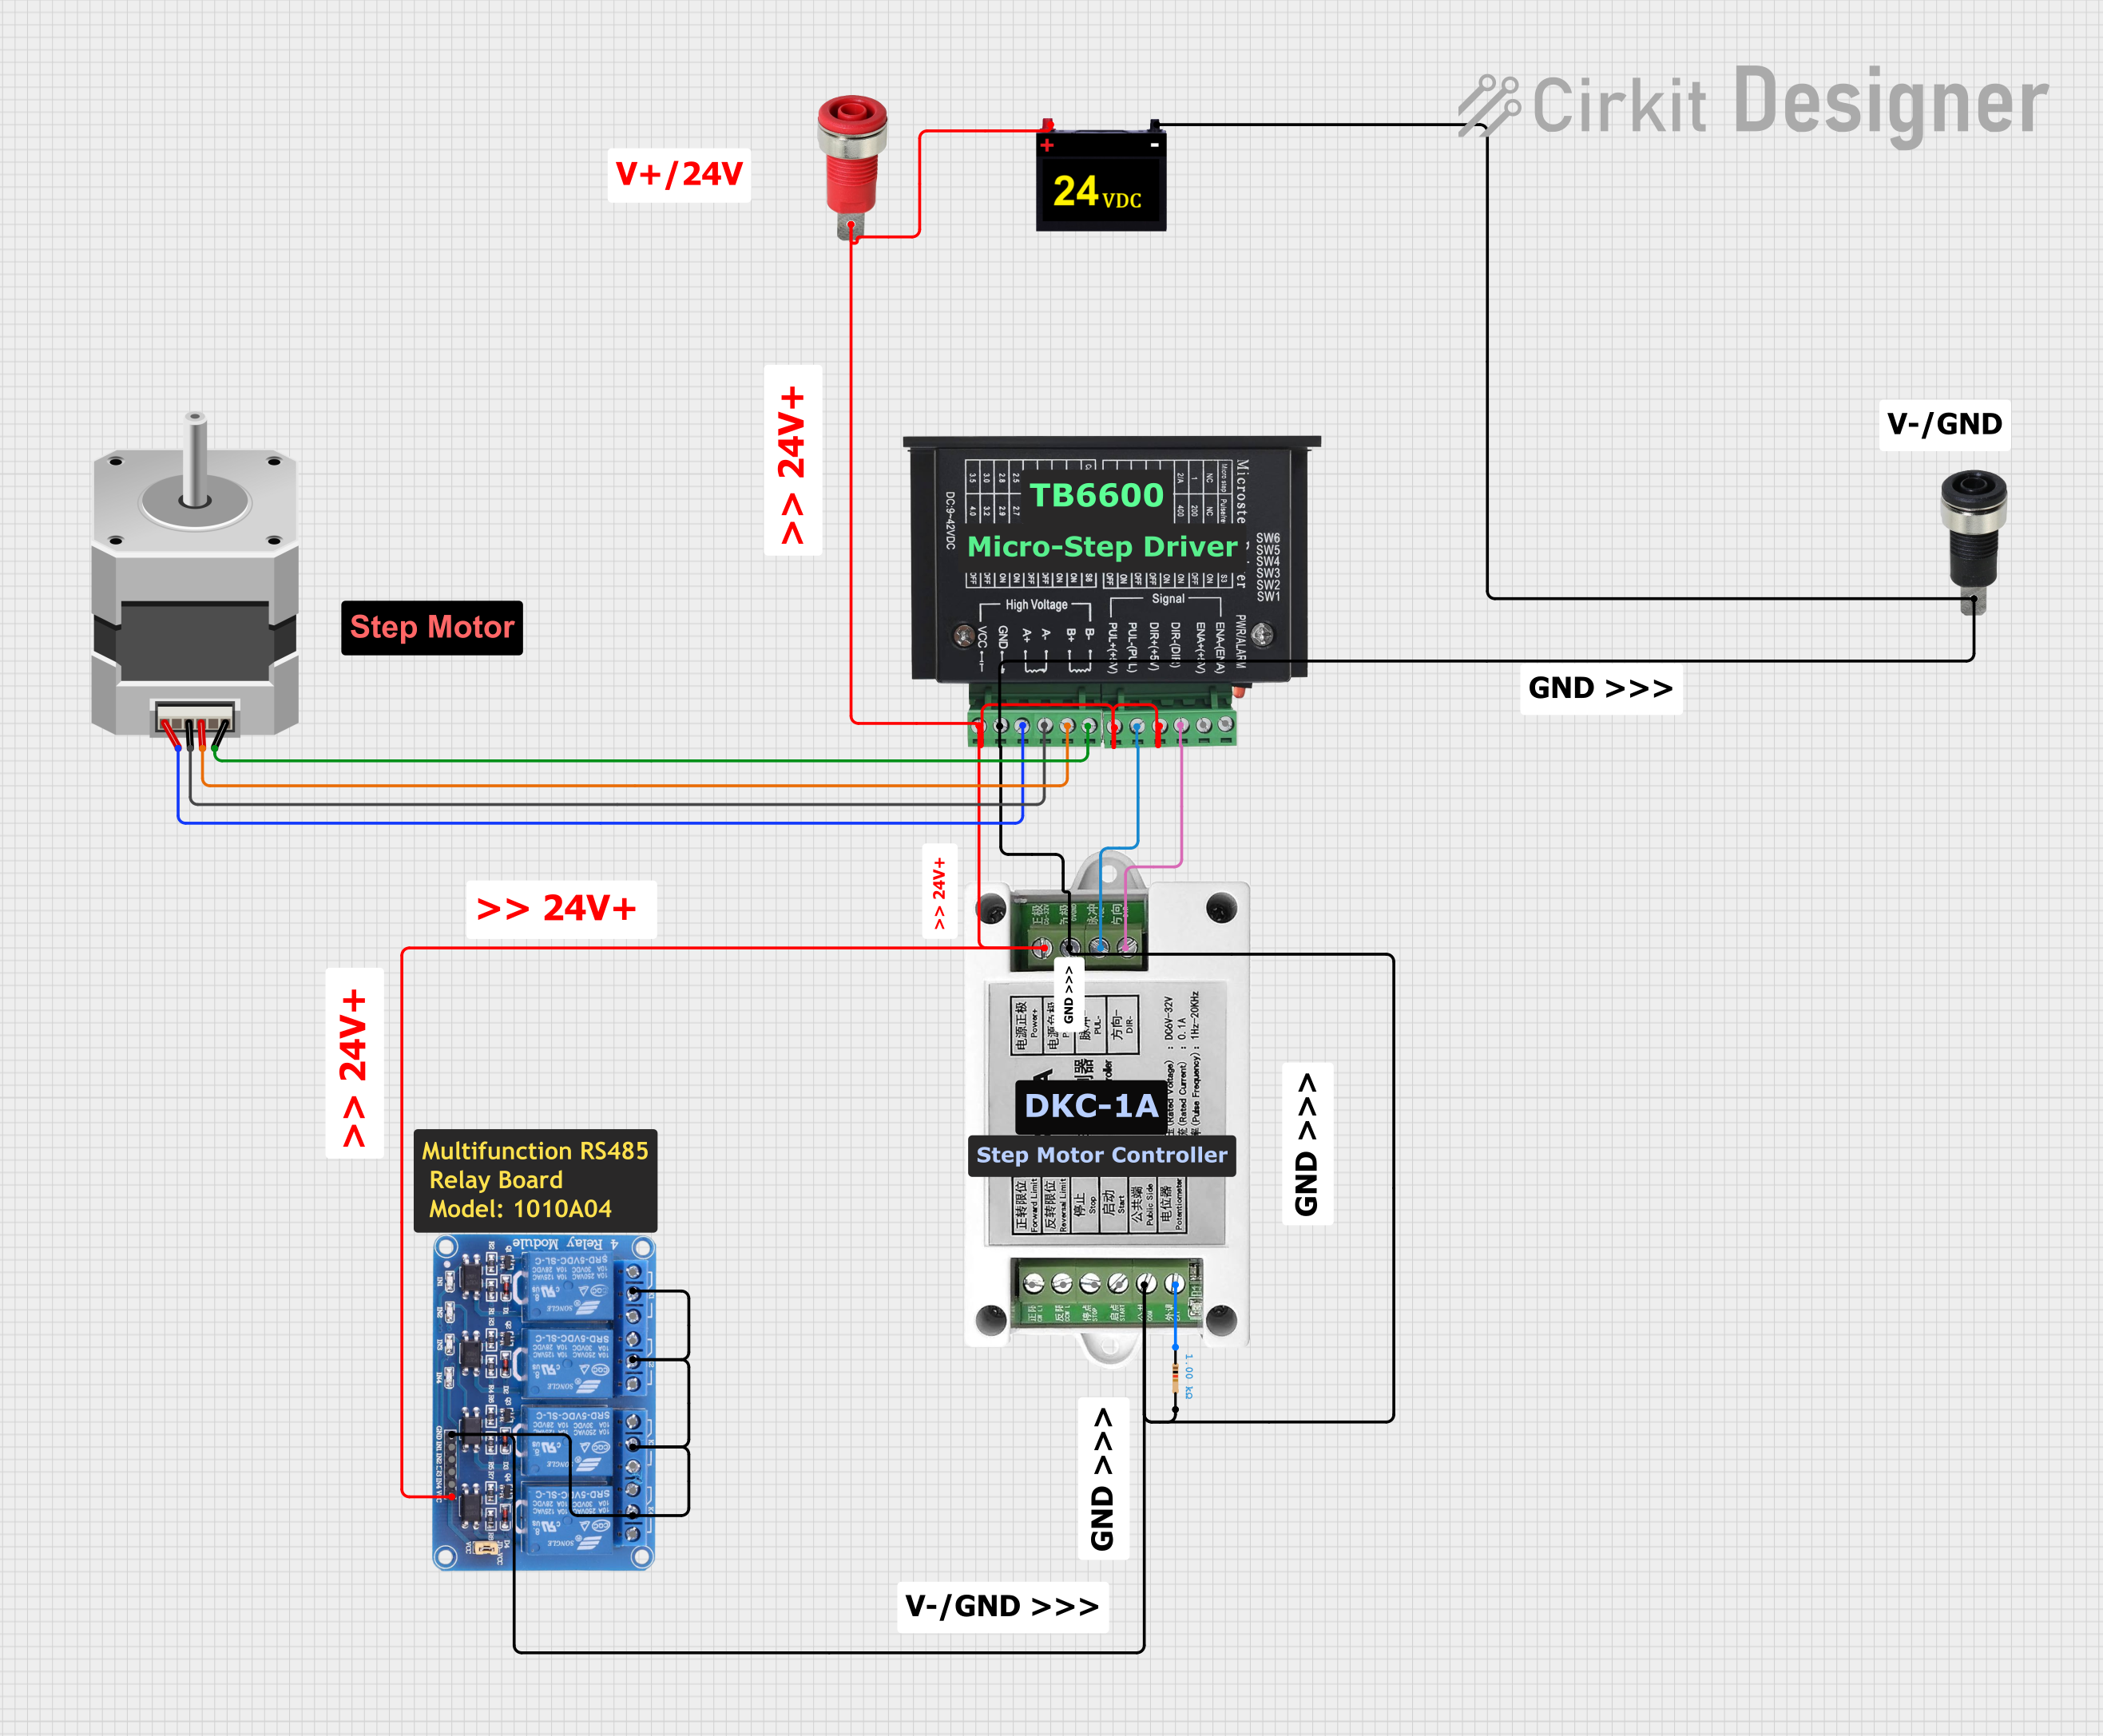
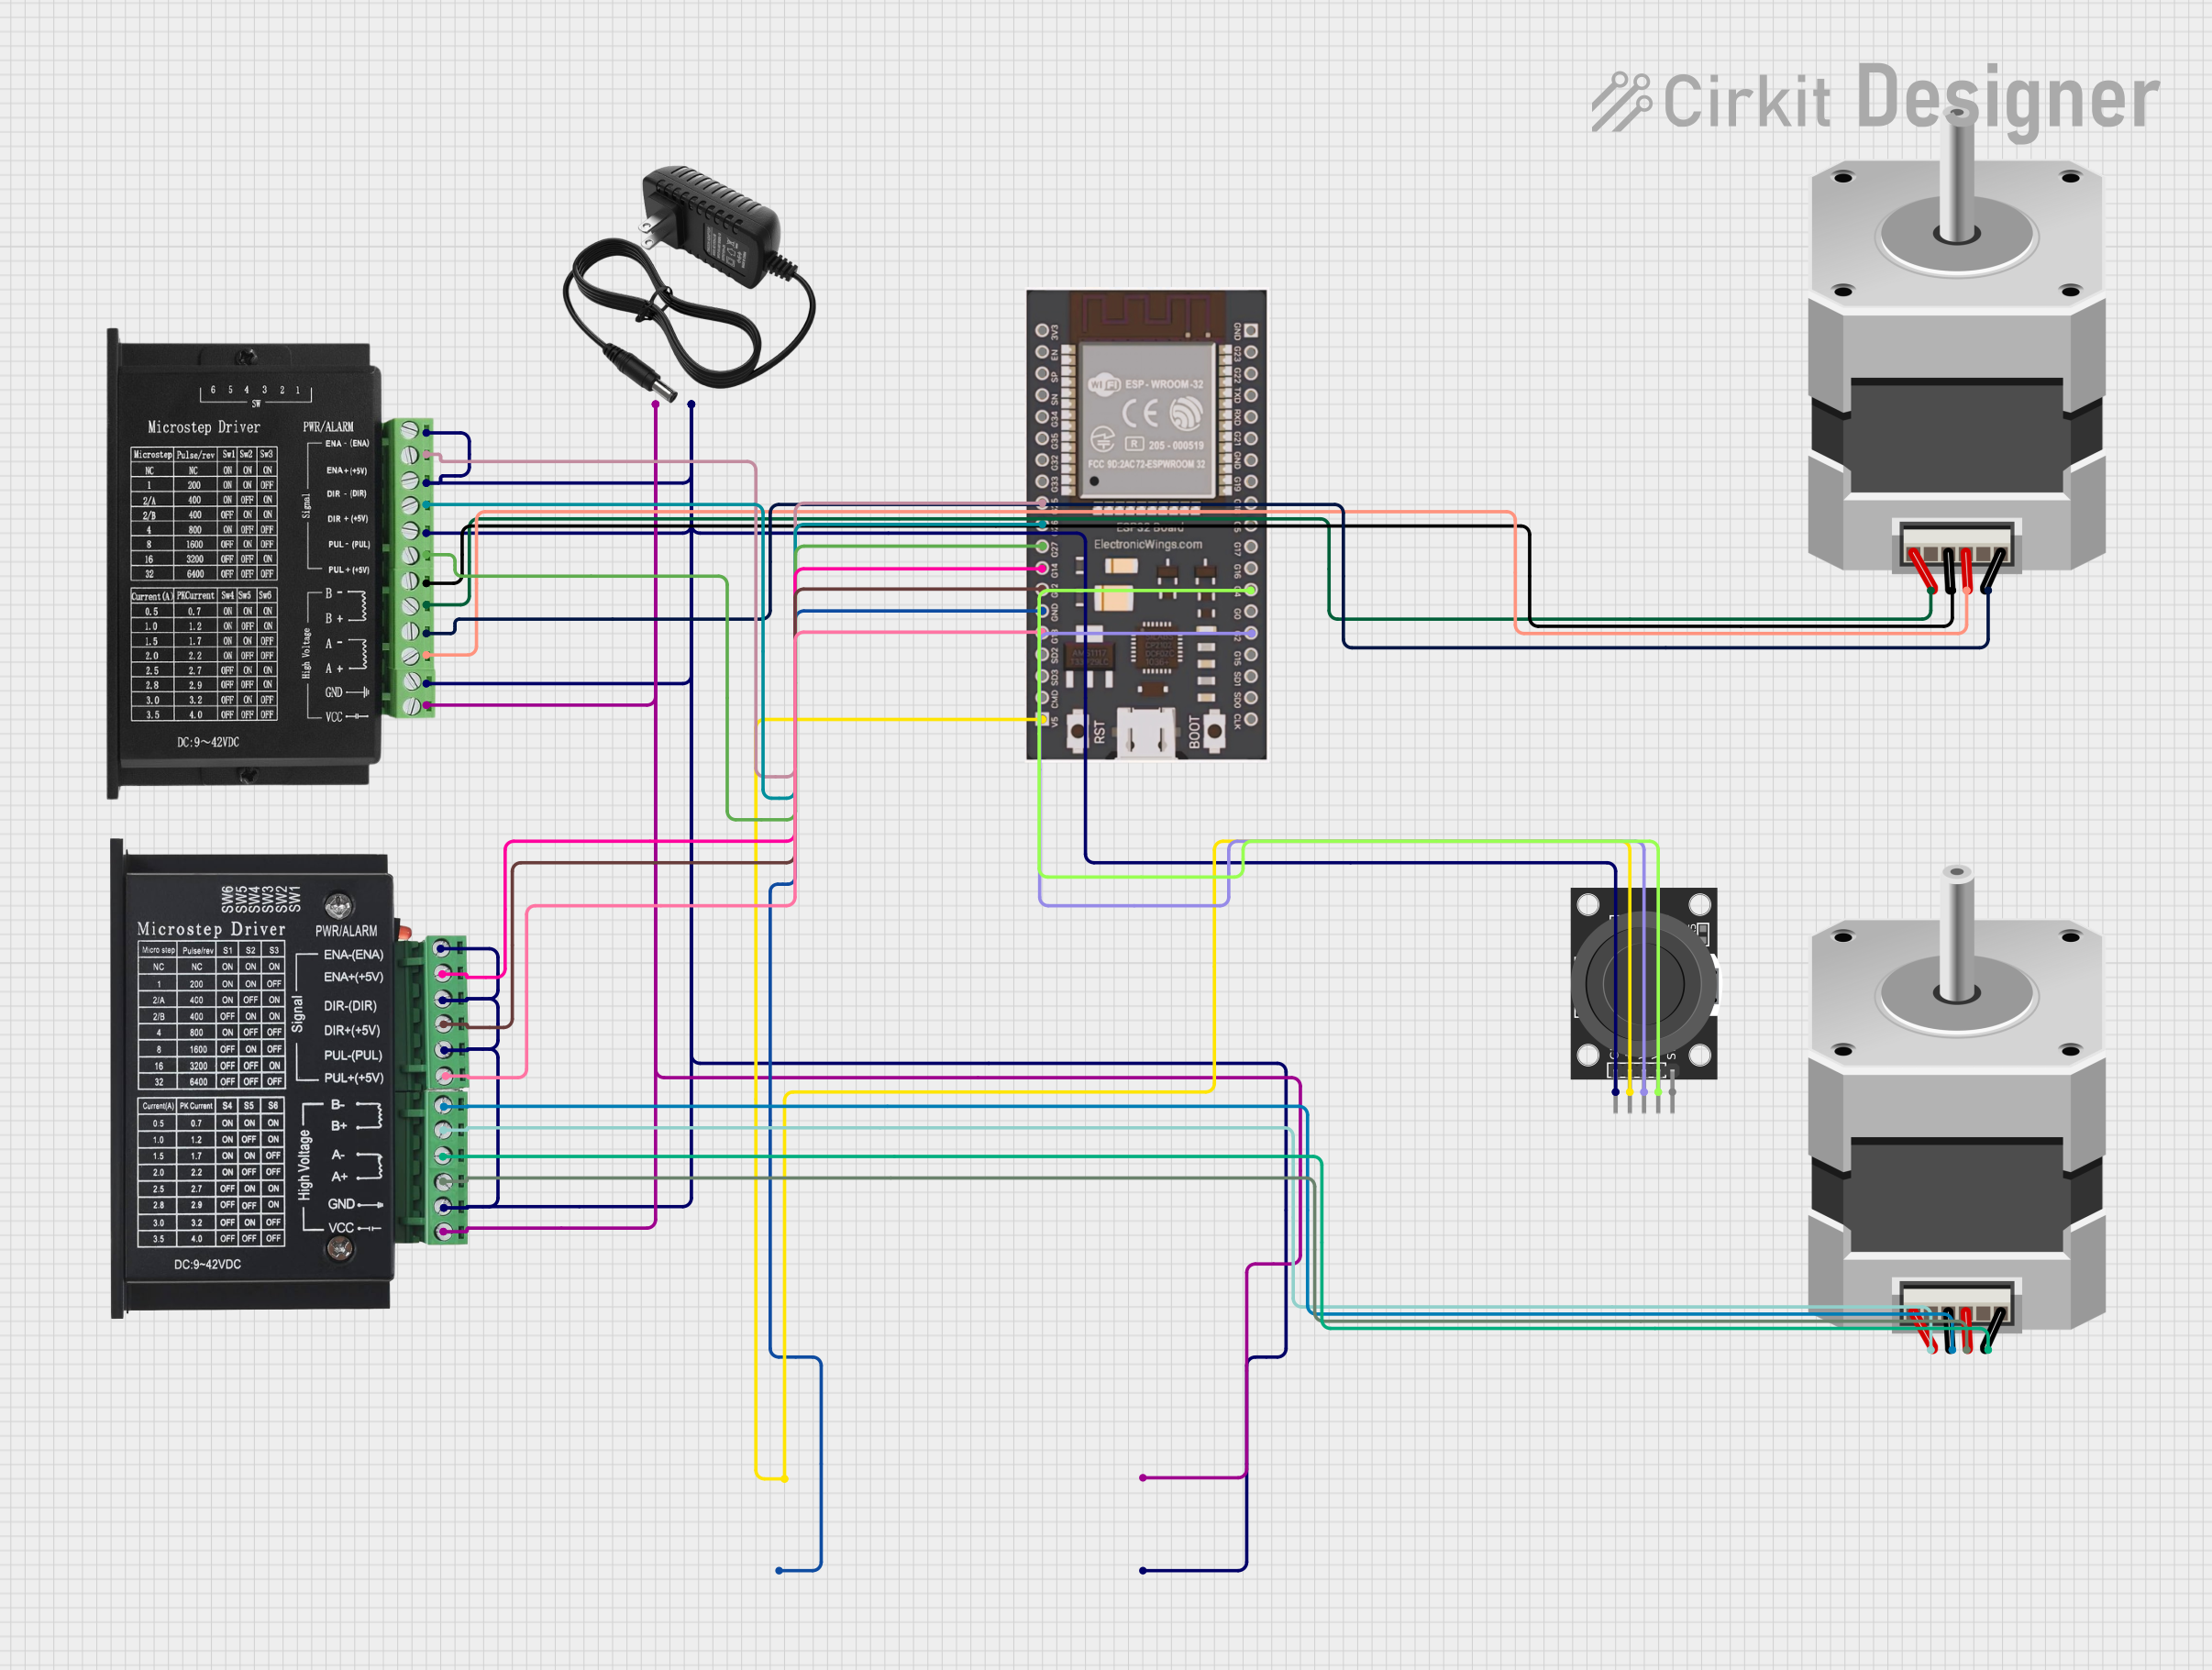
- Power Supply: Connect a DC power supply (9V to 42V) to the
VCC and GND terminals. Ensure the power supply can provide sufficient current for the stepper motor.
- Stepper Motor Connection: Connect the stepper motor's coils to the
A+, A-, B+, and B- terminals. Refer to the motor's datasheet to identify the correct coil pairs.
- Control Signals: Connect the
PUL+, PUL-, DIR+, DIR-, ENA+, and ENA- terminals to the control signals from a microcontroller (e.g., Arduino UNO). Use a common ground between the driver and the microcontroller.
- Microstepping Configuration: Use the DIP switches on the driver to set the desired microstepping mode and current limit. Refer to the TB6600 datasheet for the DIP switch settings.
- Enable the Driver: If using the enable signal, ensure the
ENA+ and ENA- terminals are properly connected. If not used, leave them disconnected.
Important Considerations and Best Practices
- Heat Dissipation: The TB6600 generates heat during operation. Ensure proper ventilation or use a heatsink to prevent overheating.
- Current Settings: Set the current limit using the DIP switches to match the stepper motor's rated current. Exceeding the motor's current rating can cause overheating or damage.
- Signal Noise: Use shielded cables for control signals to minimize noise and ensure reliable operation.
- Power Supply: Use a stable and regulated power supply to avoid voltage fluctuations that could affect performance.
Example: Connecting the TB6600 to an Arduino UNO
Below is an example of Arduino code to control a stepper motor using the TB6600 driver:
// Define control pins for the TB6600 driver
const int stepPin = 3;  // Pin connected to PUL+ (Pulse)
const int dirPin = 4;   // Pin connected to DIR+ (Direction)

void setup() {
  // Set control pins as outputs
  pinMode(stepPin, OUTPUT);
  pinMode(dirPin, OUTPUT);

  // Set initial direction
  digitalWrite(dirPin, HIGH); // HIGH for one direction, LOW for the other
}

void loop() {
  // Generate step pulses to move the motor
  for (int i = 0; i < 200; i++) { // 200 steps for one revolution (example)
    digitalWrite(stepPin, HIGH);  // Set step pin HIGH
    delayMicroseconds(500);       // Wait 500 microseconds
    digitalWrite(stepPin, LOW);   // Set step pin LOW
    delayMicroseconds(500);       // Wait 500 microseconds
  }

  // Change direction
  digitalWrite(dirPin, !digitalRead(dirPin)); // Toggle direction
  delay(1000); // Wait 1 second before next movement
}
Troubleshooting and FAQs
Common Issues and Solutions
Motor Not Moving:
- Cause: Incorrect wiring or loose connections.
- Solution: Double-check all connections, especially the motor coils and control signals.
Motor Vibrates but Does Not Rotate:
- Cause: Incorrect microstepping or current settings.
- Solution: Verify the DIP switch settings and ensure they match the motor's specifications.
Driver Overheating:
- Cause: Insufficient cooling or excessive current setting.
- Solution: Add a heatsink or fan, and reduce the current limit using the DIP switches.
Erratic Motor Movement:
- Cause: Electrical noise or unstable power supply.
- Solution: Use shielded cables for control signals and a regulated power supply.
FAQs
Q: Can the TB6600 drive unipolar stepper motors?
A: No, the TB6600 is designed for bipolar stepper motors only.
Q: What is the maximum step frequency supported?
A: The TB6600 supports step frequencies up to 200 kHz.
Q: Can I use the TB6600 with a 3.3V microcontroller?
A: Yes, the control signal inputs are compatible with both 3.3V and 5V logic levels.
Q: How do I select the microstepping mode?
A: Use the DIP switches on the driver. Refer to the TB6600 datasheet for the specific switch settings.
This concludes the documentation for the TB6600 Microstepping Motor Driver. For further assistance, refer to the manufacturer's datasheet or contact DFRobot support.

 Open Project in Cirkit Designer