Cirkit Designer
Your all-in-one circuit design IDE
Home /
Component Documentation
How to Use motor and wheels: Examples, Pinouts, and Specs
 Design with motor and wheels in Cirkit Designer
Introduction
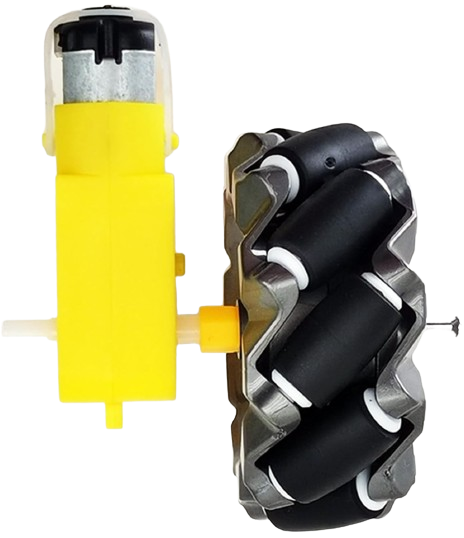
- The motor and wheels assembly is a fundamental component for building mobile robotic systems. It typically consists of a DC motor or stepper motor attached to wheels, enabling movement and navigation. This setup is widely used in robotics, remote-controlled vehicles, and automation projects.
- Common applications include robotic cars, conveyor systems, automated guided vehicles (AGVs), and educational robotics kits.
Explore Projects Built with motor and wheels
Battery-Powered Dual Gearmotor Drive System

This circuit consists of a 6V battery pack connected in parallel to two DC gearmotors, one for the left wheel and one for the right wheel of a vehicle. The battery provides power directly to both motors, enabling them to run simultaneously. As there is no control circuitry or microcontroller code provided, the motors will run continuously when the circuit is powered.
Open Project in Cirkit DesignerArduino-Controlled Robotic Vehicle with IR Sensors and L298N Motor Driver
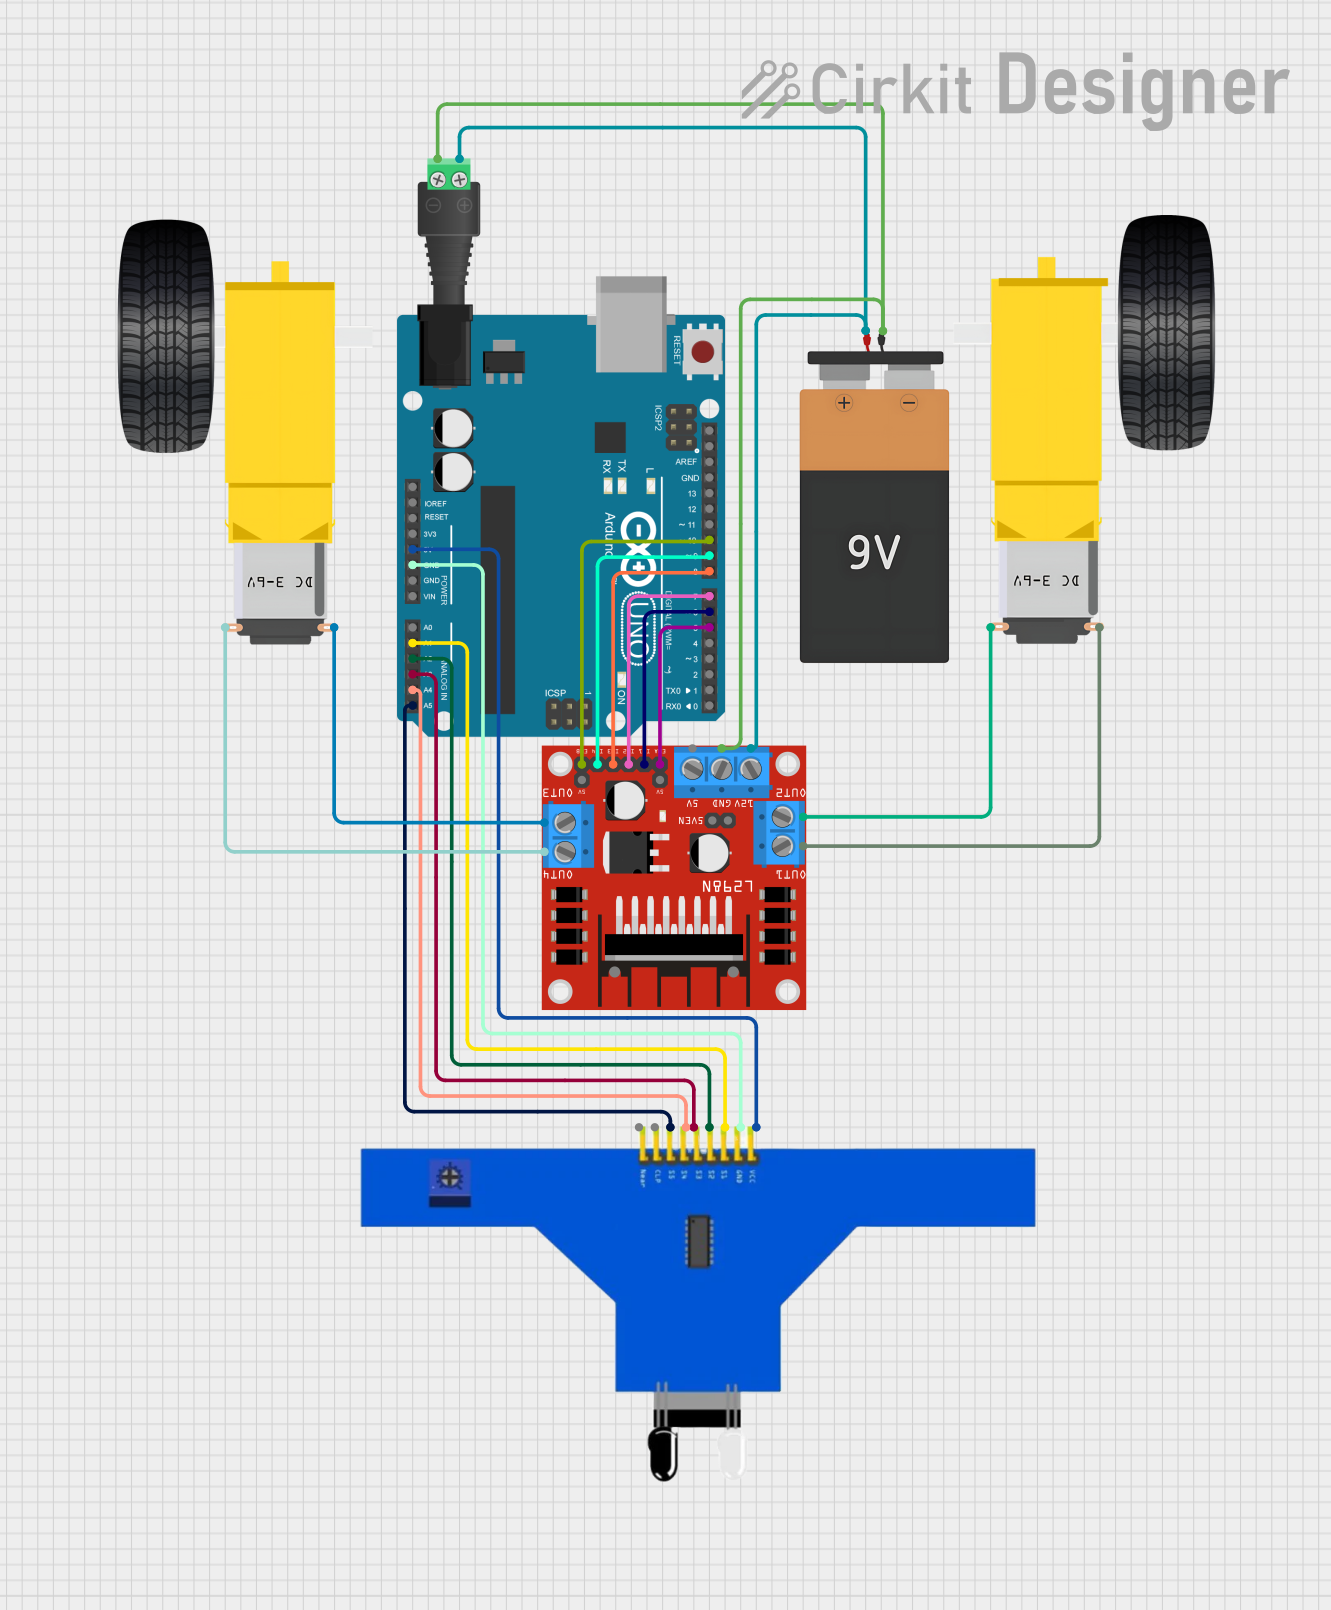
This circuit is designed to control a pair of DC gearmotors using an L298N motor driver module, which is interfaced with an Arduino UNO microcontroller. The Arduino is also connected to a 5-channel IR sensor for input, which may be used for line tracking or obstacle detection. Power is supplied by a 9V battery connected through a 2.1mm barrel jack, and the motor driver module regulates this power to drive the left and right gearmotors for a mobile robot platform.
Open Project in Cirkit DesignerESP32-CAM Controlled Wi-Fi Robot Car
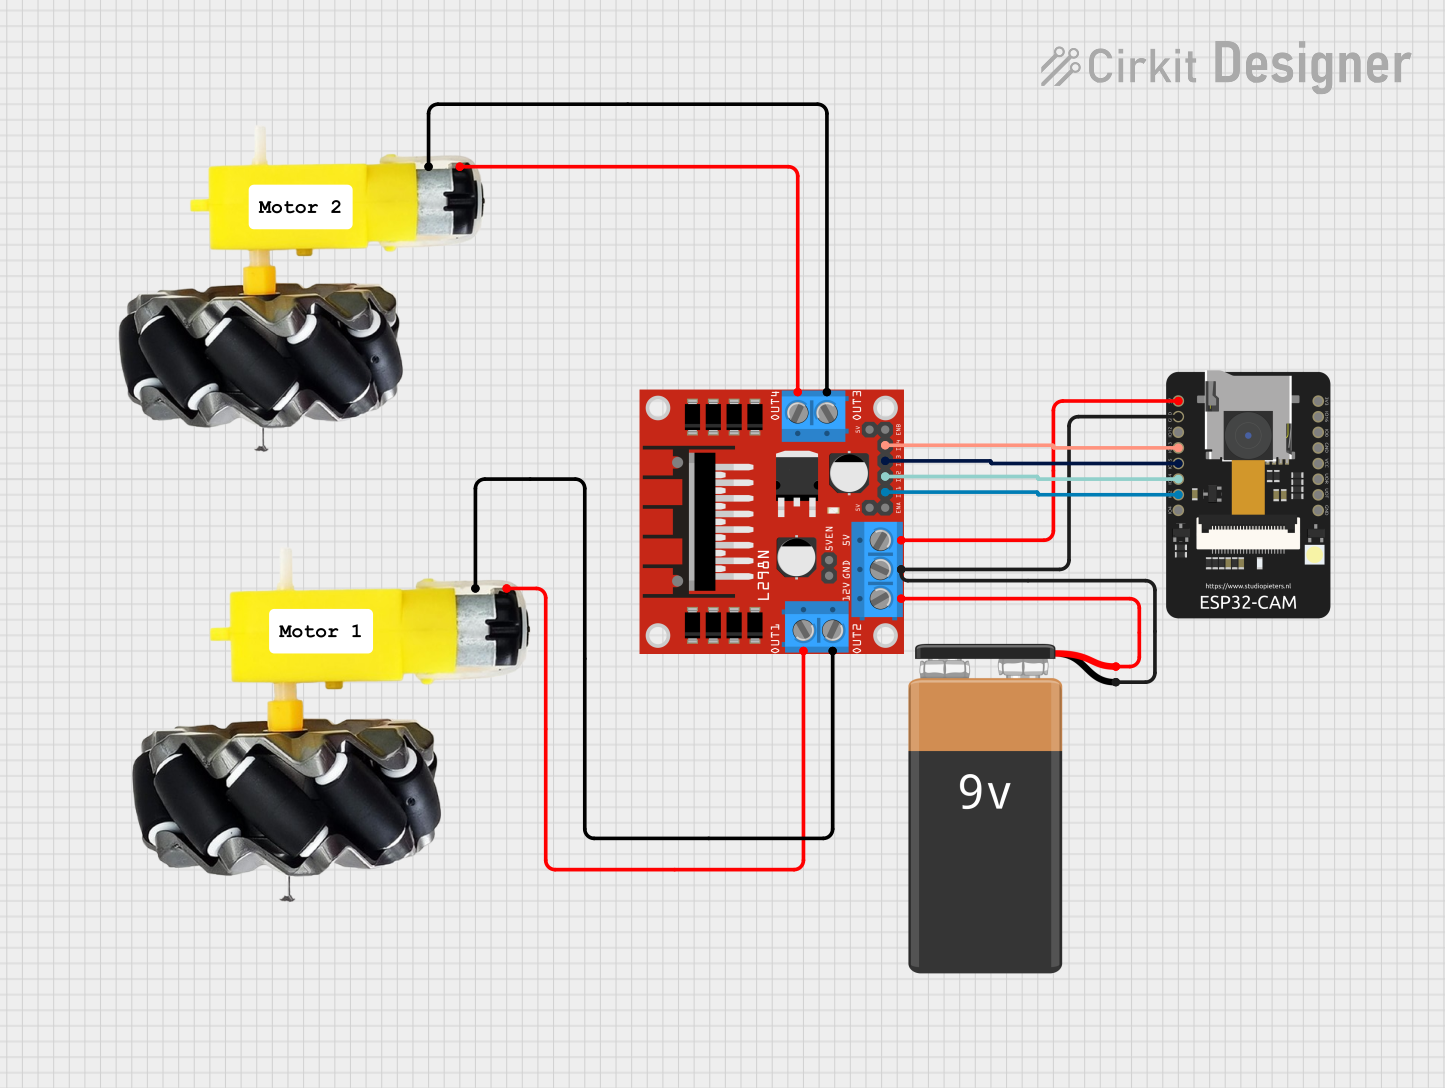
This circuit is designed to control a two-wheel motorized vehicle using an ESP32-CAM microcontroller. The ESP32-CAM is interfaced with an L298N DC motor driver to control the direction and speed of the motors attached to the wheels. Additionally, the ESP32-CAM is configured to capture images and provide WiFi connectivity for remote control via a web server with a user interface for driving commands.
Open Project in Cirkit DesignerESP32 and L298N Motor Driver-Based Wi-Fi Controlled Robotic Vehicle with GPS and Metal Detection
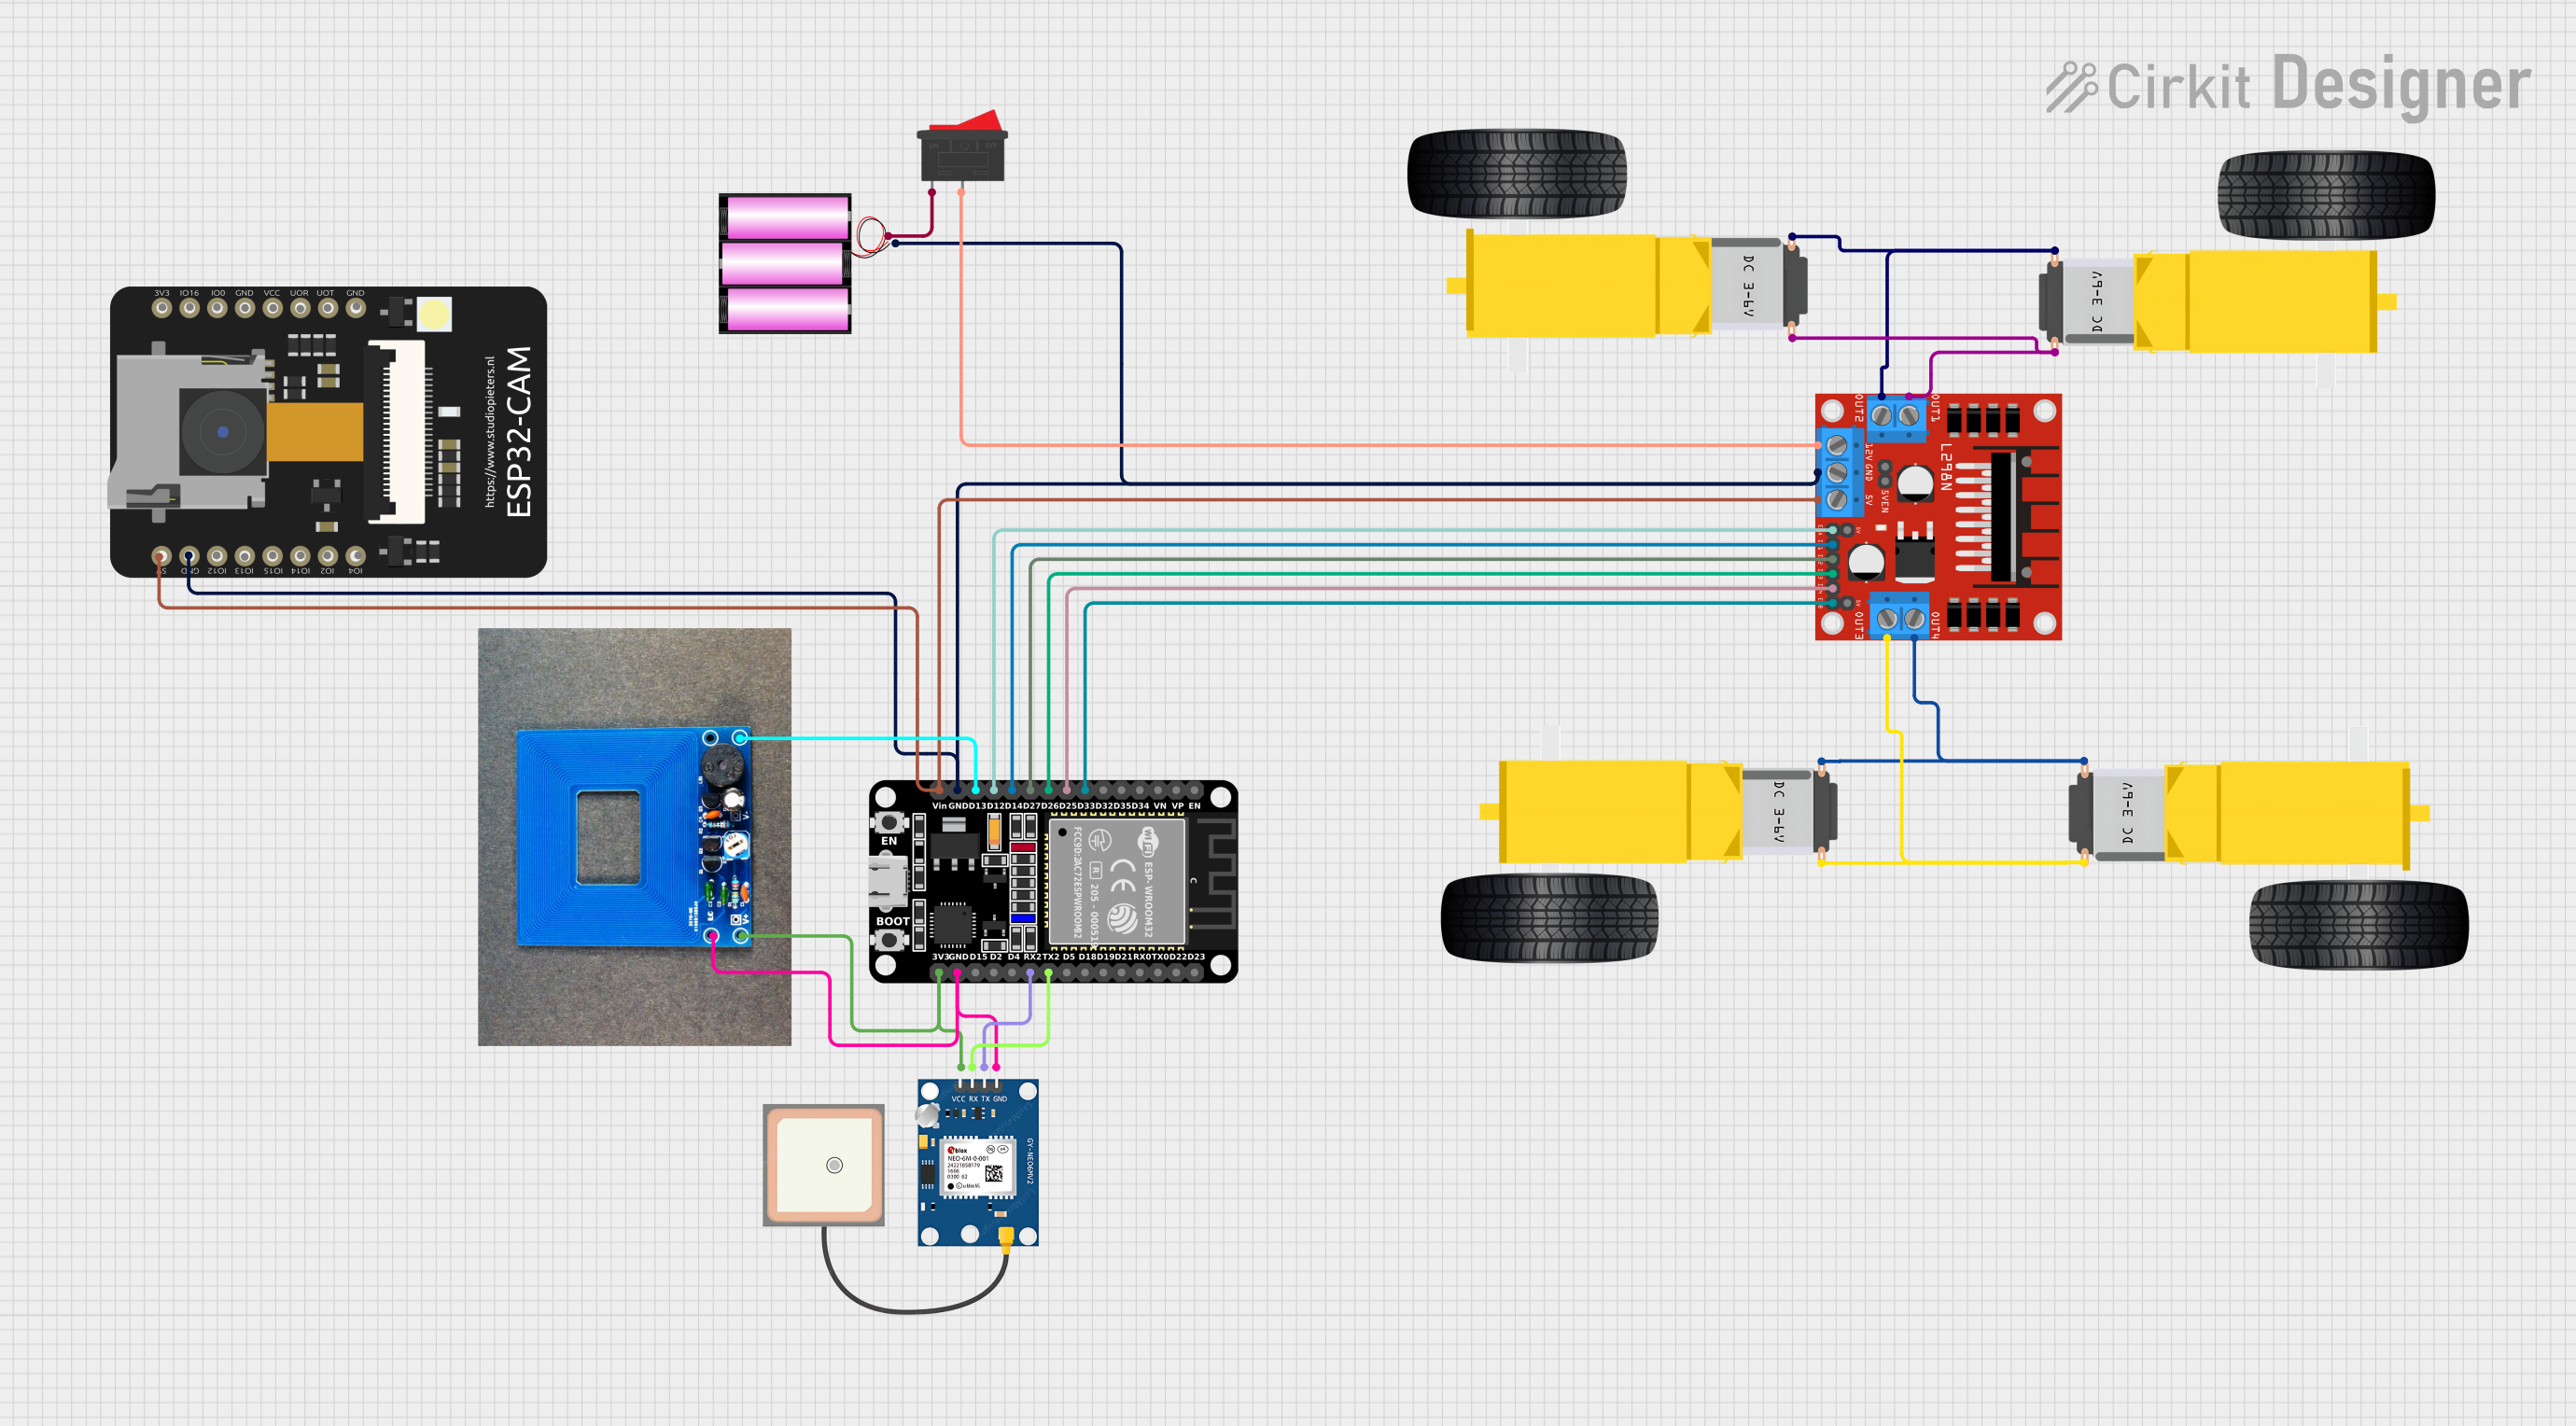
This circuit is a robotic vehicle control system that uses an ESP32 microcontroller to drive four DC gear motors via an L298N motor driver. It also includes a GPS module for location tracking, a metal detector for object detection, and an ESP32 CAM for capturing images or video, all powered by a 12V battery.
Open Project in Cirkit DesignerExplore Projects Built with motor and wheels
Battery-Powered Dual Gearmotor Drive System
This circuit consists of a 6V battery pack connected in parallel to two DC gearmotors, one for the left wheel and one for the right wheel of a vehicle. The battery provides power directly to both motors, enabling them to run simultaneously. As there is no control circuitry or microcontroller code provided, the motors will run continuously when the circuit is powered.
Open Project in Cirkit DesignerArduino-Controlled Robotic Vehicle with IR Sensors and L298N Motor Driver
This circuit is designed to control a pair of DC gearmotors using an L298N motor driver module, which is interfaced with an Arduino UNO microcontroller. The Arduino is also connected to a 5-channel IR sensor for input, which may be used for line tracking or obstacle detection. Power is supplied by a 9V battery connected through a 2.1mm barrel jack, and the motor driver module regulates this power to drive the left and right gearmotors for a mobile robot platform.
Open Project in Cirkit DesignerESP32-CAM Controlled Wi-Fi Robot Car
This circuit is designed to control a two-wheel motorized vehicle using an ESP32-CAM microcontroller. The ESP32-CAM is interfaced with an L298N DC motor driver to control the direction and speed of the motors attached to the wheels. Additionally, the ESP32-CAM is configured to capture images and provide WiFi connectivity for remote control via a web server with a user interface for driving commands.
Open Project in Cirkit DesignerESP32 and L298N Motor Driver-Based Wi-Fi Controlled Robotic Vehicle with GPS and Metal Detection
This circuit is a robotic vehicle control system that uses an ESP32 microcontroller to drive four DC gear motors via an L298N motor driver. It also includes a GPS module for location tracking, a metal detector for object detection, and an ESP32 CAM for capturing images or video, all powered by a 12V battery.
Open Project in Cirkit DesignerTechnical Specifications
Motor Specifications
| Parameter | Value |
|---|---|
| Motor Type | DC Motor / Stepper Motor |
| Operating Voltage | 3V - 12V (varies by motor model) |
| Rated Current | 100mA - 2A (depending on load) |
| Stall Current | Up to 3A (varies by motor model) |
| Torque | 0.1 Nm - 1 Nm (model-dependent) |
| Speed | 50 RPM - 300 RPM (no load) |
Wheel Specifications
| Parameter | Value |
|---|---|
| Wheel Diameter | 65mm - 100mm |
| Wheel Material | Rubber or Plastic |
| Hub Type | Compatible with motor shaft |
| Traction | High-grip surface for stability |
Pin Configuration (for DC Motor)
| Pin Name | Description |
|---|---|
| V+ | Positive terminal for motor power |
| V- | Negative terminal for motor power |
Pin Configuration (for Stepper Motor)
| Pin Name | Description |
|---|---|
| A+ | Coil A positive terminal |
| A- | Coil A negative terminal |
| B+ | Coil B positive terminal |
| B- | Coil B negative terminal |
Usage Instructions
Using the Motor and Wheels in a Circuit
- Power Supply: Ensure the motor is powered with the correct voltage and current as per its specifications. Use a motor driver or H-bridge circuit to control the motor safely.
- Motor Driver: Connect the motor to a motor driver (e.g., L298N or L293D) to control speed and direction. The motor driver acts as an interface between the microcontroller and the motor.
- Wheel Attachment: Securely attach the wheels to the motor shaft. Ensure proper alignment to avoid wobbling during operation.
- Microcontroller Control: Use a microcontroller (e.g., Arduino UNO) to send control signals to the motor driver for speed and direction control.
Important Considerations
- Current Limiting: Use a current-limiting resistor or a motor driver with built-in current control to prevent damage to the motor.
- Heat Dissipation: Motors can heat up during prolonged use. Ensure proper ventilation or heat sinks if necessary.
- Power Supply: Use a separate power supply for the motor to avoid voltage drops affecting the microcontroller.
Example Code for Arduino UNO (DC Motor Control)
// This example demonstrates how to control a DC motor using an L298N motor driver
// and an Arduino UNO. The motor speed is controlled using PWM, and the direction
// is controlled using digital pins.

const int ENA = 9;  // PWM pin for motor speed control
const int IN1 = 8;  // Direction control pin 1
const int IN2 = 7;  // Direction control pin 2

void setup() {
  pinMode(ENA, OUTPUT);  // Set ENA as output
  pinMode(IN1, OUTPUT);  // Set IN1 as output
  pinMode(IN2, OUTPUT);  // Set IN2 as output
}

void loop() {
  // Rotate motor forward
  digitalWrite(IN1, HIGH);  // Set IN1 high
  digitalWrite(IN2, LOW);   // Set IN2 low
  analogWrite(ENA, 150);    // Set motor speed (0-255)

  delay(2000);  // Run motor for 2 seconds

  // Rotate motor backward
  digitalWrite(IN1, LOW);   // Set IN1 low
  digitalWrite(IN2, HIGH);  // Set IN2 high
  analogWrite(ENA, 150);    // Set motor speed (0-255)

  delay(2000);  // Run motor for 2 seconds

  // Stop motor
  digitalWrite(IN1, LOW);   // Set IN1 low
  digitalWrite(IN2, LOW);   // Set IN2 low
  analogWrite(ENA, 0);      // Set motor speed to 0

  delay(2000);  // Wait for 2 seconds before repeating
}
Troubleshooting and FAQs
Common Issues
Motor Not Spinning:
- Check the power supply voltage and current.
- Verify connections to the motor driver and microcontroller.
- Ensure the motor driver is receiving control signals.
Motor Spins in One Direction Only:
- Verify the direction control pins (e.g., IN1 and IN2) are correctly connected.
- Check the logic levels being sent to the motor driver.
Motor Overheating:
- Reduce the load on the motor or use a motor with higher torque.
- Ensure proper ventilation or add a heat sink.
Wheels Wobbling:
- Check that the wheels are securely attached to the motor shaft.
- Use compatible hubs or adapters for a snug fit.
FAQs
Can I use a single power supply for both the motor and microcontroller?
- It is recommended to use separate power supplies to avoid voltage drops and noise affecting the microcontroller.
What type of motor driver should I use?
- For low-power motors, L293D or L298N drivers are suitable. For high-power motors, consider using MOSFET-based drivers or dedicated motor controllers.
How do I calculate the required torque for my application?
- Determine the load weight, wheel radius, and desired acceleration. Use the formula:
Torque (Nm) = Force (N) × Radius (m).
Force can be calculated as mass × acceleration.
- Determine the load weight, wheel radius, and desired acceleration. Use the formula:
This documentation provides a comprehensive guide to using motor and wheels assemblies effectively in your projects.