The Pixhawk Px4 Front, manufactured by 3D Robotics (Part ID: PX4), is a high-performance flight control hardware designed for drones and other unmanned vehicles. It serves as the central processing unit for autonomous navigation, stabilization, and control. Equipped with advanced sensors and robust processing capabilities, the Pixhawk Px4 Front supports a wide range of autopilot software, including PX4 and ArduPilot, making it a versatile choice for hobbyists, researchers, and commercial applications.
Explore Projects Built with Pixhawk Px4 Front
Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
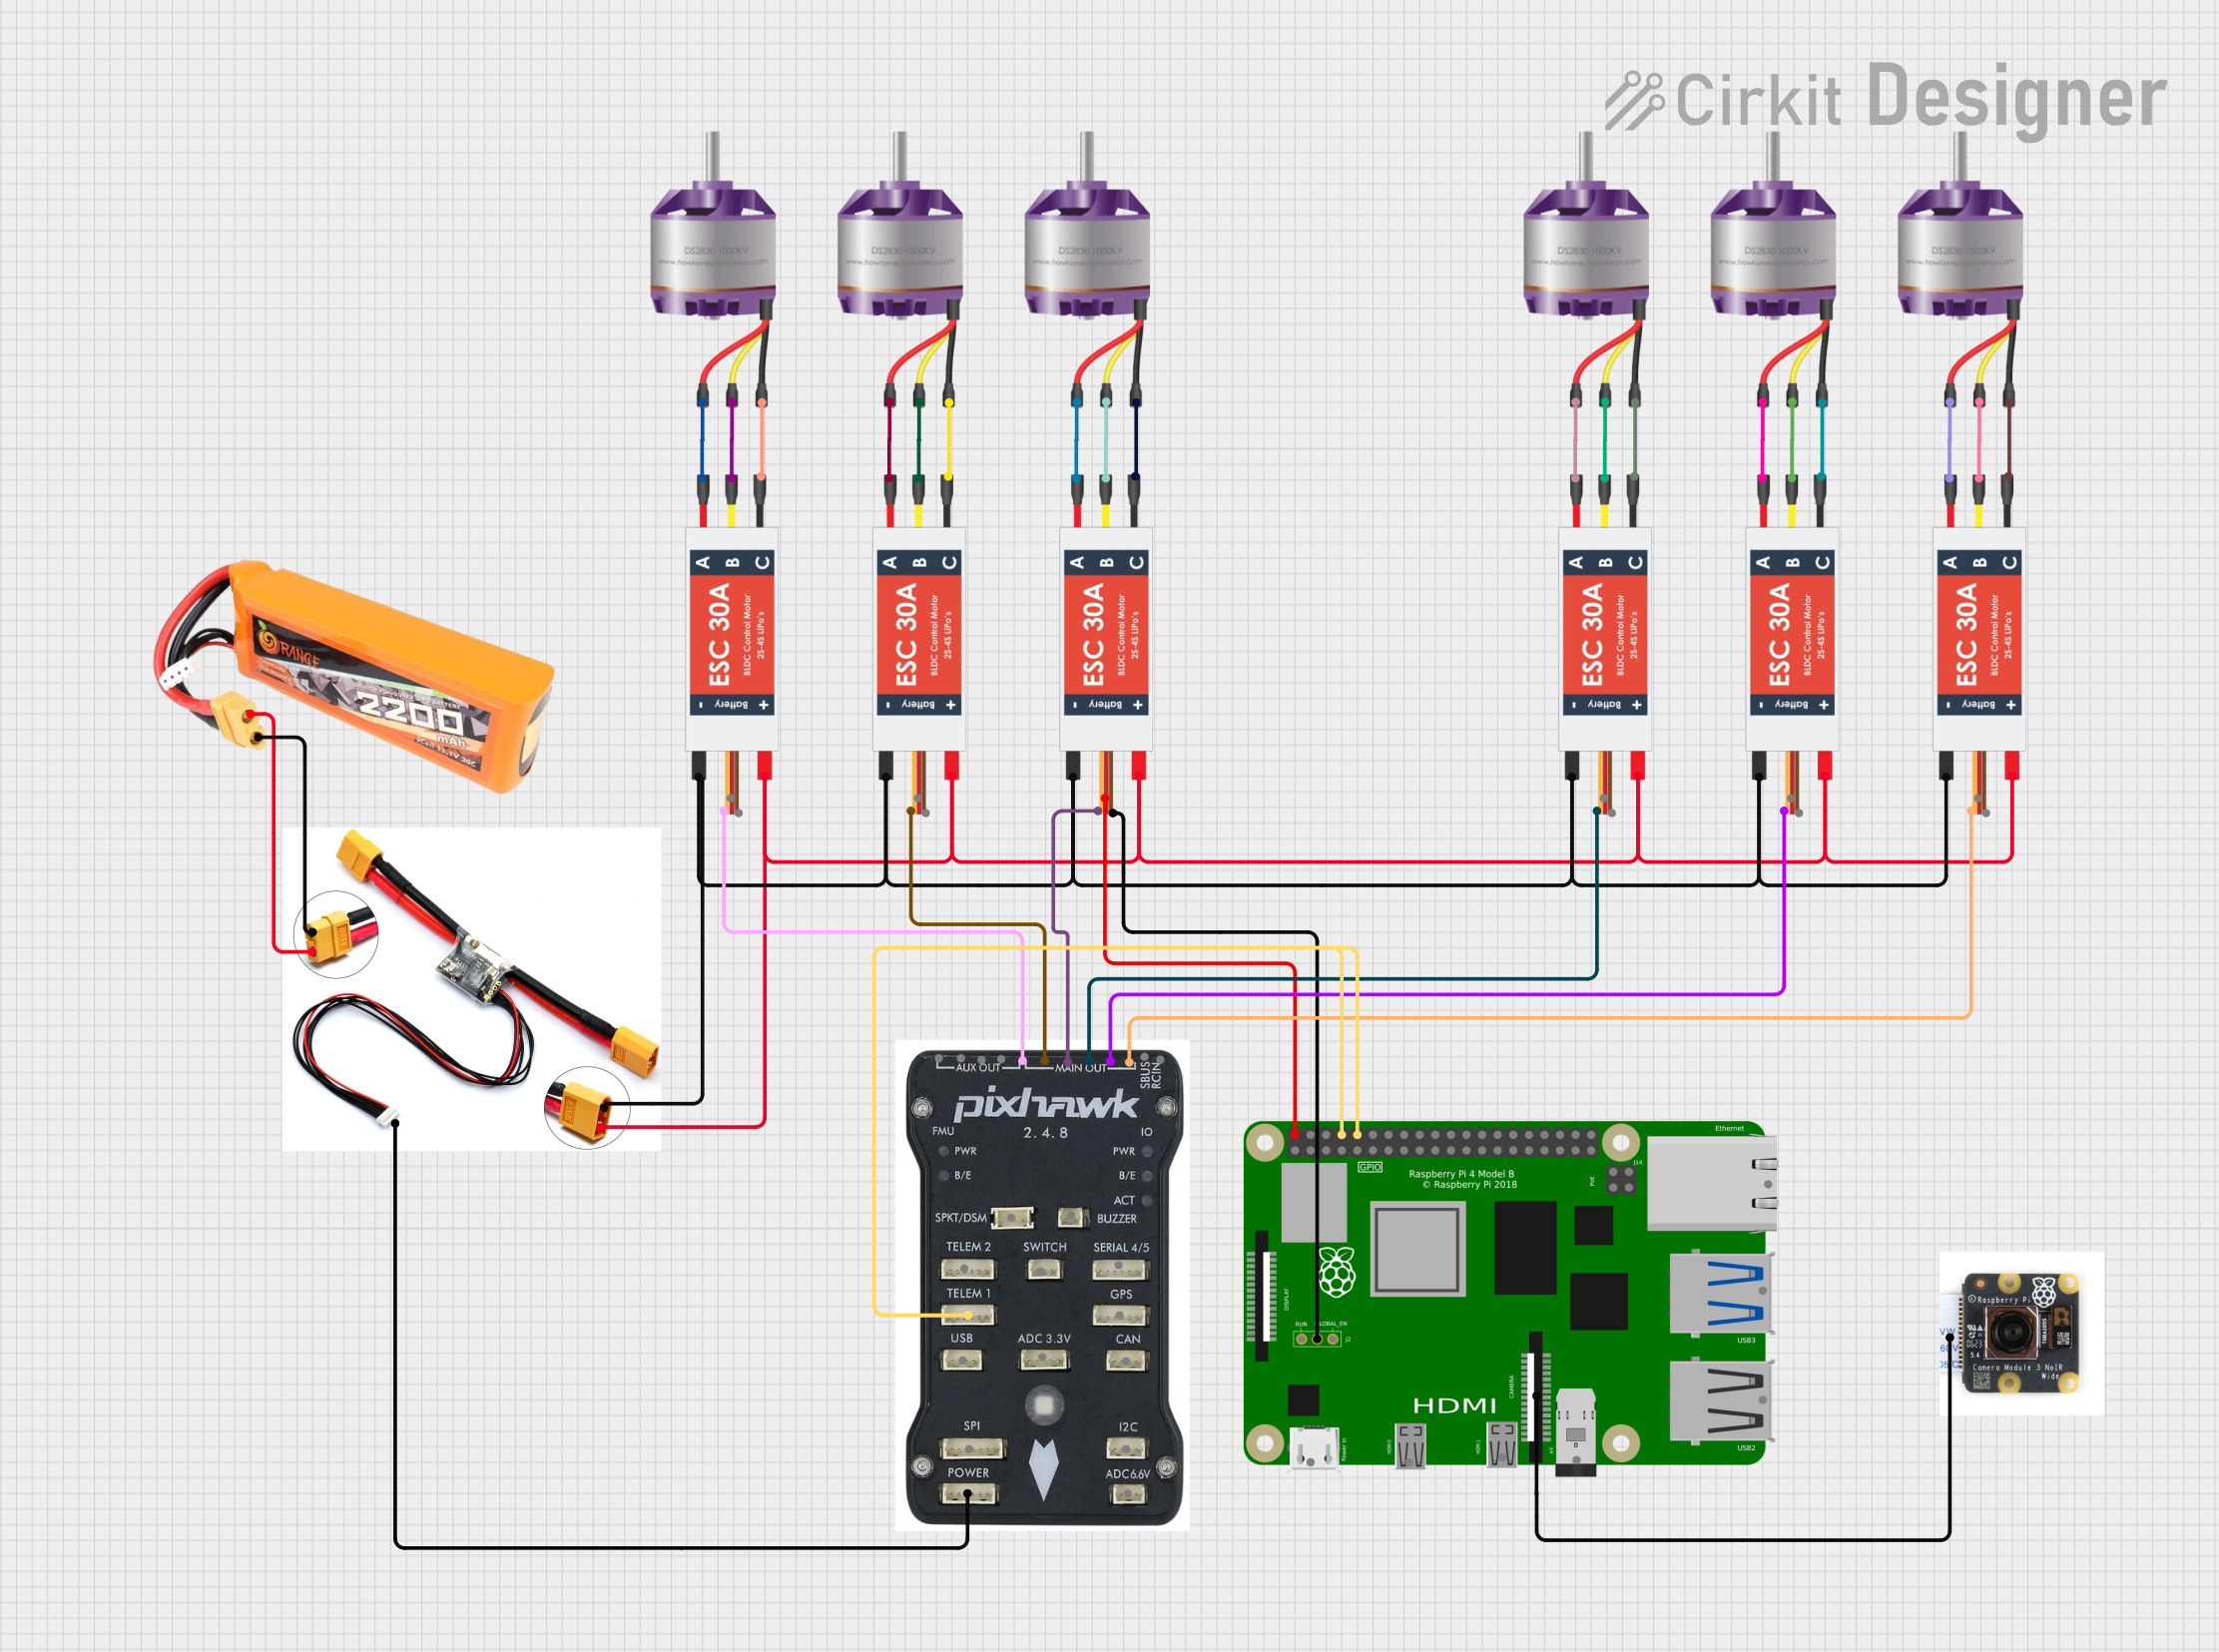
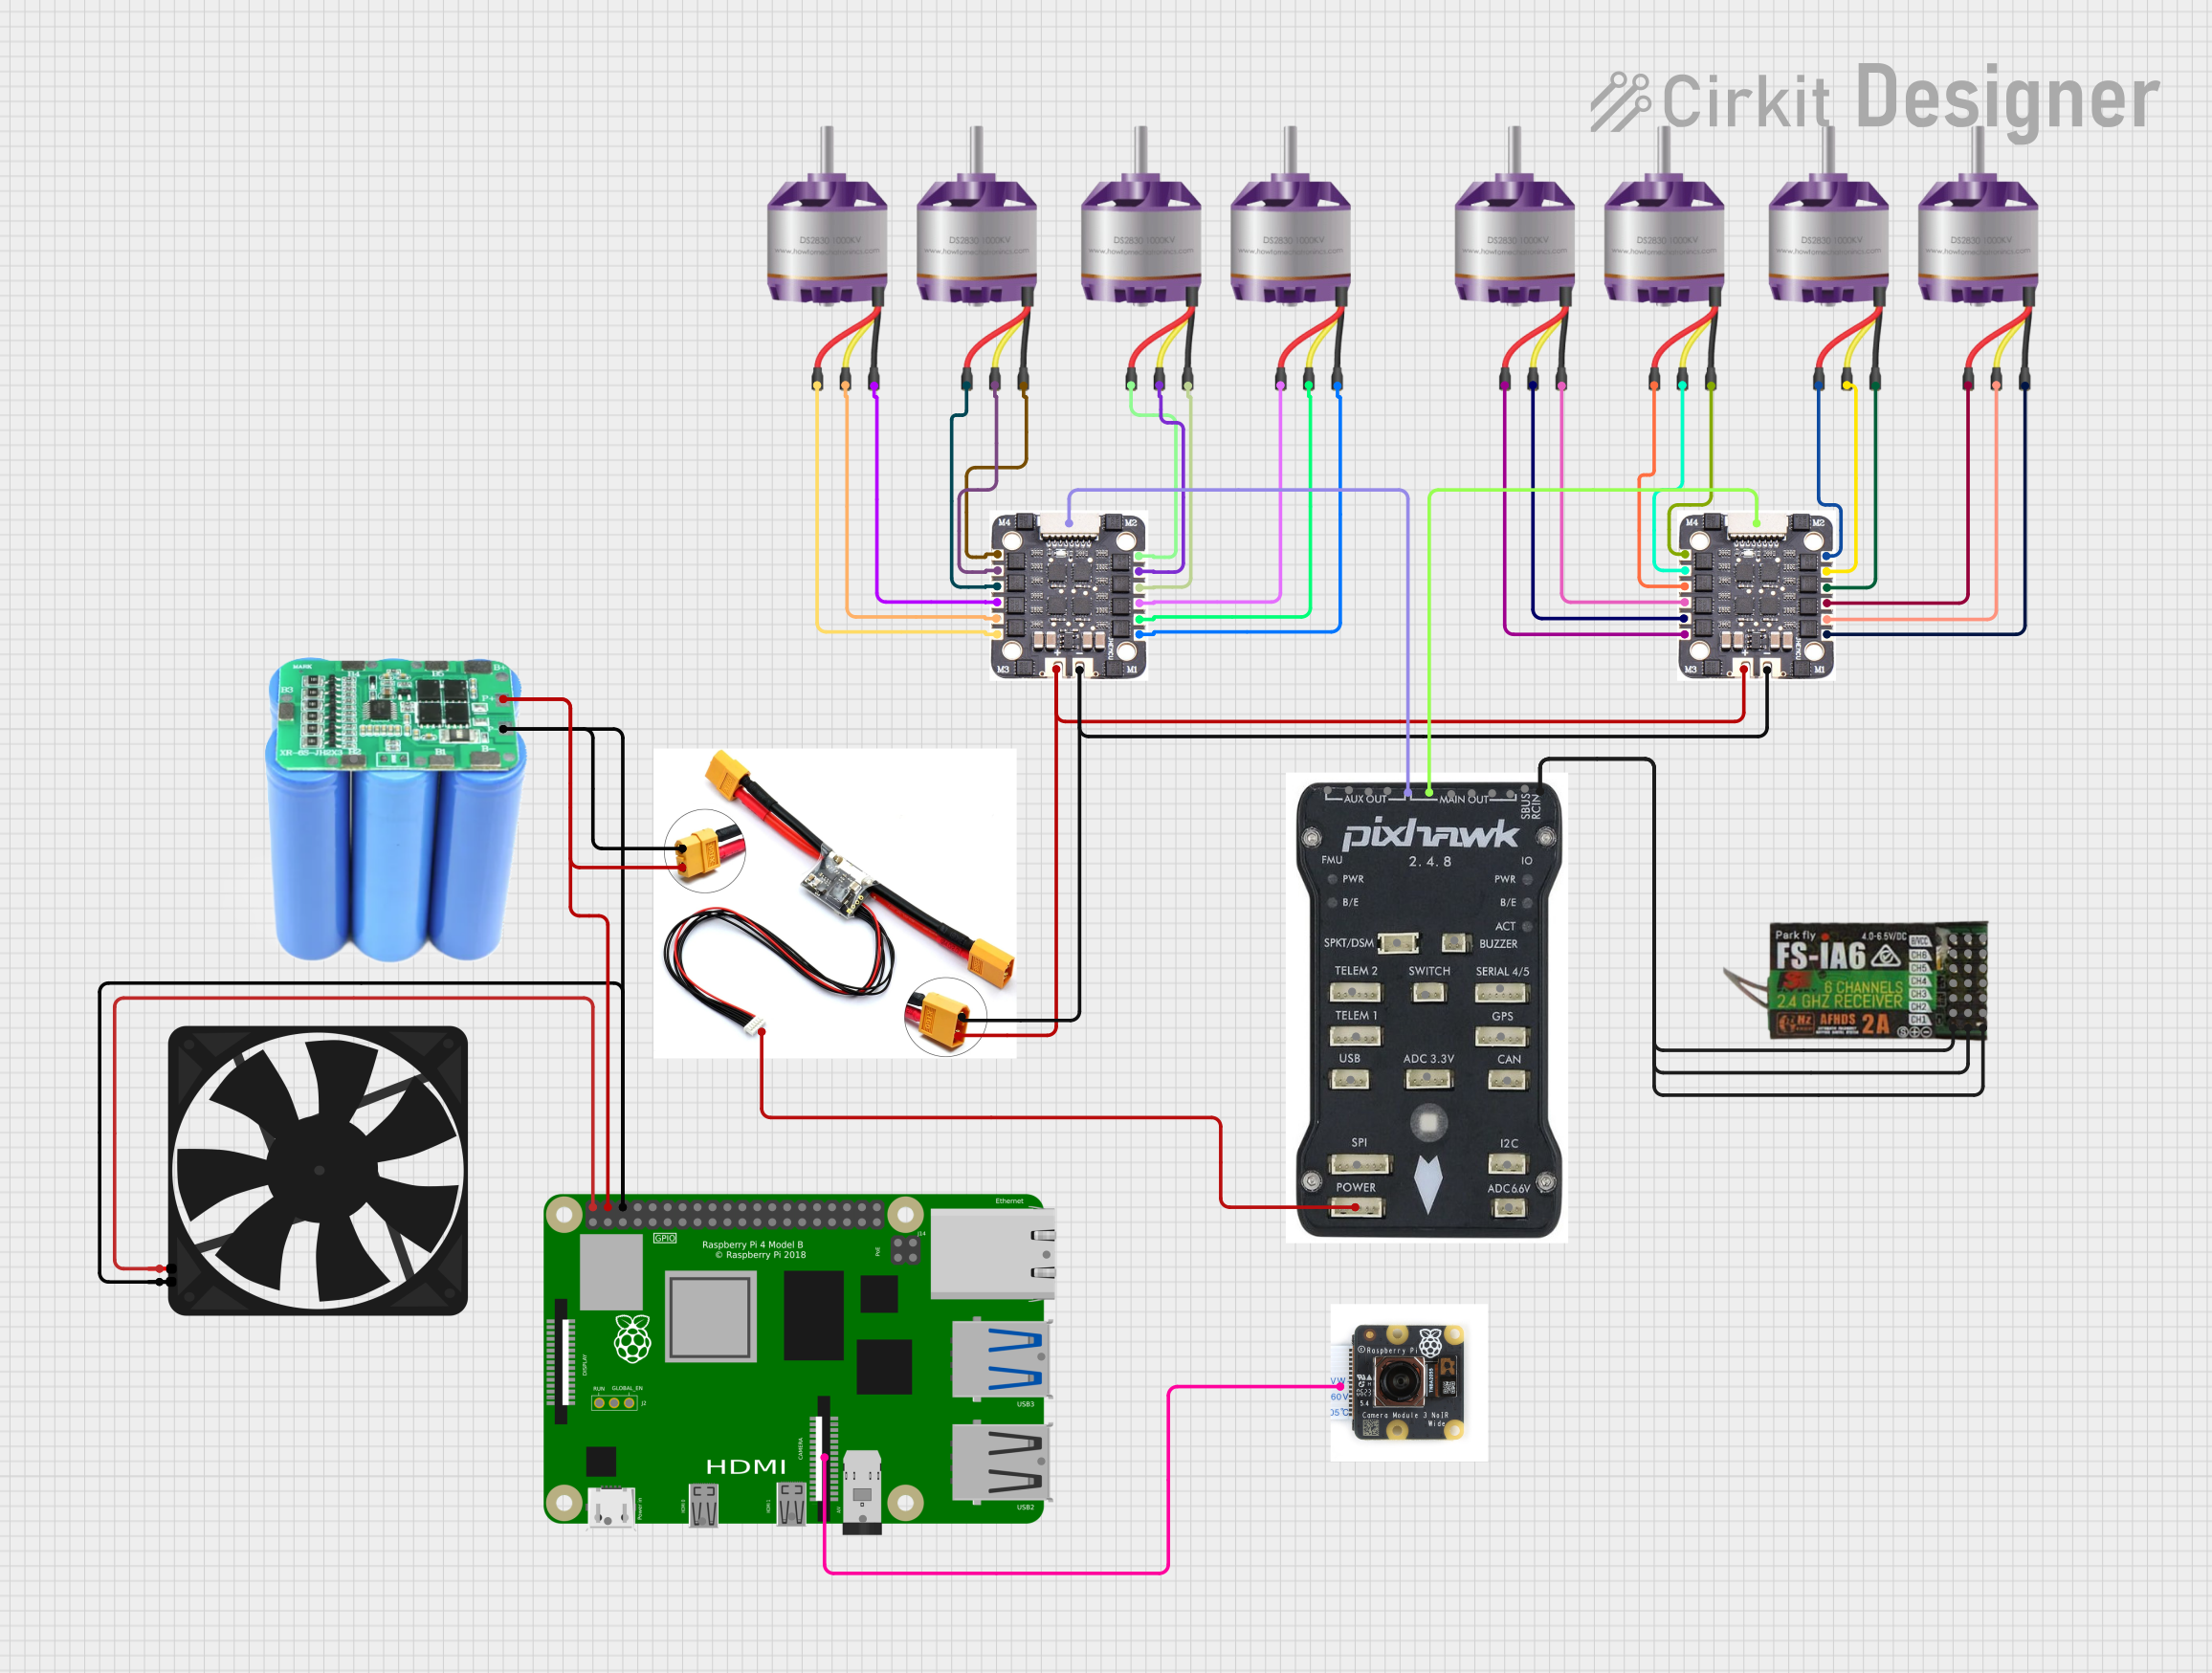
This circuit is designed for a multi-motor application, likely a drone or a similar vehicle, featuring eight brushless motors controlled by two 4-in-1 electronic speed controllers (ESCs). The ESCs are powered by a 3s2p 18650 battery pack and interfaced with a Pixhawk flight controller for motor management. Additionally, the system includes a Raspberry Pi 4B for advanced processing and control, which is connected to a NoIR camera module and a cooling fan, and a power module to supply and monitor the power to the Pixhawk.
This circuit is designed to control multiple brushless motors using electronic speed controllers (ESCs) managed by a Pixhawk flight controller. The system is powered by a LiPo battery, and a Raspberry Pi 4B is used for additional processing and interfacing with a camera module. The ESCs receive power from the battery and control signals from the Pixhawk, which in turn communicates with the Raspberry Pi for telemetry and control purposes.
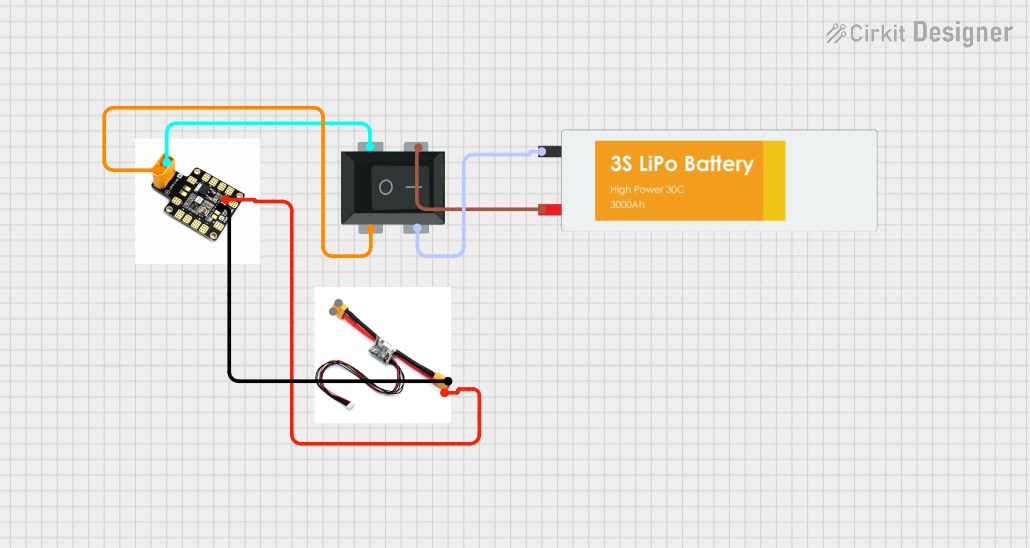
This circuit is designed to power a Pixhawk module using a LiPo battery. The circuit includes a rocker switch to control the power flow from the battery to a power distribution board (PDB), which then supplies 12V to the Pixhawk module.
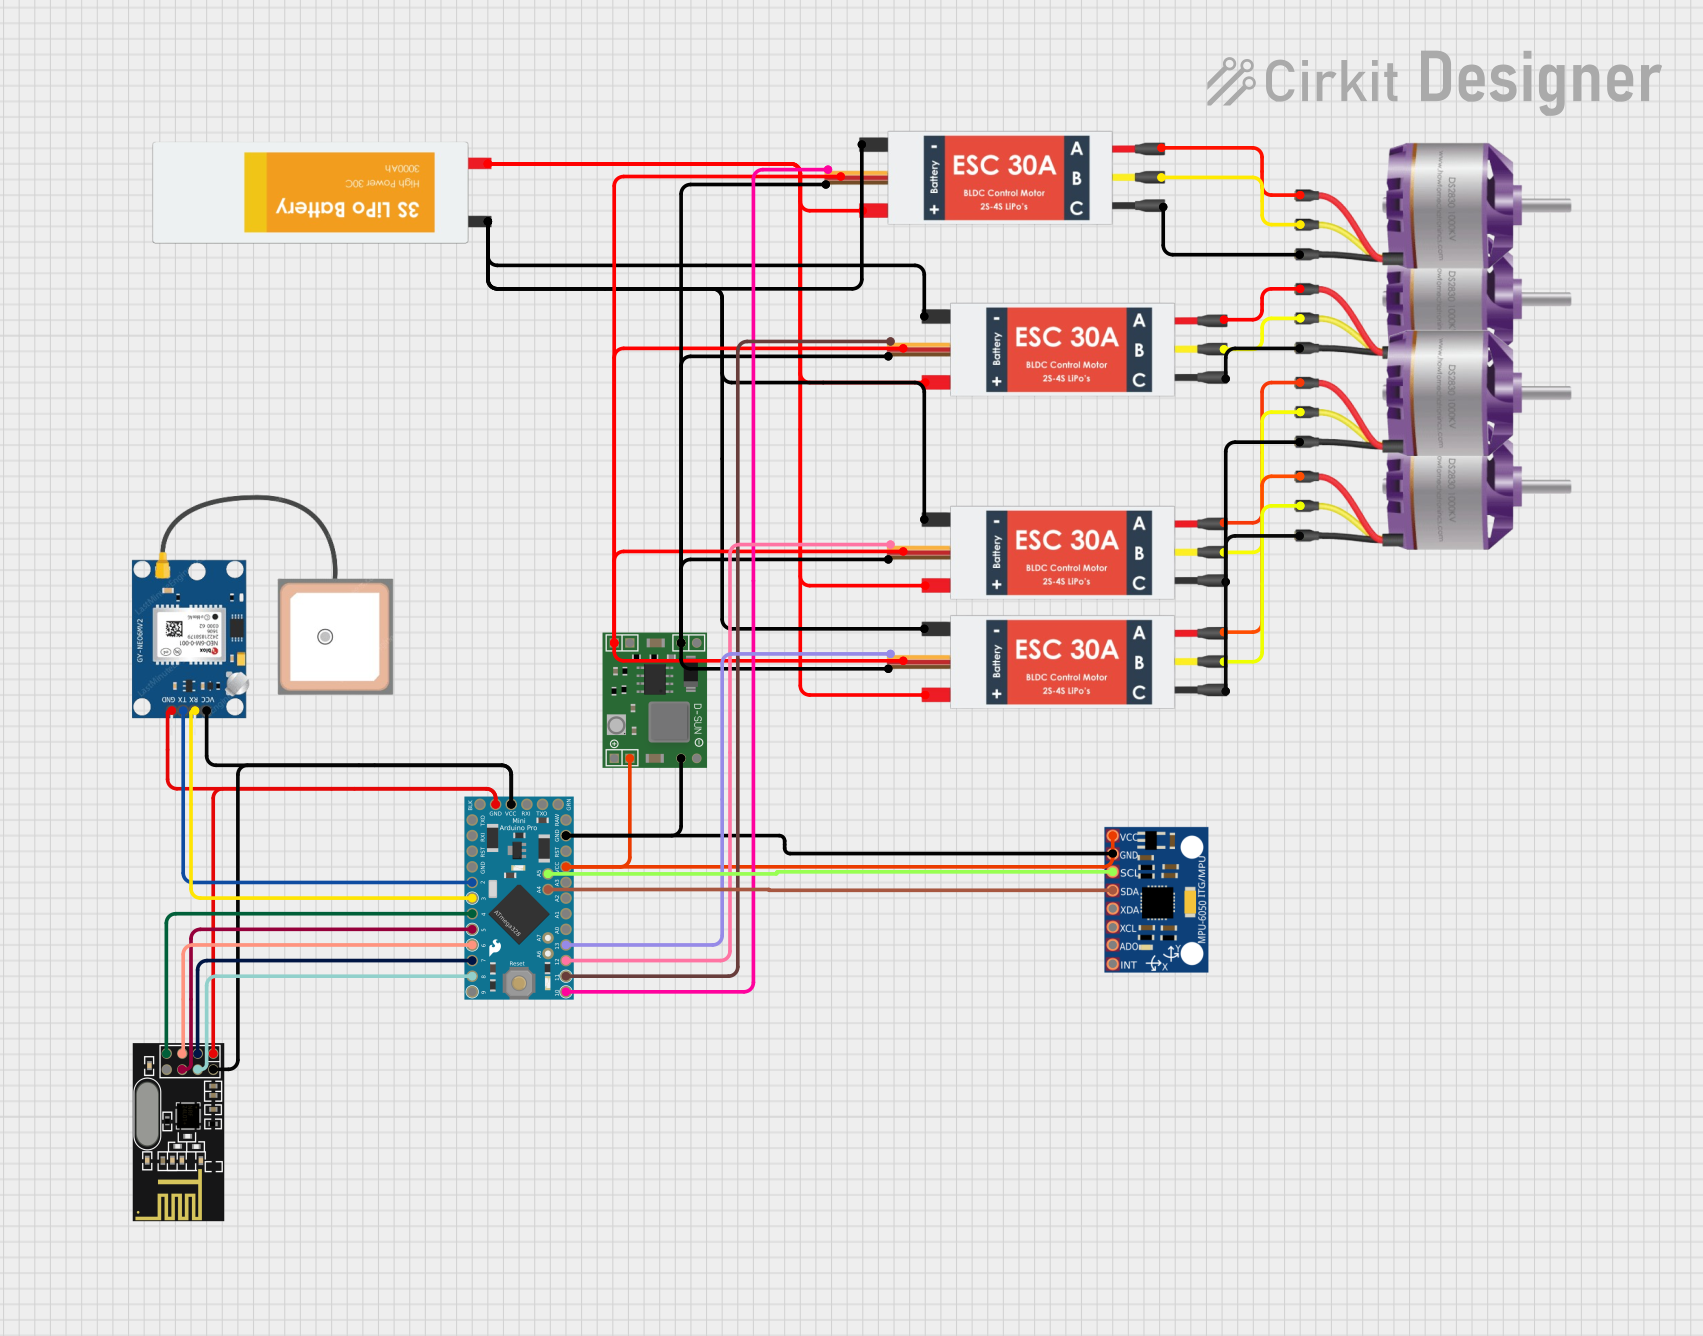
This circuit is designed for a quadcopter control system. It features an Arduino Pro Mini as the central microcontroller, interfacing with a GPS module for positioning, an NRF24L01 module for wireless communication, and an MPU-6050 for motion sensing. Power regulation is managed by an MP1584EN board, and four electronic speed controllers (ESCs) are connected to brushless motors for propeller control.
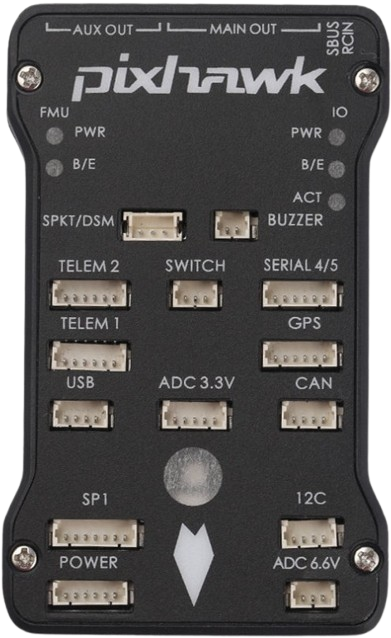
The Pixhawk Px4 Front features multiple connectors for peripherals, sensors, and power. Below is a summary of the key pin configurations:
Power Input
Pin Name
Description
VDD_5V
Main power input (4.1V to 5.7V)
GND
Ground connection
I/O Ports
Port Name
Pin Name
Description
TELEM1
TX, RX
Telemetry port 1 for communication
TELEM2
TX, RX
Telemetry port 2 for communication
GPS
TX, RX, GND
GPS module connection
I2C
SCL, SDA
I2C bus for external sensors
CAN
CAN_H, CAN_L
CAN bus for advanced peripherals
PWM Outputs
Pin Name
Description
PWM1-8
Motor/servo control signals
GND
Ground connection
USB Interface
Pin Name
Description
USB_D+
USB data positive
USB_D-
USB data negative
GND
Ground connection
Usage Instructions
How to Use the Pixhawk Px4 Front in a Circuit
Powering the Pixhawk: Connect a regulated 5V power supply to the VDD_5V pin. Ensure the power source can provide sufficient current for the connected peripherals.
Connecting Peripherals:
Attach a GPS module to the GPS port for navigation.
Connect telemetry radios to TELEM1 or TELEM2 for remote communication.
Use the I2C port to connect external sensors like rangefinders or airspeed sensors.
Motor and Servo Connections: Connect ESCs or servos to the PWM output pins (PWM1-8). Ensure proper calibration of ESCs before flight.
Software Setup:
Install the PX4 or ArduPilot firmware using the QGroundControl or Mission Planner software.
Configure the flight parameters, calibrate sensors, and set up the vehicle type (e.g., quadcopter, fixed-wing).
Testing: Perform a pre-flight check to ensure all sensors, motors, and communication links are functioning correctly.
Important Considerations and Best Practices
Power Supply: Use a stable power source to avoid voltage drops that may cause the Pixhawk to reboot mid-operation.
Firmware Updates: Regularly update the firmware to access new features and bug fixes.
Sensor Calibration: Always calibrate the accelerometer, gyroscope, and compass before the first use or after significant temperature changes.
Safety: Test the system in a controlled environment before deploying it in real-world applications.
Example Code for Arduino UNO Integration
The Pixhawk Px4 Front can communicate with an Arduino UNO via the UART interface. Below is an example code snippet for reading telemetry data:
#include <SoftwareSerial.h>

// Define RX and TX pins for communication with Pixhawk
#define RX_PIN 10
#define TX_PIN 11

// Initialize SoftwareSerial for Pixhawk communication
SoftwareSerial pixhawkSerial(RX_PIN, TX_PIN);

void setup() {
  // Start serial communication with Pixhawk
  pixhawkSerial.begin(57600); // Pixhawk default baud rate
  Serial.begin(9600);         // Serial monitor baud rate

  Serial.println("Pixhawk-Arduino Communication Initialized");
}

void loop() {
  // Check if data is available from Pixhawk
  if (pixhawkSerial.available()) {
    // Read and print data from Pixhawk
    char data = pixhawkSerial.read();
    Serial.print(data);
  }
}
Troubleshooting and FAQs
Common Issues and Solutions
Pixhawk Not Powering On:
Cause: Insufficient or unstable power supply.
Solution: Verify the input voltage is within the 4.1V to 5.7V range. Use a reliable power source.
No Communication with Telemetry Radios:
Cause: Incorrect baud rate or wiring.
Solution: Ensure the baud rate matches the telemetry module settings. Double-check the TX and RX connections.
GPS Not Detected:
Cause: Loose connection or incompatible GPS module.
Solution: Verify the GPS module is connected to the correct port. Check compatibility with the Pixhawk.
Motors Not Responding:
Cause: Incorrect PWM connections or ESC calibration.
Solution: Ensure the ESCs are connected to the correct PWM pins. Calibrate the ESCs using the autopilot software.
FAQs
Q: Can the Pixhawk Px4 Front be used with fixed-wing aircraft? A: Yes, it supports multiple vehicle types, including fixed-wing, rotary-wing, and VTOL aircraft.
Q: What software is compatible with the Pixhawk Px4 Front? A: The Pixhawk Px4 Front supports PX4 and ArduPilot firmware.
Q: How do I update the firmware? A: Use QGroundControl or Mission Planner to download and install the latest firmware.
Q: Can I connect multiple sensors to the I2C port? A: Yes, the I2C bus supports multiple devices, but ensure each device has a unique address.
This documentation provides a comprehensive guide to using the Pixhawk Px4 Front effectively. For further assistance, refer to the official 3D Robotics support resources.

 Open Project in Cirkit Designer