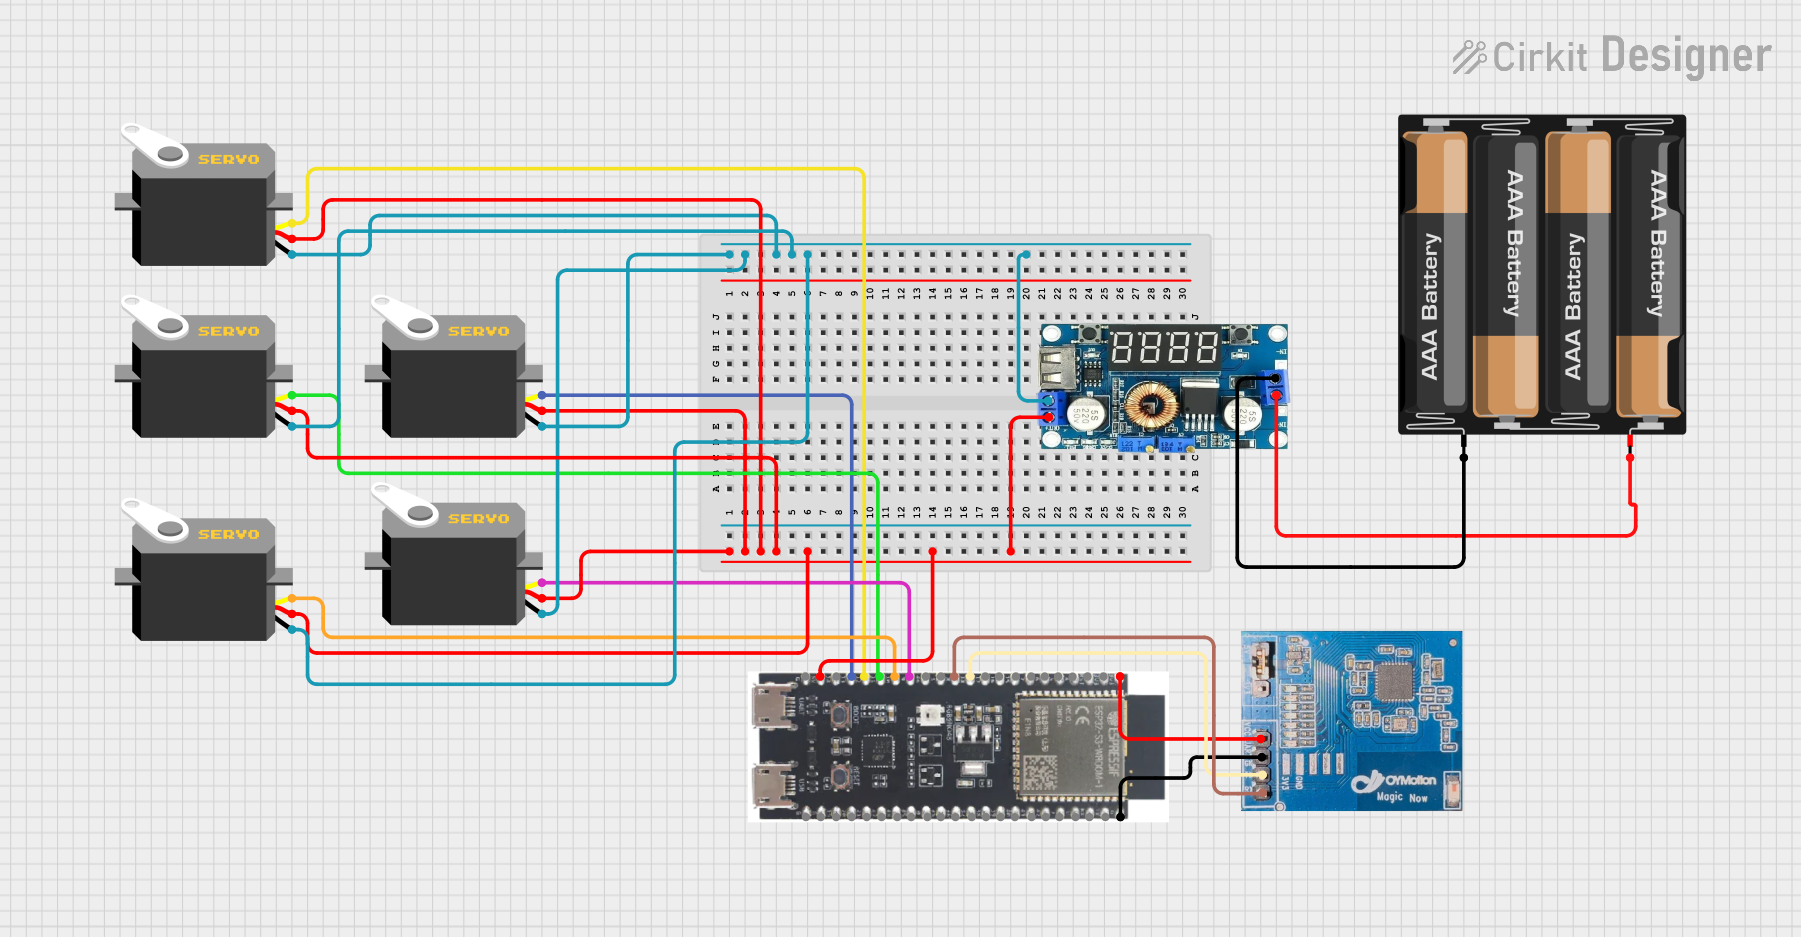
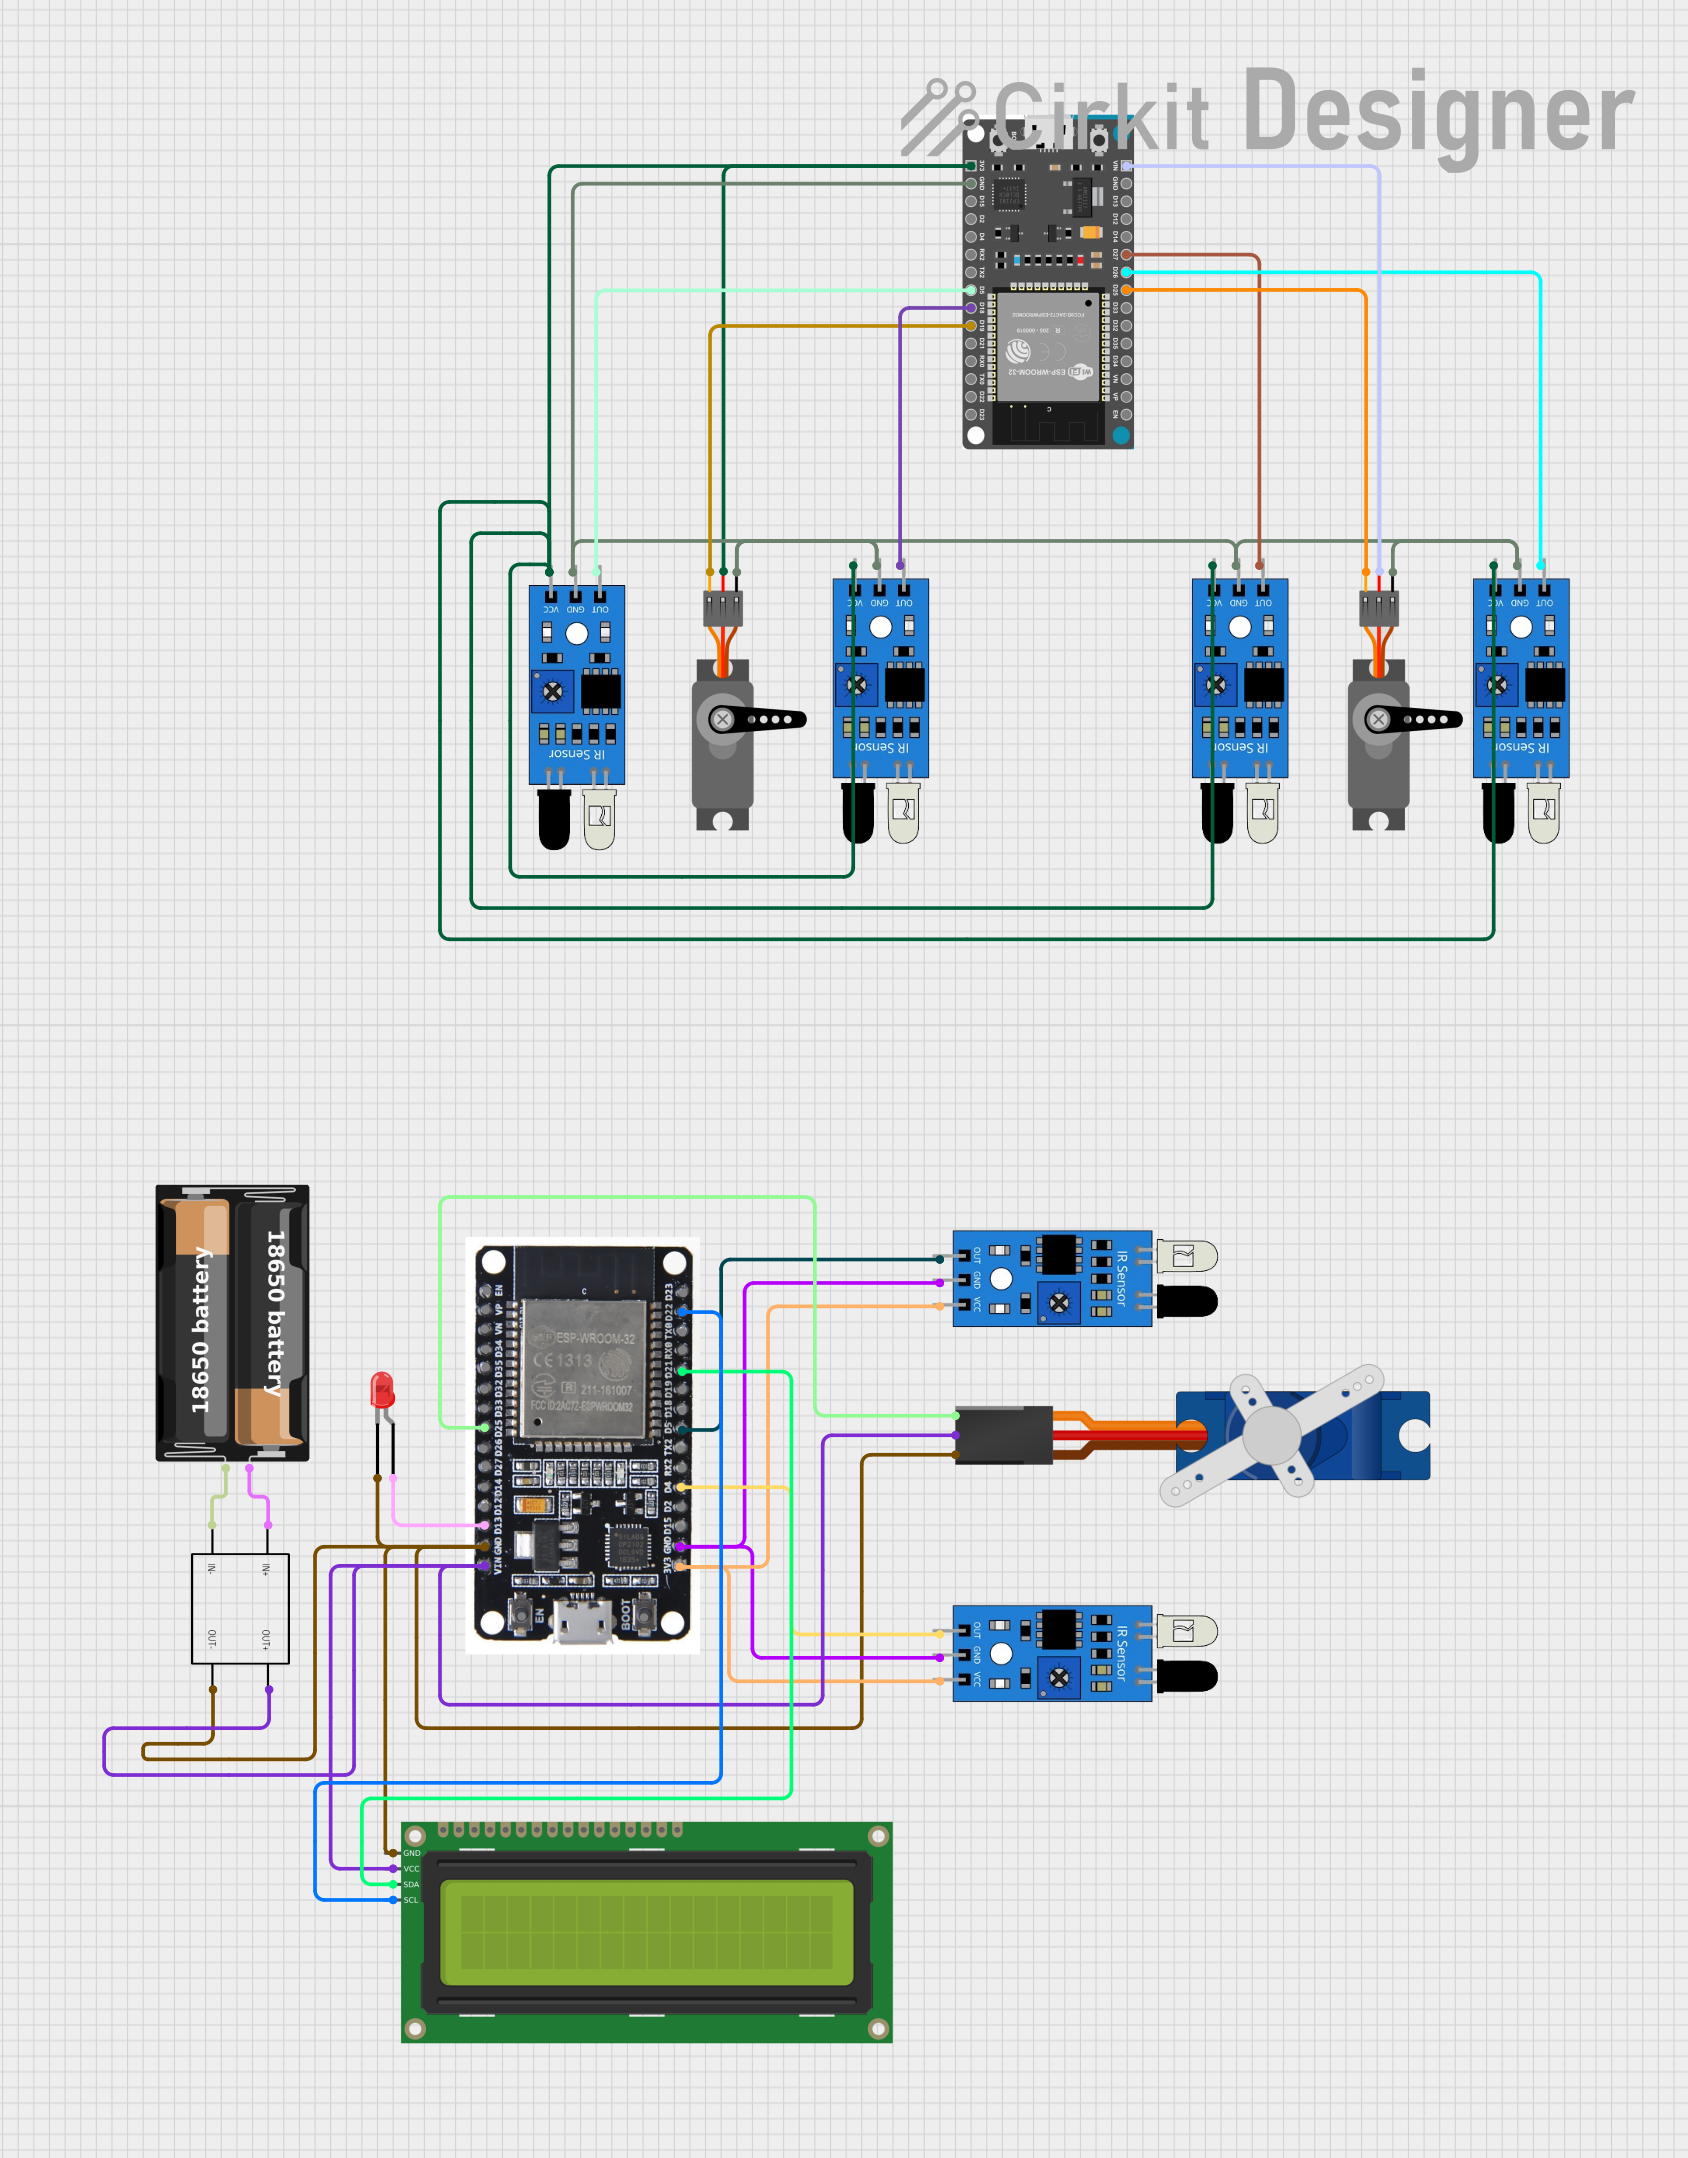
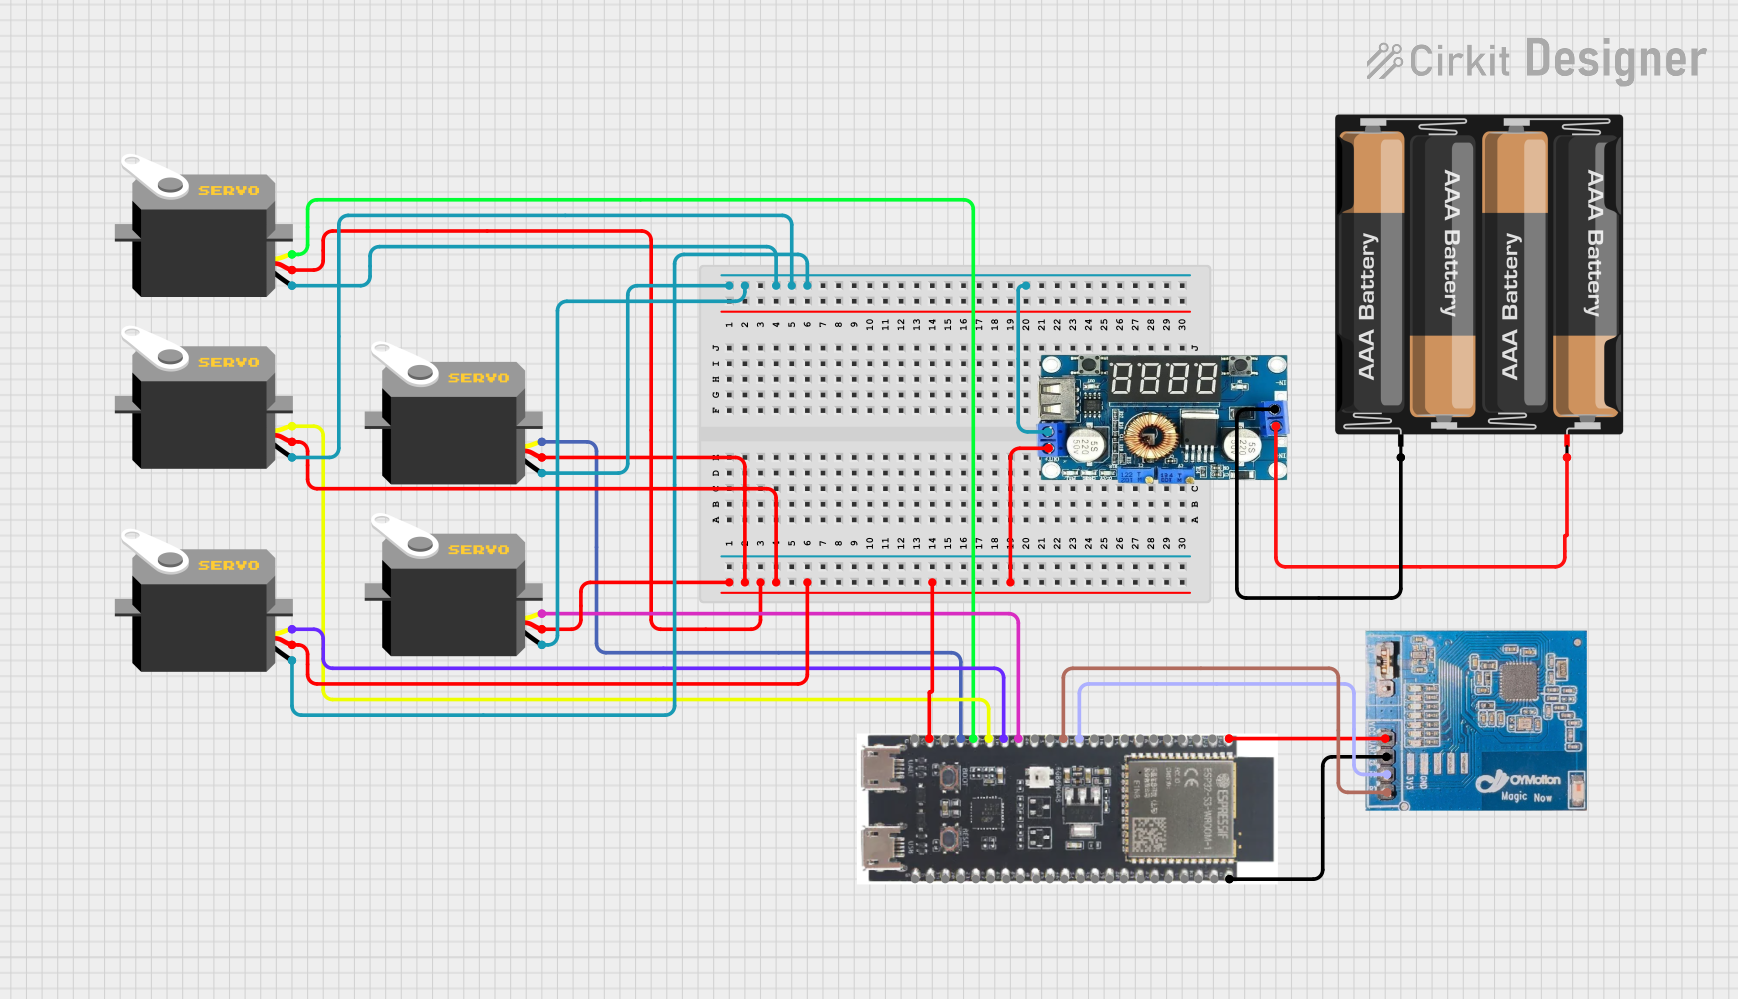
Introduction
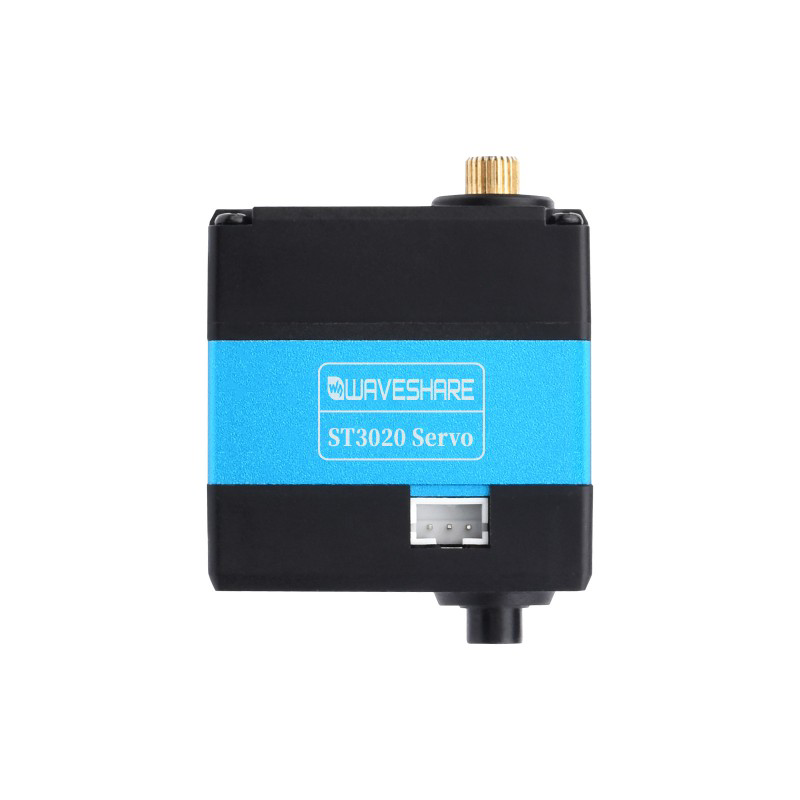
The SERVO ST3020, manufactured by Waveshare, is a high-performance servo motor designed for precise control in robotics and automation applications. Its compact design, high torque output, and built-in feedback system make it ideal for tasks requiring accurate positioning and smooth motion. This servo motor is widely used in robotic arms, RC vehicles, drones, and industrial automation systems.
Common Applications
- Robotic arms and manipulators
- RC vehicles and drones
- Industrial automation systems
- Precision control in mechatronics projects
- Educational robotics kits
Technical Specifications
The SERVO ST3020 is engineered for reliability and performance. Below are its key technical details:
Pin Configuration
The SERVO ST3020 has a standard 3-pin connector for interfacing with control systems. The pinout is as follows:
Usage Instructions
Connecting the SERVO ST3020
- Power Supply: Connect the red wire to a 5V or 6V power source. Ensure the power supply can provide sufficient current (at least 2A) to handle the servo's peak load.
- Ground: Connect the brown wire to the ground (GND) of your circuit.
- Signal: Connect the orange wire to the PWM output pin of your microcontroller or servo controller.
Controlling the Servo with an Arduino UNO
The SERVO ST3020 can be easily controlled using an Arduino UNO. Below is an example code snippet to rotate the servo to specific angles:
#include <Servo.h> // Include the Servo library

Servo myServo; // Create a Servo object

void setup() {
  myServo.attach(9); // Attach the servo to pin 9 on the Arduino
}

void loop() {
  myServo.write(0); // Move the servo to 0 degrees
  delay(1000);      // Wait for 1 second

  myServo.write(90); // Move the servo to 90 degrees
  delay(1000);       // Wait for 1 second

  myServo.write(180); // Move the servo to 180 degrees
  delay(1000);        // Wait for 1 second
}
Important Considerations
- Power Supply: Use a dedicated power source for the servo to avoid voltage drops that may affect other components in your circuit.
- PWM Signal: Ensure the PWM signal is within the specified range (500 µs to 2500 µs) to avoid damaging the servo.
- Mechanical Load: Avoid exceeding the servo's torque rating to prevent overheating or mechanical failure.
Troubleshooting and FAQs
Common Issues and Solutions
Servo Not Moving
- Cause: Incorrect wiring or insufficient power supply.
- Solution: Double-check the wiring and ensure the power supply meets the servo's voltage and current requirements.
Servo Jittering
- Cause: Noisy or unstable PWM signal.
- Solution: Use a stable PWM source and ensure proper grounding.
Overheating
- Cause: Excessive mechanical load or prolonged operation at stall torque.
- Solution: Reduce the load on the servo and avoid operating it at stall torque for extended periods.
Limited Range of Motion
- Cause: PWM signal out of range or mechanical obstruction.
- Solution: Verify the PWM signal is within the 500 µs to 2500 µs range and check for any physical obstructions.
FAQs
Q: Can I power the SERVO ST3020 directly from the Arduino UNO?
A: It is not recommended. The Arduino's 5V pin cannot supply enough current for the servo, especially under load. Use an external power source.
Q: What happens if I exceed the servo's torque rating?
A: Exceeding the torque rating can cause the servo to overheat, reduce its lifespan, or result in mechanical failure.
Q: Can I use the SERVO ST3020 for continuous rotation?
A: No, the SERVO ST3020 is designed for positional control within a 0° to 180° range. For continuous rotation, use a servo specifically designed for that purpose.
Q: How do I extend the servo's lifespan?
A: Operate the servo within its specified voltage, torque, and temperature limits. Avoid prolonged operation at stall torque and ensure proper cooling.

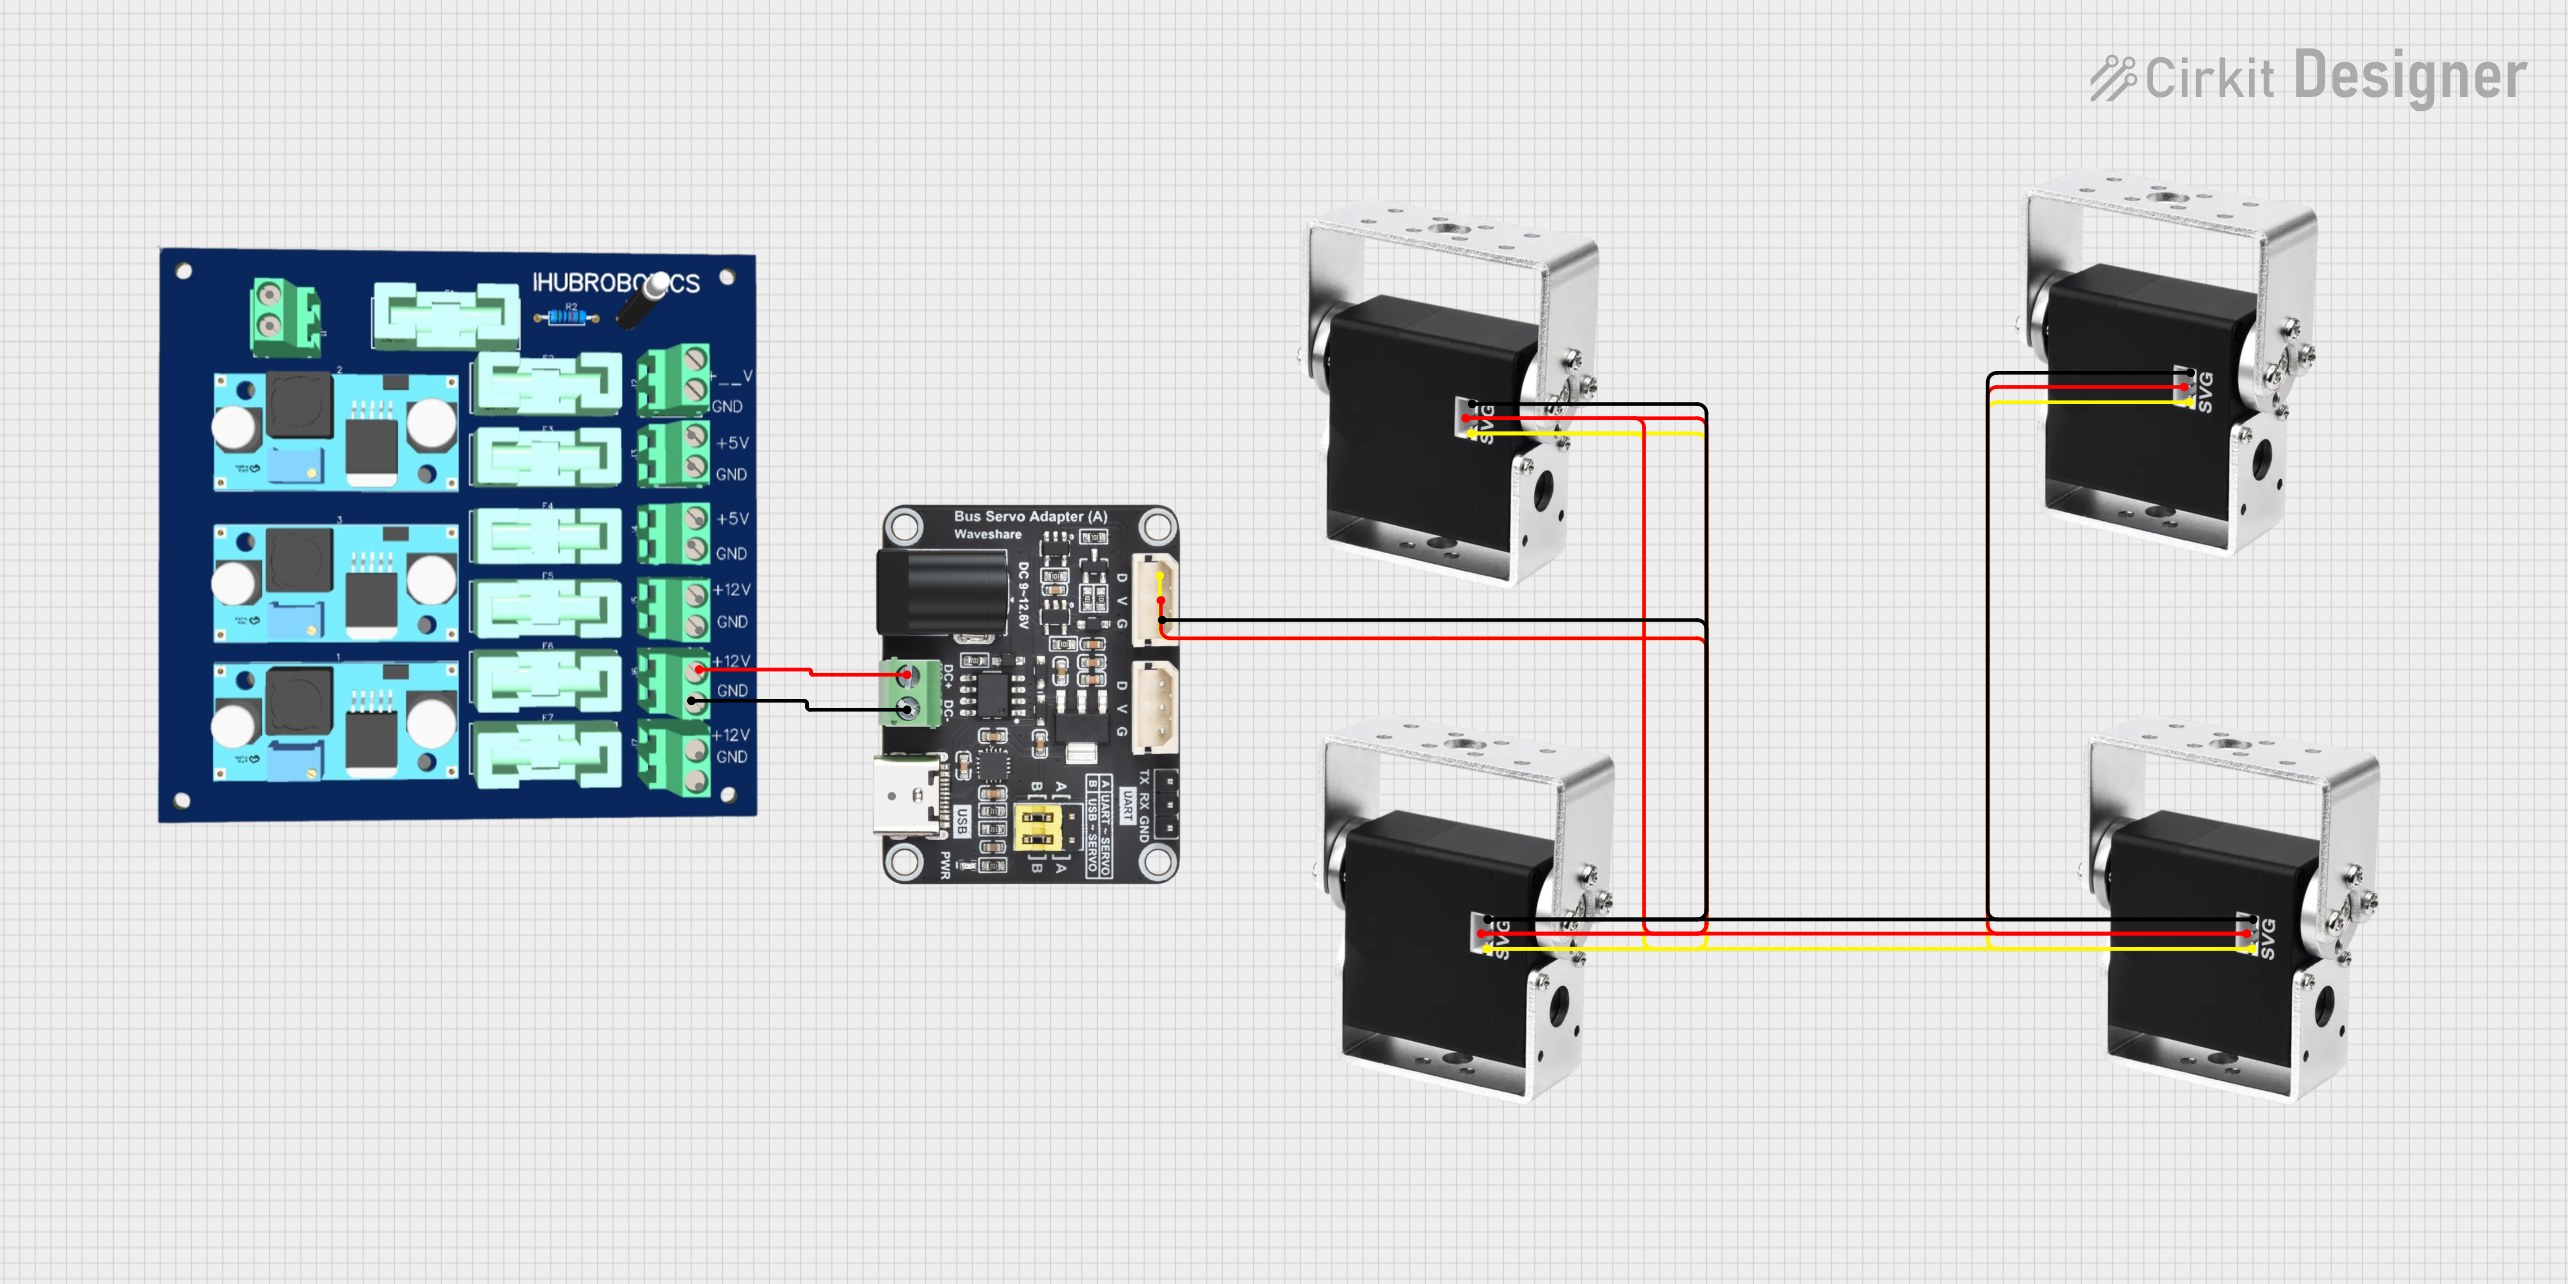
 Open Project in Cirkit Designer