
Cirkit Designer LogoCirkit DesignerYour all-in-one circuit design IDE Launch Cirkit Designer App

How to Use Tmc2208: Examples, Pinouts, and Specs

Image of Tmc2208Design with Tmc2208 in Cirkit Designer

Introduction

The TMC2208 is a high-performance stepper motor driver manufactured by Trinamic (TMC). It is widely used in 3D printers, CNC machines, and other motion control applications. This driver is known for its silent operation, thanks to Trinamic's StealthChop technology, and its ability to achieve precise microstepping. The TMC2208 can be configured via UART interface, making it a versatile and user-friendly choice for various projects.

Explore Projects Built with Tmc2208

Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
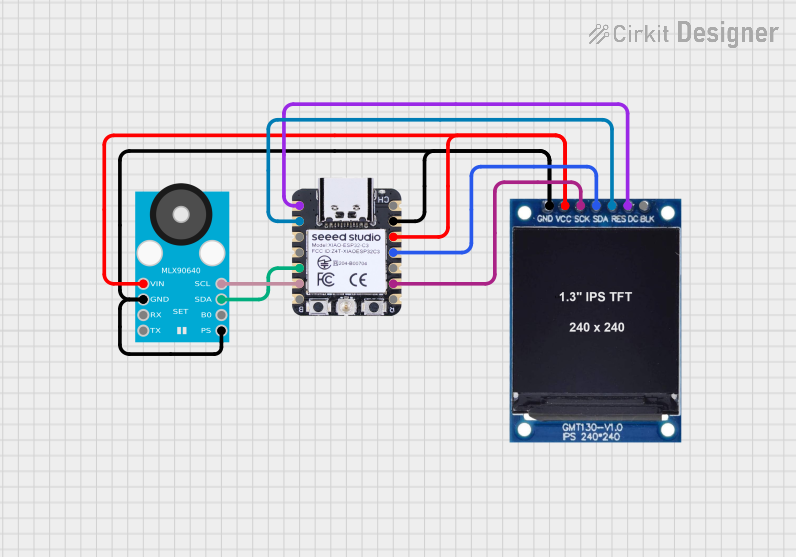
Image of ESP32C3-Based Thermal Imaging Camera with TFT Display: A project utilizing Tmc2208 in a practical application

ESP32C3-Based Thermal Imaging Camera with TFT Display

This circuit connects a 1.3 inch TFT Module 240×240 ST7789 display, a GY-MCU90640 thermal camera module, and a XIAO ESP32C3 microcontroller to create a thermal imaging system. The ESP32C3 microcontroller is programmed to read temperature data from the thermal camera, process it, and display a visual representation of the temperature distribution on the TFT screen. The circuit is designed for applications requiring thermal monitoring, such as detecting heat sources or monitoring temperature variations in an environment.

Open Project in Cirkit Designer
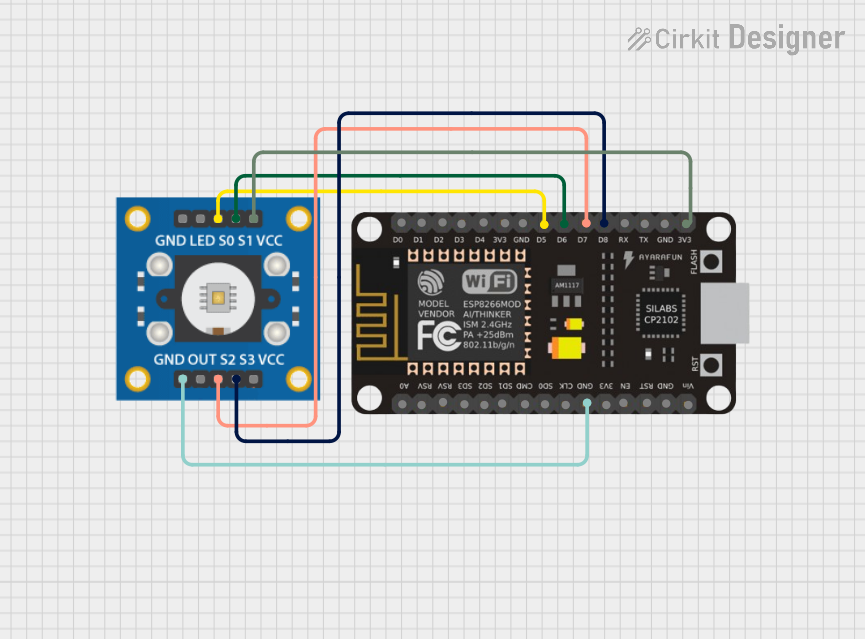

Image of ESP8266 NodeMCU Controlled TCS3200 Color Sensor Interface: A project utilizing Tmc2208 in a practical application
ESP8266 NodeMCU Controlled TCS3200 Color Sensor Interface

This circuit connects an ESP8266 NodeMCU microcontroller to a TCS3200 color sensor. The NodeMCU's digital pins D5, D6, D7, and D8 are interfaced with the TCS3200's S0, S1, S2, and S3 pins respectively, allowing the microcontroller to control the color sensor's filtering and frequency scaling. Power is supplied to the TCS3200 from the NodeMCU's 3.3V pin, and both devices share a common ground.

Open Project in Cirkit Designer

Common Applications

Technical Specifications

The TMC2208 offers a range of features and specifications that make it suitable for demanding applications. Below are the key technical details:

Parameter Value
Supply Voltage (V_M) 4.75V to 36V
Logic Voltage (V_IO) 3.3V or 5V
Maximum Motor Current (I_RMS) Up to 1.2A (RMS), 2A (peak)
Microstepping Resolution Up to 256 microsteps per full step
Communication Interface UART
Operating Modes StealthChop, SpreadCycle
Standby Current Configurable via UART
Thermal Shutdown Yes
Overcurrent Protection Yes

Pin Configuration

The TMC2208 comes in a 16-pin package. Below is the pinout and description:

Pin Name Description
1 GND Ground connection
2 V_M Motor power supply (4.75V to 36V)
3 VCC_IO Logic voltage input (3.3V or 5V)
4 EN Enable pin (active low)
5 MS1 Microstep resolution selection pin 1
6 MS2 Microstep resolution selection pin 2
7 STEP Step pulse input
8 DIR Direction control input
9 UART UART communication pin
10 DIAG Diagnostic output
11 INDEX Step position indicator
12 CFG1 Configuration pin 1
13 CFG2 Configuration pin 2
14 NC Not connected
15 NC Not connected
16 GND Ground connection

Usage Instructions

How to Use the TMC2208 in a Circuit

  1. Power Supply: Connect the motor power supply (V_M) to a voltage source between 4.75V and 36V. Ensure the logic voltage (VCC_IO) matches your microcontroller's logic level (3.3V or 5V).
  2. Microstepping Configuration: Use the MS1 and MS2 pins to set the desired microstepping resolution. Alternatively, configure microstepping via UART for more flexibility.
  3. Control Signals: Connect the STEP and DIR pins to your microcontroller to control the motor's steps and direction.
  4. UART Communication: For advanced configuration, connect the UART pin to your microcontroller's UART TX pin. Use a suitable library or commands to configure parameters like current limits, standby current, and operating modes.
  5. Enable Pin: Pull the EN pin low to enable the driver. Pull it high to disable the driver.

Important Considerations

Example Code for Arduino UNO

Below is an example of how to control the TMC2208 using an Arduino UNO:

// Example code to control a stepper motor with TMC2208 and Arduino UNO
// Ensure the TMC2208 is connected to the correct pins on the Arduino

#define STEP_PIN 3  // Pin connected to STEP on TMC2208
#define DIR_PIN  4  // Pin connected to DIR on TMC2208
#define EN_PIN   5  // Pin connected to EN on TMC2208

void setup() {
  pinMode(STEP_PIN, OUTPUT); // Set STEP pin as output
  pinMode(DIR_PIN, OUTPUT);  // Set DIR pin as output
  pinMode(EN_PIN, OUTPUT);   // Set EN pin as output

  digitalWrite(EN_PIN, LOW); // Enable the TMC2208 driver
  digitalWrite(DIR_PIN, HIGH); // Set initial direction
}

void loop() {
  // Generate step pulses to move the motor
  digitalWrite(STEP_PIN, HIGH); // Step pulse HIGH
  delayMicroseconds(500);       // Wait 500 microseconds
  digitalWrite(STEP_PIN, LOW);  // Step pulse LOW
  delayMicroseconds(500);       // Wait 500 microseconds
}

Troubleshooting and FAQs

Common Issues and Solutions

  1. Motor Not Moving

    • Cause: Incorrect wiring or insufficient power supply.
    • Solution: Verify all connections and ensure the power supply meets the voltage and current requirements.
  2. Driver Overheating

    • Cause: Excessive motor current or inadequate cooling.
    • Solution: Reduce the motor current via UART or VREF adjustment. Add a heatsink or fan for cooling.
  3. Noisy Operation

    • Cause: Incorrect operating mode or poor motor quality.
    • Solution: Enable StealthChop mode for silent operation. Check the motor for defects.
  4. UART Communication Fails

    • Cause: Incorrect UART wiring or baud rate mismatch.
    • Solution: Verify the UART connections and ensure the baud rate matches the TMC2208's default (typically 9600 bps).

FAQs
