The TB6612FNG module, manufactured by Breakout, is a dual H-bridge motor driver IC designed to control two DC motors or one stepper motor. It provides advanced features such as PWM (Pulse Width Modulation) control, direction control, and current sensing, making it a versatile and efficient choice for motor control applications. This module is widely used in robotics, automation systems, and other projects requiring precise motor control.
Explore Projects Built with TB6612FNG Module
Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
This circuit is an emergency alert system that uses a NUCLEO-F072RB microcontroller to send SMS alerts and make calls via a SIM800L GSM module, while obtaining location data from a GPS NEO 6M module. The system is powered by a Li-ion battery and includes a TP4056 module for battery charging and protection, with a rocker switch to control power to the microcontroller.
This circuit features a LilyGo-SIM7000G module for cellular communication and GPS functionality, interfaced with an RTC DS3231 for real-time clock capabilities. It includes voltage sensing through two voltage sensor modules, and uses an 8-channel opto-coupler for isolating different parts of the circuit. Power management is handled by a buck converter connected to a DC power source and batteries, with a fuse for protection and a rocker switch for on/off control. Additionally, there's an LED for indication purposes.
This circuit features an Arduino Mega 2560 microcontroller interfaced with a SIM800L GSM module, two fingerprint scanners, an I2C LCD display, an IR sensor, and a piezo buzzer. Power management is handled by a PowerBoost 1000 Basic Pad USB, a TP4056 charging module, and a Li-ion 18650 battery, with an option to use a Mini AC-DC 110V-230V to 5V 700mA module for direct power supply. The primary functionality appears to be a security system with GSM communication capabilities, biometric access control, and visual/audible feedback.
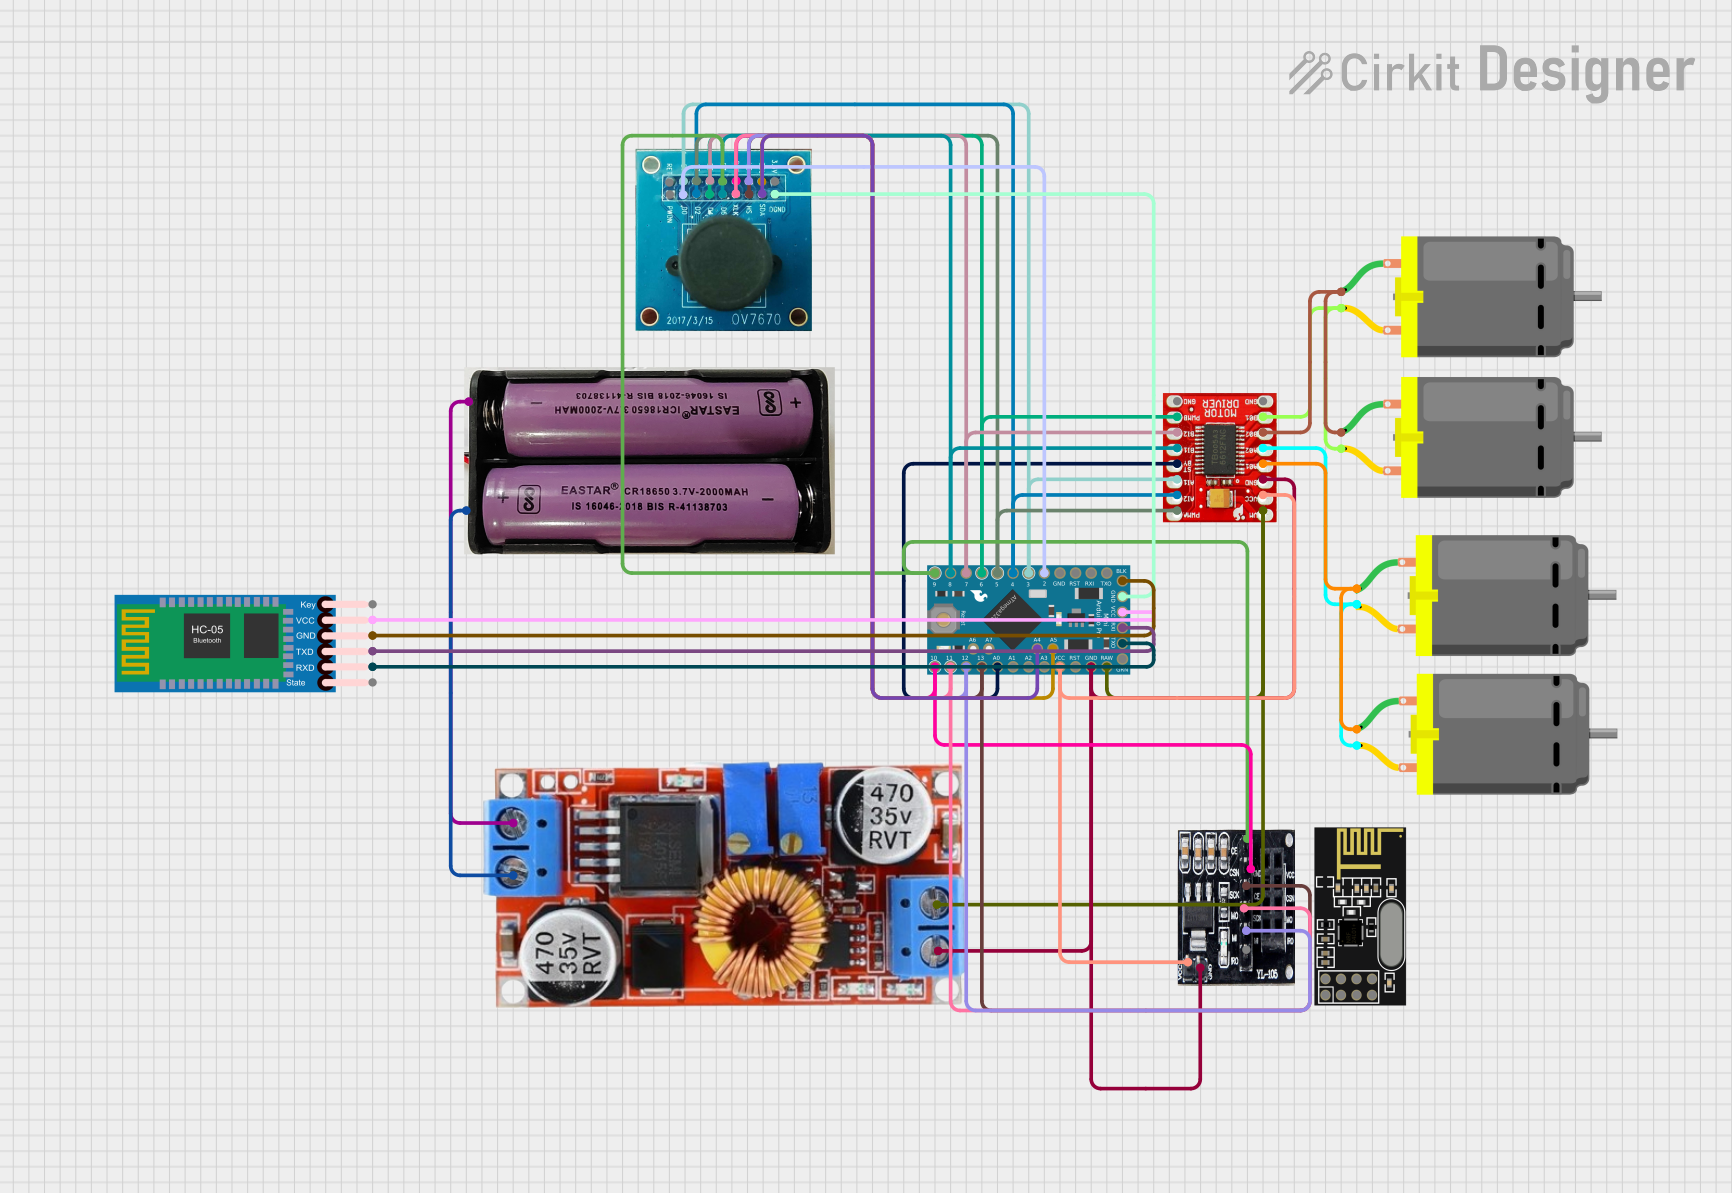
This circuit is a remote-controlled robotic system featuring an Arduino Pro Mini, a TB6612FNG motor driver, and an NRF24L01 wireless module. The Arduino controls four DC motors via the motor driver and communicates wirelessly using the NRF24L01 module, while an OV7670 camera module and an HC-05 Bluetooth module provide additional functionality.
Robotics (e.g., controlling wheels or robotic arms)
Automated conveyor systems
DIY projects involving DC or stepper motors
Remote-controlled vehicles
Industrial automation
Technical Specifications
The TB6612FNG module is designed to handle a wide range of motor control requirements. Below are its key technical details:
Key Specifications
Parameter
Value
Operating Voltage (Vcc)
2.7V to 5.5V
Motor Voltage (VM)
4.5V to 13.5V
Output Current (per channel)
1.2A (continuous), 3.2A (peak)
Control Interface
PWM, Direction Control
Standby Current
1 µA (typical)
Operating Temperature
-20°C to +85°C
Dimensions
20mm x 15mm (module size may vary)
Pin Configuration and Descriptions
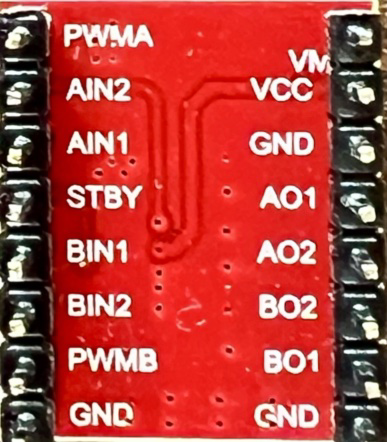
The TB6612FNG module has 16 pins, each serving a specific function. Below is the pinout and description:
Pin Name
Pin Number
Description
VCC
1
Logic power supply (2.7V to 5.5V)
VM
2
Motor power supply (4.5V to 13.5V)
GND
3, 8, 13
Ground connection
AIN1
4
Input 1 for Motor A (controls direction)
AIN2
5
Input 2 for Motor A (controls direction)
PWMA
6
PWM input for Motor A (speed control)
STBY
7
Standby control (active HIGH to enable the module)
BIN1
9
Input 1 for Motor B (controls direction)
BIN2
10
Input 2 for Motor B (controls direction)
PWMB
11
PWM input for Motor B (speed control)
AO1
12
Output 1 for Motor A
AO2
14
Output 2 for Motor A
BO1
15
Output 1 for Motor B
BO2
16
Output 2 for Motor B
Usage Instructions
The TB6612FNG module is straightforward to use in motor control circuits. Below are the steps and best practices for integrating it into your project.
Connecting the Module
Power Supply:
Connect the VCC pin to a 3.3V or 5V logic power supply.
Connect the VM pin to the motor power supply (4.5V to 13.5V).
Connect all GND pins to the ground of your circuit.
Motor Connections:
Connect the motor terminals to AO1 and AO2 for Motor A, and BO1 and BO2 for Motor B.
Control Pins:
Use AIN1 and AIN2 to control the direction of Motor A, and BIN1 and BIN2 for Motor B.
Use PWMA and PWMB to control the speed of Motor A and Motor B, respectively, via PWM signals.
Set the STBY pin HIGH to enable the module.
Example Arduino Code
Below is an example of how to control two DC motors using the TB6612FNG module and an Arduino UNO:
// Define motor control pins
#define AIN1 4  // Motor A direction control pin 1
#define AIN2 5  // Motor A direction control pin 2
#define PWMA 6  // Motor A speed control (PWM)
#define BIN1 7  // Motor B direction control pin 1
#define BIN2 8  // Motor B direction control pin 2
#define PWMB 9  // Motor B speed control (PWM)
#define STBY 10 // Standby pin

void setup() {
  // Set control pins as outputs
  pinMode(AIN1, OUTPUT);
  pinMode(AIN2, OUTPUT);
  pinMode(PWMA, OUTPUT);
  pinMode(BIN1, OUTPUT);
  pinMode(BIN2, OUTPUT);
  pinMode(PWMB, OUTPUT);
  pinMode(STBY, OUTPUT);

  // Enable the motor driver
  digitalWrite(STBY, HIGH);
}

void loop() {
  // Motor A: Forward at 50% speed
  digitalWrite(AIN1, HIGH);
  digitalWrite(AIN2, LOW);
  analogWrite(PWMA, 128); // 50% duty cycle (0-255)

  // Motor B: Reverse at 75% speed
  digitalWrite(BIN1, LOW);
  digitalWrite(BIN2, HIGH);
  analogWrite(PWMB, 192); // 75% duty cycle (0-255)

  delay(2000); // Run motors for 2 seconds

  // Stop both motors
  analogWrite(PWMA, 0);
  analogWrite(PWMB, 0);

  delay(2000); // Wait for 2 seconds
}
Best Practices
Ensure the motor power supply voltage (VM) matches the motor's rated voltage.
Use appropriate decoupling capacitors near the power supply pins to reduce noise.
Avoid exceeding the maximum current ratings to prevent damage to the module.
Use heat sinks or proper ventilation if operating at high currents for extended periods.
Troubleshooting and FAQs
Common Issues
Motors not spinning:
Verify that the STBY pin is set HIGH.
Check the power supply connections for VCC and VM.
Ensure the PWM signals are being generated correctly.
Motor spins in the wrong direction:
Swap the connections to AIN1 and AIN2 (or BIN1 and BIN2) to reverse the direction.
Module overheating:
Ensure the current drawn by the motors does not exceed the module's rated limits.
Add a heat sink or improve ventilation if necessary.
PWM control not working:
Verify that the PWM pins are connected to Arduino PWM-capable pins.
Check the duty cycle values being sent to the analogWrite() function.
FAQs
Q: Can I control a stepper motor with this module?
A: Yes, the TB6612FNG can control a stepper motor by using both H-bridges. You will need to generate the appropriate step and direction signals.
Q: What happens if I leave the STBY pin floating?
A: The module will remain in standby mode, and the motors will not operate. Always set the STBY pin HIGH to enable the module.
Q: Can I use this module with a 3.3V microcontroller?
A: Yes, the TB6612FNG supports logic levels as low as 2.7V, making it compatible with 3.3V microcontrollers.
By following this documentation, you can effectively integrate the TB6612FNG module into your motor control projects.


 Open Project in Cirkit Designer