The RC-Car Bluetooth Driver is an electronic module designed to provide wireless control capabilities to radio-controlled (RC) cars. By interfacing with a Bluetooth-enabled mobile device or computer, users can remotely control the speed, direction, and various other functions of their RC car. This component is ideal for hobbyists and enthusiasts looking to upgrade their RC car with modern control options.
Explore Projects Built with RC-Car bluetooth driver
Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
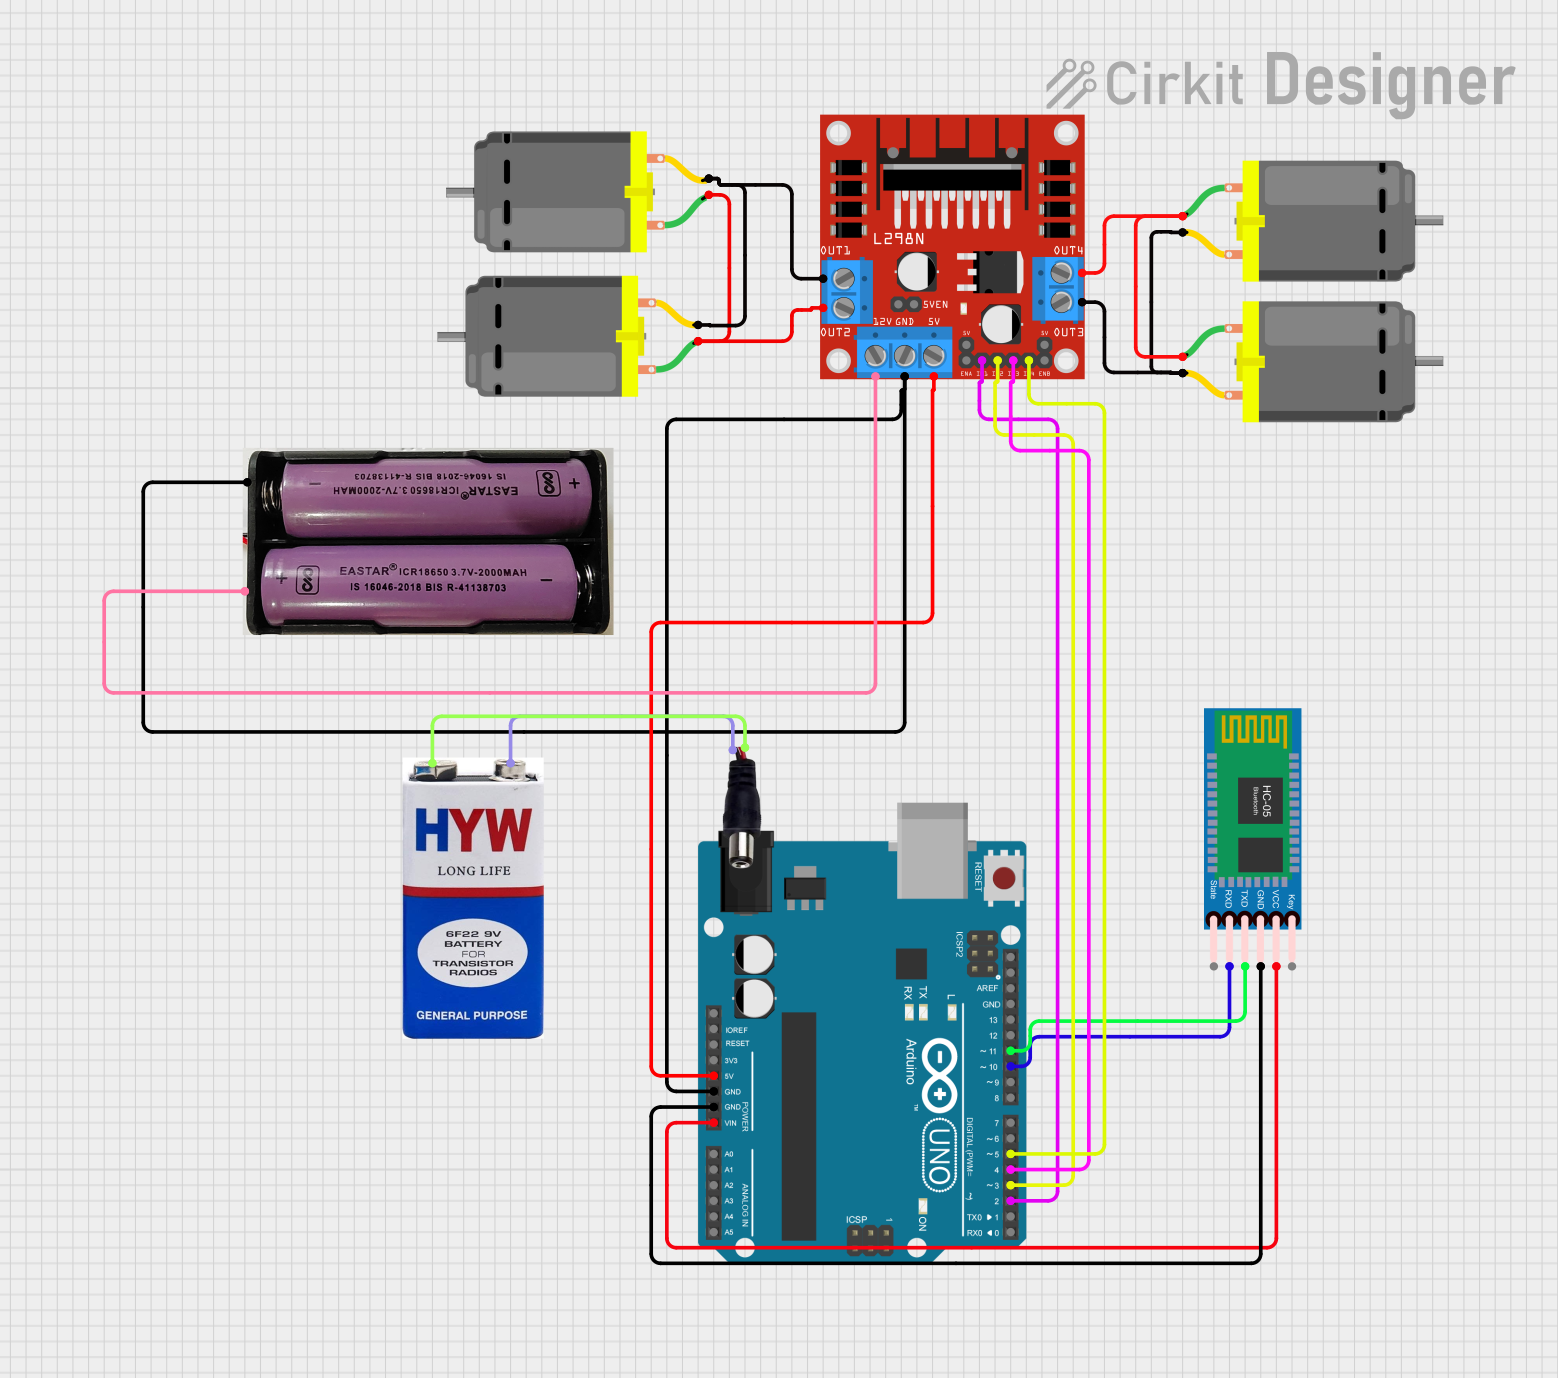
This circuit is a Bluetooth-controlled RC car using an Arduino UNO, an HC-05 Bluetooth module, and an L298N motor driver to control four DC motors. The Arduino receives commands via Bluetooth to move the car forward, backward, left, right, or stop, and translates these commands into motor control signals.
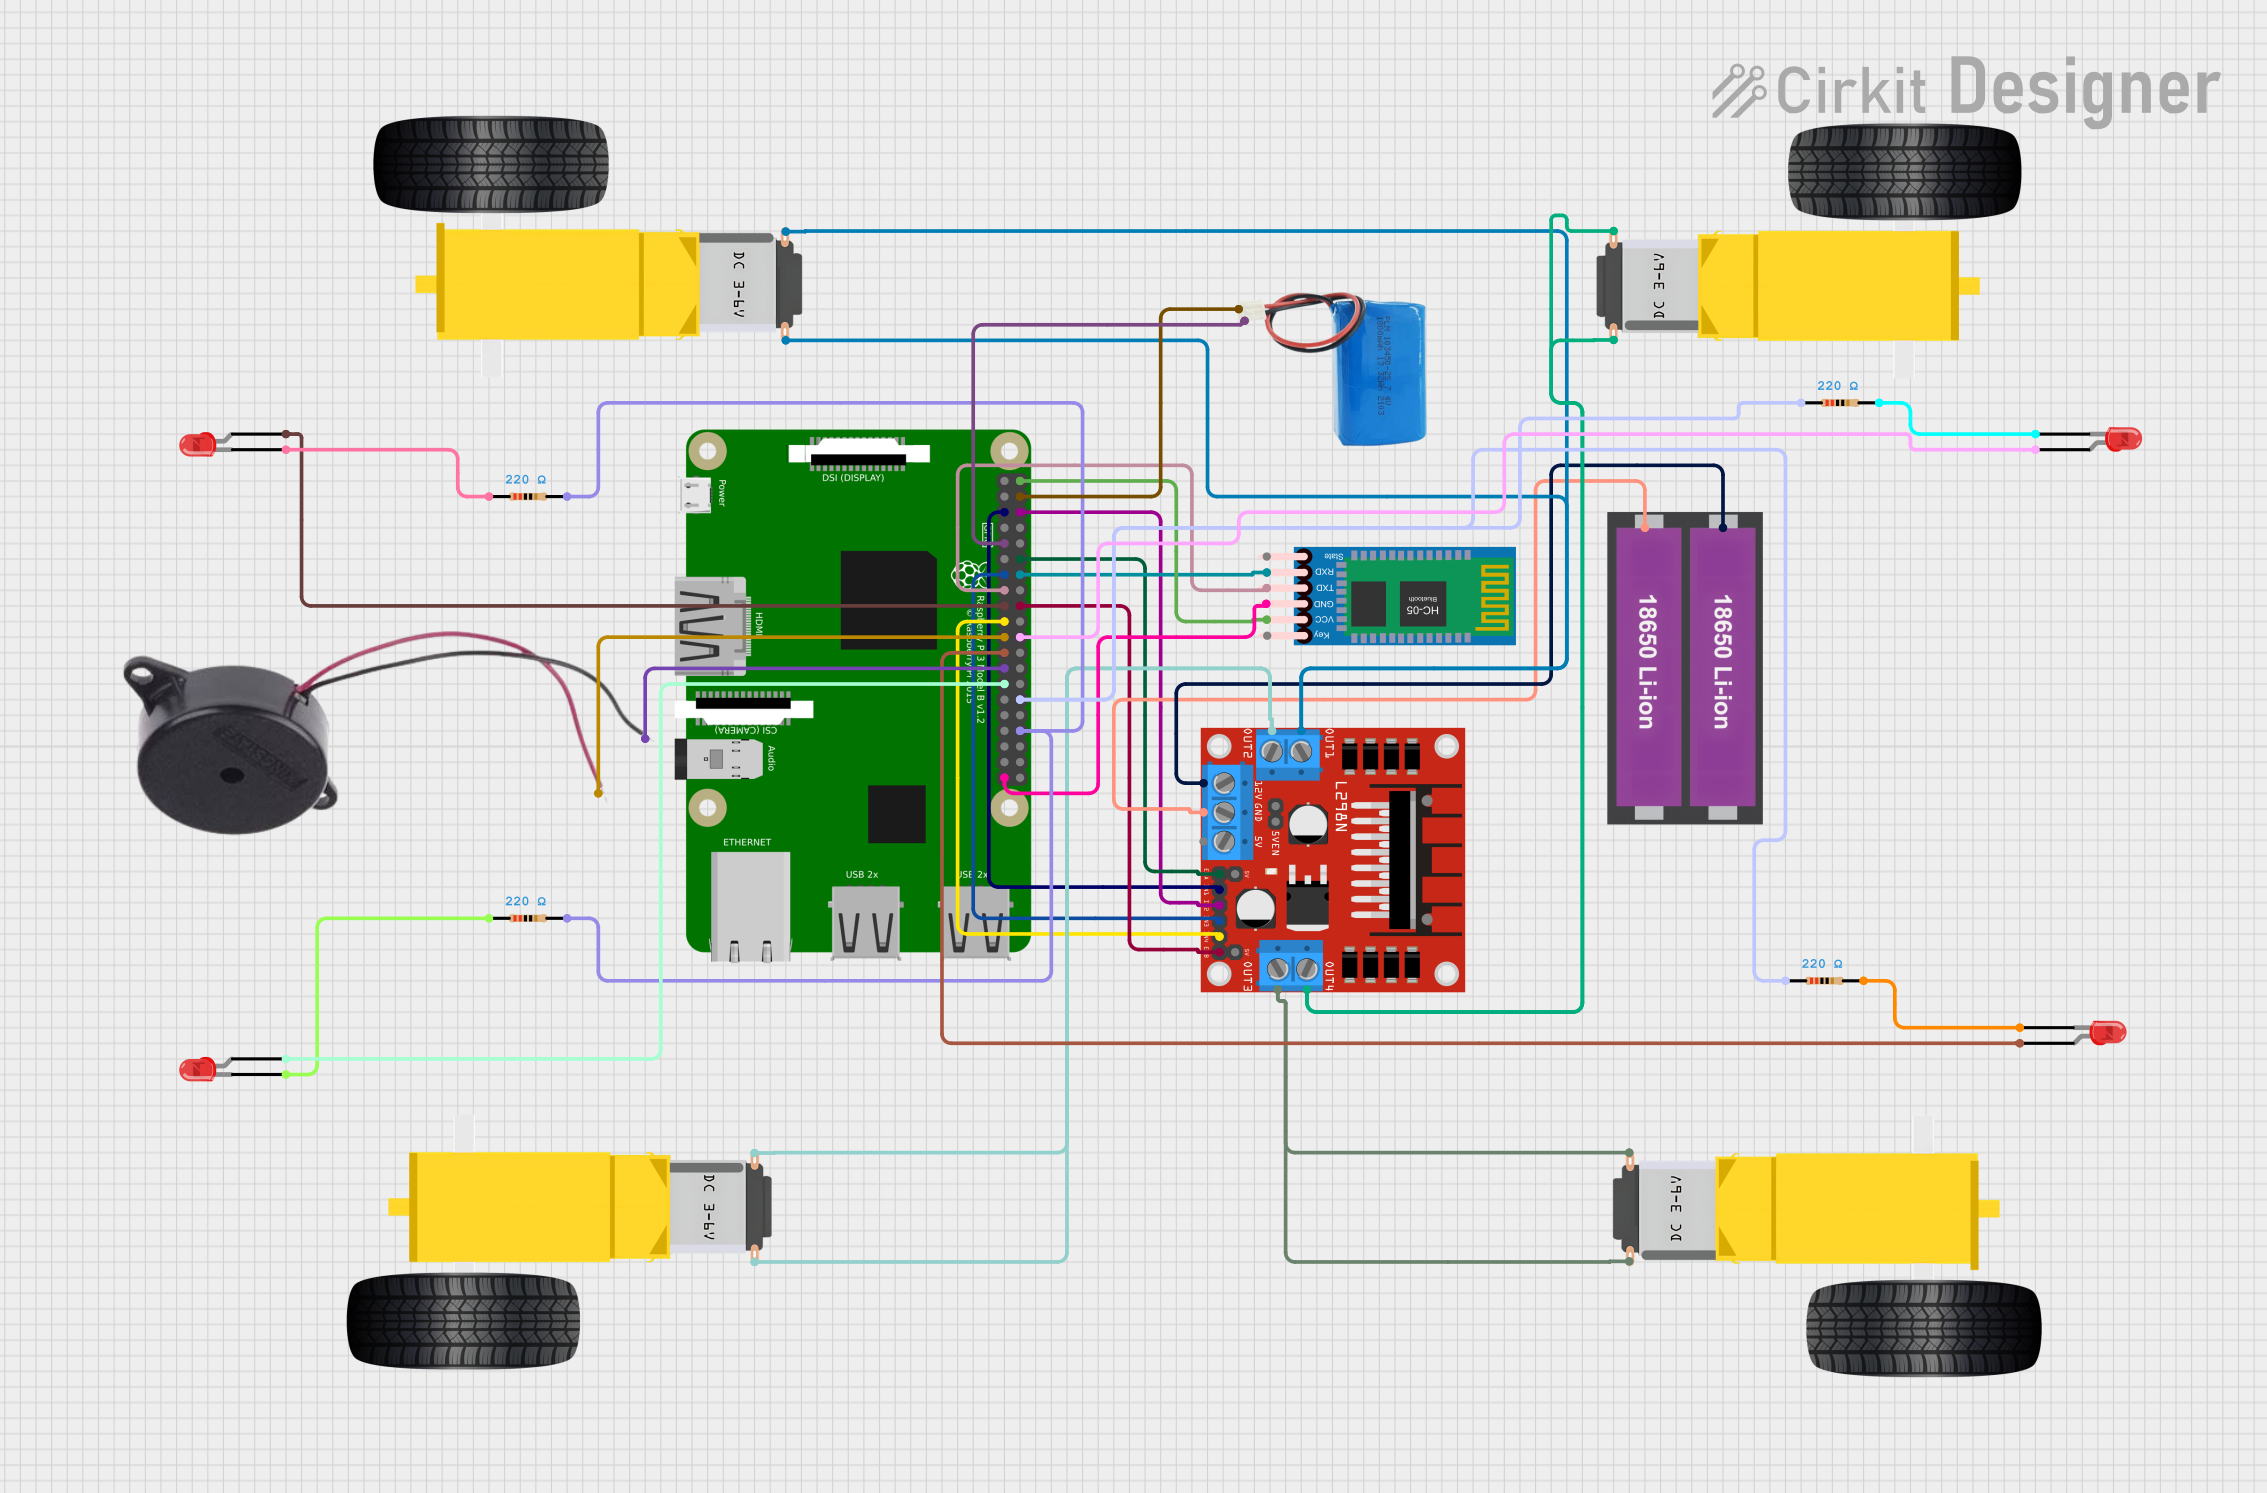
This circuit is a Bluetooth-controlled robotic car using a Raspberry Pi 3B, an L298N motor driver, and an HC-05 Bluetooth module. The Raspberry Pi controls the movement of the car by driving the motors through the L298N driver and can also toggle LEDs and a buzzer for signaling. The car receives movement commands via Bluetooth, allowing for remote control.
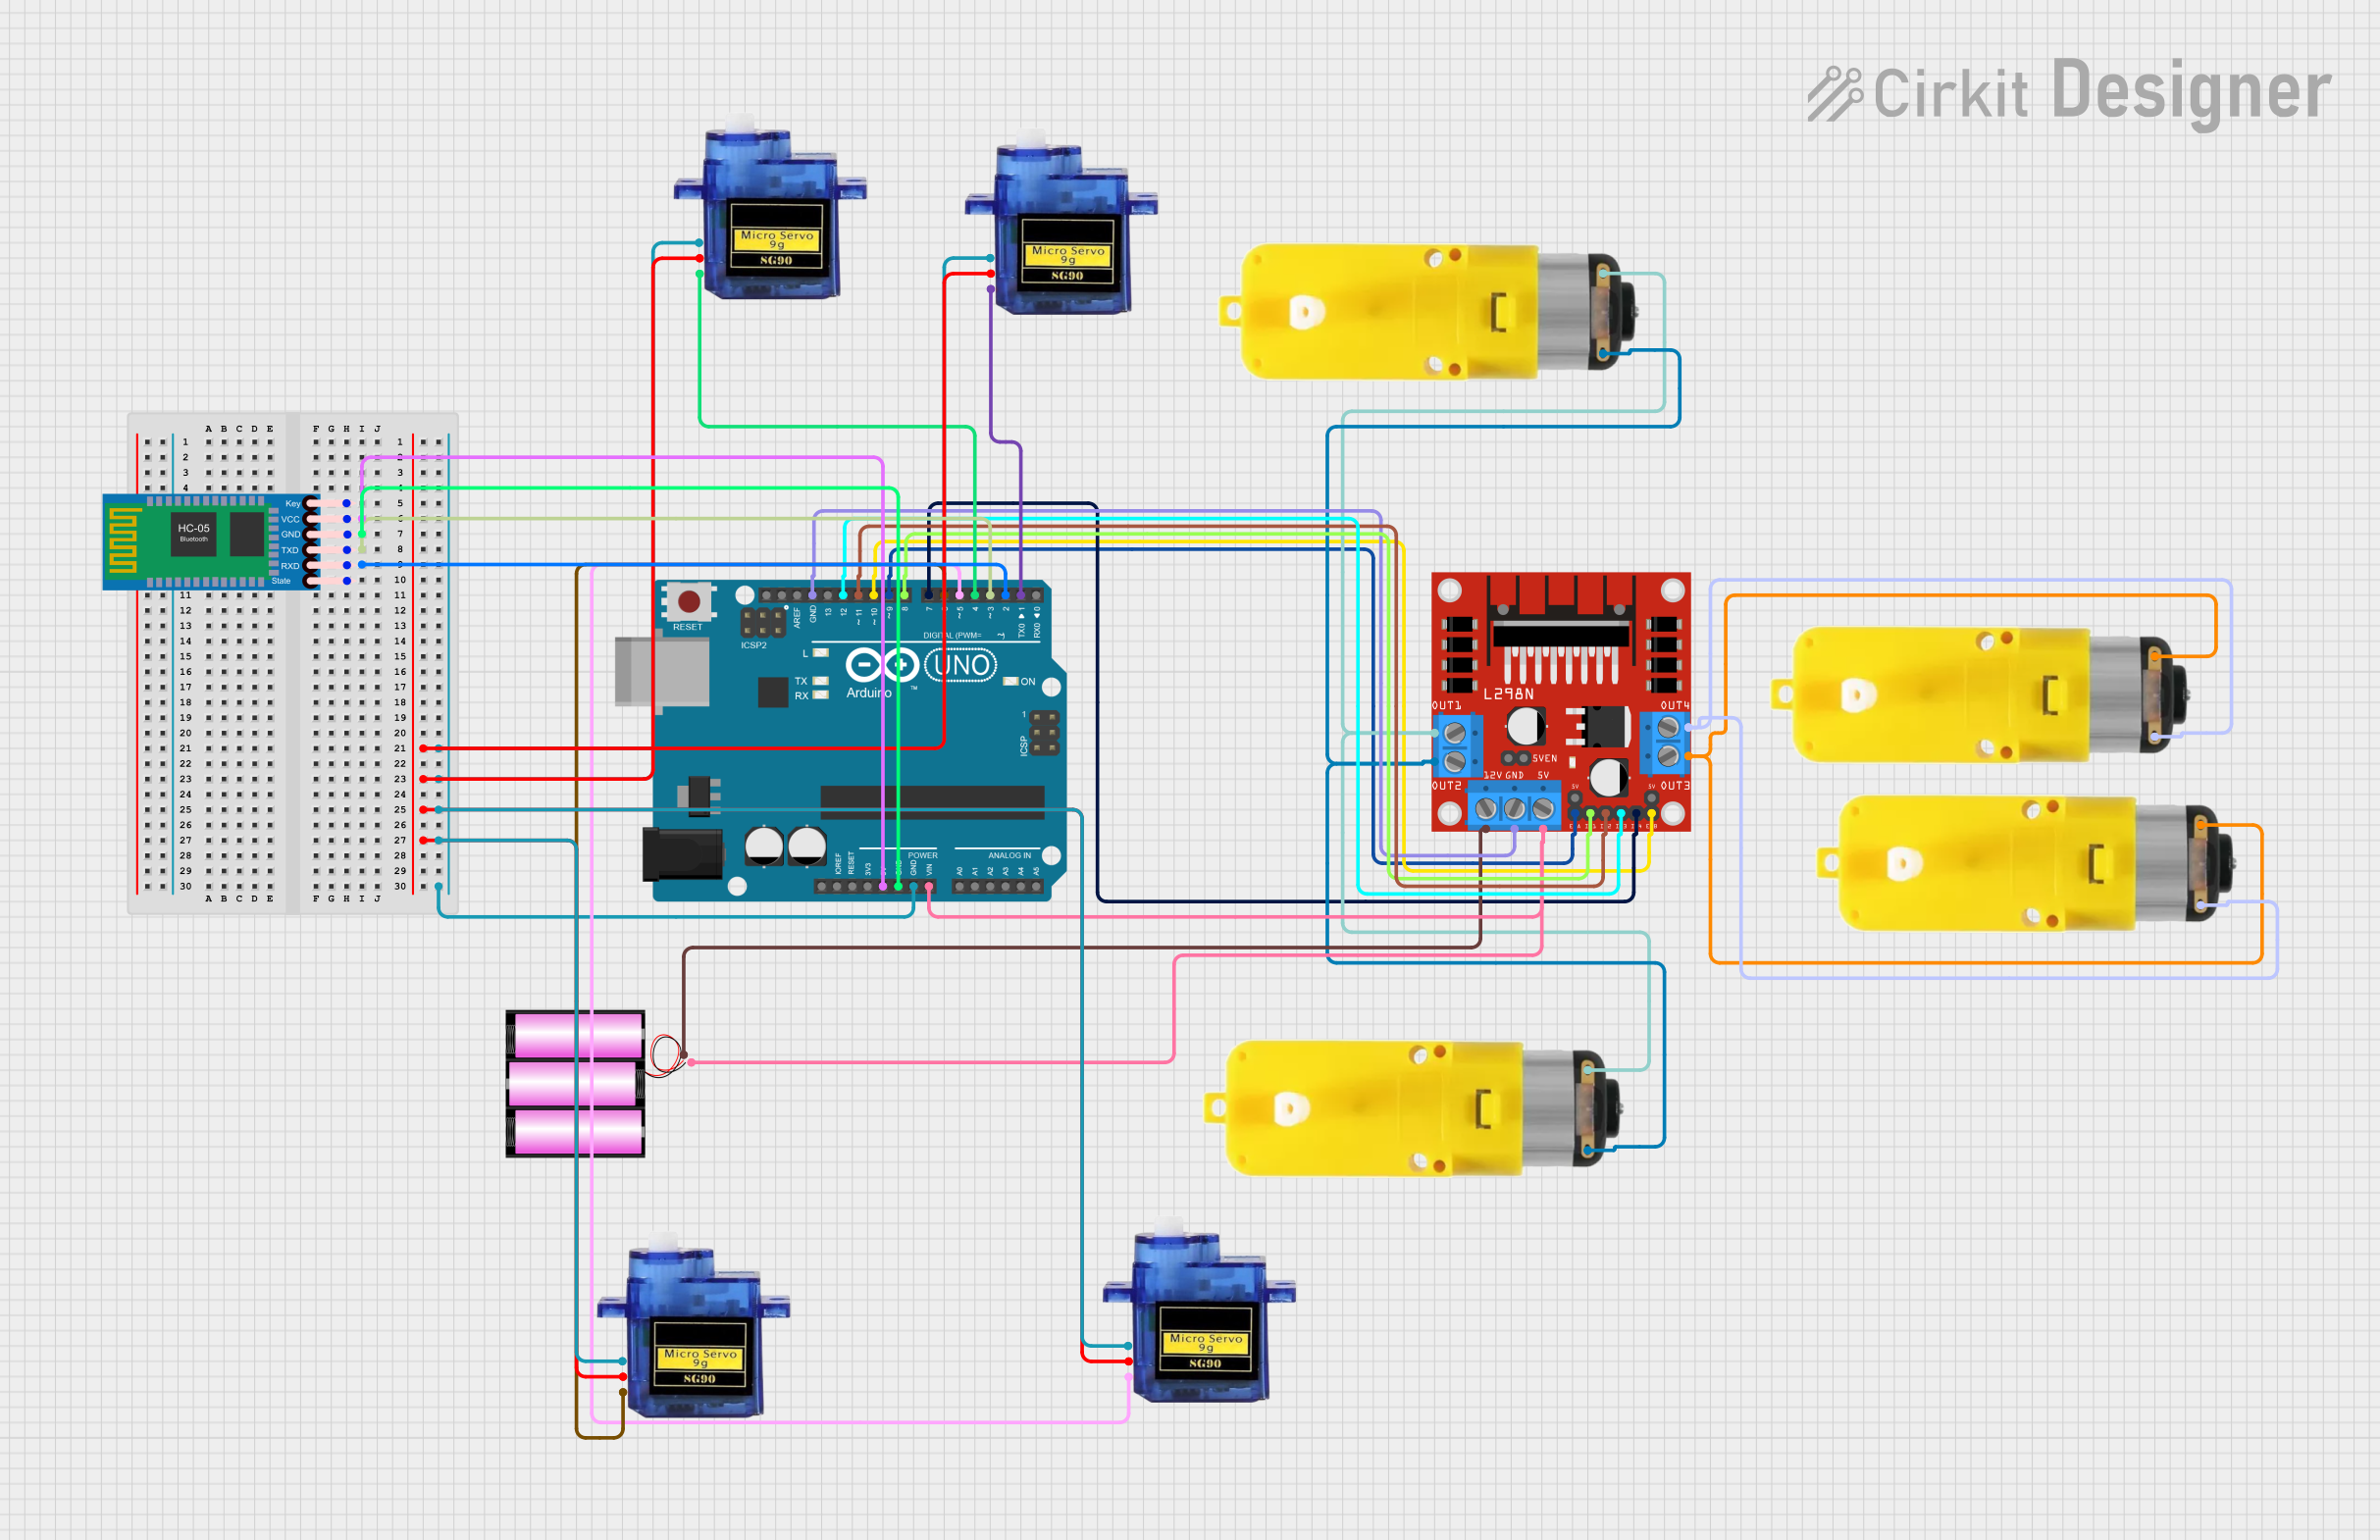
This circuit is a Bluetooth-controlled car using an Arduino UNO, an HC-05 Bluetooth module, an L298N motor driver, and multiple motors and servos. The Arduino receives commands via Bluetooth to control the direction and speed of the motors, enabling the car to move forward, backward, turn left, and turn right.
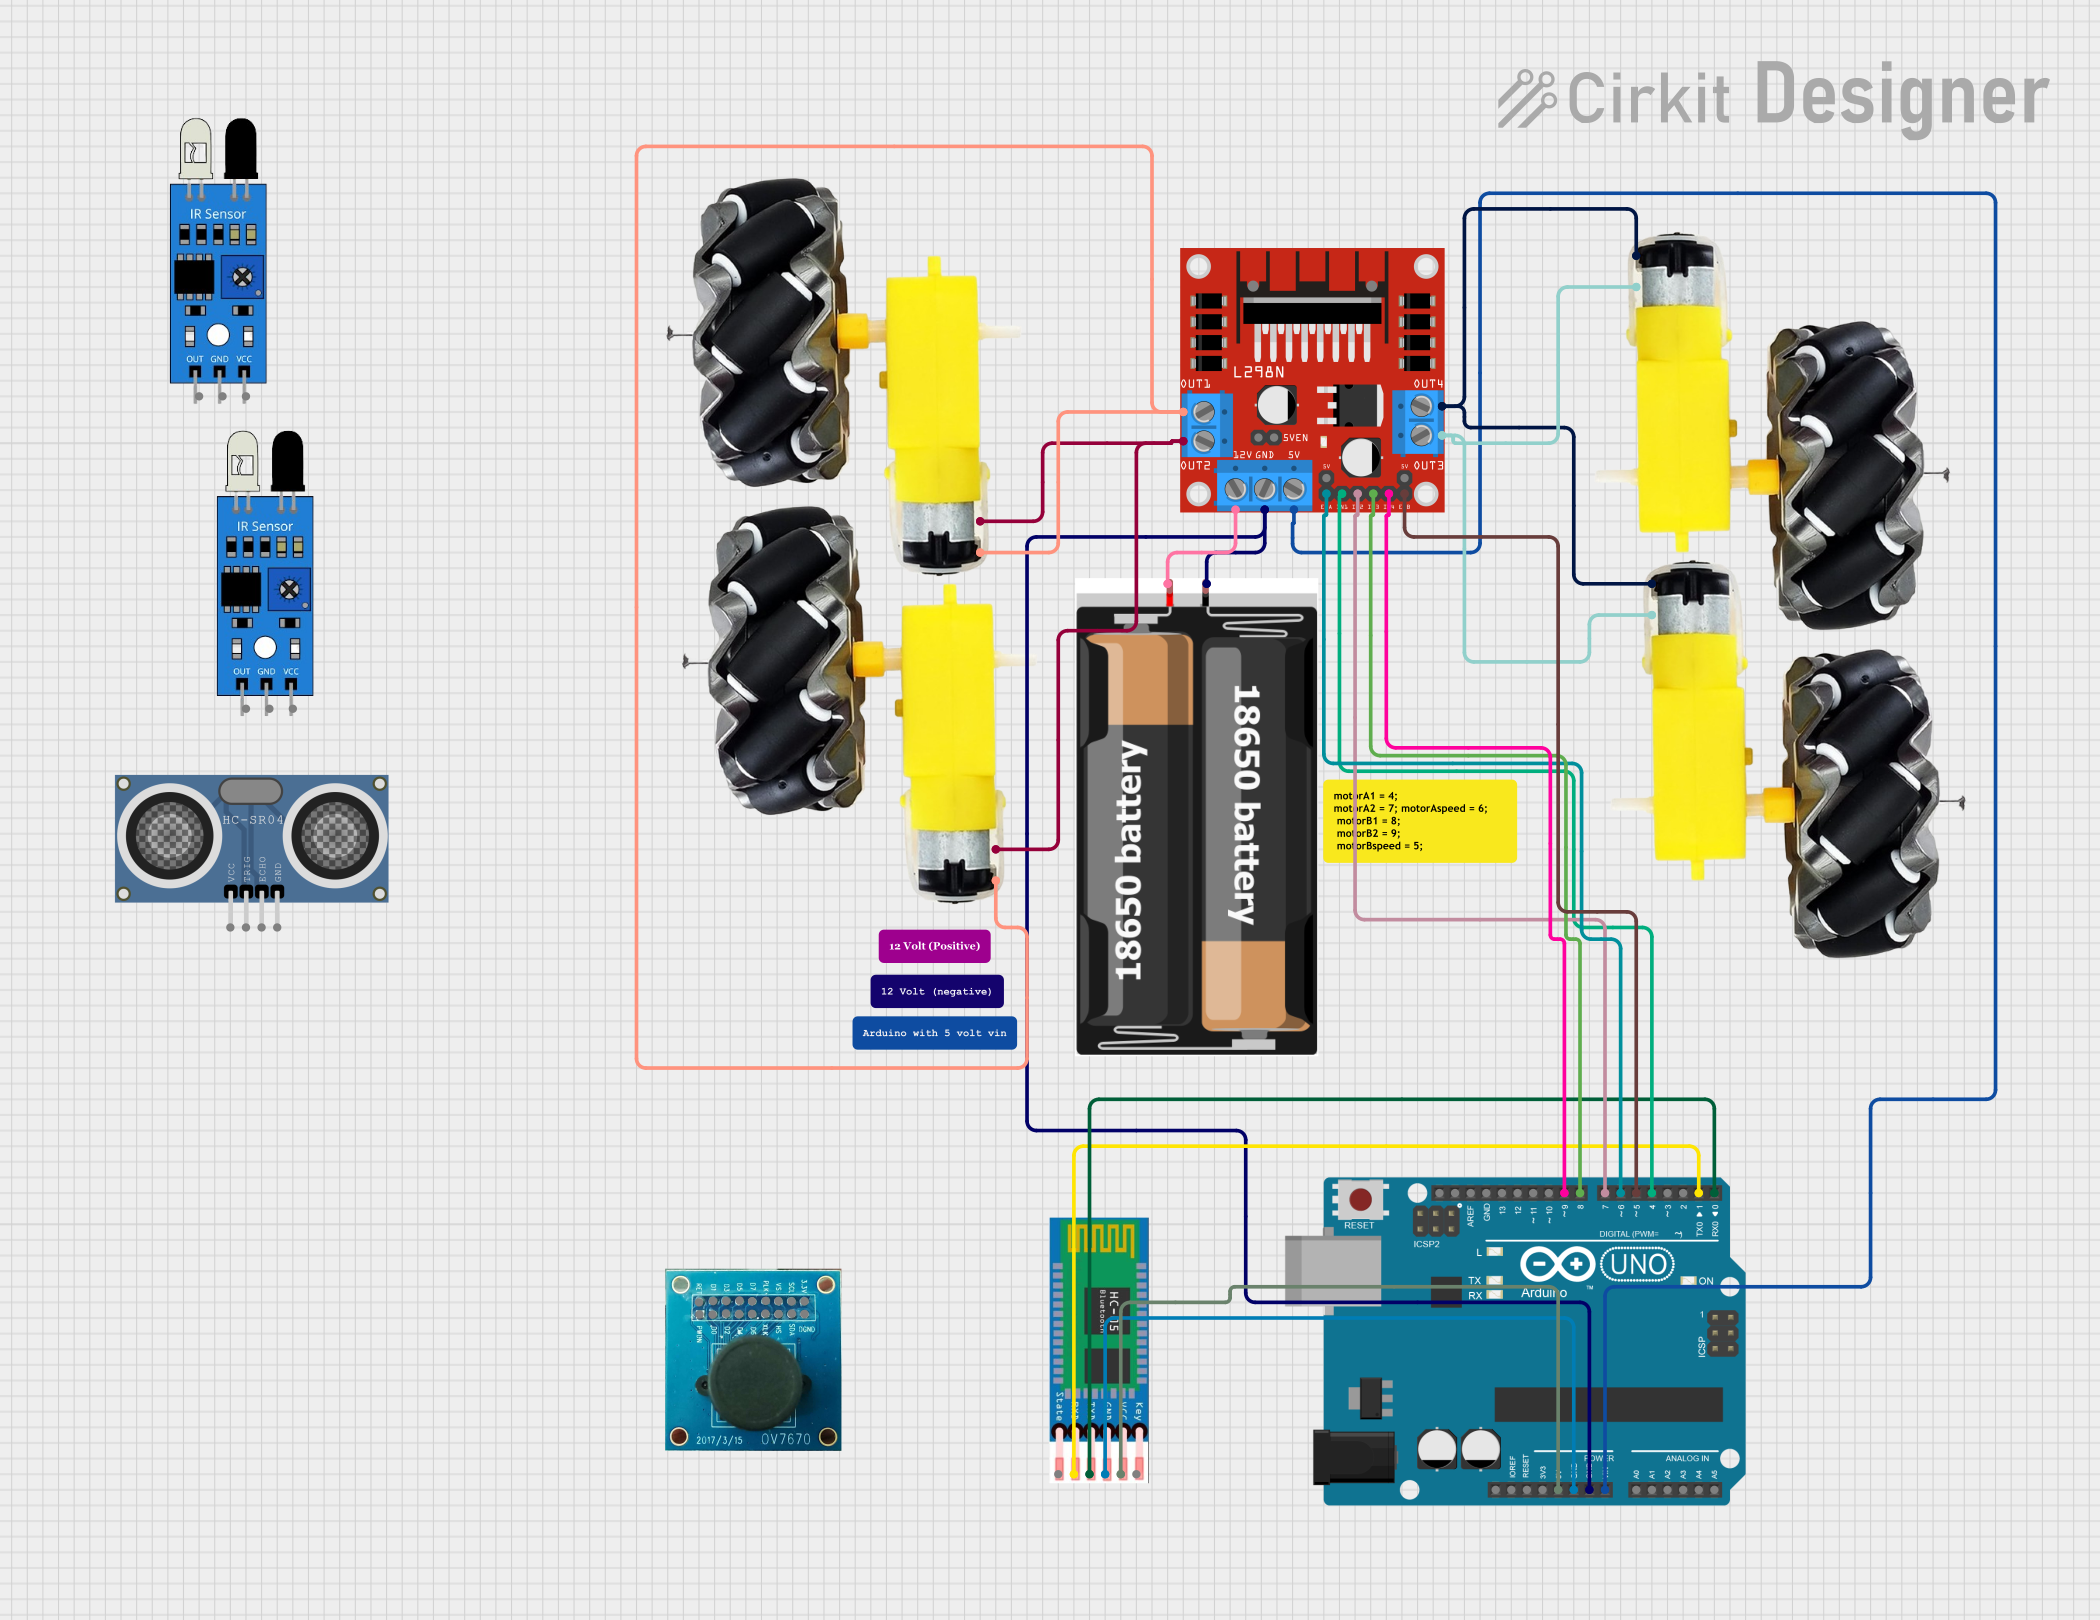
This circuit is a Bluetooth-controlled car using an Arduino UNO, an L298N motor driver, and four DC motors. The Arduino receives commands via a Bluetooth module (HC-05) and controls the motor driver to move the car forward, backward, left, or right based on the received commands.
Communication Range: Up to 10 meters (without obstacles)
Control Channels: 2 (typically used for speed and steering)
Input Interface: UART (TTL logic levels)
Operating Temperature: -10°C to +55°C
Pin Configuration and Descriptions
Pin Number
Pin Name
Description
1
VCC
Power supply input (3.3V to 6V)
2
GND
Ground
3
TX
UART Transmit; connects to RX of MCU
4
RX
UART Receive; connects to TX of MCU
5
CH1
Channel 1 output (e.g., speed control)
6
CH2
Channel 2 output (e.g., steering control)
Usage Instructions
Integrating with a Circuit
Power Supply: Connect the VCC pin to a suitable power source within the 3.3V to 6V range. Ensure that the power supply can handle the current requirements of the module.
Ground Connection: Connect the GND pin to the common ground of your circuit.
UART Communication: Interface the TX and RX pins with the corresponding RX and TX pins of your microcontroller unit (MCU), such as an Arduino UNO.
Output Channels: Connect CH1 and CH2 to the respective control inputs of your RC car's motor driver or servos.
Important Considerations and Best Practices
Ensure that the power supply is stable and within the specified voltage range to prevent damage to the Bluetooth driver.
Pair the Bluetooth module with your control device before attempting to send commands.
Use shielded cables for UART communication if there is a lot of electrical noise in the environment.
Always disconnect the power before making or altering connections to prevent shorts and damage.
Example Code for Arduino UNO
#include <SoftwareSerial.h>

SoftwareSerial BTSerial(10, 11); // RX | TX

void setup() {
  pinMode(9, OUTPUT); // CH1
  pinMode(8, OUTPUT); // CH2
  BTSerial.begin(9600); // Start Bluetooth communication at 9600 baud rate
  Serial.begin(9600); // Start serial communication for debugging
}

void loop() {
  if (BTSerial.available()) { // Check if there are incoming bytes via Bluetooth
    char command = BTSerial.read(); // Read the incoming byte
    switch (command) {
      case 'F': // Forward command
        digitalWrite(9, HIGH);
        digitalWrite(8, LOW);
        break;
      case 'B': // Backward command
        digitalWrite(9, LOW);
        digitalWrite(8, HIGH);
        break;
      case 'S': // Stop command
        digitalWrite(9, LOW);
        digitalWrite(8, LOW);
        break;
      // Add more cases as needed for additional commands
    }
  }
}
Troubleshooting and FAQs
Common Issues
Bluetooth Pairing Issues: Ensure the Bluetooth module is in pairing mode and that your device is compatible with Bluetooth 4.0 or BLE.
No Response to Commands: Verify that all connections are secure and that the correct power supply is used. Check that the UART pins are correctly connected to the MCU.
Intermittent Control: This could be due to power supply issues or environmental interference. Ensure a stable power source and consider using shielded cables.
Solutions and Tips
Reset the Module: If the module is unresponsive, try disconnecting the power for a few seconds and then reconnecting it.
Check LED Indicators: Most Bluetooth modules have LED indicators that can help diagnose connection and activity status.
Update Firmware: Ensure that the module's firmware is up to date for optimal performance and compatibility.
FAQs
Q: Can I use this module with any RC car?
A: The module can be used with any RC car that has provisions for electronic speed and steering control, provided you can interface the module with the car's electronics.
Q: What is the maximum range of the Bluetooth connection?
A: The typical range is up to 10 meters, but this can be affected by obstacles and interference.
Q: How do I change the Bluetooth name and password of the module?
A: This process varies by module manufacturer. Refer to the specific module's datasheet or user manual for instructions on configuring Bluetooth settings.
Q: Can I control multiple RC cars with one Bluetooth driver?
A: No, each Bluetooth driver is designed to control one RC car at a time. However, you can pair multiple drivers with separate control devices to manage multiple cars independently.
This documentation provides a comprehensive guide to using the RC-Car Bluetooth Driver. For further assistance or technical support, please contact the manufacturer or visit their support forums.

 Open Project in Cirkit Designer