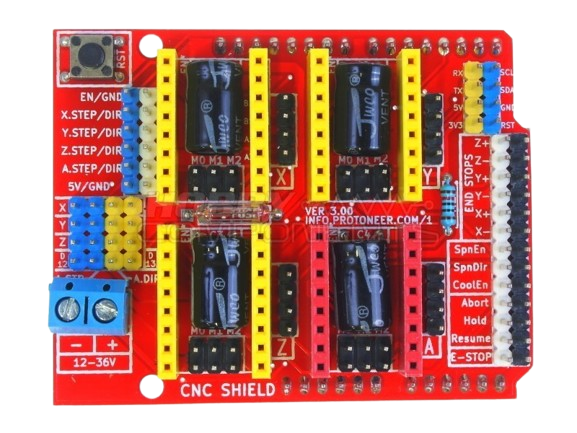
The CNC SHIELD V3, manufactured by INFO PROTONER (Part ID: CNC SHIELD), is a versatile control board designed for CNC machines, 3D printers, and laser engravers. It provides an efficient and user-friendly interface for controlling stepper motors, endstops, and other peripherals. The shield is compatible with Arduino boards, making it an excellent choice for hobbyists and professionals alike. Its modular design allows for easy integration of stepper motor drivers and other components, enabling precise control of motion systems.
Explore Projects Built with CNC SHIELD V3
Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
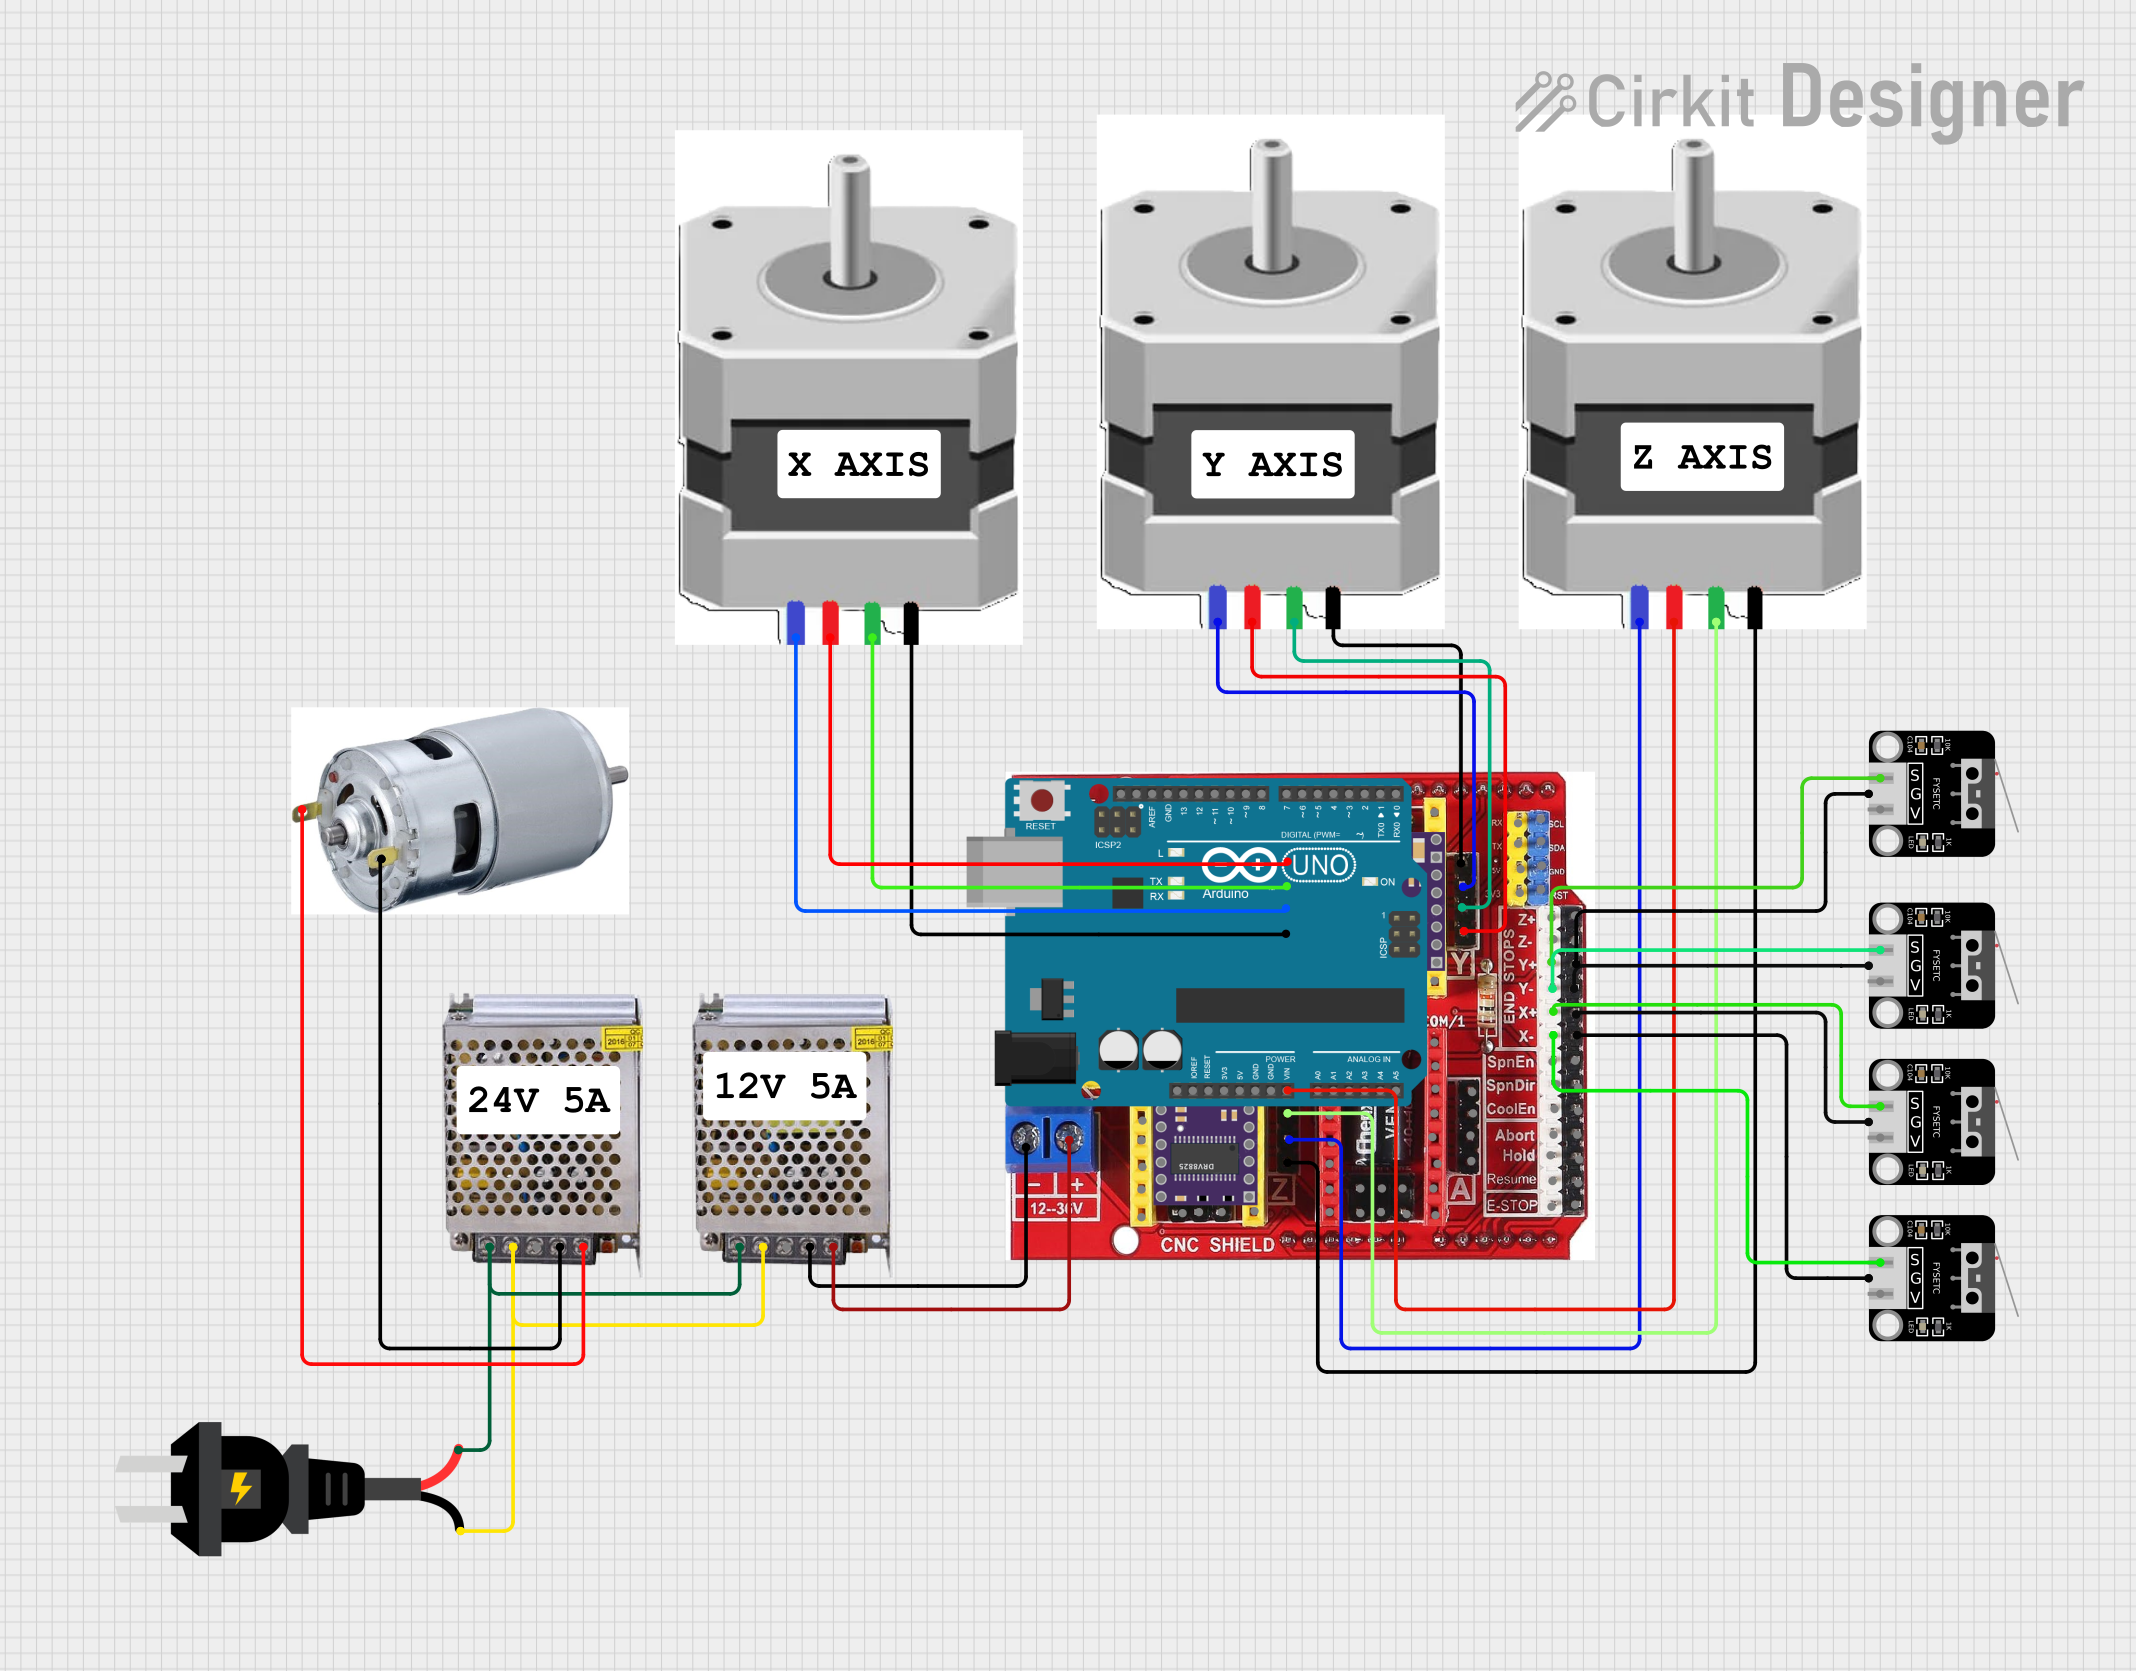
This circuit is a CNC machine control system that uses an Arduino UNO and a CNC Shield V3 to control three NEMA23 stepper motors for X, Y, and Z axes, along with limit switches for end-stop detection. The system is powered by a 12V power supply and includes a 775 motor for additional functionality, with the Arduino running basic setup and loop code.
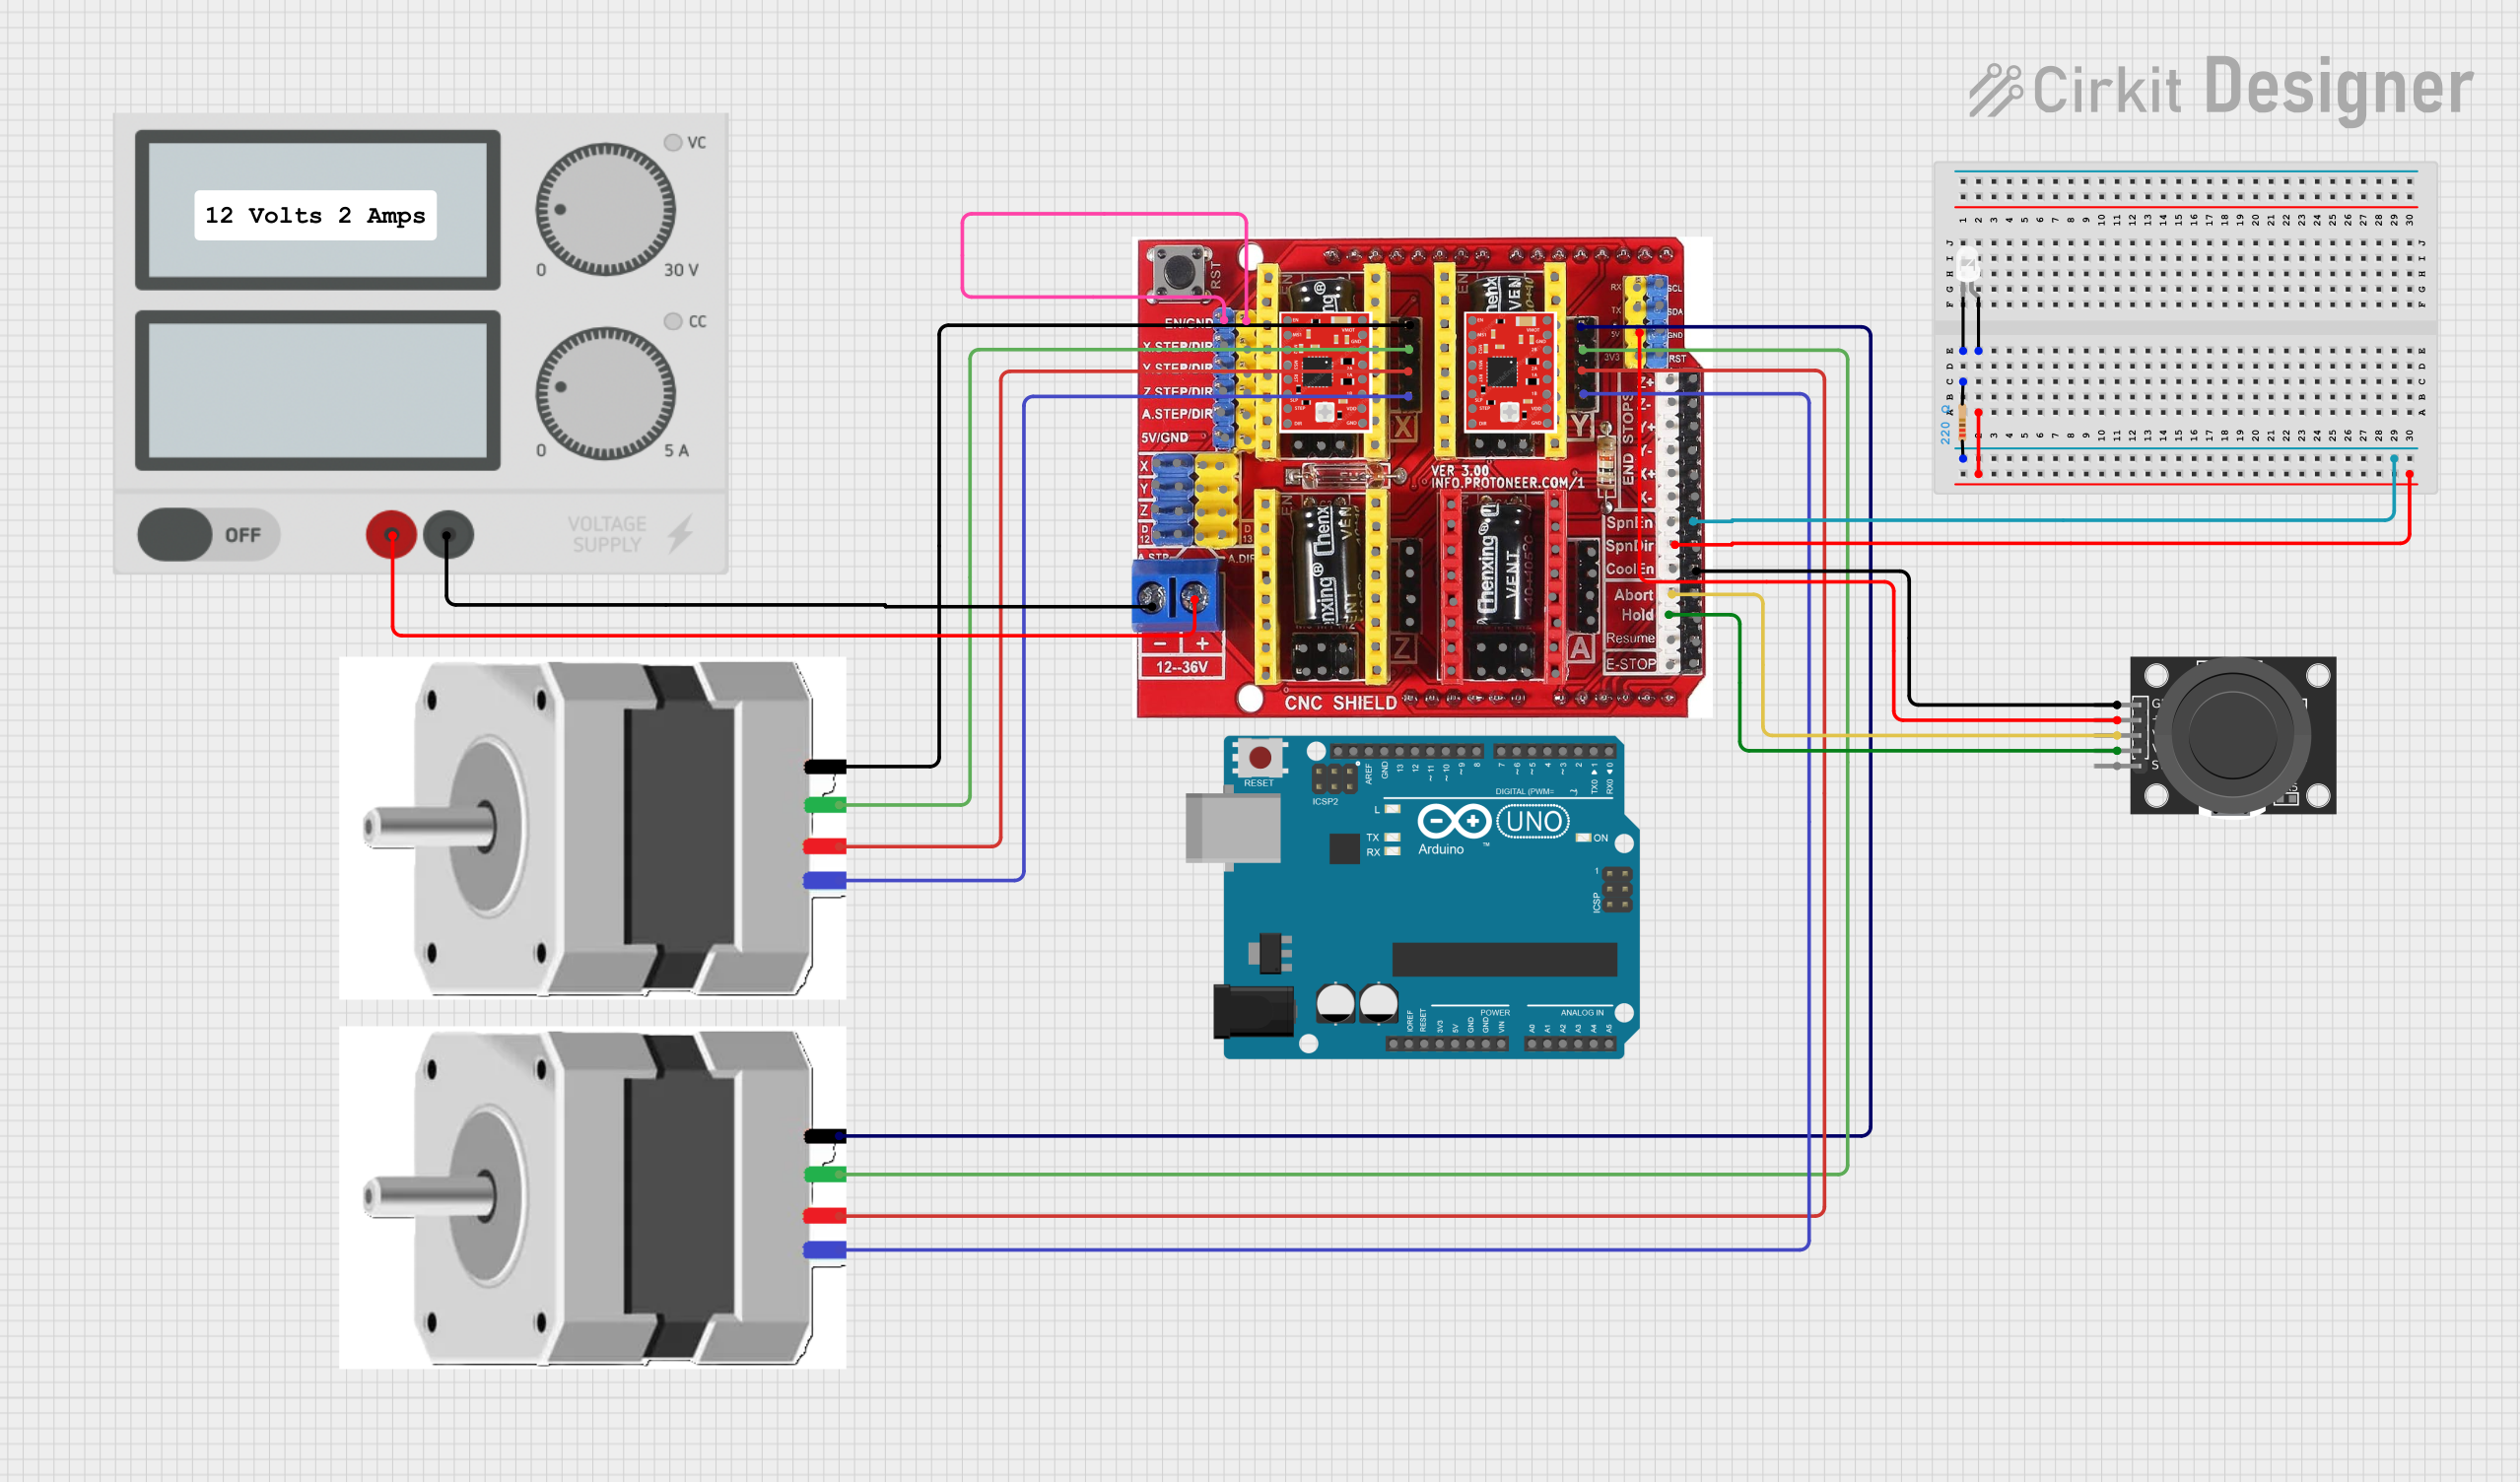
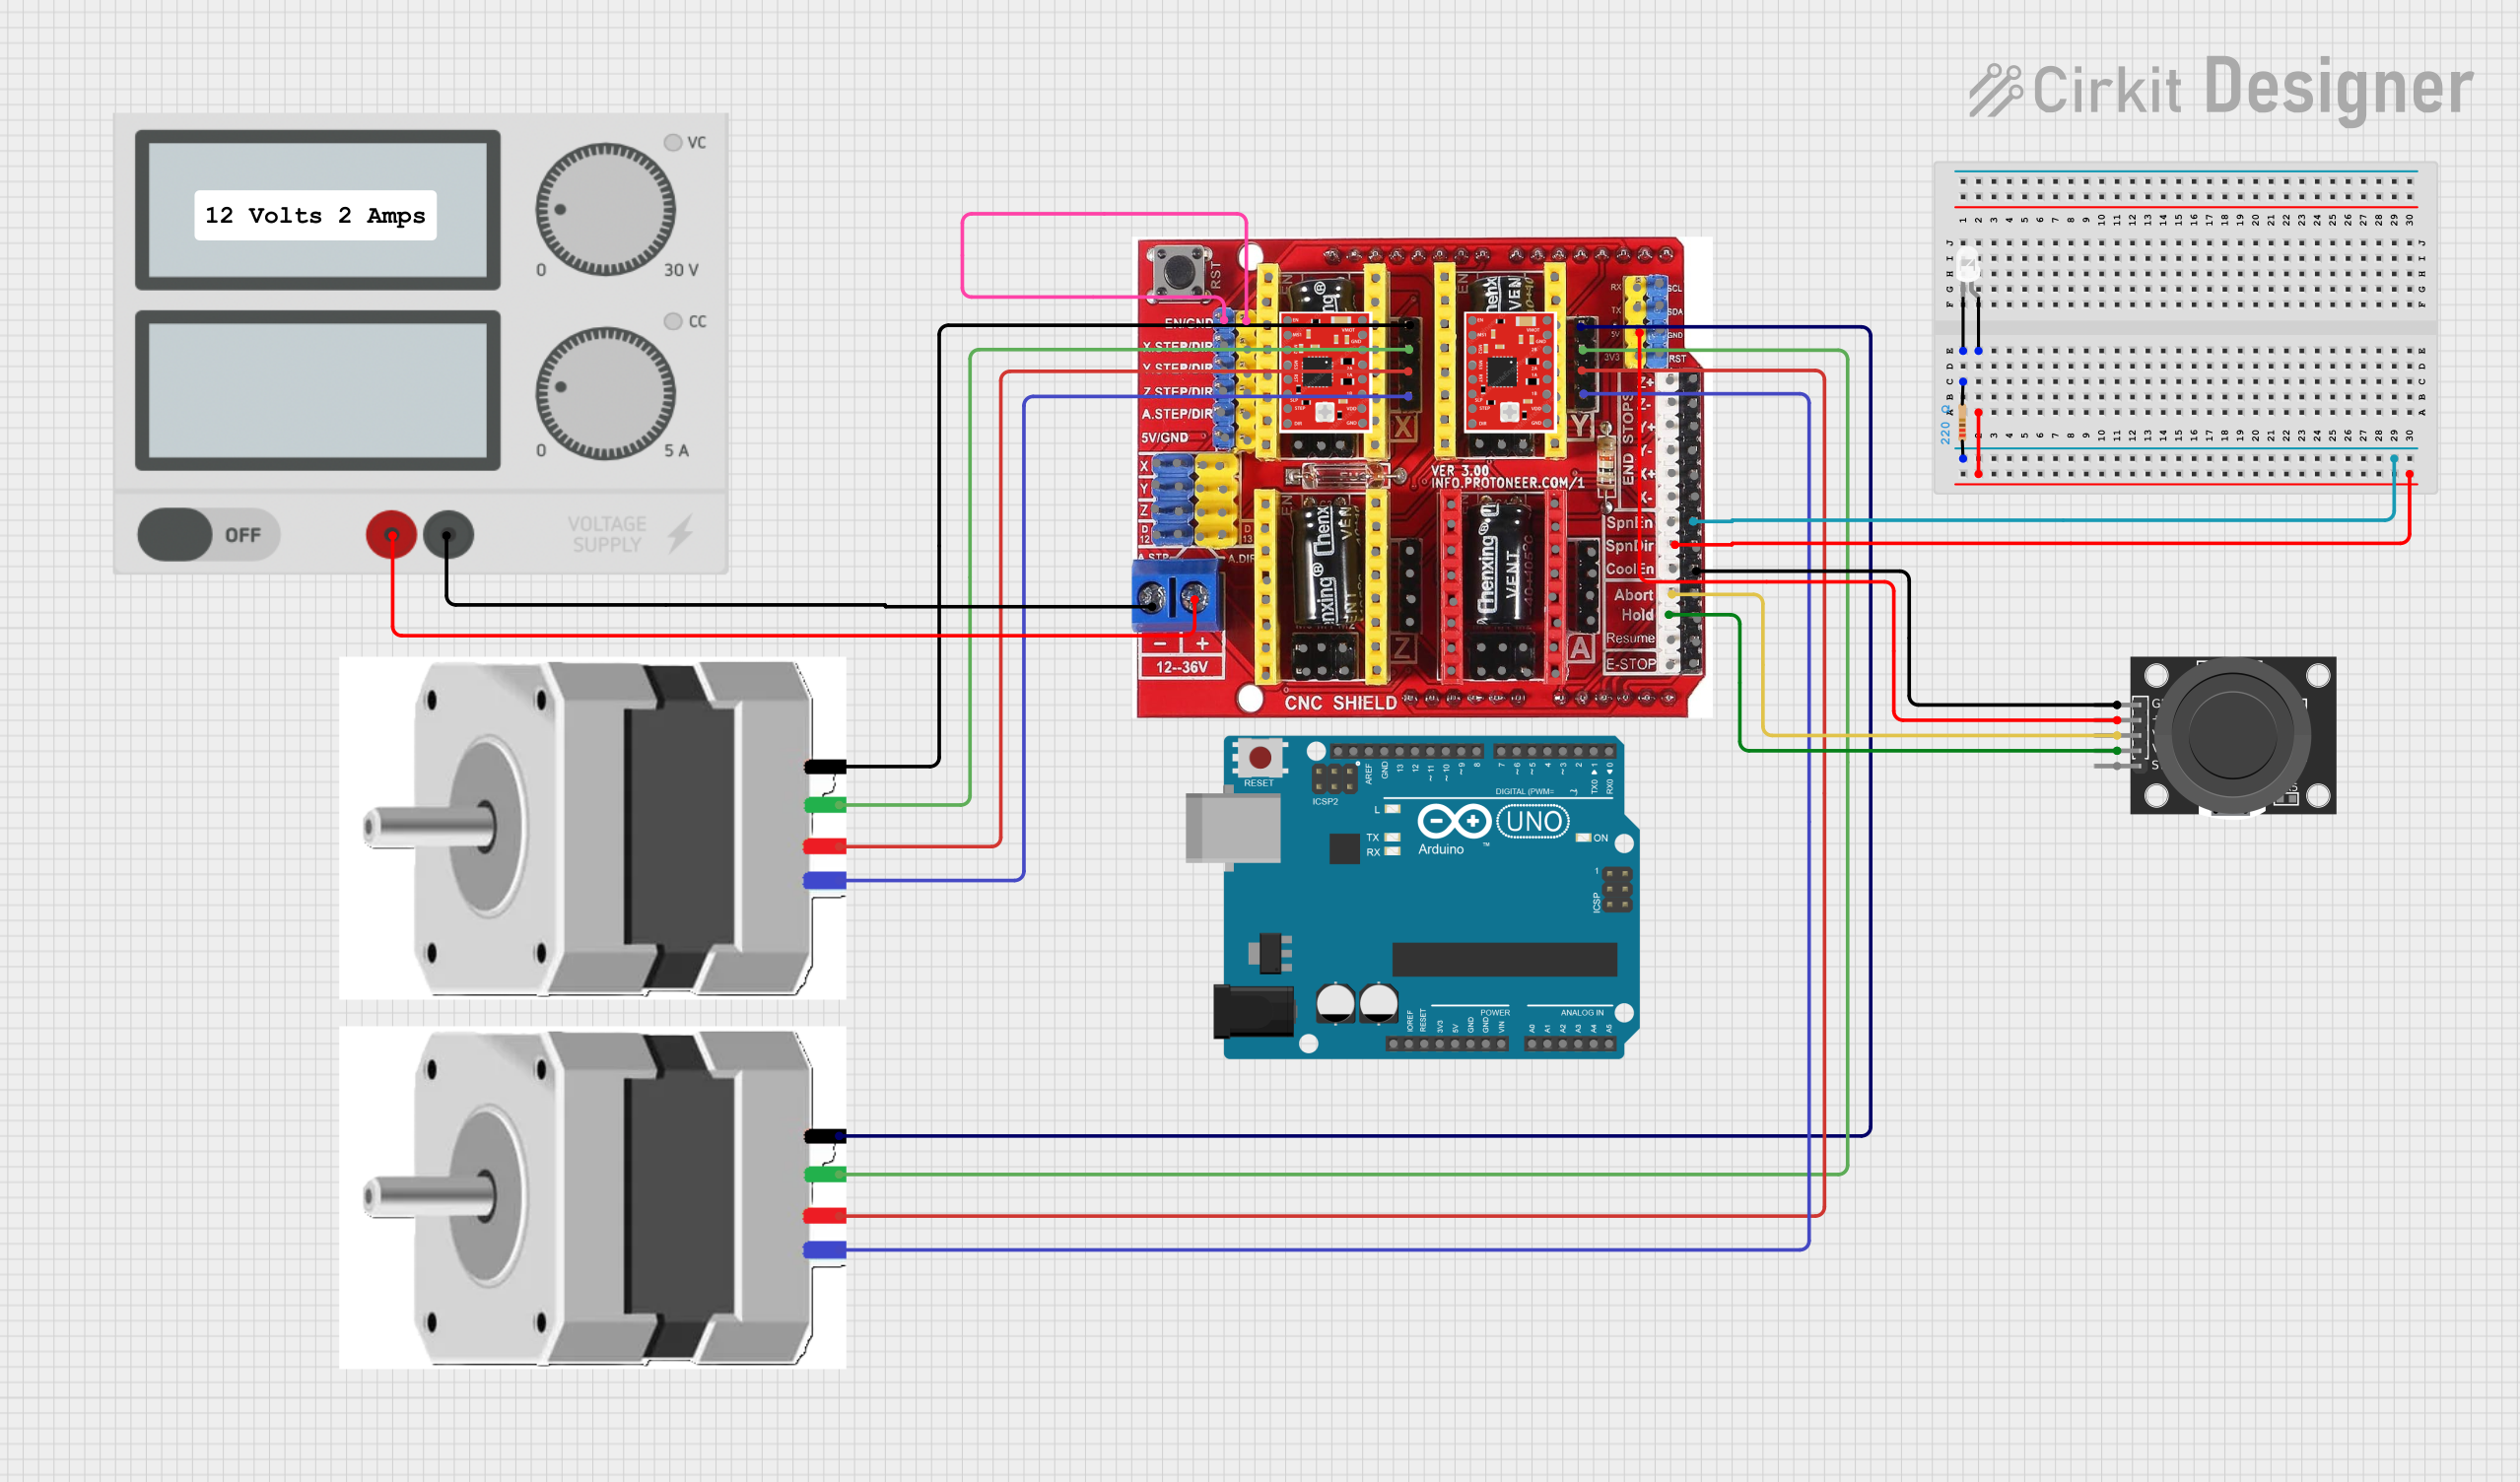
This circuit is a CNC control system that uses an Arduino UNO to interface with a CNC Shield V3, which drives two NEMA23 stepper motors for X and Y axis control. A KY-023 Dual Axis Joystick Module provides manual control inputs, and an LED with a current-limiting resistor indicates the spindle direction status.
This circuit controls a CNC machine using an Arduino UNO, a joystick module, and stepper motors. The joystick inputs are used to control the X and Y axes of the CNC machine, while an LED indicates the spindle direction. The CNC shield and motor drivers interface the Arduino with the stepper motors.
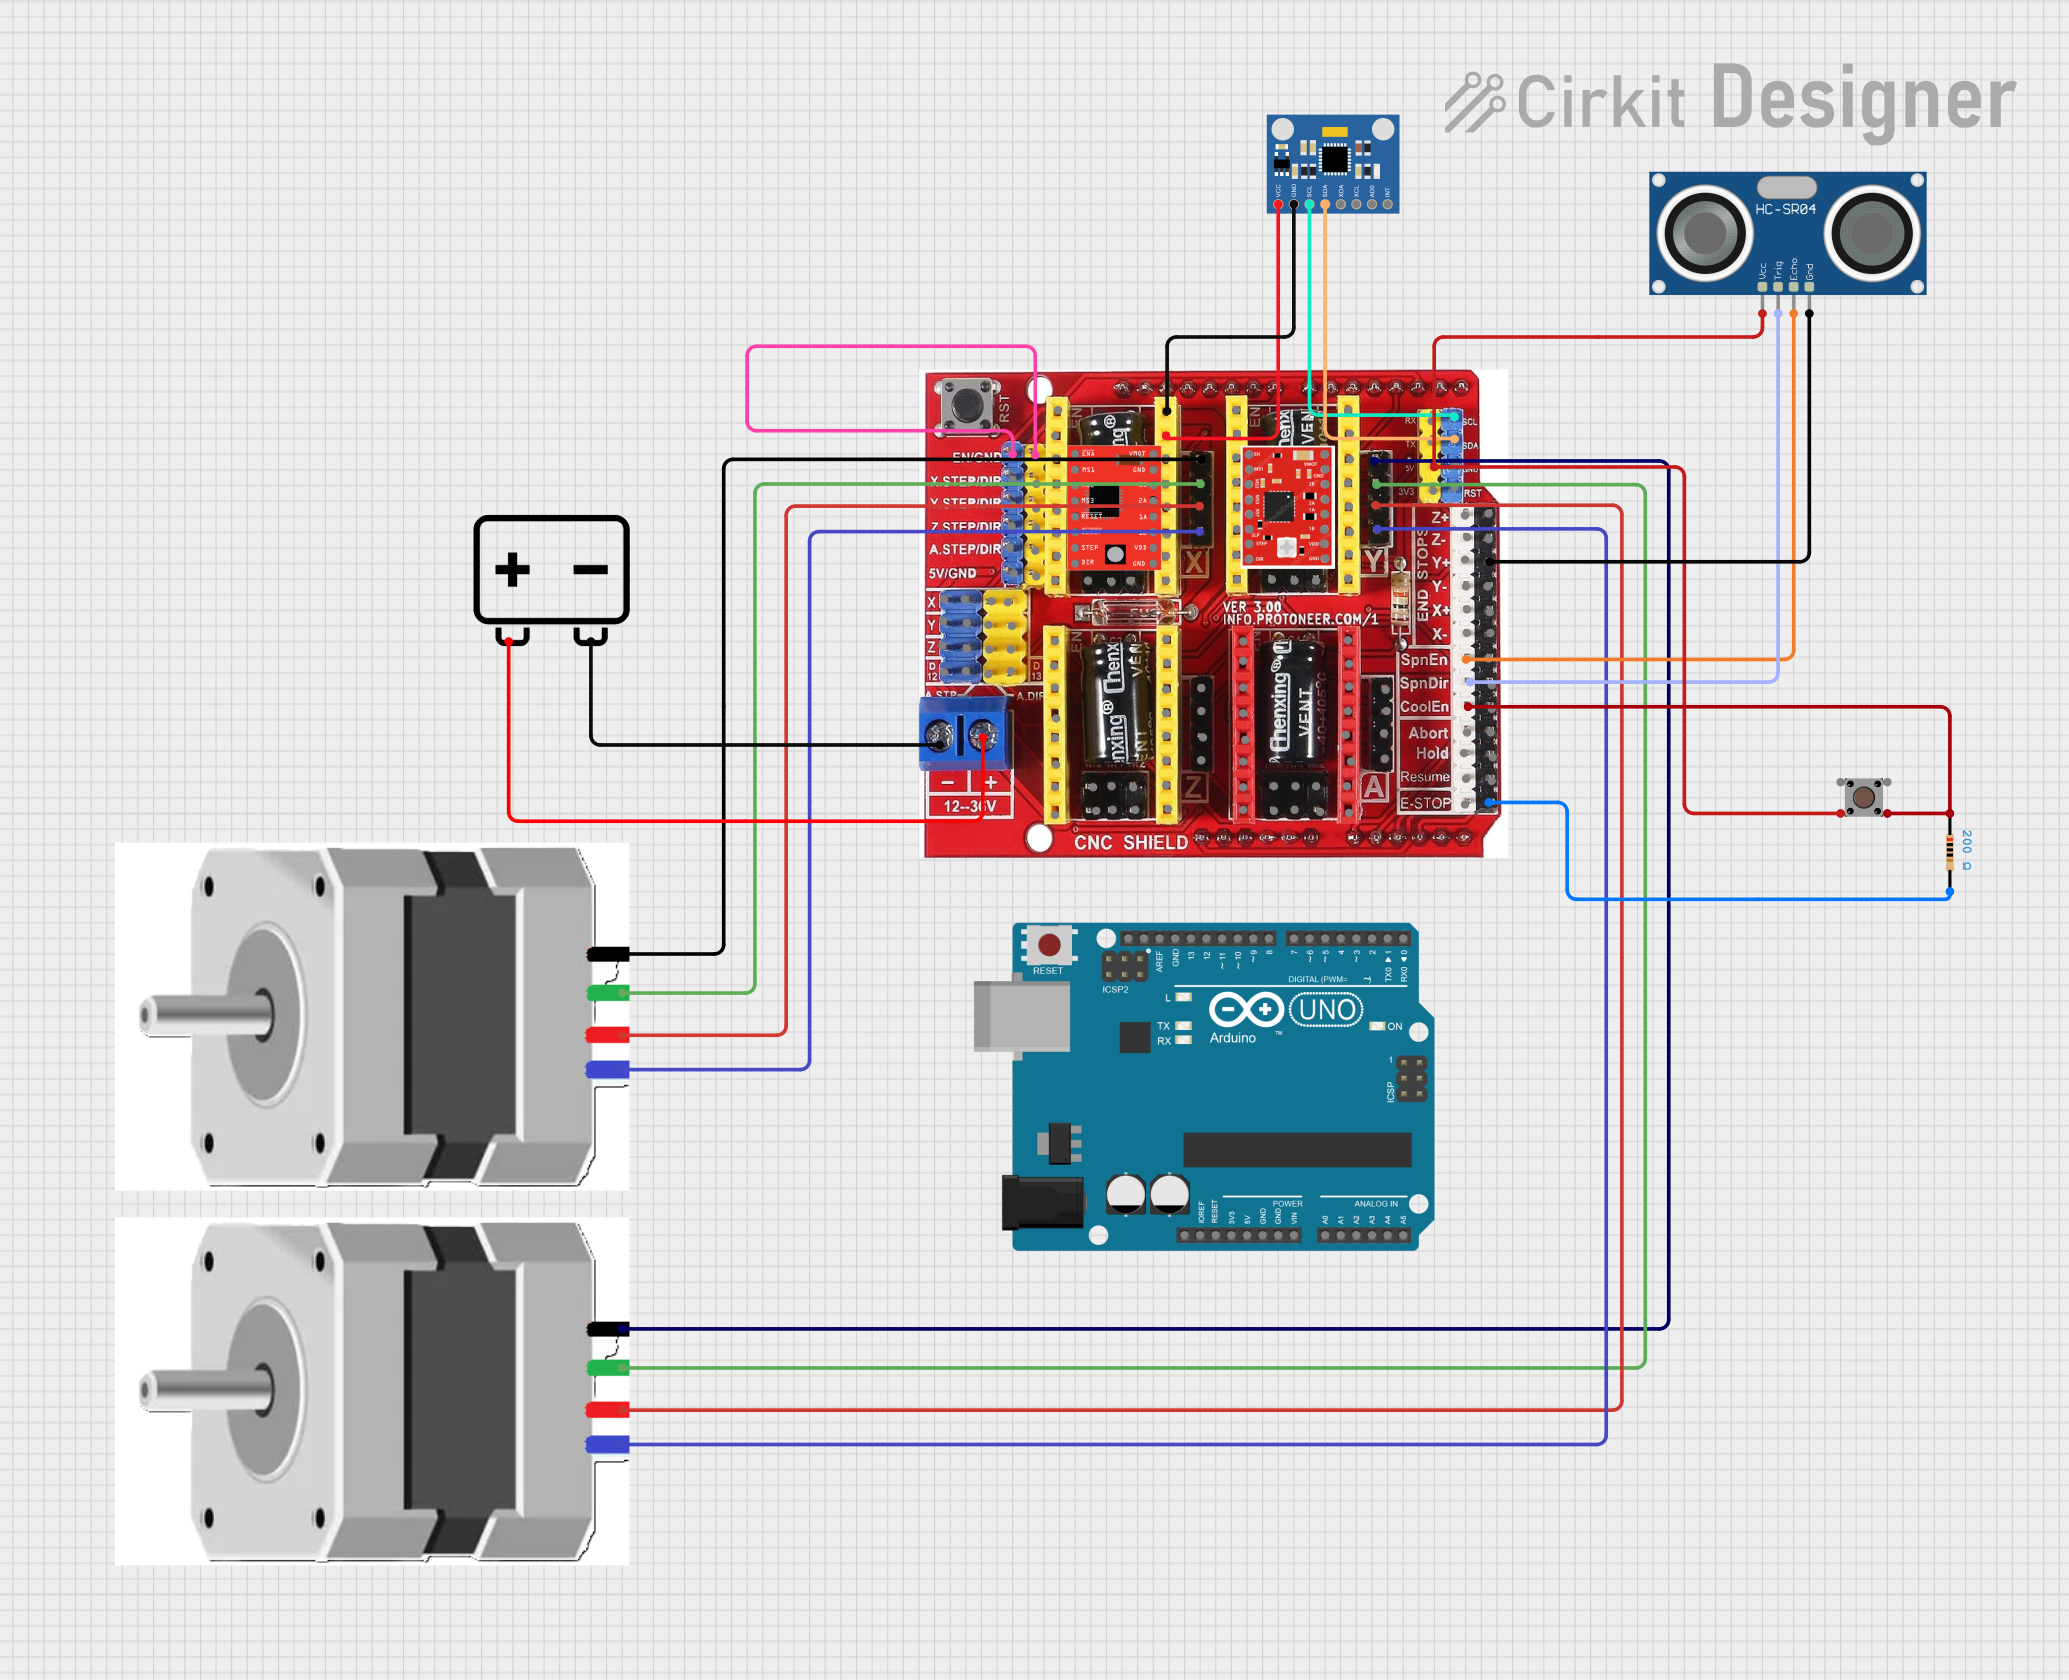
This circuit is a robotic control system that uses an Arduino UNO to manage a CNC Shield V3, which drives NEMA23 stepper motors for movement. It also incorporates an HC-SR04 ultrasonic sensor for distance measurement and an MPU6050 accelerometer and gyroscope for orientation sensing, enabling precise navigation and obstacle avoidance.
The CNC SHIELD V3 is designed to work seamlessly with Arduino boards, such as the Arduino UNO. Below are the key technical details and pin configurations:
Key Technical Details
Input Voltage: 12V to 36V (via external power supply for stepper motors)
Logic Voltage: 5V (provided by the Arduino board)
Stepper Motor Drivers Supported: A4988, DRV8825, and compatible drivers
Endstop Connections: 6 (2 per axis for X, Y, and Z)
Spindle/Accessory Control: PWM output for spindle speed control
Dimensions: 68mm x 53mm (fits standard Arduino UNO footprint)
Pin Configuration and Descriptions
The CNC SHIELD V3 has a straightforward pin layout for easy connectivity. Below is a table describing the key pins and their functions:
Pin Name
Description
X-STEP, Y-STEP, Z-STEP, A-STEP
Step pulse input for X, Y, Z, and A axes (connected to stepper drivers)
X-DIR, Y-DIR, Z-DIR, A-DIR
Direction control input for X, Y, Z, and A axes
EN (Enable)
Enables or disables all stepper drivers
X-END, Y-END, Z-END
Endstop inputs for X, Y, and Z axes (min and max positions)
SPN-EN
Spindle enable signal
SPN-DIR
Spindle direction control
PWM
Pulse-width modulation output for spindle speed control
VCC, GND
Power supply pins for logic (5V)
Motor Power Input
External power input for stepper motors (12V to 36V)
Usage Instructions
How to Use the CNC SHIELD V3 in a Circuit
Connect the Shield to an Arduino UNO:
Align the CNC SHIELD V3 with the Arduino UNO and carefully plug it into the Arduino's headers.
Install Stepper Motor Drivers:
Insert compatible stepper motor drivers (e.g., A4988 or DRV8825) into the designated sockets. Ensure correct orientation by matching the "Enable" pin on the driver with the "EN" pin on the shield.
Connect Stepper Motors:
Attach the stepper motors to the X, Y, Z, and A axis motor output terminals.
Connect Endstops:
Wire the endstop switches to the X-END, Y-END, and Z-END pins. Use normally open (NO) or normally closed (NC) switches as required.
Power the Shield:
Connect an external power supply (12V to 36V) to the motor power input terminal. Ensure the power supply can handle the current requirements of your stepper motors.
Upload Firmware:
Install GRBL firmware on the Arduino UNO using the Arduino IDE. GRBL is an open-source motion control firmware compatible with the CNC SHIELD V3.
Connect to a Computer:
Use a USB cable to connect the Arduino UNO to your computer. Use software like Universal G-code Sender (UGS) to send G-code commands to the shield.
Important Considerations and Best Practices
Cooling: Use heatsinks and/or a cooling fan for the stepper motor drivers to prevent overheating during operation.
Microstepping Configuration: Set the desired microstepping mode using the jumpers under each stepper driver.
Power Supply: Ensure the external power supply voltage matches the requirements of your stepper motors.
Firmware Settings: Configure GRBL settings (e.g., steps/mm, max feed rate) to match your machine's specifications.
Example Code for Arduino UNO
Below is an example of how to control a stepper motor connected to the X-axis using the CNC SHIELD V3:
// Example code to control a stepper motor on the X-axis using CNC SHIELD V3
// Ensure GRBL firmware is installed for full functionality

#define X_STEP_PIN 2  // Pin for X-axis step signal
#define X_DIR_PIN 5   // Pin for X-axis direction signal
#define ENABLE_PIN 8  // Pin to enable stepper drivers

void setup() {
  pinMode(X_STEP_PIN, OUTPUT);  // Set X_STEP_PIN as output
  pinMode(X_DIR_PIN, OUTPUT);   // Set X_DIR_PIN as output
  pinMode(ENABLE_PIN, OUTPUT);  // Set ENABLE_PIN as output

  digitalWrite(ENABLE_PIN, LOW);  // Enable stepper drivers
}

void loop() {
  digitalWrite(X_DIR_PIN, HIGH);  // Set direction to forward
  for (int i = 0; i < 200; i++) { // Move 200 steps (1 revolution for 1.8° stepper)
    digitalWrite(X_STEP_PIN, HIGH);  // Generate step pulse
    delayMicroseconds(500);          // Step pulse duration
    digitalWrite(X_STEP_PIN, LOW);   // End step pulse
    delayMicroseconds(500);          // Delay between steps
  }
  delay(1000);  // Wait 1 second before reversing direction

  digitalWrite(X_DIR_PIN, LOW);  // Set direction to reverse
  for (int i = 0; i < 200; i++) { // Move 200 steps in reverse
    digitalWrite(X_STEP_PIN, HIGH);
    delayMicroseconds(500);
    digitalWrite(X_STEP_PIN, LOW);
    delayMicroseconds(500);
  }
  delay(1000);  // Wait 1 second before repeating
}
Troubleshooting and FAQs
Common Issues and Solutions
Stepper Motors Not Moving:
Cause: Incorrect wiring or loose connections.
Solution: Double-check motor connections and ensure the stepper drivers are properly seated.
Overheating Stepper Drivers:
Cause: Insufficient cooling or excessive current settings.
Solution: Attach heatsinks and/or a cooling fan. Adjust the current limit on the stepper drivers.
Endstops Not Detected:
Cause: Incorrect wiring or faulty switches.
Solution: Verify endstop connections and test the switches with a multimeter.
GRBL Not Responding:
Cause: Firmware not installed or incorrect settings.
Solution: Reinstall GRBL firmware and verify configuration settings.
FAQs
Can I use the CNC SHIELD V3 with other Arduino boards?
Yes, the shield is compatible with Arduino boards that have the same pinout as the Arduino UNO.
What stepper motor drivers are recommended?
The A4988 and DRV8825 drivers are commonly used and fully compatible with the CNC SHIELD V3.
How do I control the spindle speed?
Use the PWM pin to send a pulse-width modulation signal to the spindle controller.
Can I use the A-axis for a rotary tool?
Yes, the A-axis can be configured for a rotary tool or as a clone of another axis.
By following this documentation, you can effectively set up and use the CNC SHIELD V3 for your motion control projects.

 Open Project in Cirkit Designer