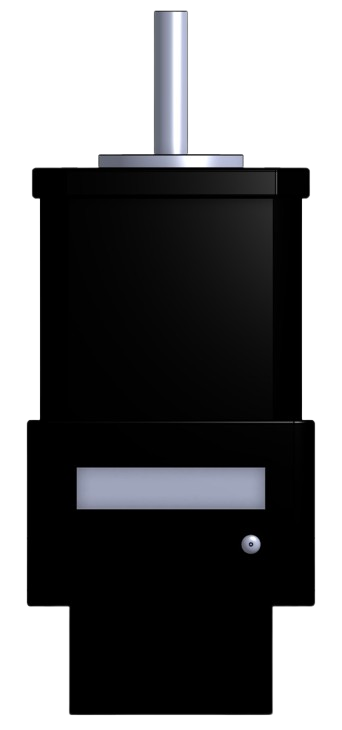
The Stepper Motor 2 (STP-MTRD-17038E), manufactured by Automation Direct, is a high-performance stepper motor designed for precise control of angular position and speed. Unlike traditional DC motors, stepper motors divide a full rotation into a large number of discrete steps, making them ideal for applications requiring accurate positioning and repeatable motion.
Explore Projects Built with Stepper Motor 2
Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
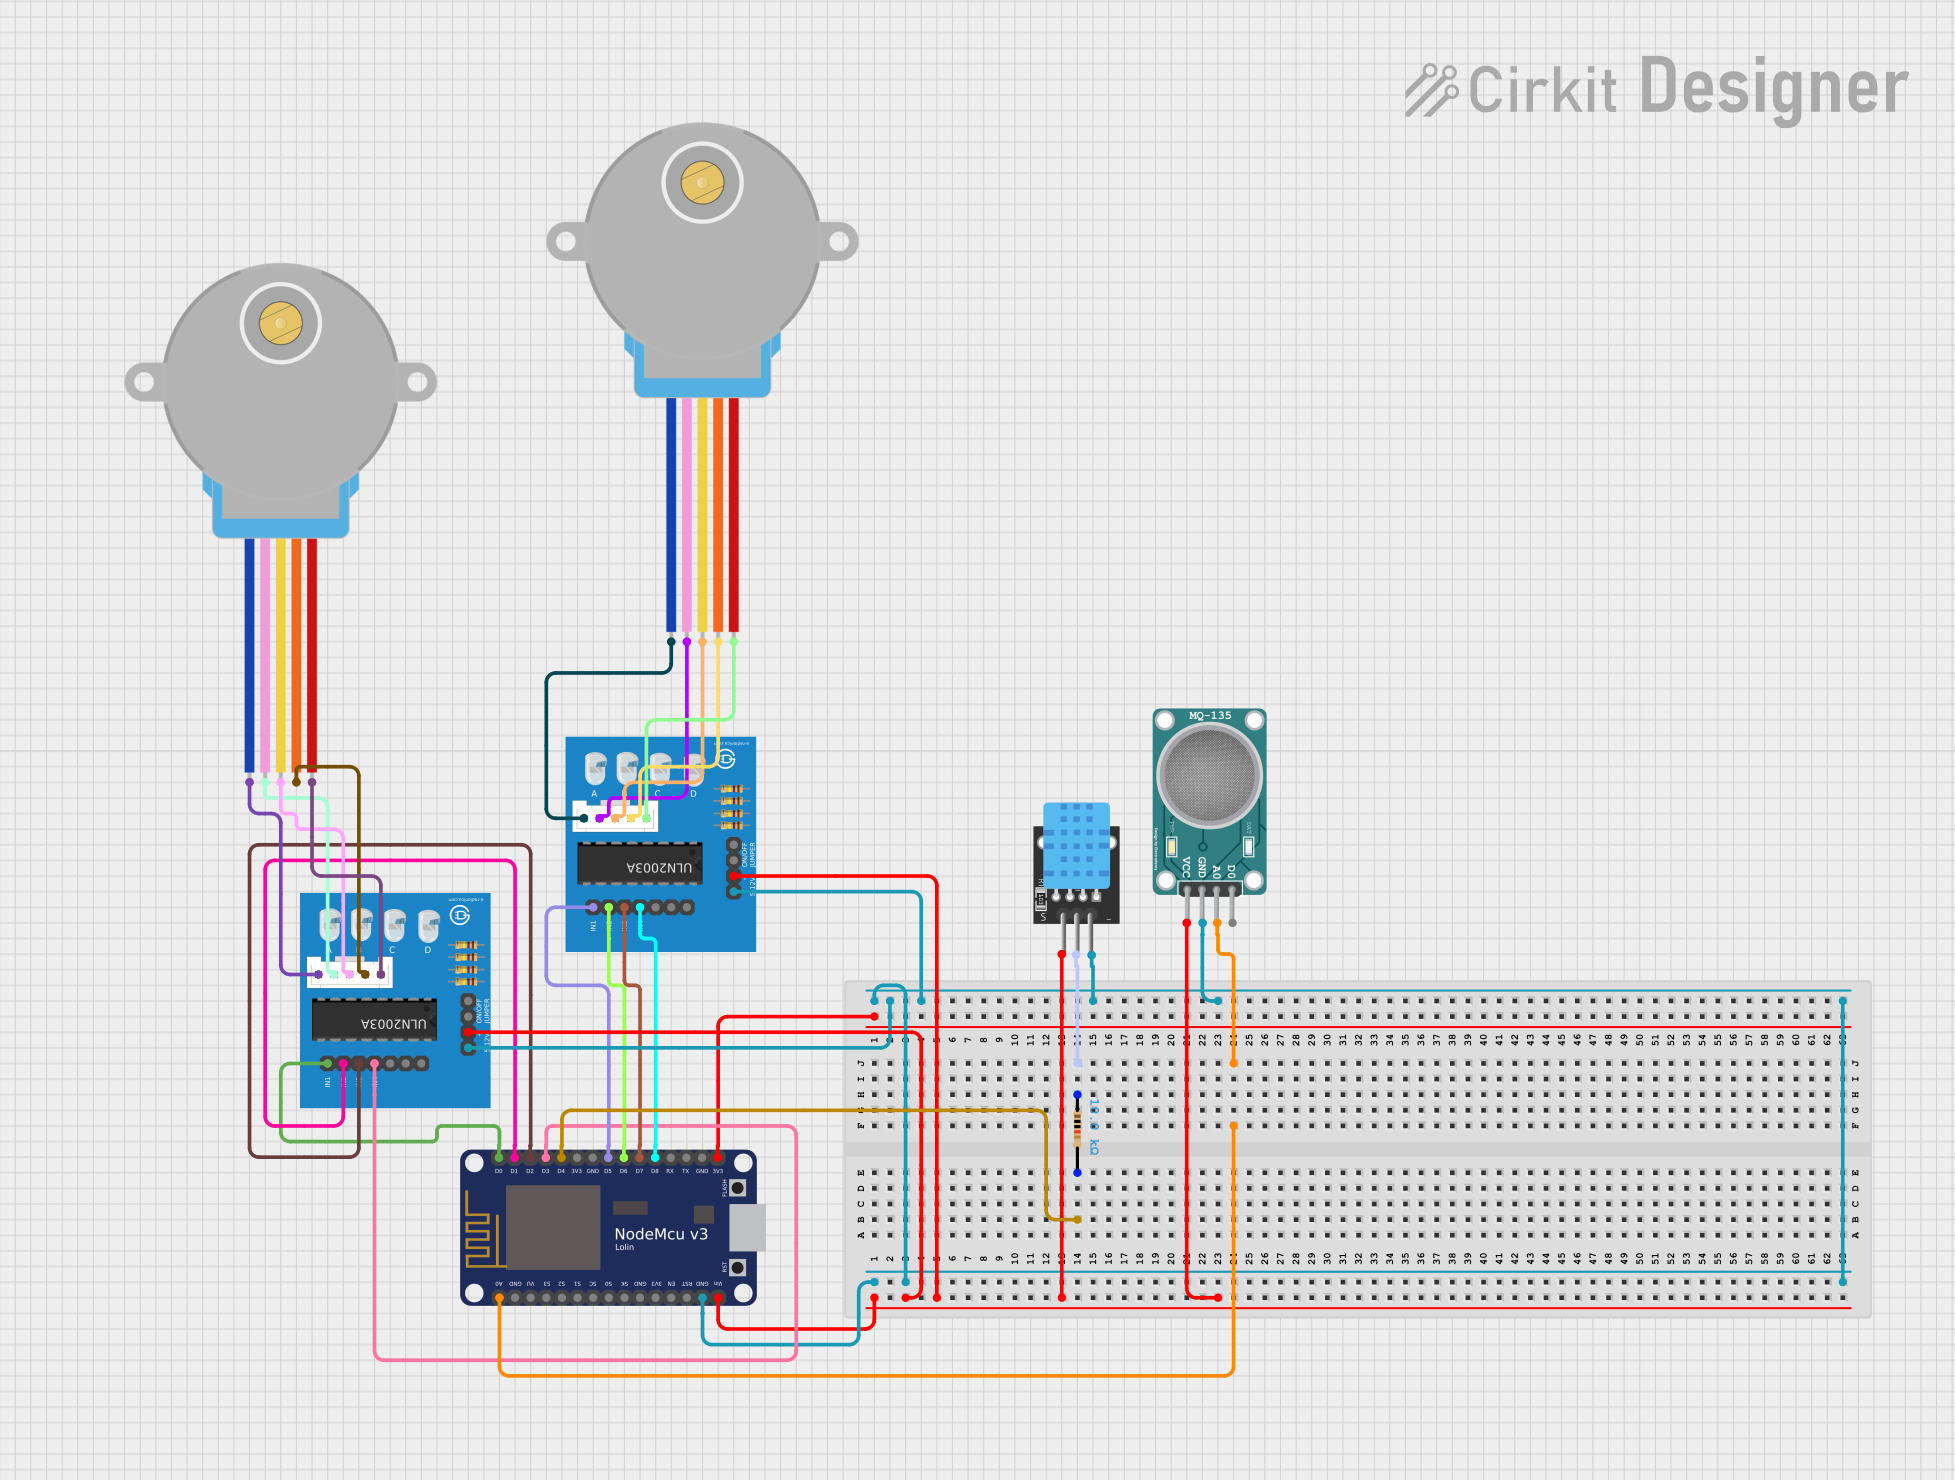
This circuit features two 28BYJ-48 stepper motors controlled by ULN2003A breakout boards, interfaced with a NodeMCU V3 ESP8266 microcontroller. The NodeMCU collects environmental data from a DHT11 temperature and humidity sensor and an MQ-135 air quality sensor. The microcontroller uses WiFi for connectivity and controls the stepper motors based on the sensor inputs, likely for regulating environmental conditions.
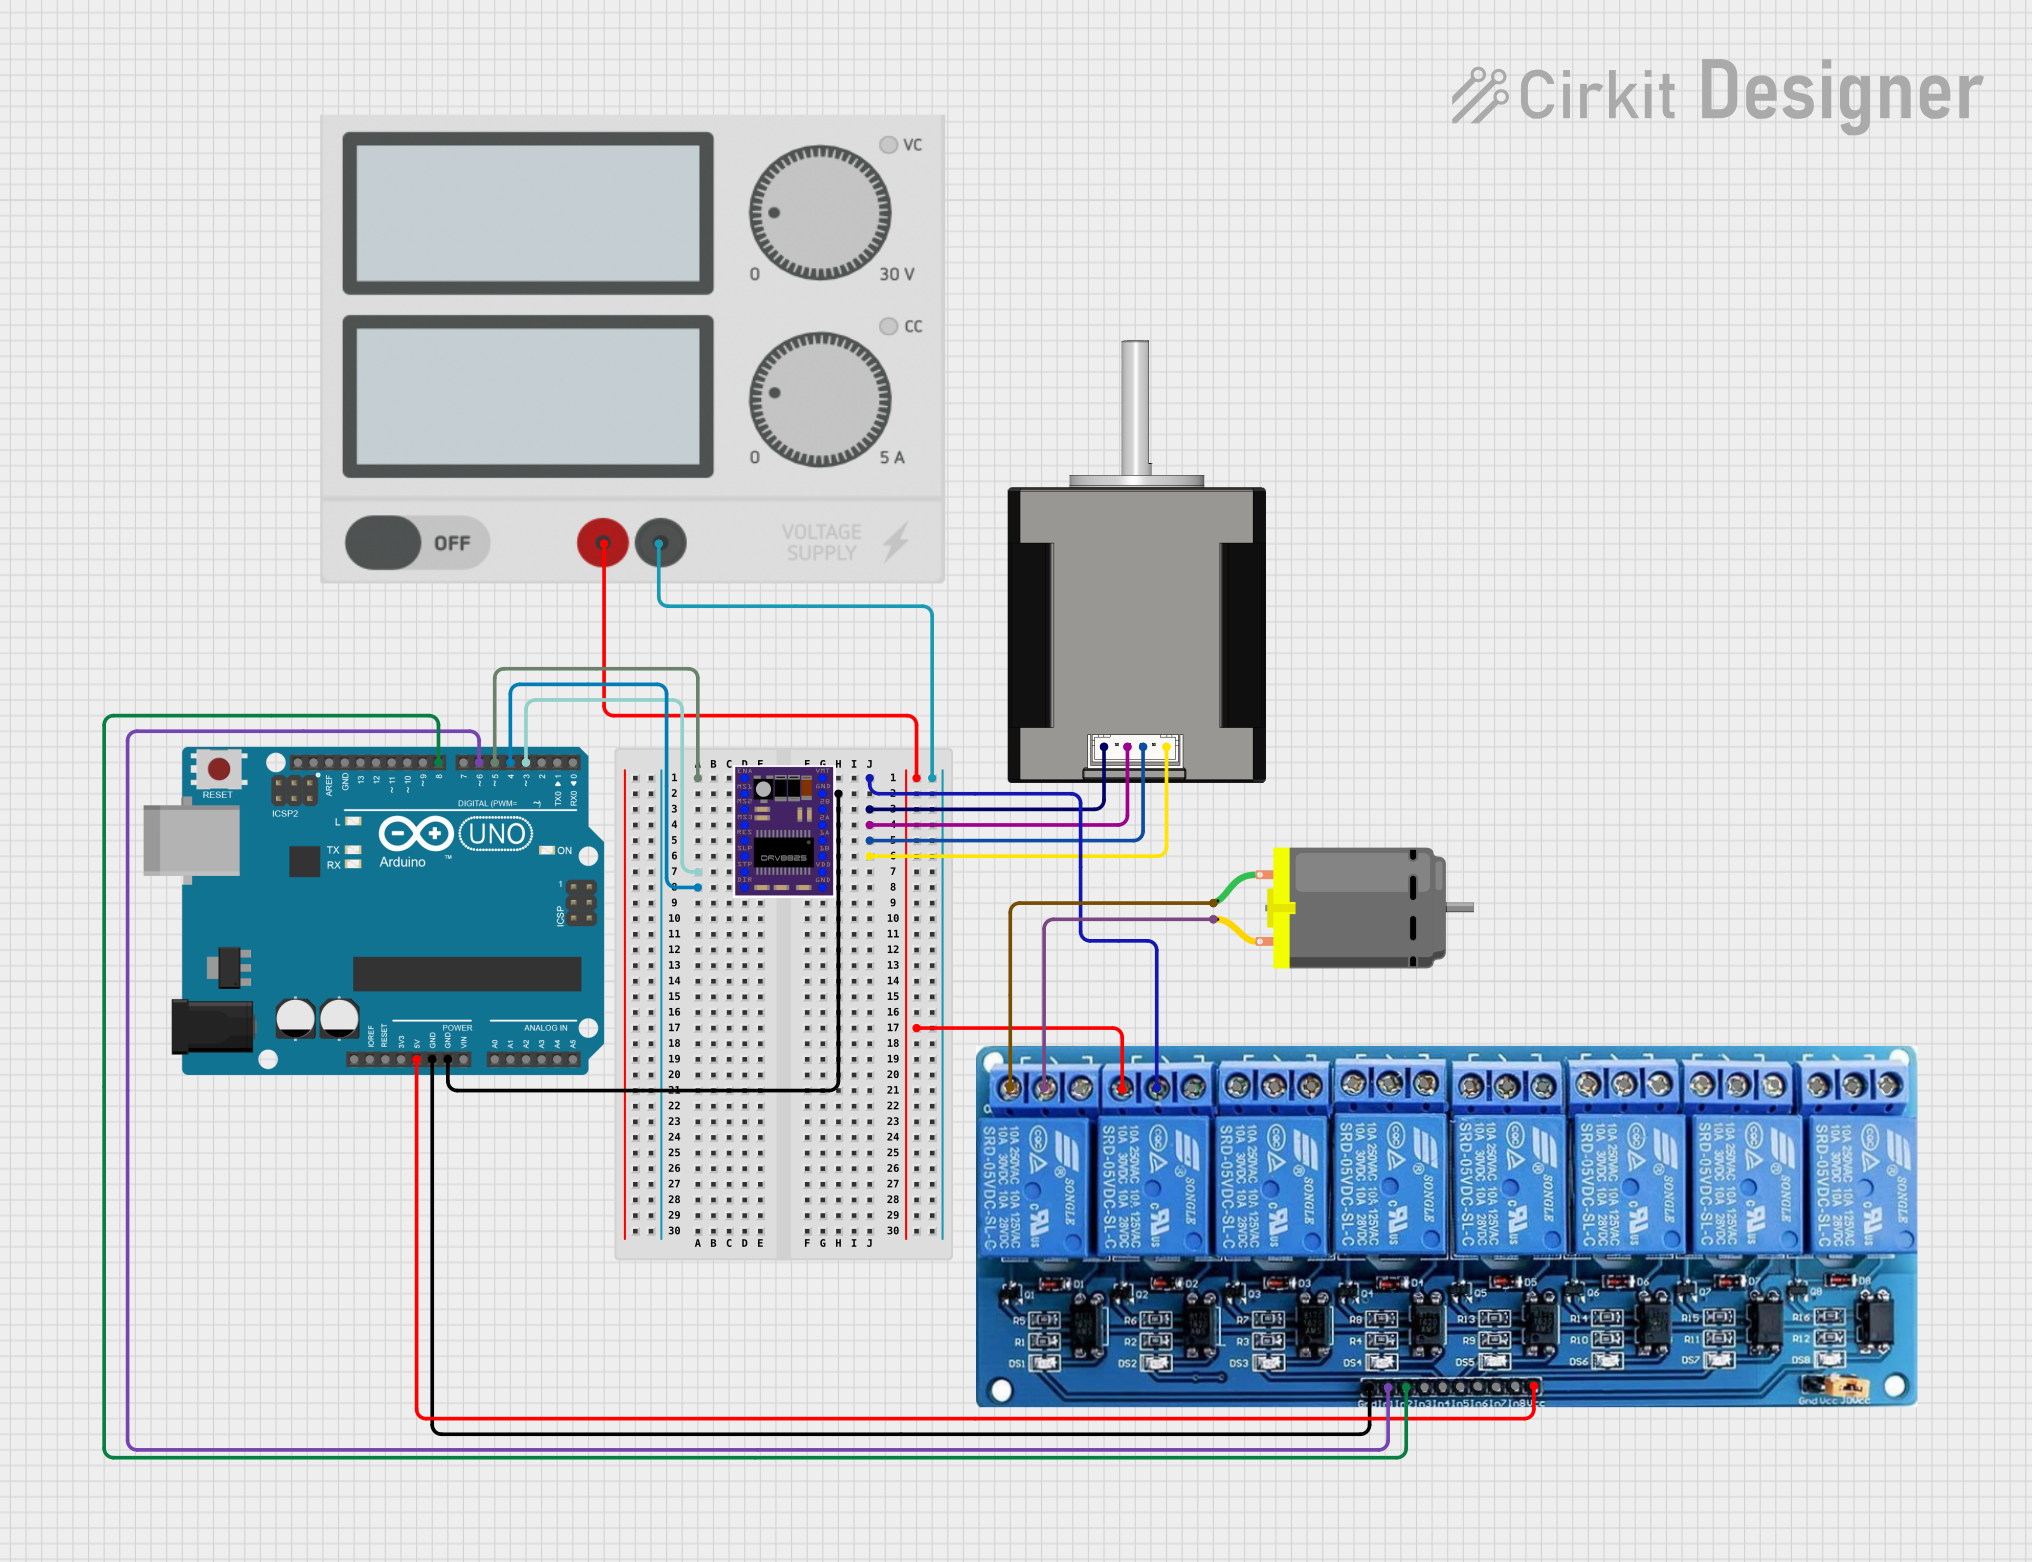
This circuit controls a Nema 17 stepper motor using a DRV8825 driver module, with an Arduino UNO microcontroller dictating the step and direction. Additionally, the circuit can switch a DC motor on and off using a relay module controlled by the Arduino. The power supply provides the necessary voltage for the relay and the motor driver, which in turn powers the stepper motor, while the Arduino's firmware defines the motor's stepping behavior and the relay's switching to control the DC motor.
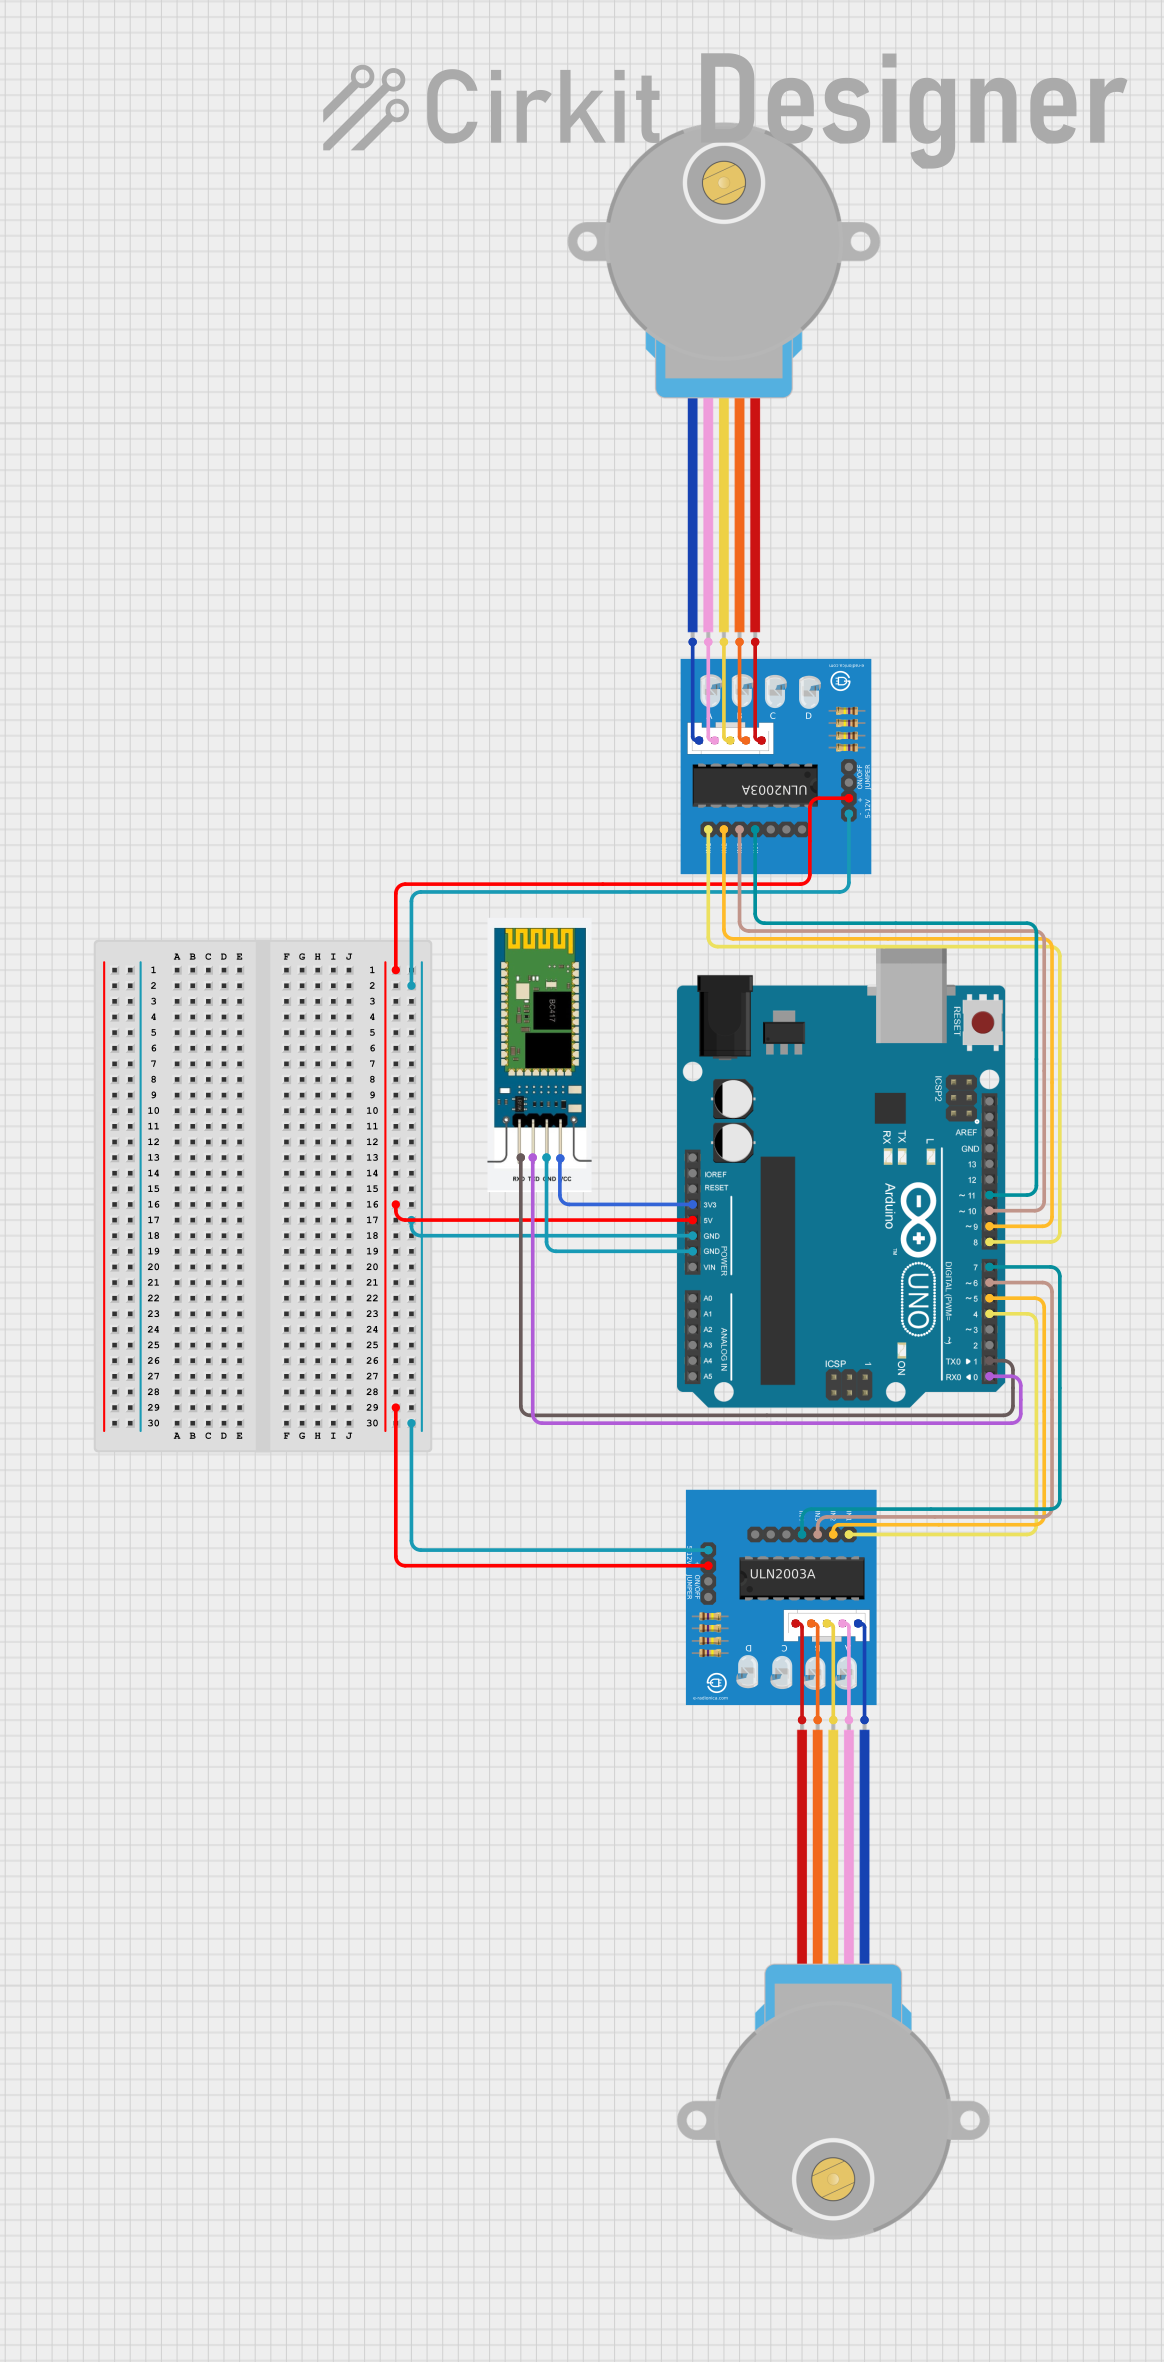
This circuit features an Arduino UNO microcontroller interfaced with two 28BYJ-48 stepper motors via two ULN2003A breakout boards, and an HC-06 Bluetooth module for wireless communication. The Arduino controls the stepper motors using the AccelStepper library, allowing for precise movement and acceleration control. The HC-06 module enables the Arduino to receive commands via Bluetooth to control the speed and direction of the stepper motors.
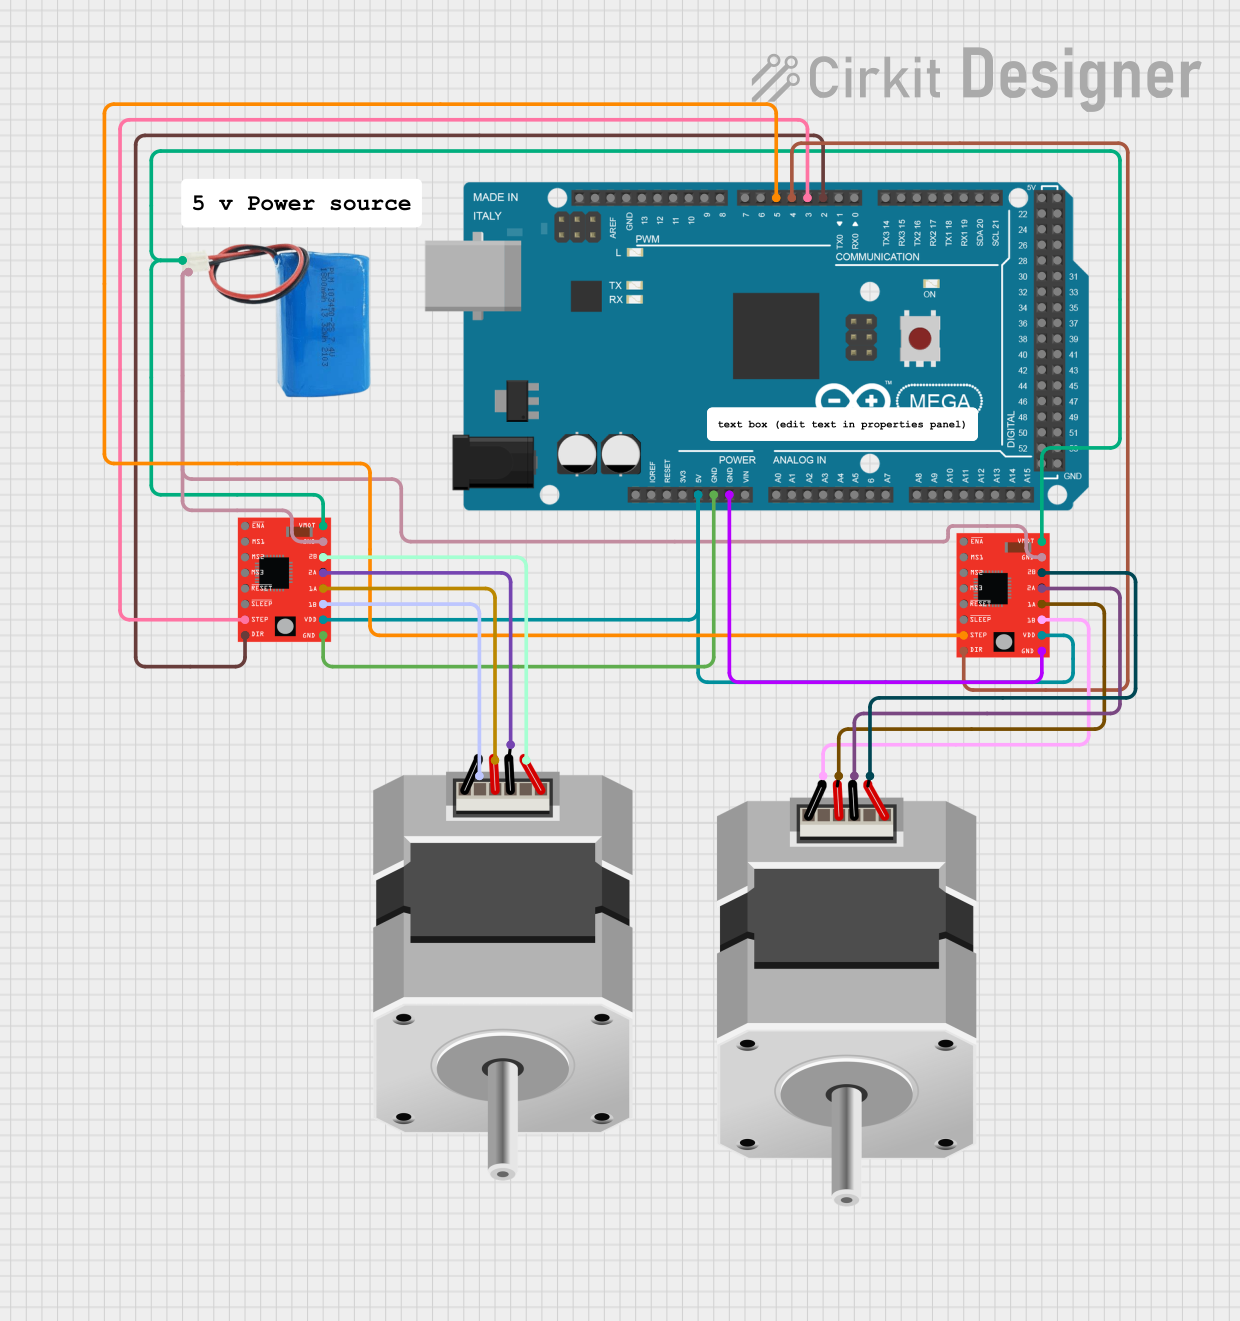
This circuit controls two bipolar stepper motors using A4988 stepper motor drivers, which are managed by an Arduino Mega 2560. The Arduino runs a program that rotates the motors 3000 steps forward and backward with a 1-second delay between direction changes, utilizing the DIR and STEP pins for motor control.
3D Printers: For precise movement of print heads and platforms.
CNC Machines: To control tool positioning with high accuracy.
Robotics: For controlling joint movements and actuators.
Automated Systems: Such as conveyor belts and pick-and-place machines.
Camera Gimbals: For smooth and precise camera positioning.
Technical Specifications
The following table outlines the key technical details of the STP-MTRD-17038E stepper motor:
Parameter
Value
Manufacturer
Automation Direct
Part Number
STP-MTRD-17038E
Step Angle
1.8° per step
Holding Torque
1.26 Nm (178 oz-in)
Rated Current per Phase
2.8 A
Voltage
2.55 V
Resistance per Phase
0.91 Ω
Inductance per Phase
3.6 mH
Number of Leads
4
Shaft Diameter
6.35 mm (0.25 in)
Motor Frame Size
NEMA 17
Weight
0.5 kg (1.1 lbs)
Pin Configuration and Descriptions
The STP-MTRD-17038E is a 4-wire bipolar stepper motor. The pinout and wiring details are as follows:
Lead Color
Function
Description
Red
Phase A+
Positive terminal of Phase A coil
Blue
Phase A-
Negative terminal of Phase A coil
Green
Phase B+
Positive terminal of Phase B coil
Black
Phase B-
Negative terminal of Phase B coil
Usage Instructions
How to Use the Component in a Circuit
Power Supply: Ensure the motor is powered by a suitable driver capable of handling the rated current (2.8 A per phase) and voltage (2.55 V). A stepper motor driver such as the Automation Direct STP-DRV-4850 is recommended.
Wiring: Connect the motor leads to the driver as per the pin configuration table. Ensure proper polarity to avoid incorrect operation.
Control Signals: Use a microcontroller (e.g., Arduino UNO) or a motion controller to send step and direction signals to the driver.
Step Resolution: Configure the driver for the desired microstepping resolution (e.g., full step, half step, 1/8 step) to achieve the required precision.
Important Considerations and Best Practices
Current Limiting: Set the current limit on the driver to match the motor's rated current (2.8 A) to prevent overheating.
Cooling: Ensure adequate ventilation or heat dissipation for the motor and driver during operation.
Backlash and Load: Avoid excessive mechanical backlash or overloading the motor, as this can reduce accuracy and lifespan.
Power Supply: Use a regulated power supply with sufficient current capacity to handle the motor and driver.
Example Code for Arduino UNO
Below is an example of how to control the STP-MTRD-17038E stepper motor using an Arduino UNO and a compatible stepper motor driver:
// Include the Stepper library for easy motor control
#include <Stepper.h>

// Define the number of steps per revolution (360° / 1.8° = 200 steps)
#define STEPS_PER_REV 200

// Initialize the Stepper library with the motor's step count and pin connections
// Pins 8 and 9 control Phase A, Pins 10 and 11 control Phase B
Stepper stepperMotor(STEPS_PER_REV, 8, 9, 10, 11);

void setup() {
  // Set the motor speed in RPM (revolutions per minute)
  stepperMotor.setSpeed(60); // 60 RPM

  // Initialize serial communication for debugging
  Serial.begin(9600);
  Serial.println("Stepper Motor Test Initialized");
}

void loop() {
  // Rotate the motor 1 full revolution clockwise
  Serial.println("Rotating clockwise...");
  stepperMotor.step(STEPS_PER_REV);

  delay(1000); // Wait for 1 second

  // Rotate the motor 1 full revolution counterclockwise
  Serial.println("Rotating counterclockwise...");
  stepperMotor.step(-STEPS_PER_REV);

  delay(1000); // Wait for 1 second
}
Notes:
Replace the pin numbers (8, 9, 10, 11) with the actual pins connected to your driver.
Adjust the speed and step count as needed for your application.
Troubleshooting and FAQs
Common Issues and Solutions
Motor Not Moving:
Cause: Incorrect wiring or loose connections.
Solution: Double-check the wiring and ensure all connections are secure.
Motor Vibrates but Does Not Rotate:
Cause: Incorrect step sequence or driver configuration.
Solution: Verify the step sequence and microstepping settings on the driver.
Overheating:
Cause: Current limit set too high or insufficient cooling.
Solution: Reduce the current limit on the driver and ensure proper ventilation.
Skipping Steps:
Cause: Excessive load or insufficient torque.
Solution: Reduce the load or increase the current limit (within safe limits).
Noisy Operation:
Cause: Low microstepping resolution or mechanical issues.
Solution: Increase the microstepping resolution and check for mechanical alignment.
FAQs
Q: Can I use this motor with a unipolar driver? A: No, the STP-MTRD-17038E is a bipolar stepper motor and requires a bipolar driver.
Q: What is the maximum speed of this motor? A: The maximum speed depends on the driver, power supply, and load. Typically, it can achieve speeds up to 1000 RPM under optimal conditions.
Q: Can I run this motor without a driver? A: No, a stepper motor driver is required to generate the precise step signals needed for operation.
Q: How do I calculate the torque required for my application? A: Use the formula: Torque = Force × Distance. Ensure the required torque is within the motor's holding torque (1.26 Nm).
By following this documentation, users can effectively integrate and operate the STP-MTRD-17038E stepper motor in their projects.

 Open Project in Cirkit Designer