The Mini L293D Motor Driver is a compact dual H-bridge motor driver designed to control the direction and speed of DC motors and stepper motors. It is widely used in robotics, automation, and other motor control applications due to its small size, ease of use, and versatility. This component is ideal for projects requiring precise motor control, such as robotic arms, wheeled robots, and conveyor systems.
Explore Projects Built with Mini L293D Motor Driver
Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
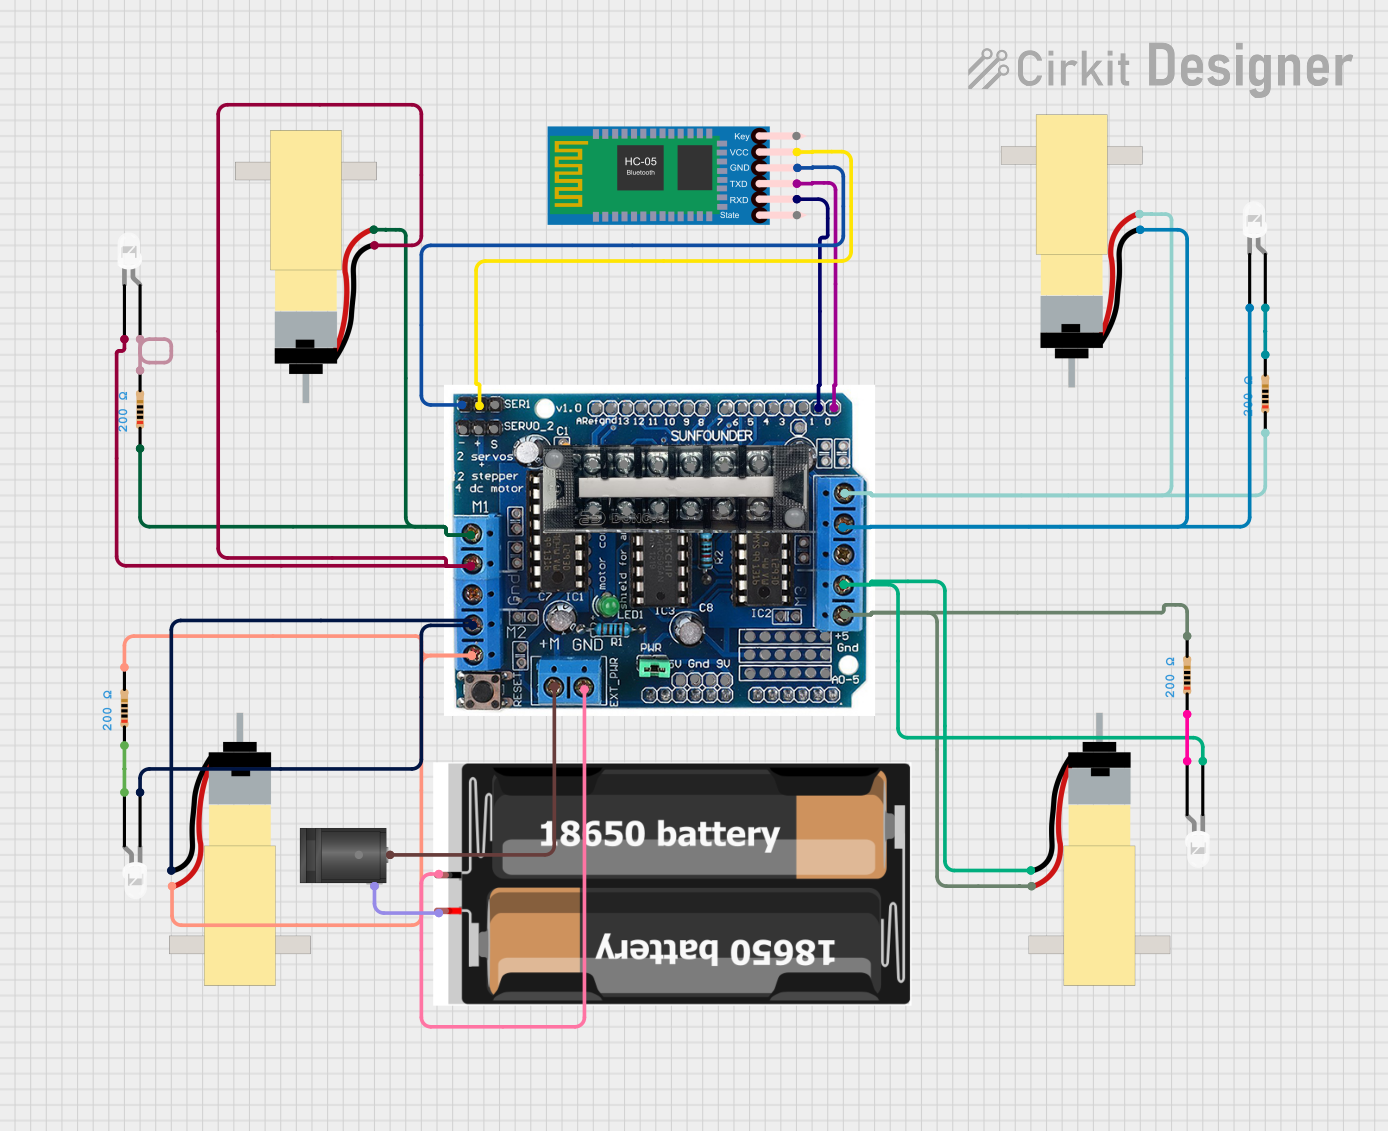
This circuit is a motor control system that uses an L293D driver shield to control four hobby gearmotors, with each motor connected to an LED and a resistor for status indication. The system is powered by a 2x 18650 battery pack and includes an HC-05 Bluetooth module for wireless communication.
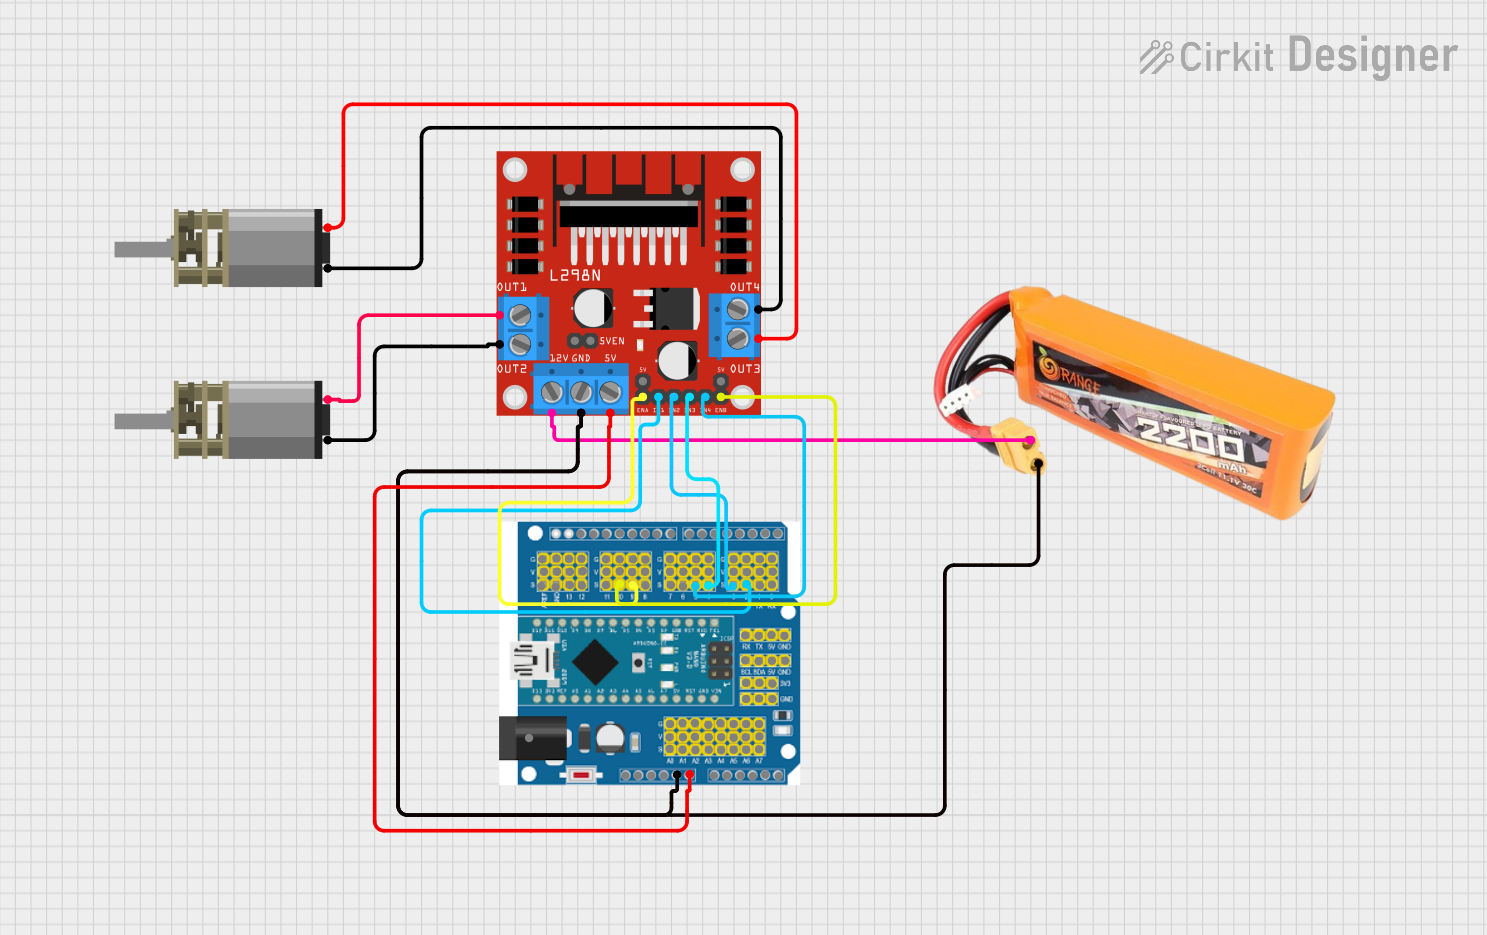
This circuit uses an Arduino Expansion Board to control two DC Mini Metal Gear Motors via an L298N DC motor driver. The motors are powered by a 2200mAh LiPo battery, and the Arduino sends control signals to the motor driver to manage the direction and speed of the motors.
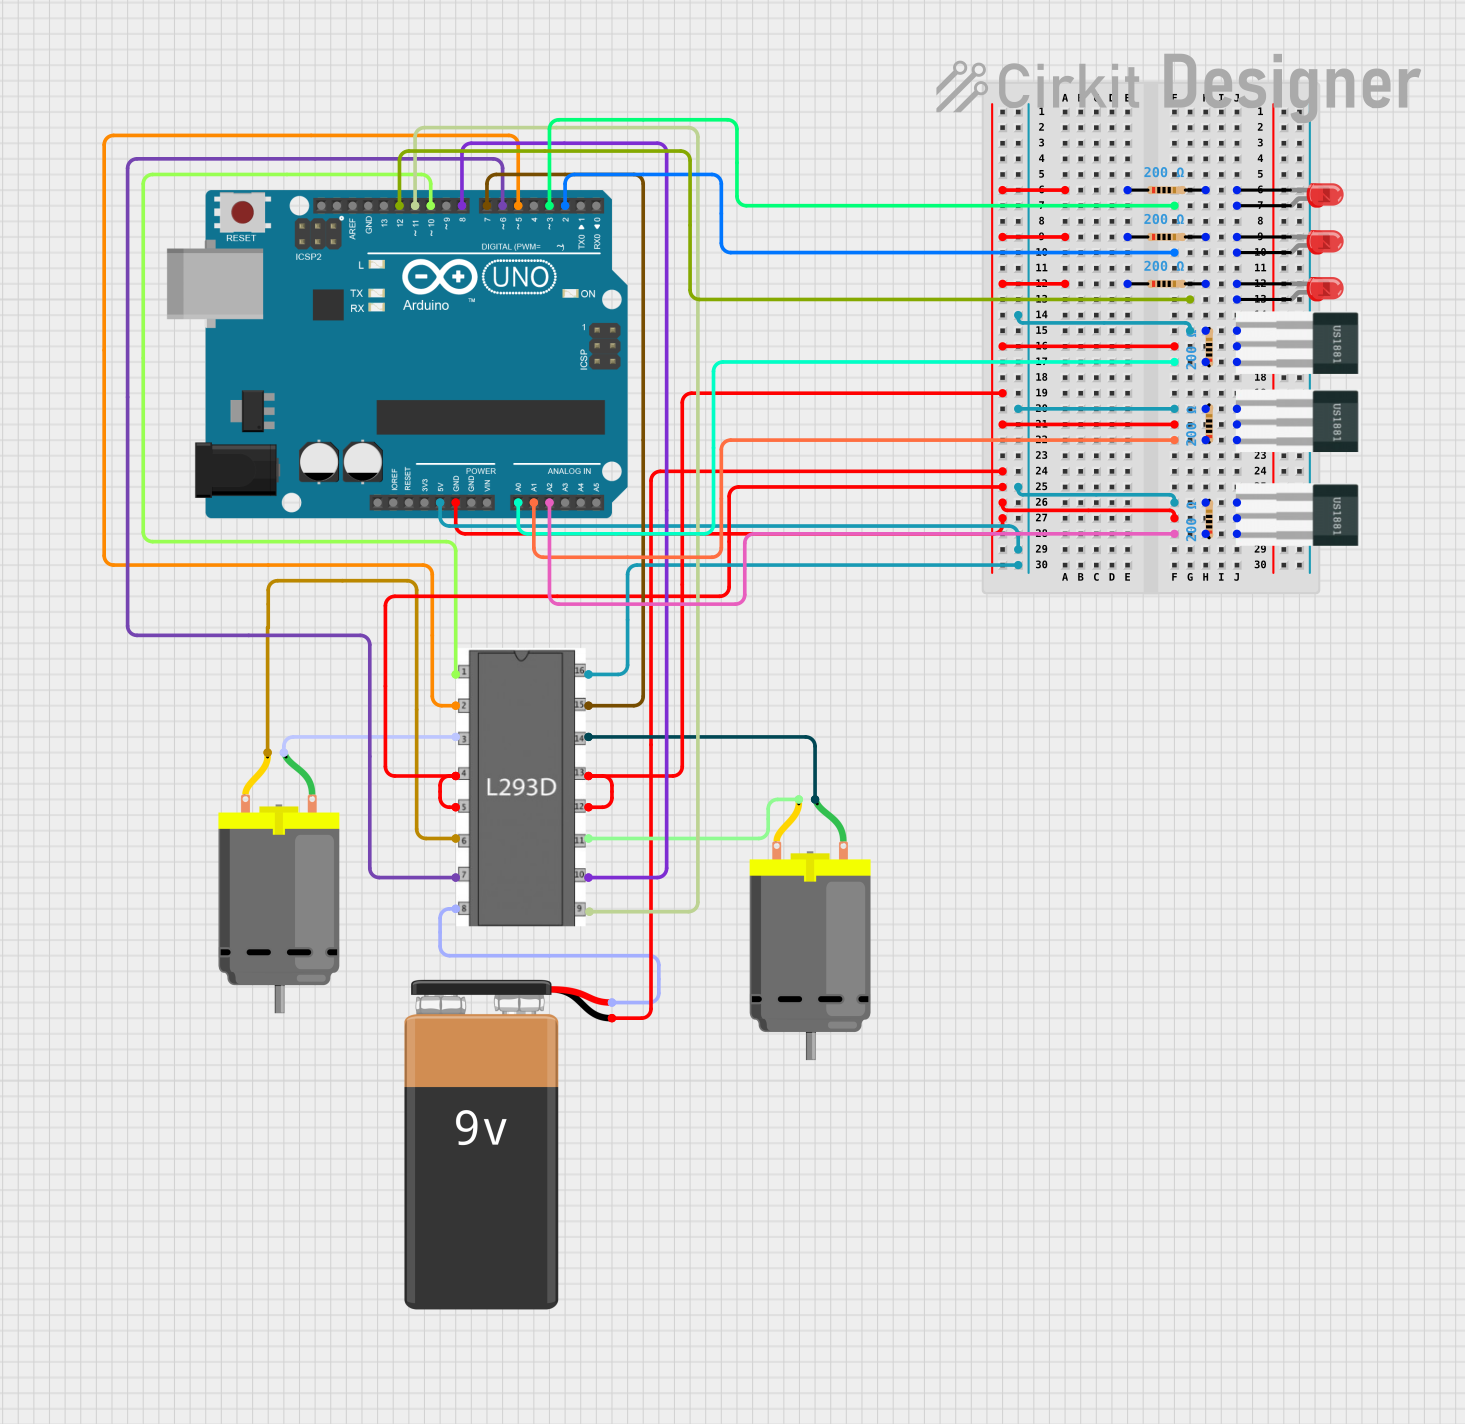
This circuit controls two DC motors using an L293D motor driver, with an Arduino UNO as the microcontroller. The Arduino reads inputs from three Hall sensors and controls the motors' direction based on the sensors' states, while also indicating the sensors' status through three LEDs. Each LED and Hall sensor is connected to the Arduino with a current-limiting resistor, and the motors' operation is dependent on the Hall sensors' signals.
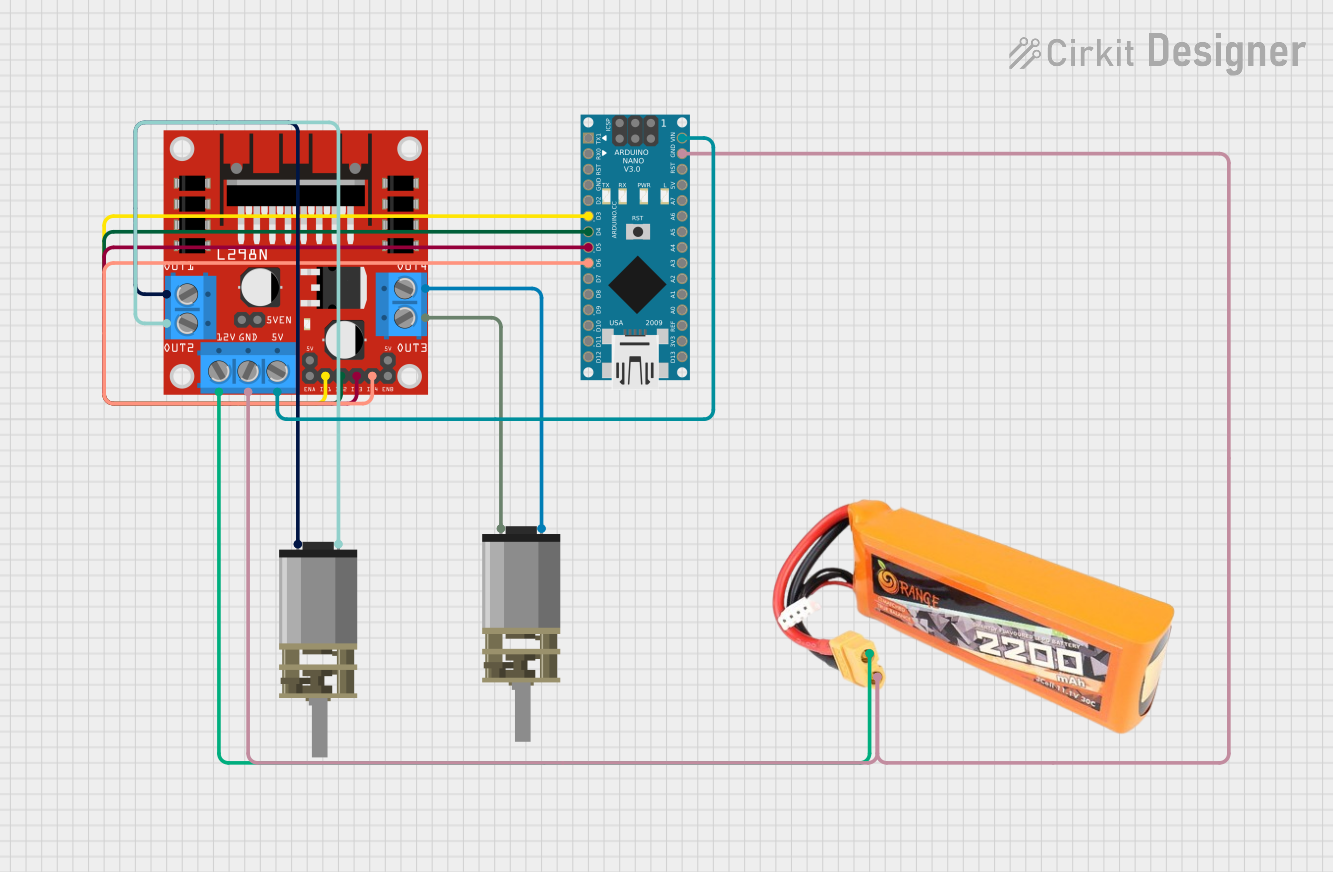
This circuit is designed to control two DC Mini Metal Gear Motors using an Arduino Nano microcontroller and an L298N DC motor driver. The Arduino Nano's digital pins D3, D4, D5, and D6 are connected to the L298N's IN1, IN2, IN3, and IN4 inputs respectively, allowing the microcontroller to control the speed and direction of the motors. Power is supplied by a lipo battery connected to the L298N, which also provides 5V back to the Arduino's VIN pin, and the motors are connected to the L298N's output pins.
Stepper motor control for CNC machines or 3D printers
Technical Specifications
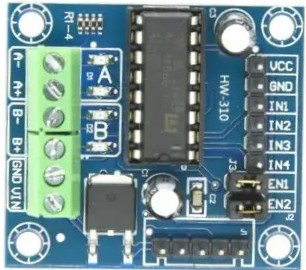
The Mini L293D Motor Driver is based on the L293D IC, which is capable of driving two DC motors or one stepper motor. Below are the key technical details:
Key Specifications:
Operating Voltage: 4.5V to 36V
Logic Voltage: 5V
Maximum Output Current (per channel): 600mA (peak: 1.2A)
Number of Channels: 2 (dual H-bridge)
Motor Types Supported: DC motors, stepper motors
Control Logic: TTL-compatible
Thermal Shutdown Protection: Yes
Dimensions: Compact form factor (varies by manufacturer)
Pin Configuration and Descriptions:
The Mini L293D Motor Driver typically has the following pin layout:
Input/Control Pins:
Pin Name
Pin Number
Description
IN1
1
Input 1 for Motor A (controls direction)
IN2
2
Input 2 for Motor A (controls direction)
IN3
7
Input 1 for Motor B (controls direction)
IN4
8
Input 2 for Motor B (controls direction)
ENA
9
Enable pin for Motor A (PWM for speed control)
ENB
10
Enable pin for Motor B (PWM for speed control)
Power and Output Pins:
Pin Name
Pin Number
Description
VCC
16
Motor power supply (4.5V to 36V)
GND
4, 5, 12, 13
Ground
VS
8
Logic voltage supply (typically 5V)
OUT1
3
Output 1 for Motor A
OUT2
6
Output 2 for Motor A
OUT3
11
Output 1 for Motor B
OUT4
14
Output 2 for Motor B
Usage Instructions
How to Use the Mini L293D Motor Driver in a Circuit:
Power Connections:
Connect the motor power supply to the VCC pin (4.5V to 36V).
Connect the logic voltage (5V) to the VS pin.
Connect all GND pins to the ground of your circuit.
Motor Connections:
Connect the terminals of Motor A to OUT1 and OUT2.
Connect the terminals of Motor B to OUT3 and OUT4.
Control Connections:
Use the IN1 and IN2 pins to control the direction of Motor A.
Use the IN3 and IN4 pins to control the direction of Motor B.
Use the ENA and ENB pins to enable/disable the motors and control their speed using PWM signals.
Logic Control:
Use a microcontroller (e.g., Arduino UNO) to send control signals to the input pins (IN1, IN2, IN3, IN4) and PWM signals to the enable pins (ENA, ENB).
Example Arduino Code:
Below is an example of how to control two DC motors using the Mini L293D Motor Driver and an Arduino UNO:
// Define motor control pins
#define IN1 2  // Motor A direction control pin 1
#define IN2 3  // Motor A direction control pin 2
#define ENA 9  // Motor A speed control (PWM pin)
#define IN3 4  // Motor B direction control pin 1
#define IN4 5  // Motor B direction control pin 2
#define ENB 10 // Motor B speed control (PWM pin)

void setup() {
  // Set motor control pins as outputs
  pinMode(IN1, OUTPUT);
  pinMode(IN2, OUTPUT);
  pinMode(ENA, OUTPUT);
  pinMode(IN3, OUTPUT);
  pinMode(IN4, OUTPUT);
  pinMode(ENB, OUTPUT);
}

void loop() {
  // Motor A: Forward at 50% speed
  digitalWrite(IN1, HIGH); // Set IN1 high
  digitalWrite(IN2, LOW);  // Set IN2 low
  analogWrite(ENA, 128);   // Set ENA to 50% duty cycle (128/255)

  // Motor B: Reverse at 75% speed
  digitalWrite(IN3, LOW);  // Set IN3 low
  digitalWrite(IN4, HIGH); // Set IN4 high
  analogWrite(ENB, 192);   // Set ENB to 75% duty cycle (192/255)

  delay(2000); // Run motors for 2 seconds

  // Stop both motors
  analogWrite(ENA, 0); // Set ENA to 0% duty cycle (stop motor A)
  analogWrite(ENB, 0); // Set ENB to 0% duty cycle (stop motor B)

  delay(2000); // Wait for 2 seconds
}
Important Considerations:
Ensure the motor power supply voltage matches the motor's rated voltage.
Do not exceed the maximum current rating of 600mA per channel.
Use proper heat dissipation if operating at high currents for extended periods.
Always connect all ground pins to a common ground to avoid erratic behavior.
Troubleshooting and FAQs
Common Issues and Solutions:
Motors Not Running:
Check all power connections (VCC, VS, and GND).
Ensure the enable pins (ENA, ENB) are receiving a valid PWM signal or are set high.
Motors Running in the Wrong Direction:
Reverse the connections to the input pins (IN1, IN2, IN3, IN4) or swap the motor terminals.
Overheating:
Ensure the current draw of the motors does not exceed the driver’s maximum rating.
Add a heat sink or cooling fan if necessary.
Erratic Motor Behavior:
Verify that all ground connections are properly connected.
Check for noise or interference in the control signals.
FAQs:
Can I control stepper motors with this driver?
Yes, the Mini L293D can control stepper motors by driving the coils in sequence. Refer to your stepper motor's datasheet for the correct sequence.
What happens if I exceed the current rating?
The driver may overheat and shut down due to thermal protection. Prolonged overcurrent may damage the IC.
Can I use this driver with a 3.3V microcontroller?
The L293D requires 5V logic levels. Use a level shifter if your microcontroller operates at 3.3V.
This concludes the documentation for the Mini L293D Motor Driver.

 Open Project in Cirkit Designer