Introduction
The Bipolar Stepper Motor (NEMA 17) is a precision motion control device widely used in robotics, 3D printers, CNC machines, and other applications requiring accurate positioning. It features two coils (phases) and operates by energizing these coils in a specific sequence to achieve precise rotational movement. The "NEMA 17" designation refers to the motor's faceplate dimensions of 1.7 x 1.7 inches, making it compact yet powerful for a variety of use cases.
Common Applications
- 3D printers for precise layer-by-layer movement
- CNC machines for accurate cutting and engraving
- Robotics for controlled motion and positioning
- Camera sliders and gimbals for smooth motion control
- Automated conveyor systems
Technical Specifications
Below are the key technical details for a typical NEMA 17 Bipolar Stepper Motor. Note that specific models may vary slightly, so always refer to the datasheet of your motor.
Pin Configuration
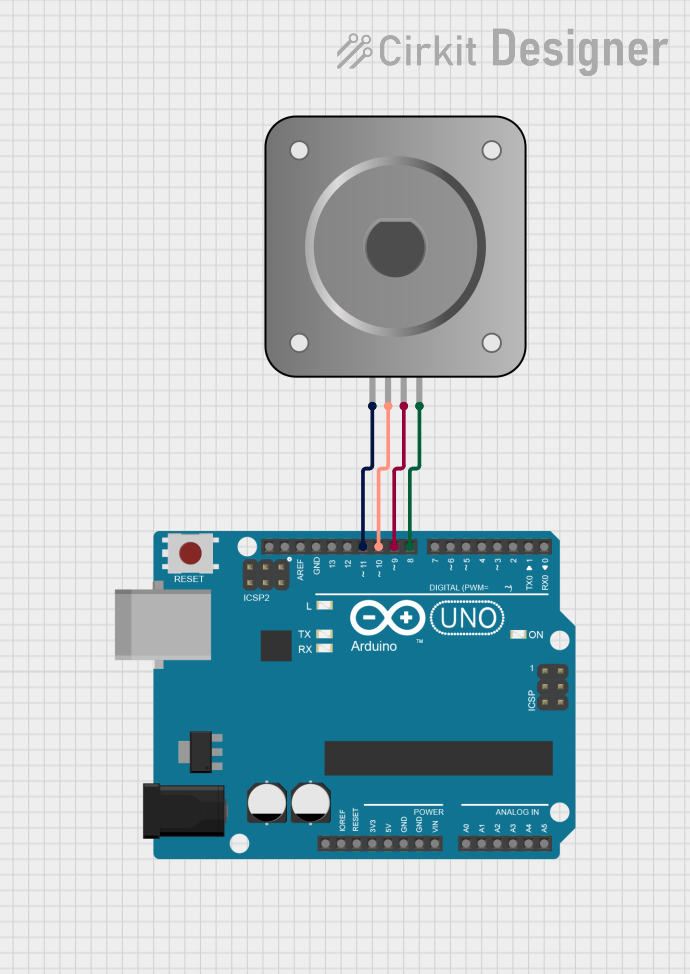
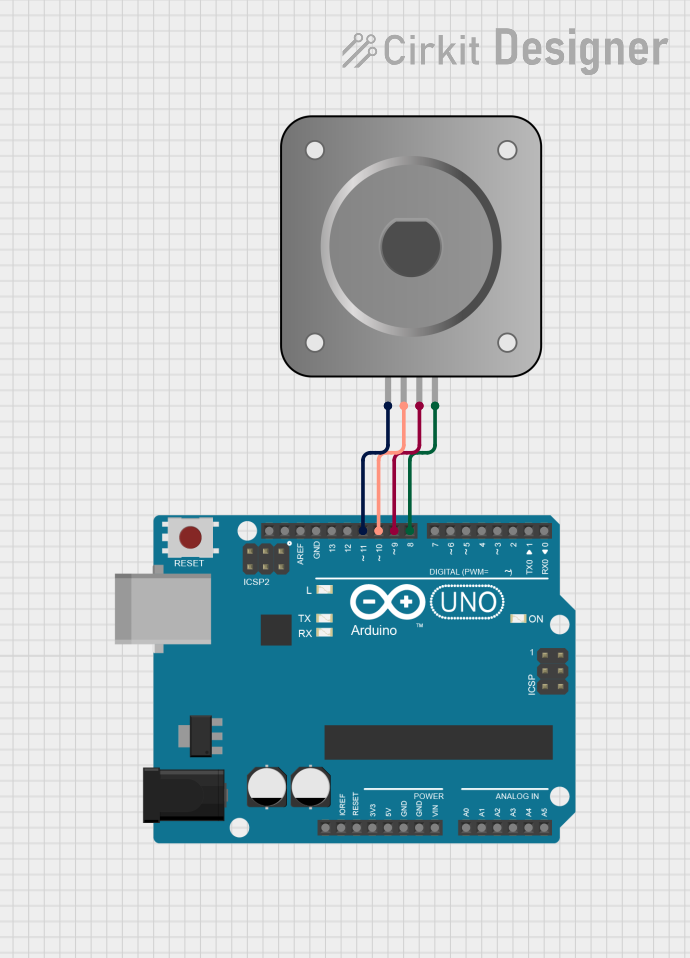
The NEMA 17 Bipolar Stepper Motor has four wires, corresponding to the two coils. The table below shows the typical wiring configuration:
Note: Wire colors may vary depending on the manufacturer. Use a multimeter to verify coil pairs by checking continuity.
Usage Instructions
Connecting the Motor
- Identify Coil Pairs: Use a multimeter to identify the two coil pairs (A-A' and B-B'). There will be continuity between the terminals of each coil.
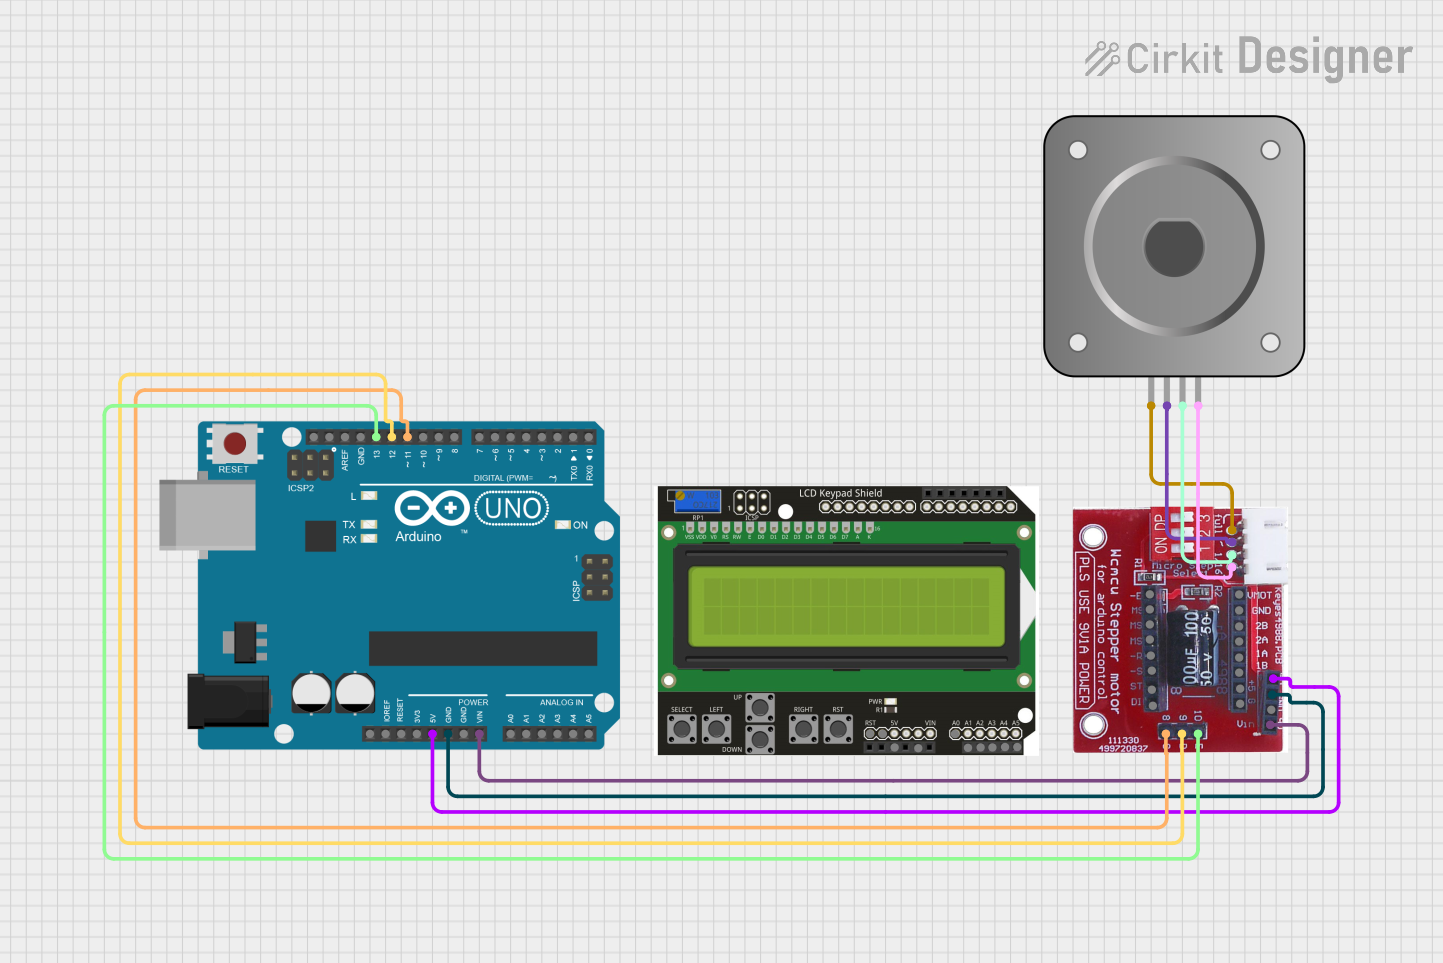
- Connect to a Driver: Use a stepper motor driver (e.g., A4988 or DRV8825) to control the motor. Connect the motor wires to the driver's output terminals as follows:
- Coil A (Red and Blue wires) to terminals A1 and A2.
- Coil B (Green and Black wires) to terminals B1 and B2.
- Power the Driver: Provide the appropriate voltage and current to the driver as specified in its datasheet. Ensure the power supply matches the motor's requirements.
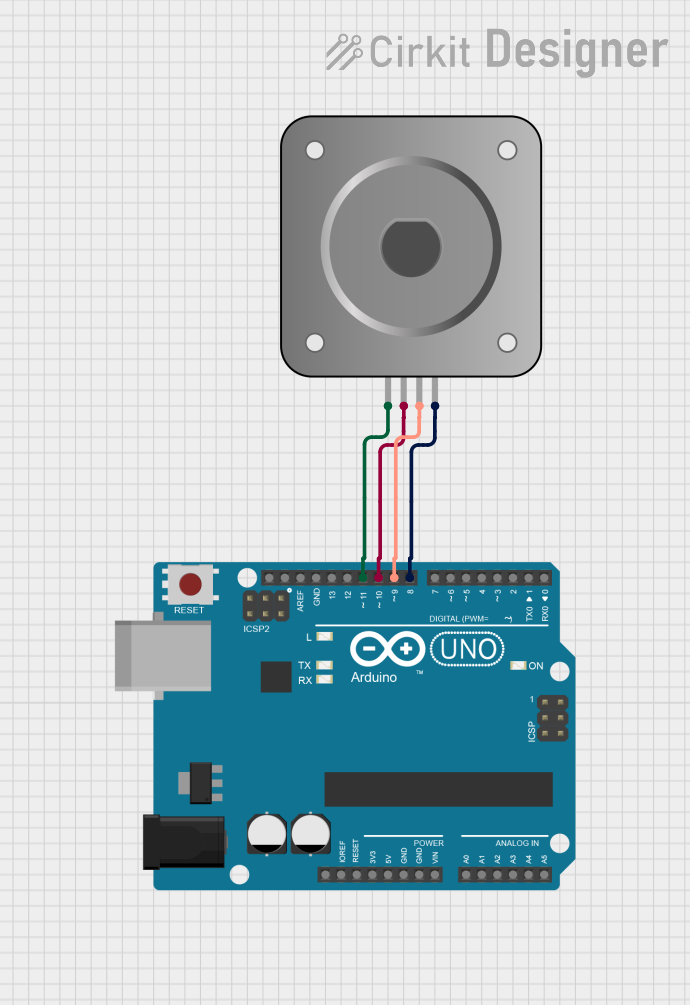
- Control Signals: Connect the driver's control pins (e.g., STEP and DIR) to a microcontroller (e.g., Arduino UNO) for precise control.
Arduino Example Code
Below is an example of how to control a NEMA 17 Bipolar Stepper Motor using an Arduino UNO and an A4988 driver:
// Define control pins for the A4988 driver
#define STEP_PIN 3  // Pin connected to the STEP input of the driver
#define DIR_PIN 4   // Pin connected to the DIR input of the driver

void setup() {
  pinMode(STEP_PIN, OUTPUT); // Set STEP pin as output
  pinMode(DIR_PIN, OUTPUT);  // Set DIR pin as output

  digitalWrite(DIR_PIN, HIGH); // Set direction (HIGH = clockwise, LOW = counterclockwise)
}

void loop() {
  // Generate step pulses to rotate the motor
  for (int i = 0; i < 200; i++) { // 200 steps = 1 full revolution (1.8° per step)
    digitalWrite(STEP_PIN, HIGH); // Set STEP pin HIGH
    delayMicroseconds(1000);      // Wait 1 ms (adjust for speed control)
    digitalWrite(STEP_PIN, LOW);  // Set STEP pin LOW
    delayMicroseconds(1000);      // Wait 1 ms
  }

  delay(1000); // Pause for 1 second before changing direction

  // Reverse direction
  digitalWrite(DIR_PIN, LOW); // Change direction to counterclockwise
  delay(1000); // Pause for 1 second
}
Best Practices
- Current Limiting: Adjust the current limit on the driver to match the motor's rated current. This prevents overheating and ensures optimal performance.
- Microstepping: Enable microstepping on the driver for smoother motion and reduced noise.
- Power Supply: Use a power supply with sufficient current capacity to handle the motor and driver requirements.
- Cooling: If the motor or driver gets too hot, consider adding a heatsink or fan for cooling.
Troubleshooting and FAQs
Common Issues
Motor Not Moving
- Cause: Incorrect wiring or insufficient power supply.
- Solution: Double-check the wiring and ensure the power supply meets the motor's requirements.
Motor Vibrates but Doesn't Rotate
- Cause: Incorrect coil connections or missing step pulses.
- Solution: Verify coil pairs and ensure the control signals are being sent correctly.
Overheating
- Cause: Current limit set too high on the driver.
- Solution: Adjust the current limit to match the motor's rated current.
Skipping Steps
- Cause: Excessive load or insufficient torque.
- Solution: Reduce the load or increase the current limit (within safe limits).
FAQs
Q: Can I run the NEMA 17 directly from an Arduino?
A: No, the Arduino cannot supply the required current. Always use a stepper motor driver.
Q: How do I identify the coil pairs if the wire colors are different?
A: Use a multimeter to check continuity. Terminals with continuity belong to the same coil.
Q: Can I use a higher voltage power supply than the motor's rated voltage?
A: Yes, but only if the driver supports it and the current limit is properly set.
Q: What is microstepping, and why is it useful?
A: Microstepping divides each full step into smaller steps, providing smoother motion and higher resolution.
By following this documentation, you can effectively use the NEMA 17 Bipolar Stepper Motor in your projects!

 Open Project in Cirkit Designer