Introduction
The A4988 Stepper Motor Driver (Red) is a compact and versatile module designed for precise control of stepper motors. It features adjustable current control, microstepping capabilities, and built-in thermal shutdown protection, making it an excellent choice for a wide range of applications. This driver is commonly used in 3D printers, CNC machines, robotics, and other projects requiring accurate motor control.
Common Applications and Use Cases
- 3D printers for precise movement of axes
- CNC machines for accurate cutting and engraving
- Robotics for controlling stepper motors in robotic arms or wheels
- Automated systems requiring stepper motor control, such as conveyor belts
Technical Specifications
The A4988 Stepper Motor Driver (Red) has the following key technical specifications:
Pin Configuration and Descriptions
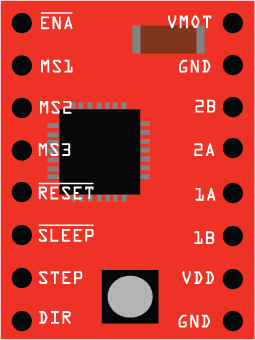
The A4988 module has 16 pins, which are described in the table below:
Usage Instructions
How to Use the A4988 in a Circuit
Power Connections:
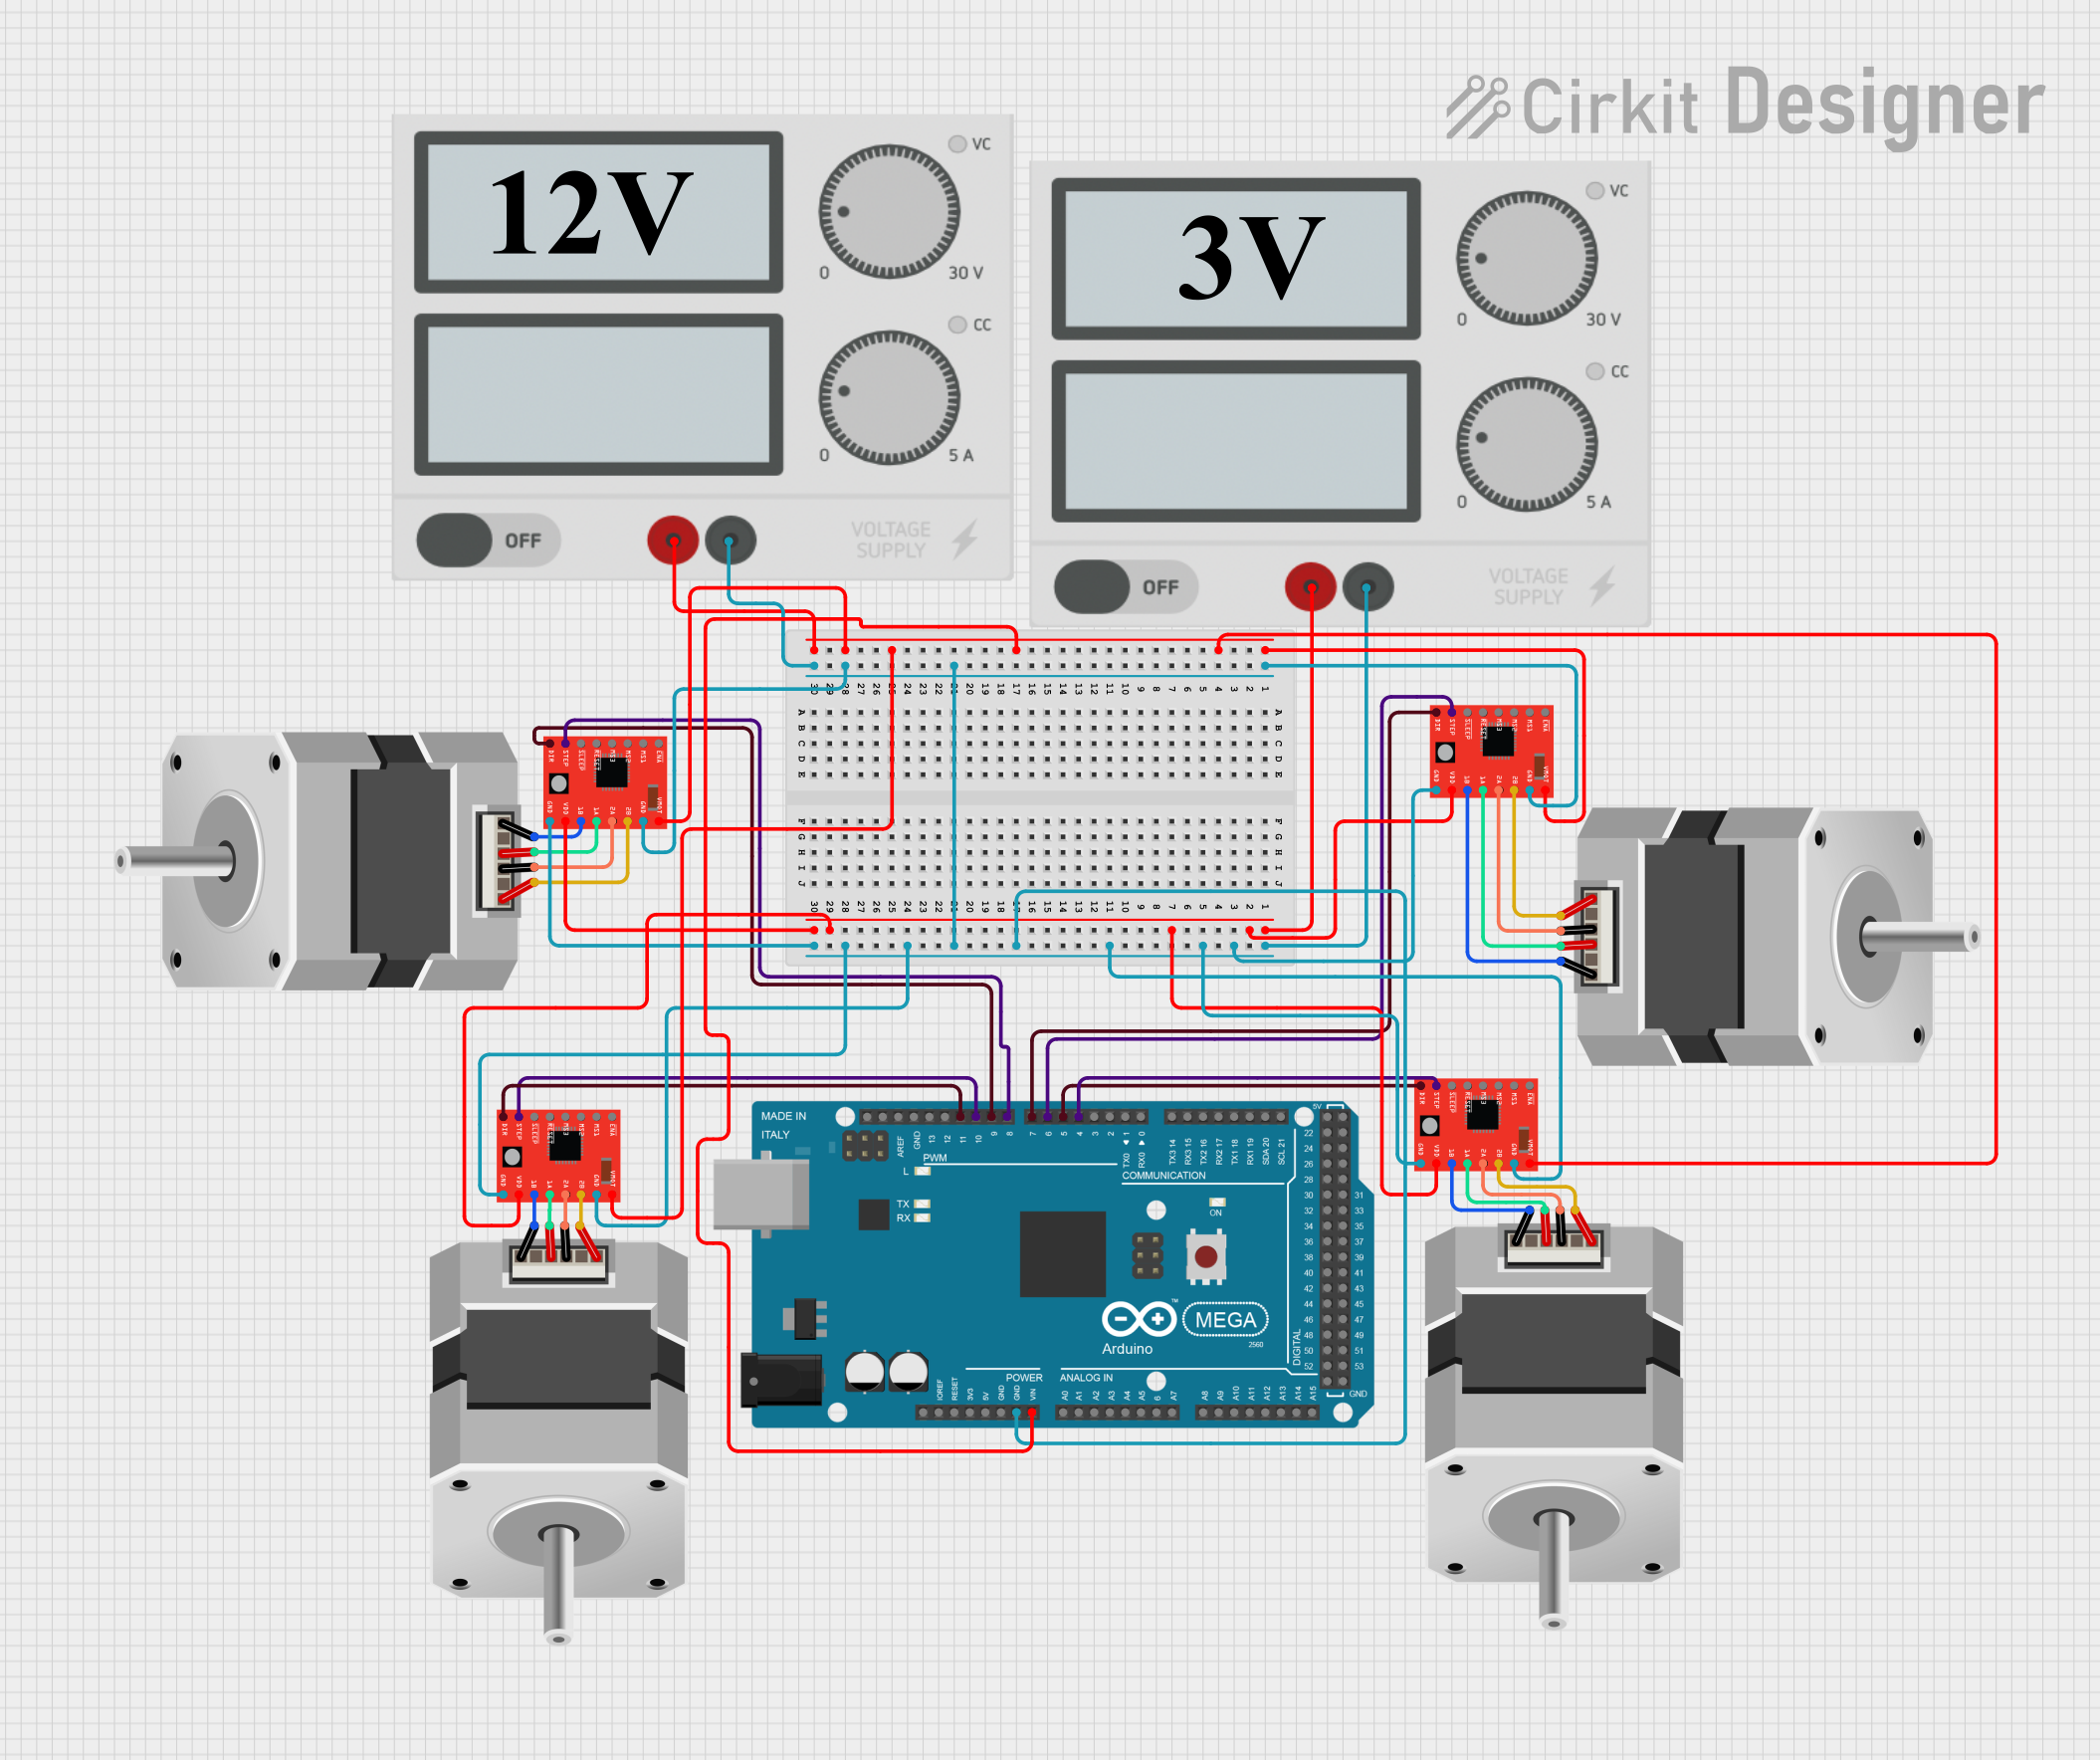
- Connect VMOT and GND to the motor power supply (8V to 35V).
- Connect VDD and GND to the logic power supply (3.3V or 5V).
- Ensure that the grounds of the motor and logic power supplies are connected.
Motor Connections:
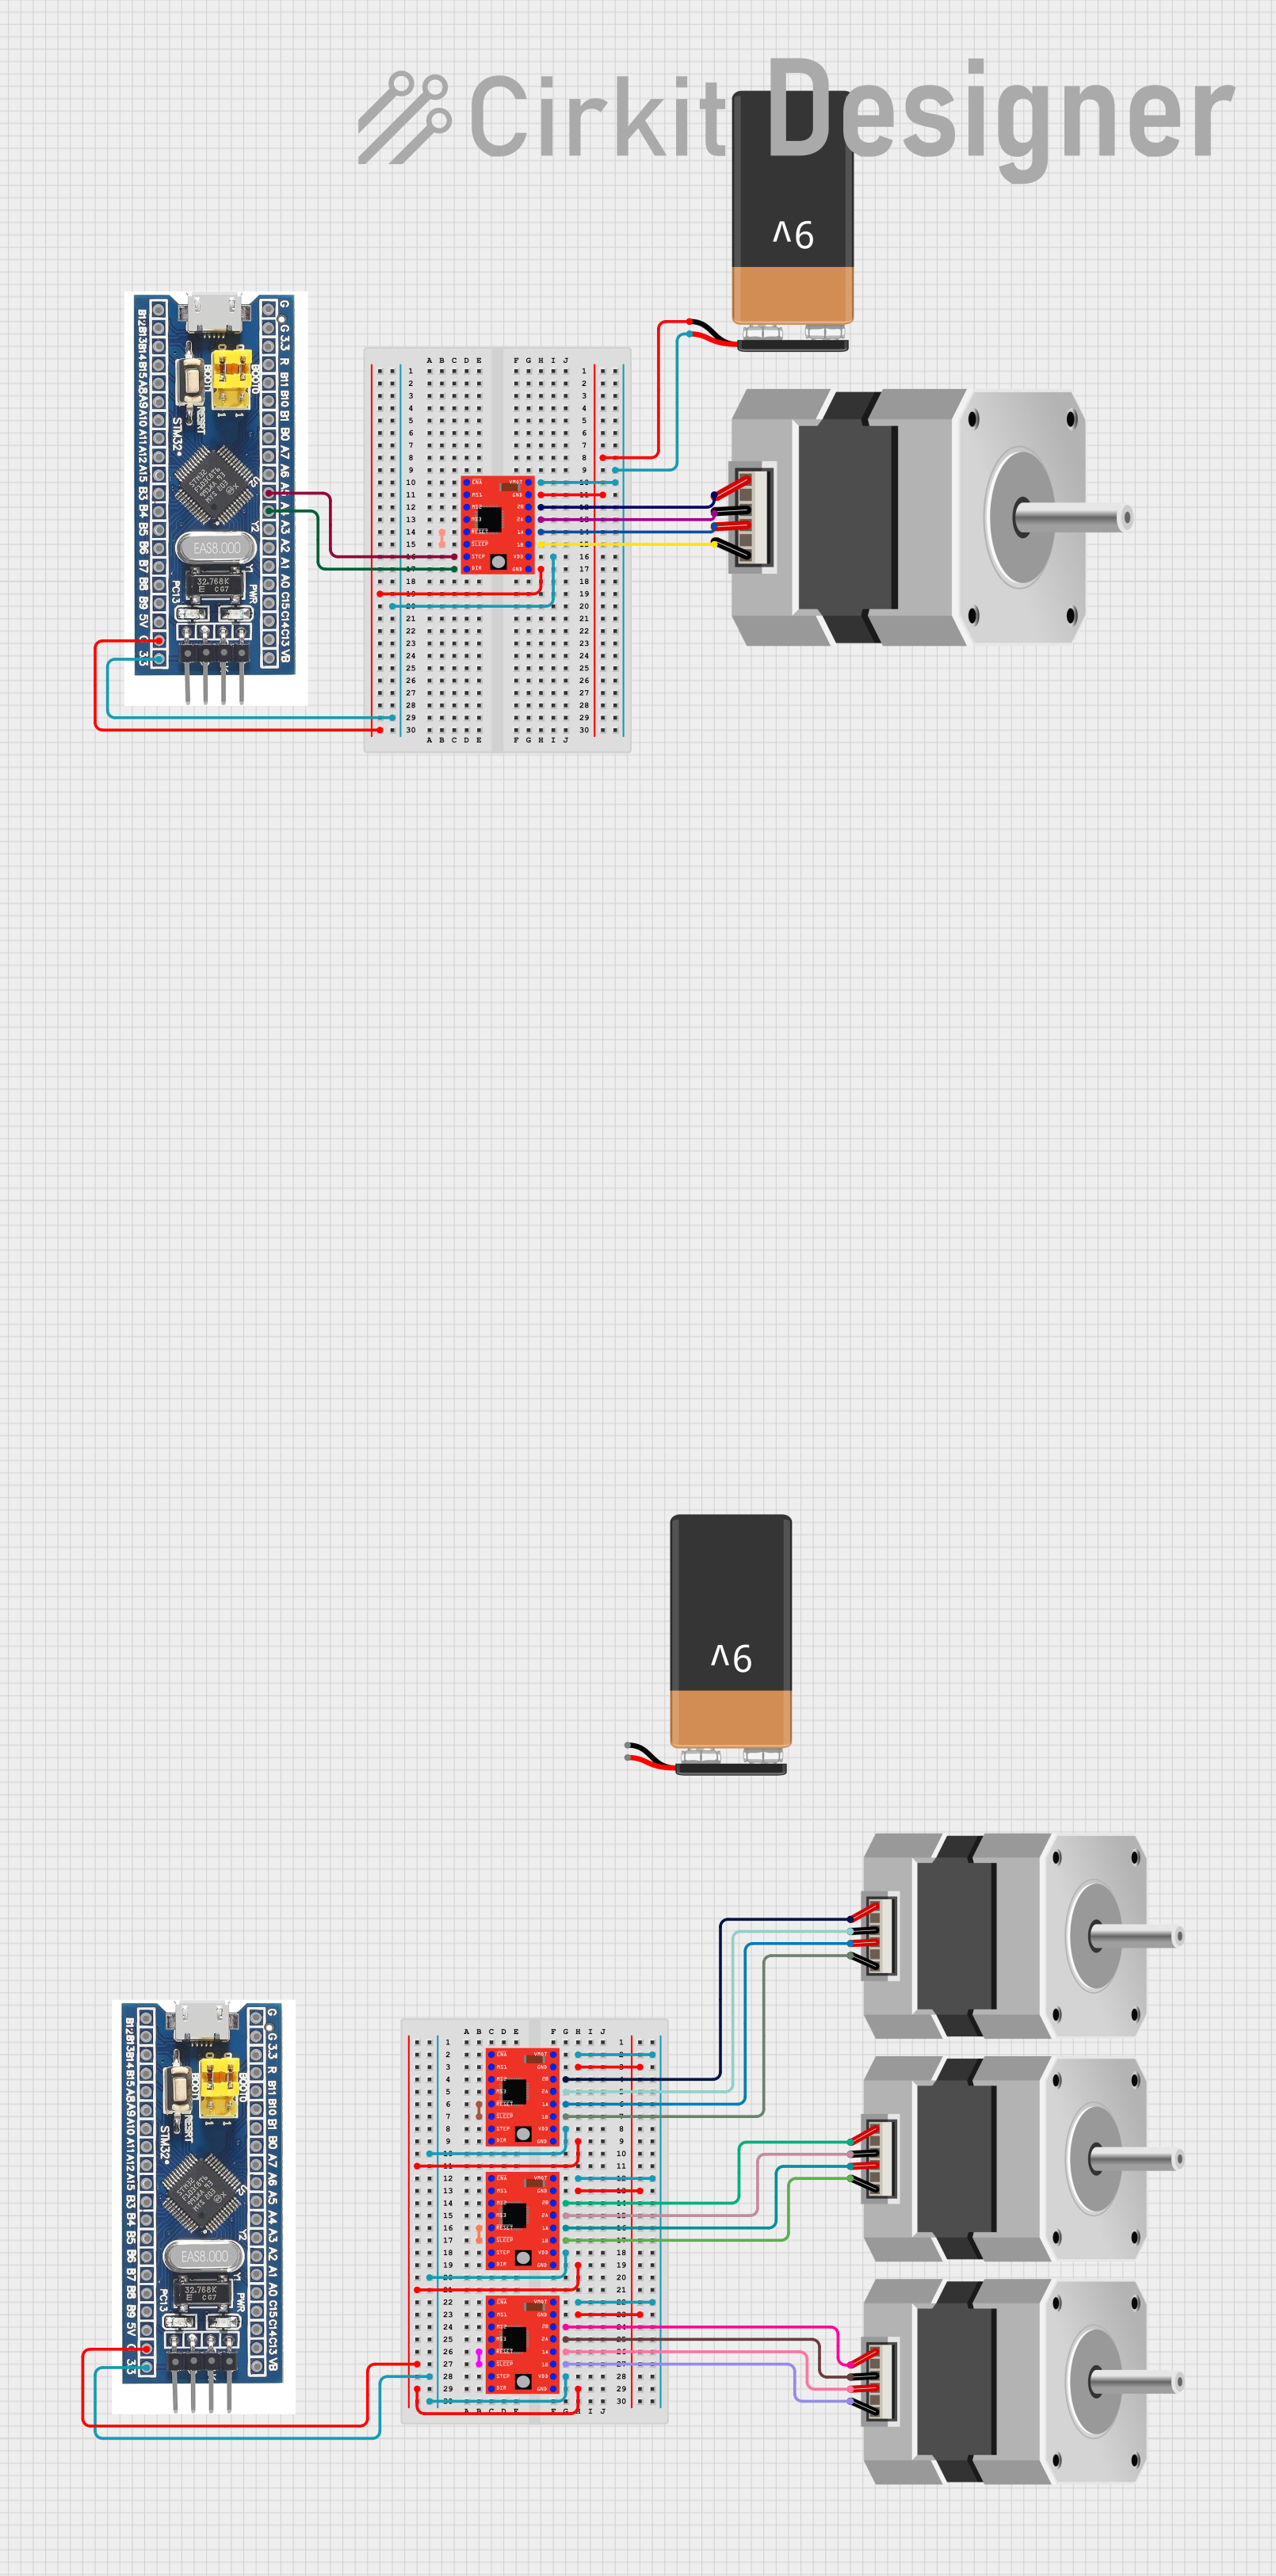
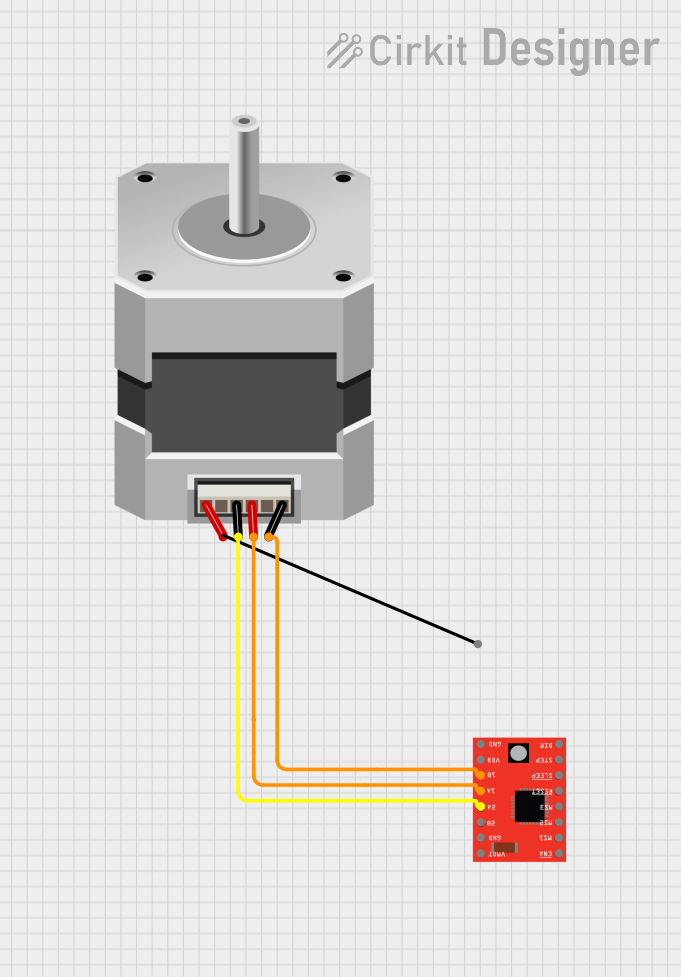
- Connect the stepper motor coils to the 1A, 1B, 2A, and 2B pins. Refer to your motor's datasheet to identify the coil pairs.
Control Signals:
- Connect the STEP pin to a microcontroller or pulse generator to control the motor steps.
- Use the DIR pin to set the motor's rotation direction (HIGH for one direction, LOW for the other).
- Optionally, connect the ENABLE pin to enable or disable the driver.
Microstepping Configuration:
- Use the MS1, MS2, and MS3 pins to set the microstepping mode. Refer to the table below:
- Adjusting Current Limit:
- Use the onboard potentiometer to set the current limit. This prevents the motor from drawing excessive current and overheating.
Important Considerations and Best Practices
- Always power off the system before connecting or disconnecting the stepper motor to avoid damaging the driver.
- Use a heat sink or active cooling if the driver operates near its maximum current rating.
- Ensure proper decoupling capacitors are placed near the VMOT and VDD pins to reduce noise and voltage spikes.
- Avoid exceeding the voltage and current ratings to prevent permanent damage to the driver.
Example Code for Arduino UNO
Below is an example code to control a stepper motor using the A4988 driver and an Arduino UNO:
// Define control pins for the A4988 driver
#define STEP_PIN 3  // Connect to the STEP pin of the A4988
#define DIR_PIN 4   // Connect to the DIR pin of the A4988

void setup() {
  pinMode(STEP_PIN, OUTPUT); // Set STEP pin as output
  pinMode(DIR_PIN, OUTPUT);  // Set DIR pin as output

  digitalWrite(DIR_PIN, HIGH); // Set initial direction (HIGH or LOW)
}

void loop() {
  // Generate a pulse to move the stepper motor one step
  digitalWrite(STEP_PIN, HIGH); // Set STEP pin HIGH
  delayMicroseconds(1000);      // Wait for 1 millisecond
  digitalWrite(STEP_PIN, LOW);  // Set STEP pin LOW
  delayMicroseconds(1000);      // Wait for 1 millisecond
}
Troubleshooting and FAQs
Common Issues and Solutions
Motor Not Moving:
- Cause: Incorrect wiring or insufficient power supply.
- Solution: Double-check all connections and ensure the power supply meets the voltage and current requirements.
Driver Overheating:
- Cause: Current limit set too high or insufficient cooling.
- Solution: Adjust the current limit using the potentiometer and add a heat sink or fan.
Motor Vibrates but Does Not Rotate:
- Cause: Incorrect coil connections or microstepping configuration.
- Solution: Verify the coil pairs and ensure the microstepping mode is set correctly.
Motor Moves in the Wrong Direction:
- Cause: DIR pin logic level is incorrect.
- Solution: Change the DIR pin state (HIGH or LOW) to reverse the direction.
FAQs
Q: Can I use the A4988 with a 12V power supply?
- A: Yes, the A4988 supports motor power supply voltages between 8V and 35V. Ensure your motor is compatible with 12V.
Q: How do I know the correct current limit for my motor?
- A: Refer to your motor's datasheet for the rated current per phase. Use the formula
VREF = I * 8 * R (where R is the sense resistor value, typically 0.1Ω) to set the current limit.
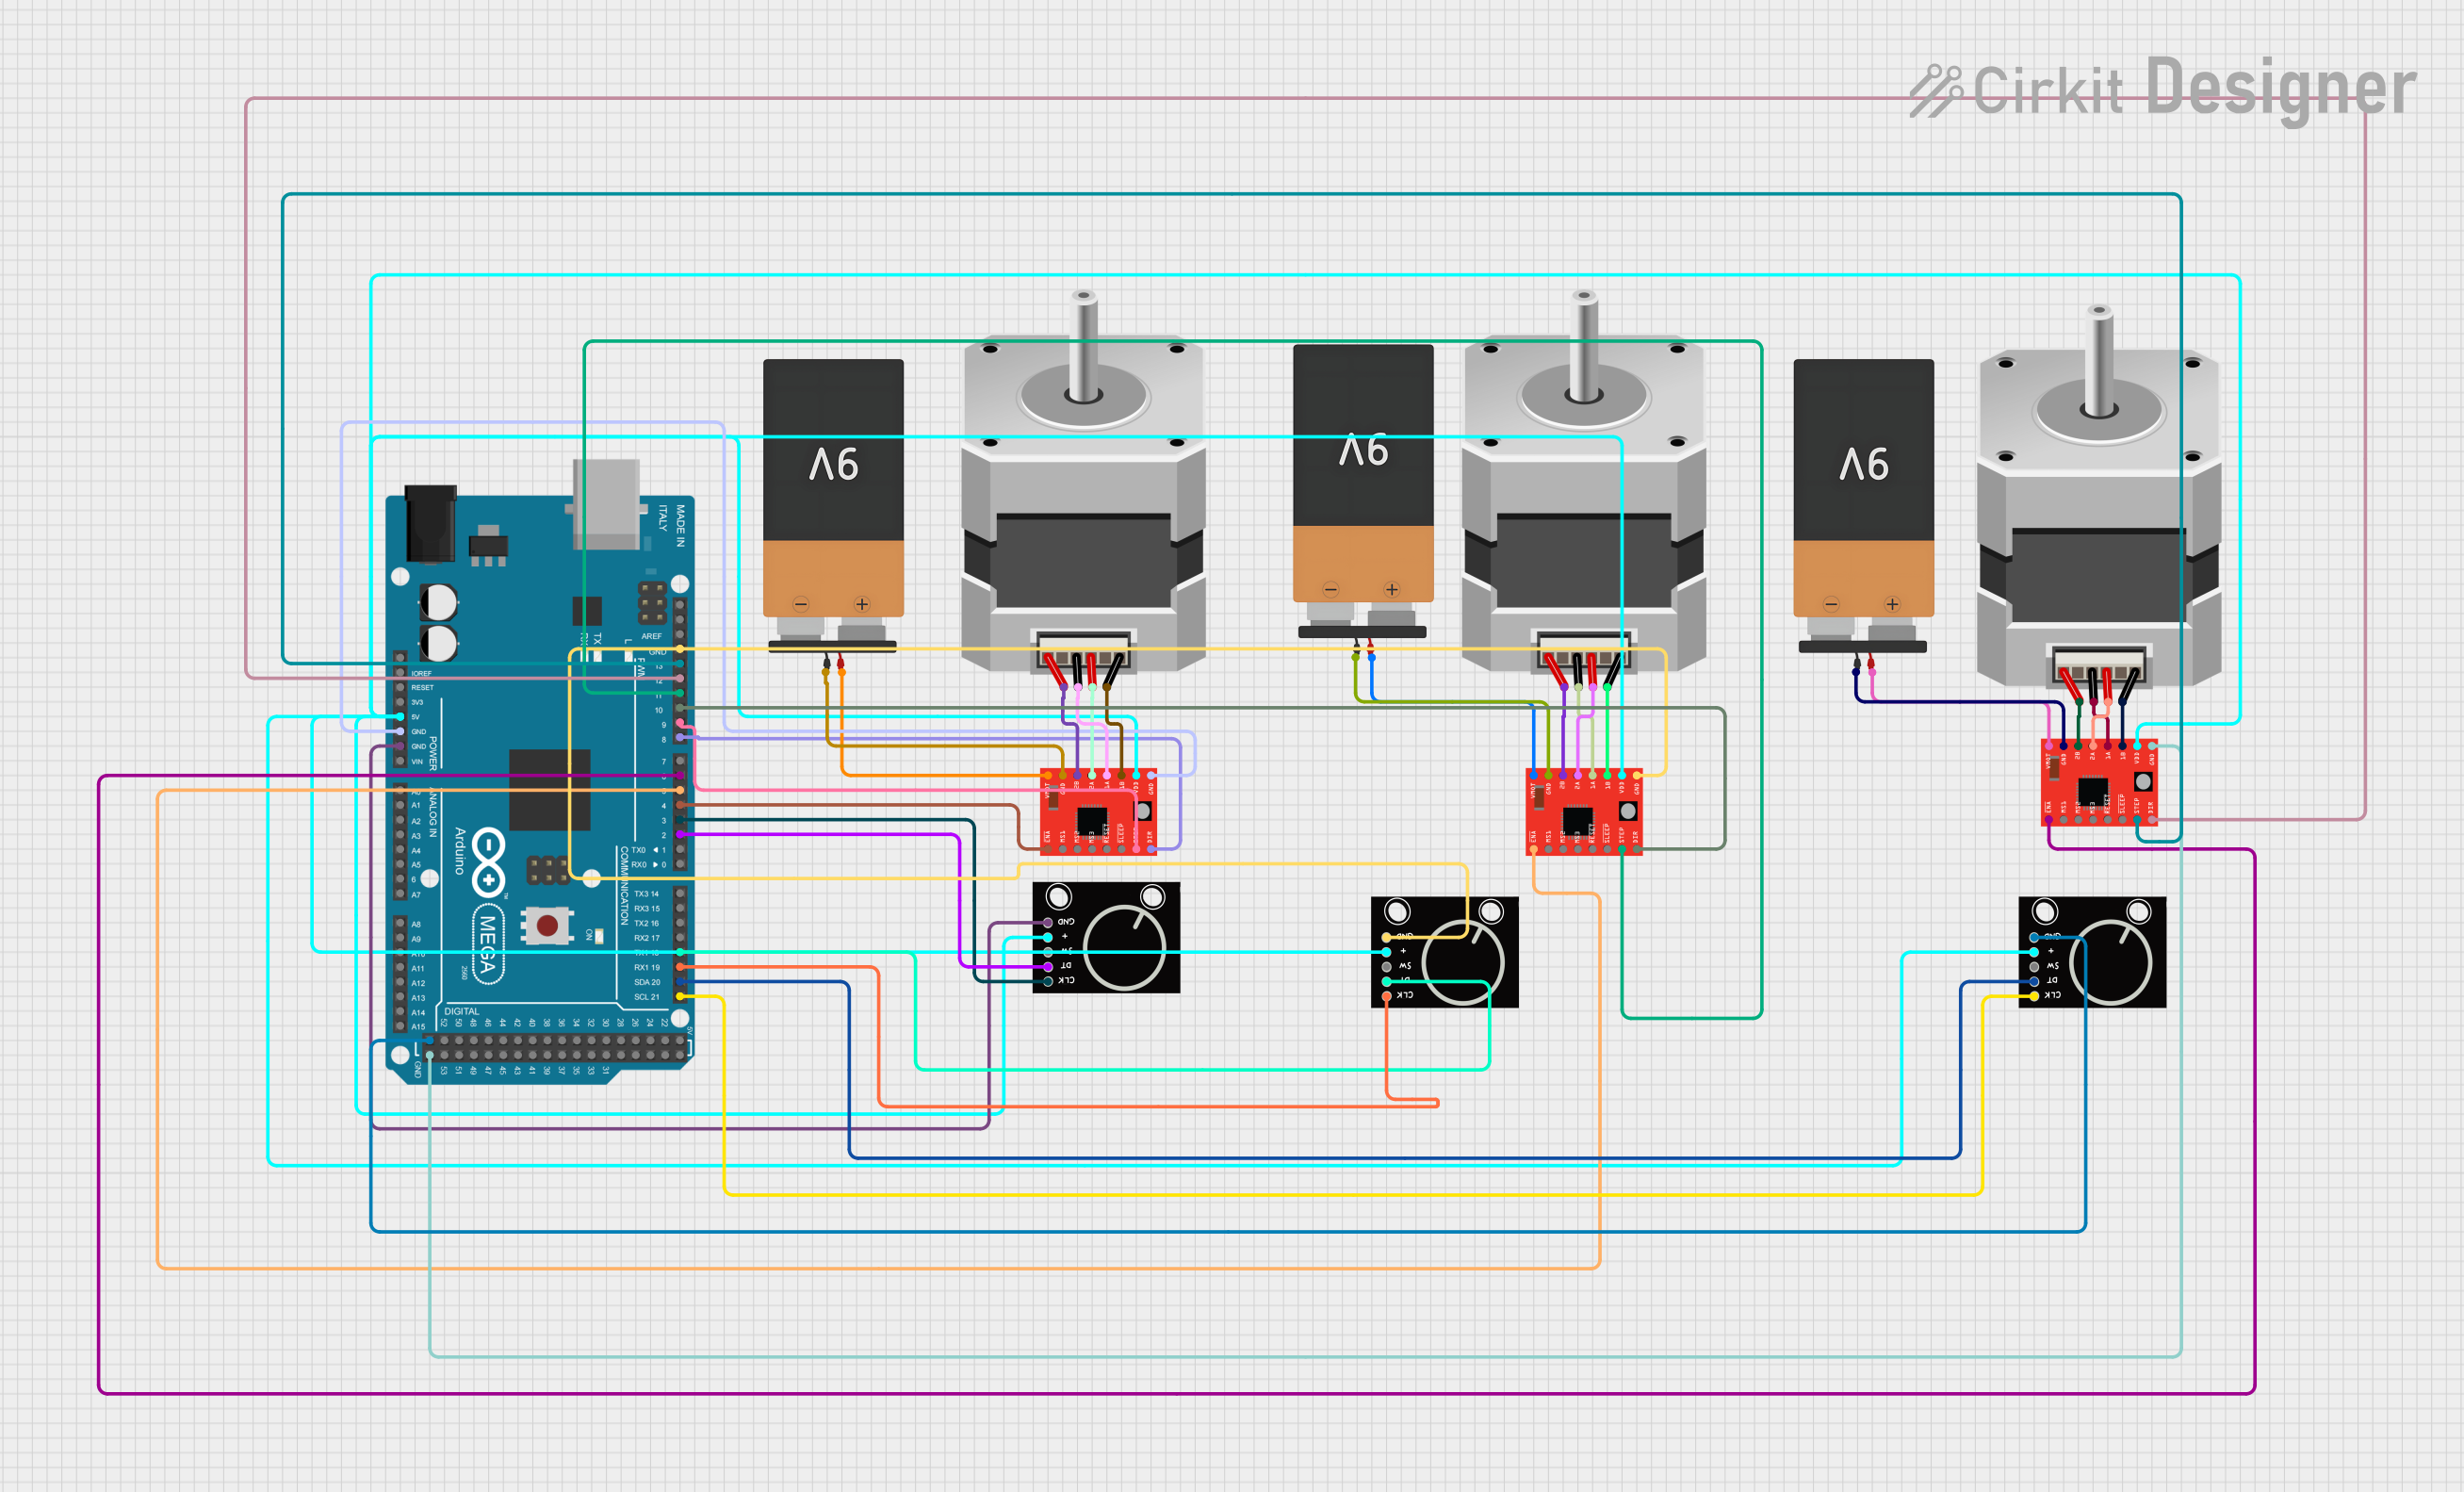
Q: Can I control multiple stepper motors with one Arduino?
- A: Yes, you can control multiple A4988 drivers with an Arduino by assigning separate STEP and DIR pins for each driver.
By following this documentation, you can effectively use the A4988 Stepper Motor Driver (Red) in your projects.

 Open Project in Cirkit Designer