The TMC2226 is a high-performance stepper motor driver manufactured by Trinamic Motion Control (TMC). It is designed to drive bipolar stepper motors in various applications, including 3D printers, CNC machines, and robotics. The TMC2226 offers advanced features such as stealthChop2 for silent operation and spreadCycle for high-speed motion, making it a popular choice for precision motion control.
Explore Projects Built with TMC2226 Stepper Driver
Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
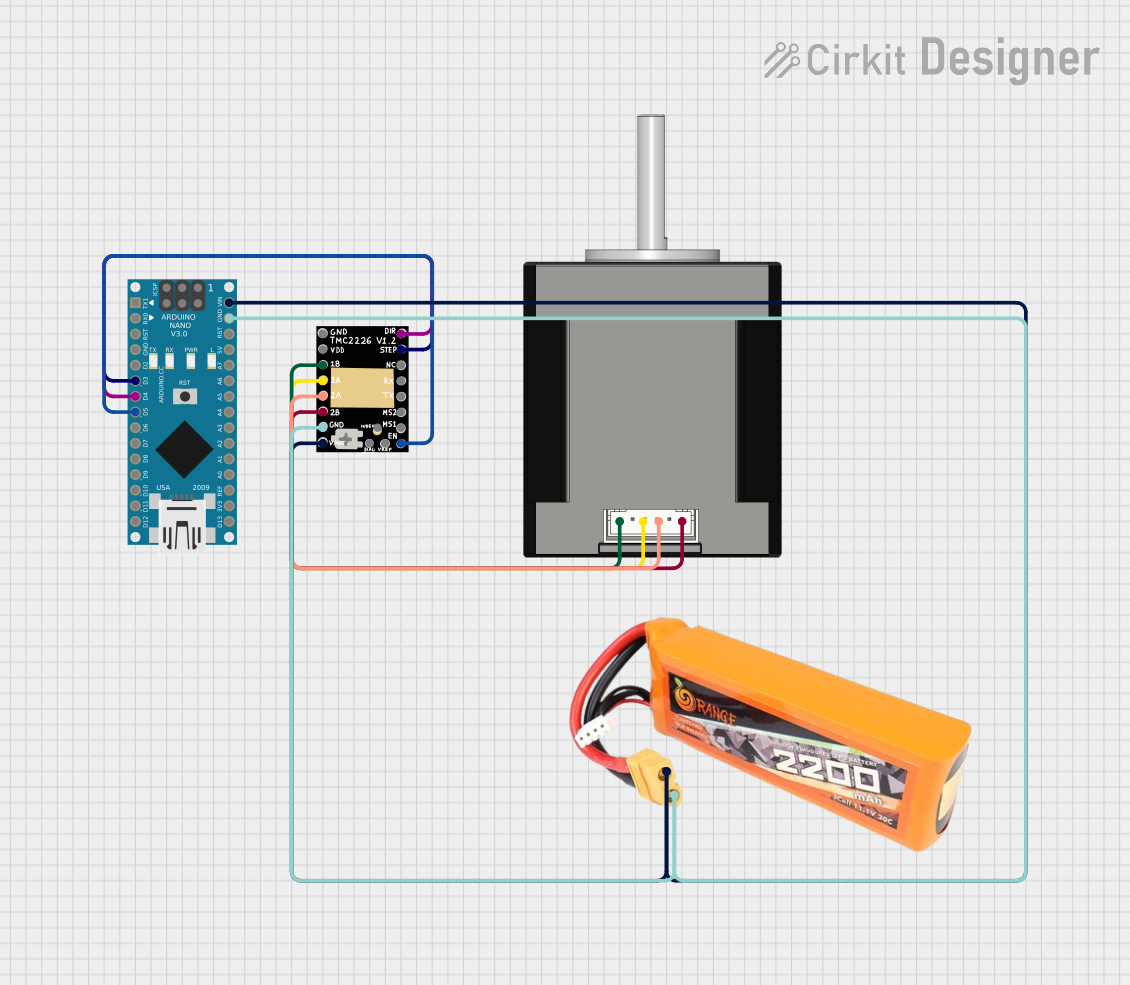
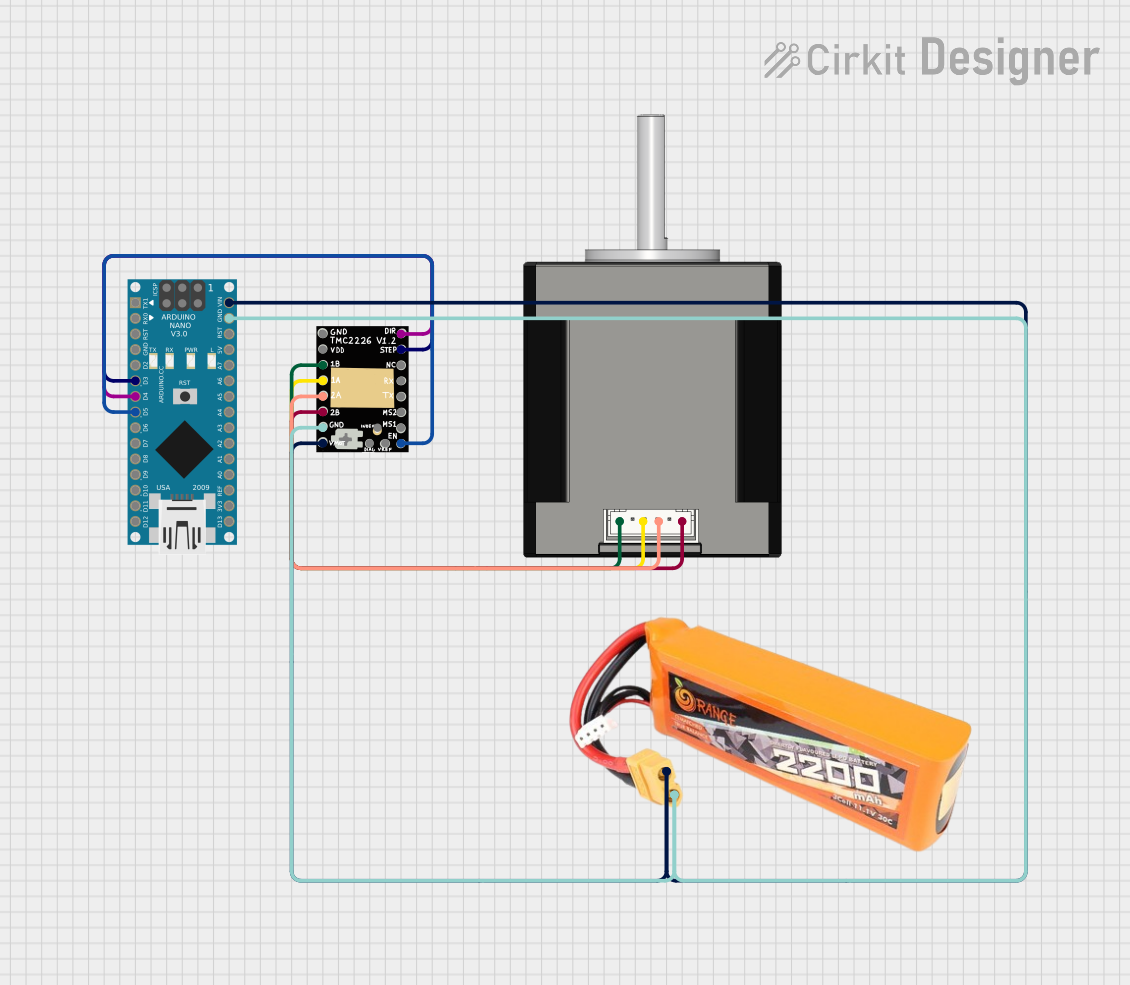
This circuit is designed to control a Nema 17 stepper motor using an Arduino Nano and a TMC2226 stepper driver. The Arduino Nano is interfaced with the TMC2226 driver to send step, direction, and enable signals, allowing for precise control of the motor's movements. Power is supplied to the motor driver and the Arduino through a connection to a lipo battery, ensuring that the motor receives the necessary voltage for operation.
This circuit controls a Nema 17 stepper motor using an Arduino Nano and a TMC2226 stepper driver, powered by a LiPo battery. The Arduino Nano sends step and direction signals to the TMC2226 driver to control the motor's movement. The setup is designed for applications requiring precise motor control, such as robotics or CNC machines.
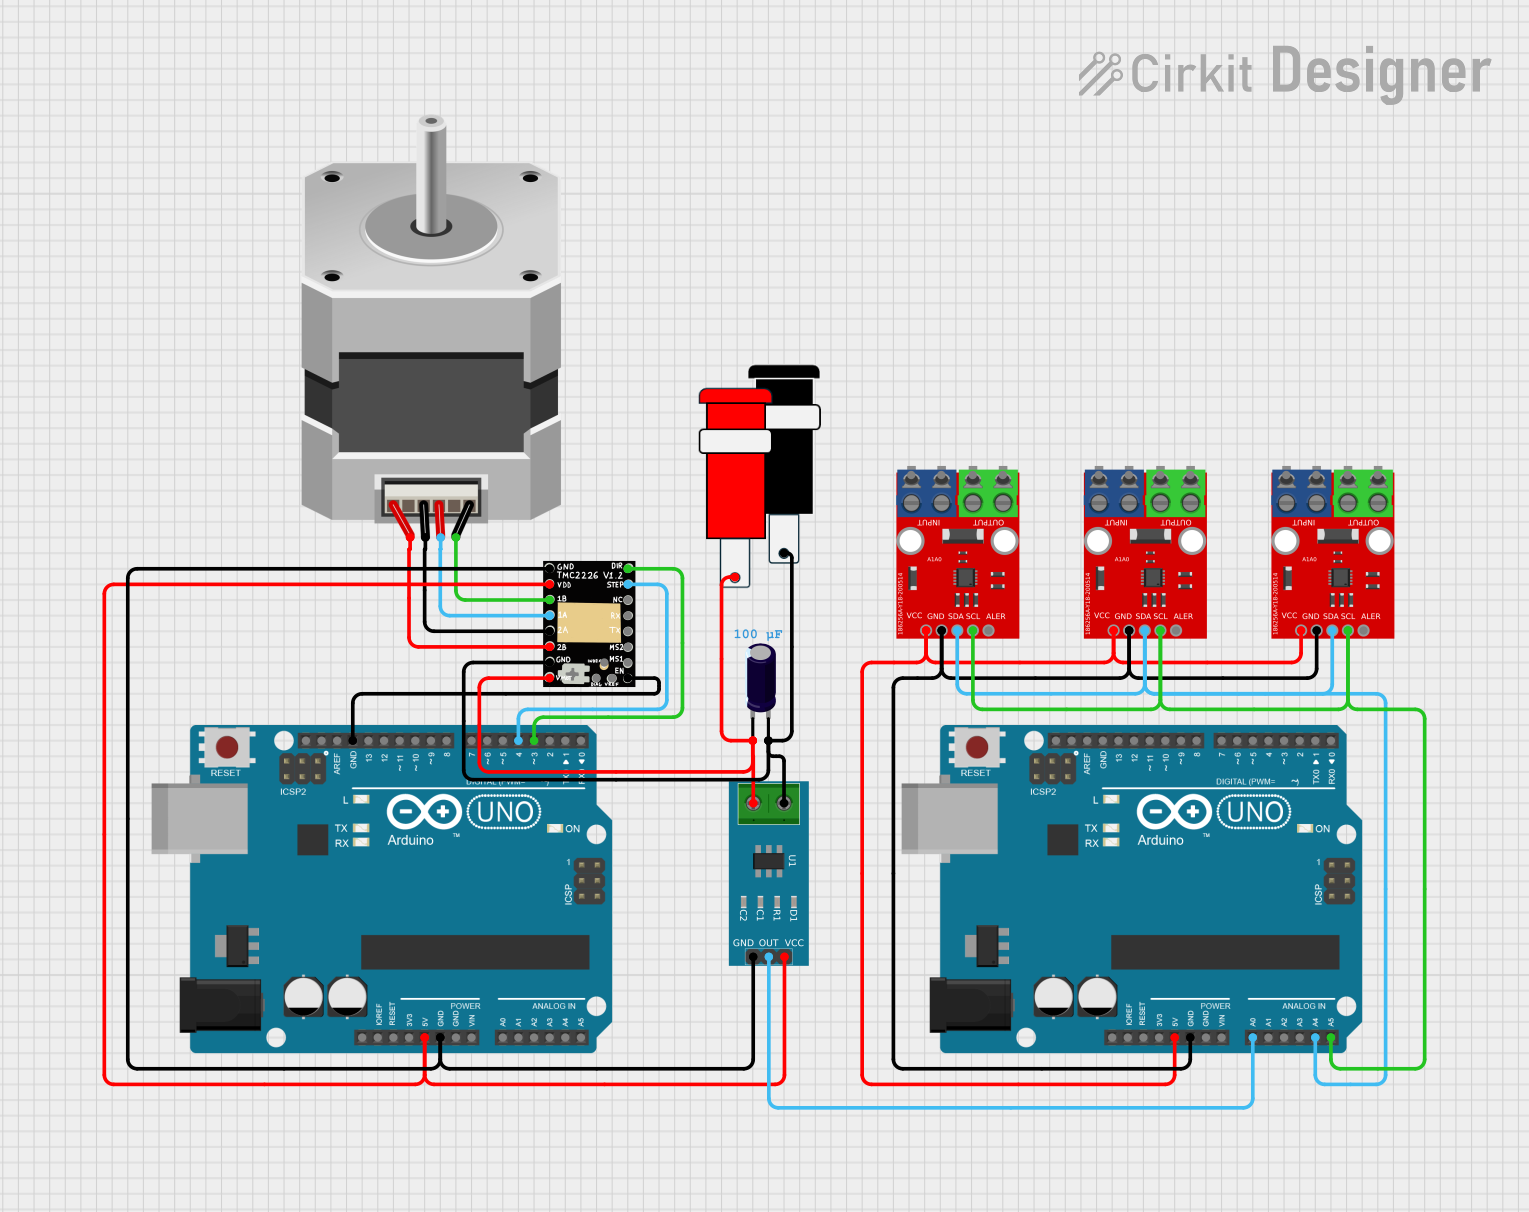
This circuit controls a bipolar stepper motor using a TMC2226 stepper driver, which is managed by an Arduino UNO. The circuit also includes a current sensor to monitor the motor's current, and multiple Nazarbayev University components are interconnected for additional functionality. Power is supplied through a 5V connector, and an electrolytic capacitor is used for voltage stabilization.
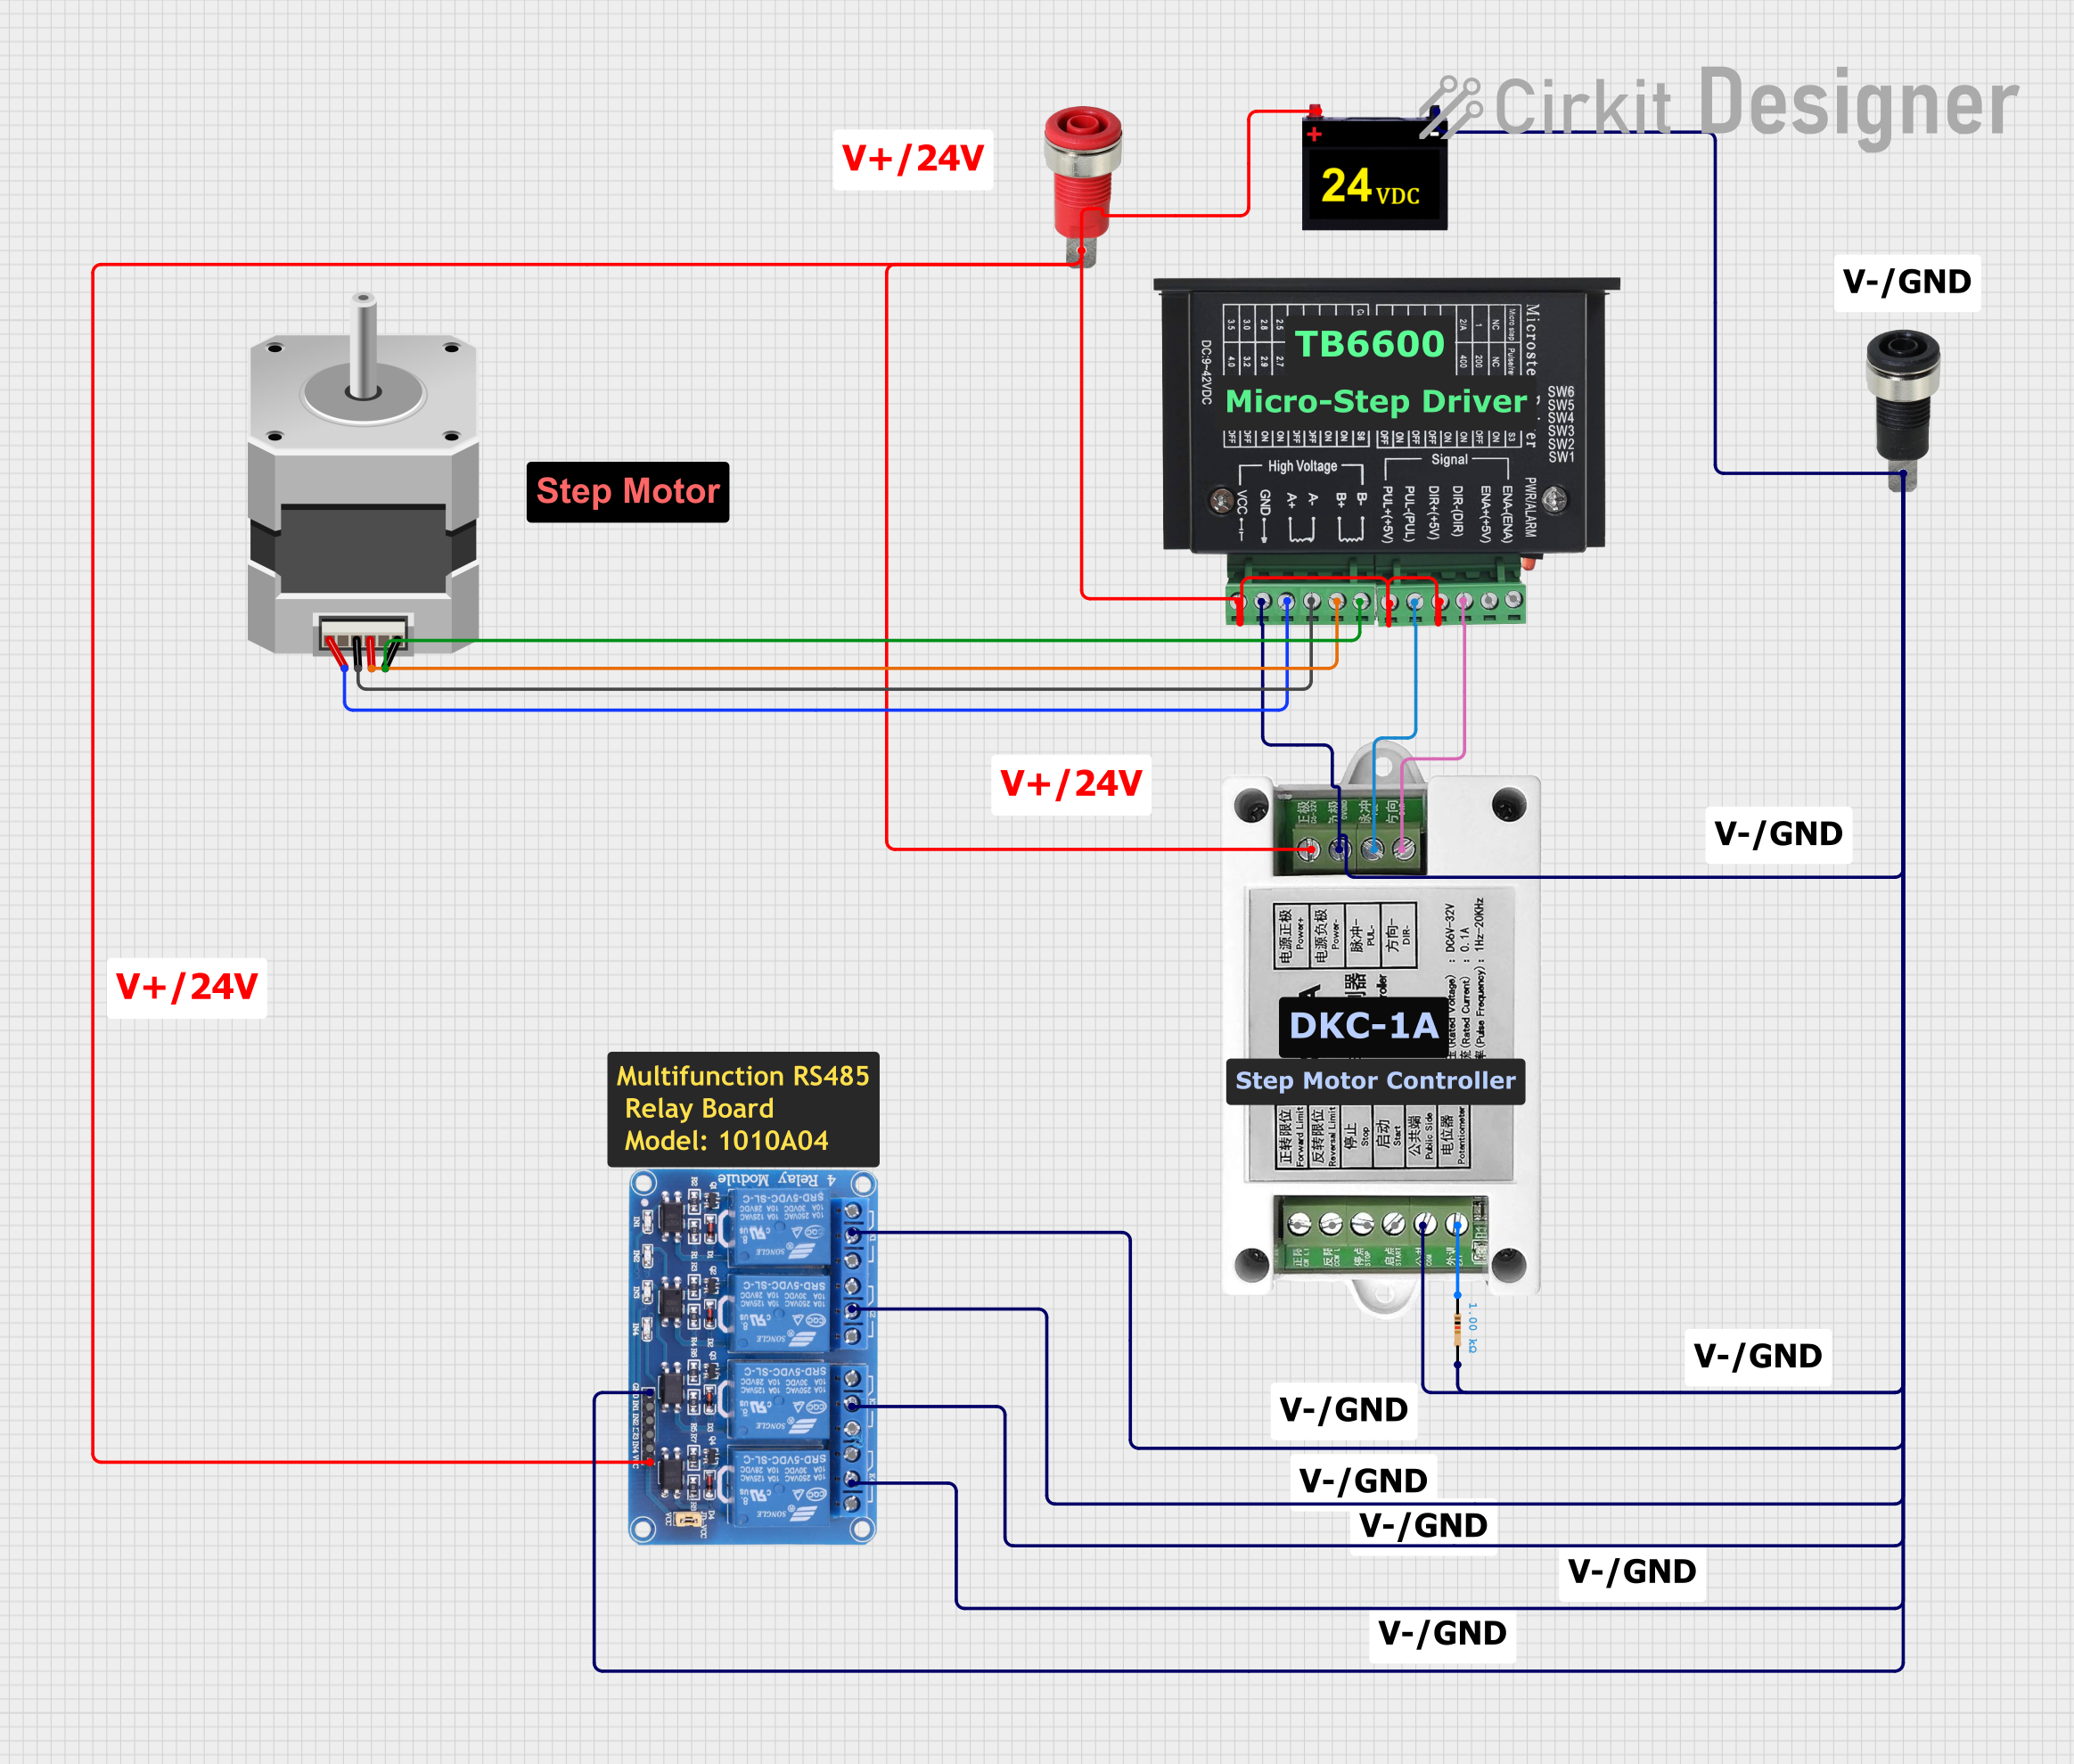
This circuit controls a bipolar stepper motor using a tb6600 micro stepping motor driver and a DKC-1A stepper motor controller. The system is powered by a 24VDC power supply and includes a relay module for additional control functionalities.
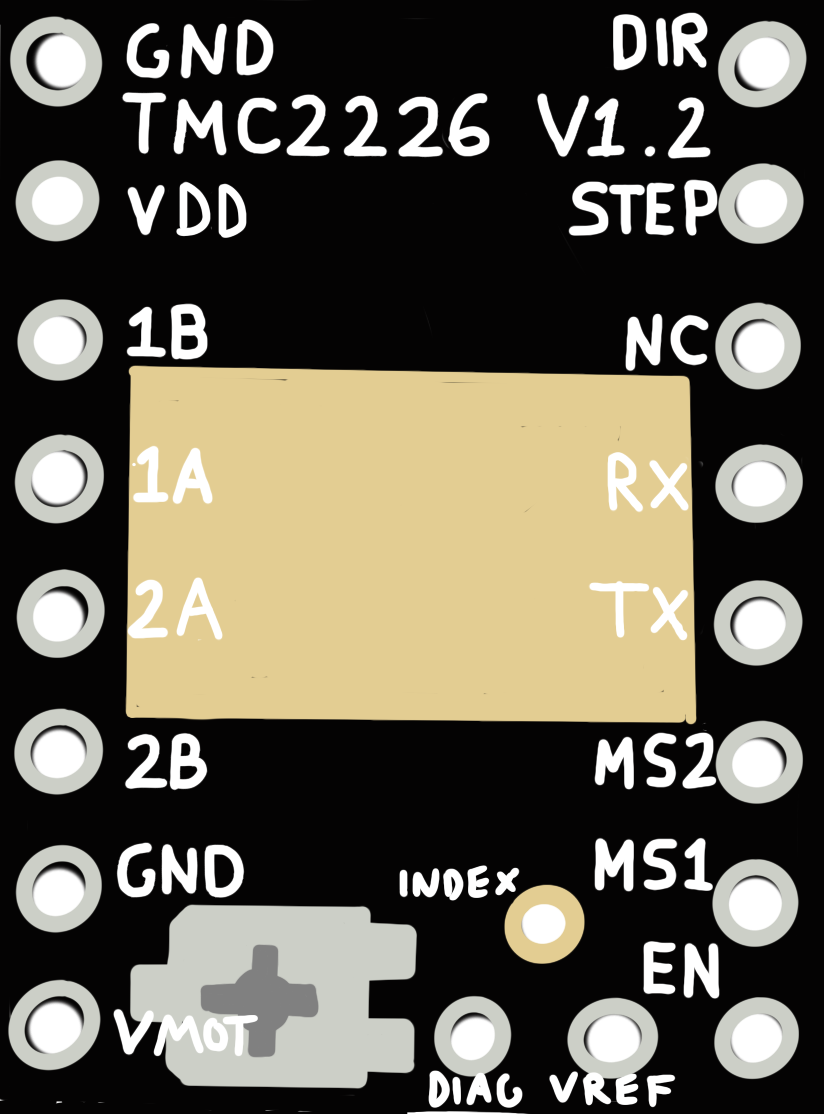
Power Supply: Connect the motor supply voltage (VM) to a suitable power source between 4.75V and 29V, and connect the logic voltage (VIO) to a 3.3V or 5V source.
Motor Connection: Connect the stepper motor wires to the motor outputs on the TMC2226.
Control Signals: Connect the STEP and DIR pins to the respective outputs on your microcontroller or motion controller.
Microstepping Configuration: Set the MS1 and MS2 pins according to the desired microstepping resolution.
Enable: The EN pin must be pulled low to enable the motor outputs.
Important Considerations and Best Practices
Ensure that the power supply voltage does not exceed the maximum rating of 29V.
Use proper decoupling capacitors close to the VM and VIO pins to minimize voltage spikes.
Configure the current limit according to the motor specifications to prevent damage.
Heat sinking may be necessary for high-current applications.
For silent operation, enable stealthChop2 mode via UART configuration.
Troubleshooting and FAQs
Common Issues Users Might Face
Motor not moving: Check the power supply, motor connections, and that the EN pin is active.
Overheating: Ensure proper current settings and heat sinking.
Noise during operation: Adjust stealthChop2 and spreadCycle settings for optimal performance.
Solutions and Tips for Troubleshooting
Verify all connections and solder joints.
Use a multimeter to check the supply voltage at the VM and VIO pins.
Ensure that the microcontroller is sending the correct step and direction signals.
Consult the TMC2226 datasheet for detailed configuration options.
FAQs
Q: Can I control the TMC2226 using an Arduino UNO?
A: Yes, the TMC2226 can be controlled with an Arduino UNO using digital I/O pins for STEP and DIR signals.
Q: What is the maximum current the TMC2226 can handle?
A: The TMC2226 can handle up to 2.0A RMS per phase without additional cooling.
Q: How do I enable UART mode for advanced configurations?
A: UART mode can be enabled by connecting the UART pin to a serial interface on your controller and configuring the driver through software.
Example Code for Arduino UNO
#include <TMCStepper.h>

#define EN_PIN           8  // Enable
#define DIR_PIN          5  // Direction
#define STEP_PIN         6  // Step
#define SERIAL_PORT Serial1 // TMC2226 Serial port
#define DRIVER_ADDRESS 0b00 // TMC2226 Driver address according to MS1 and MS2

TMC2208Stepper driver(&SERIAL_PORT, DRIVER_ADDRESS);

void setup() {
  pinMode(EN_PIN, OUTPUT);
  pinMode(DIR_PIN, OUTPUT);
  pinMode(STEP_PIN, OUTPUT);
  digitalWrite(EN_PIN, LOW); // Enable driver in active low

  SERIAL_PORT.begin(115200); // Initialize serial port for driver communication
  driver.begin();            // Initialize driver
  driver.rms_current(1000);  // Set RMS current
  driver.microsteps(16);     // Set microsteps to 1/16th
  driver.en_spreadCycle(false); // Enable stealthChop for silent operation
}

void loop() {
  digitalWrite(DIR_PIN, HIGH); // Set direction
  for (int i = 0; i < 200; i++) {
    digitalWrite(STEP_PIN, HIGH);
    delayMicroseconds(100);
    digitalWrite(STEP_PIN, LOW);
    delayMicroseconds(100);
  }
  delay(1000); // Wait 1 second
}
Note: The above code is a basic example to get started with the TMC2226 using an Arduino UNO. It assumes the use of the TMCStepper library for simplified control of Trinamic drivers. Adjust the current settings and microstepping according to your specific motor's requirements. Always refer to the TMC2226 datasheet for detailed information on configuring and using the driver.

 Open Project in Cirkit Designer