A DC motor is an electromechanical device that converts direct current (DC) electrical energy into mechanical energy. It operates on the principle of electromagnetic induction, where a magnetic field interacts with a current-carrying conductor to produce rotational motion. DC motors are widely used in various applications due to their simplicity, reliability, and ease of control.
Explore Projects Built with DC motor 2
Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
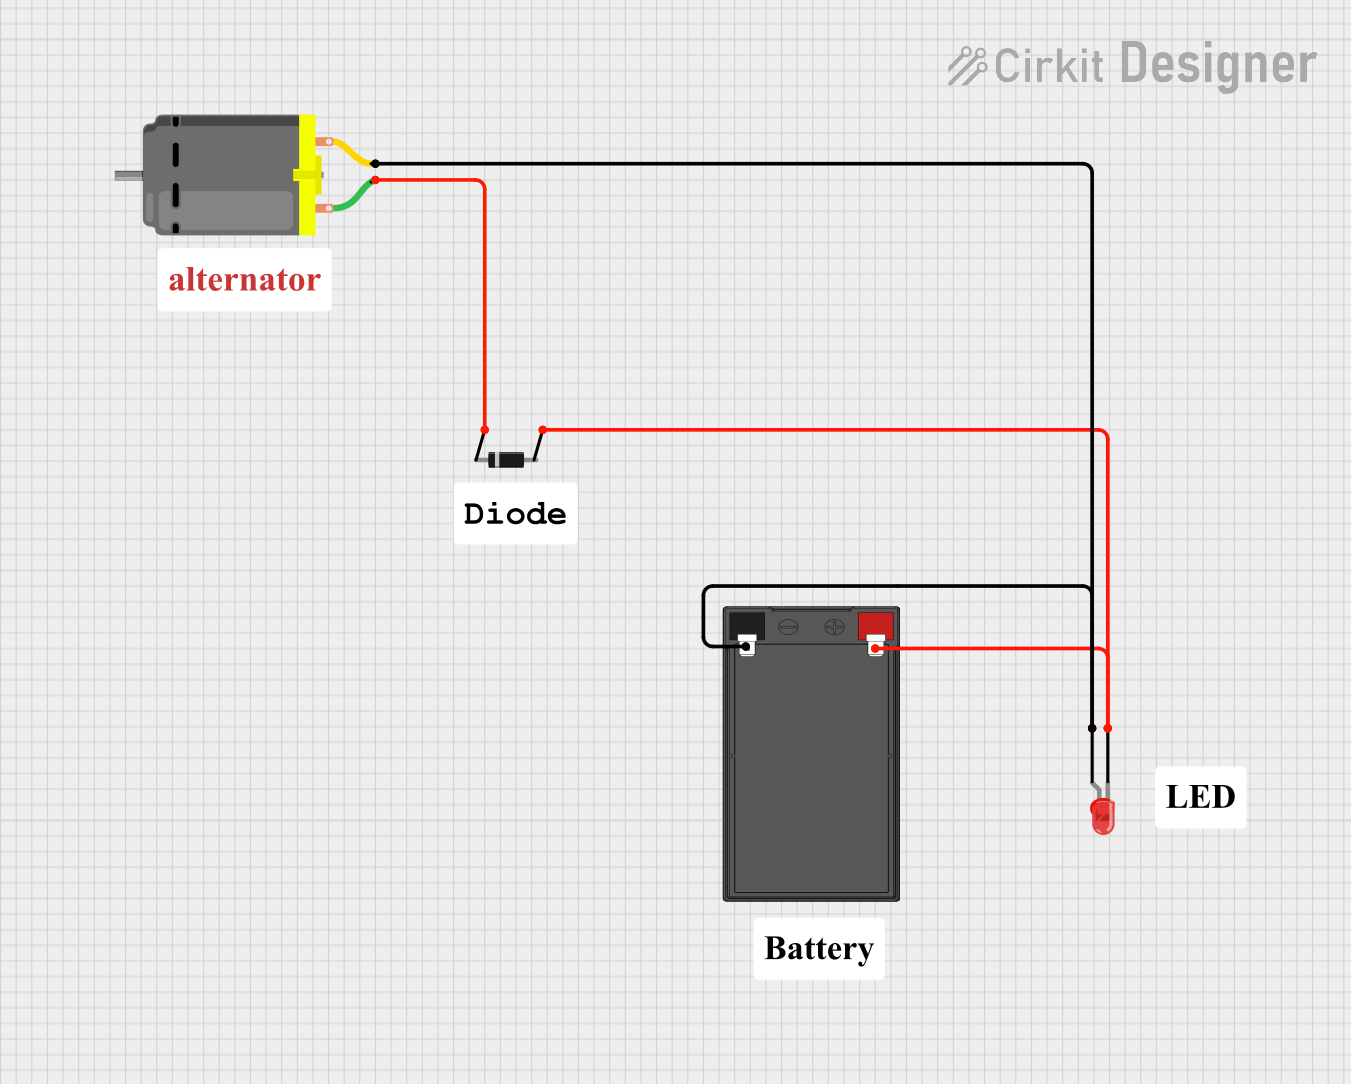
This circuit consists of a DC motor powered by a 12V battery, with a diode for protection against reverse voltage and an LED indicator. The LED is connected in parallel with the motor to indicate when the motor is powered.
This circuit controls a DC motor using an ESP32 microcontroller and a 2-channel motor driver. The ESP32 outputs a PWM signal and a direction control to the motor driver, which in turn drives the motor with power from a 12v battery. The code provided sets up the ESP32 to output a PWM signal at a fixed duty cycle and a high direction signal, causing the motor to spin in one direction at a constant speed.
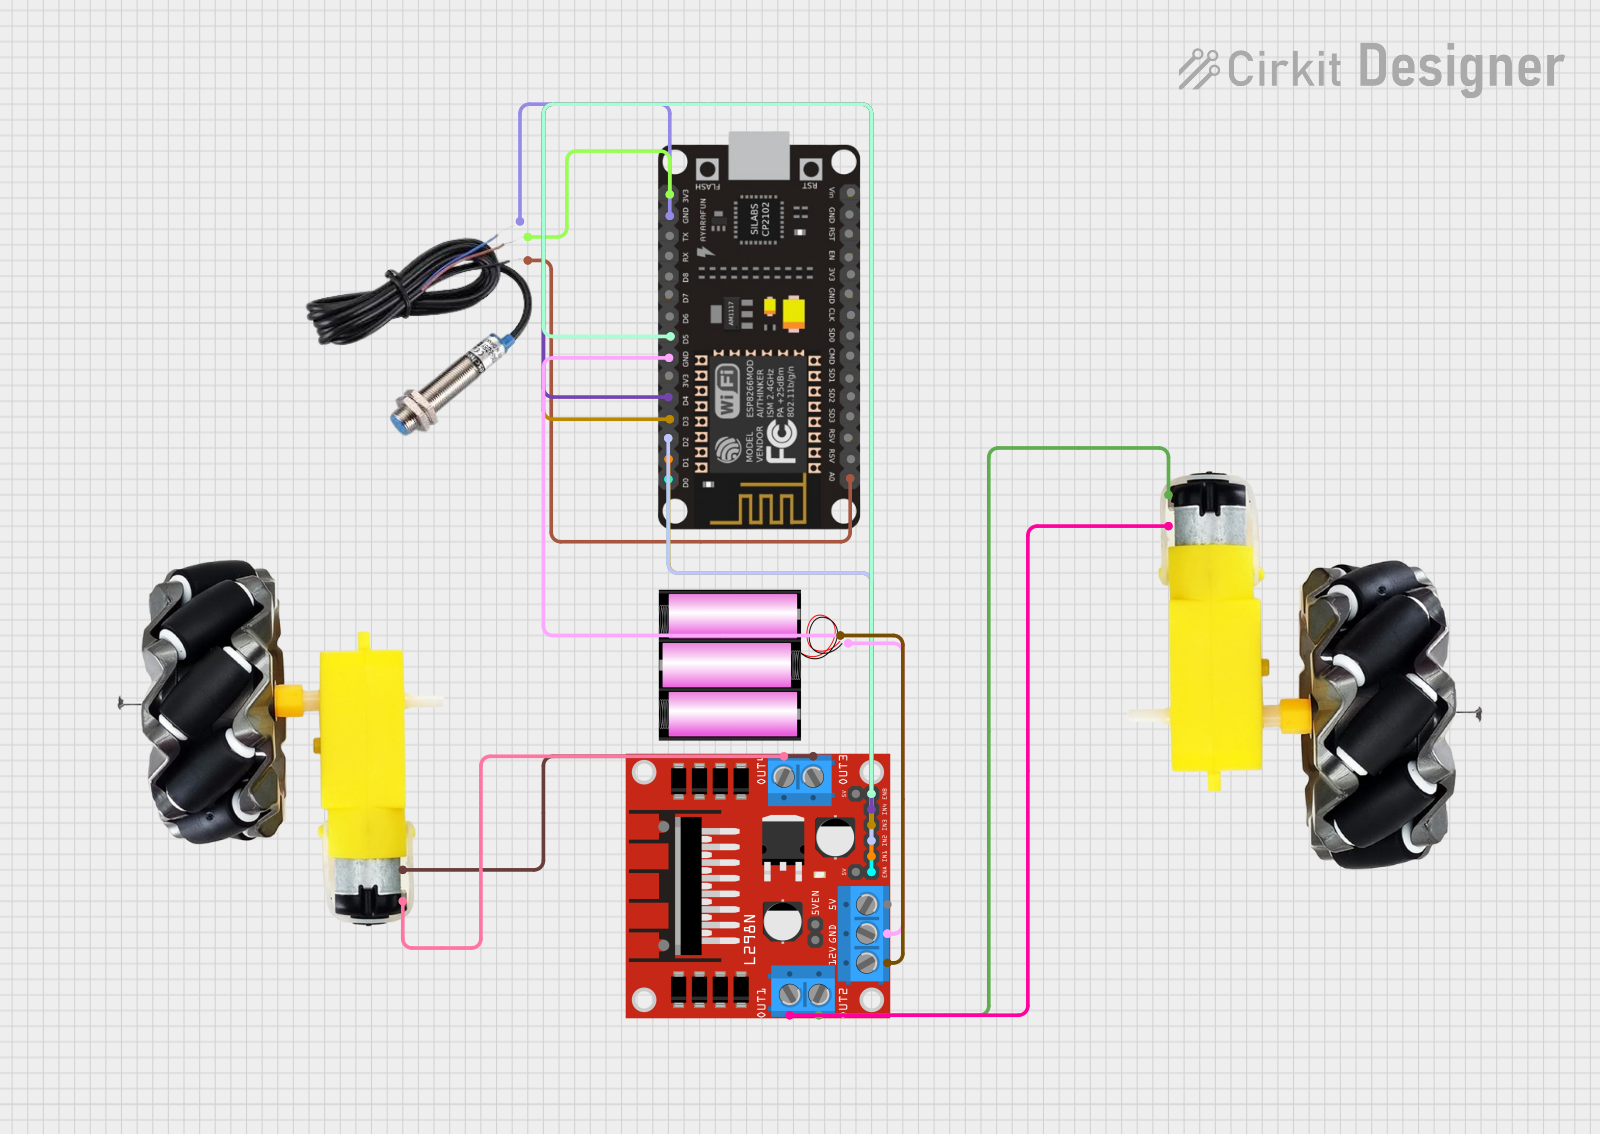
This circuit is designed to control two DC motors using an ESP8266 NodeMCU microcontroller and an L298N motor driver. The motors are connected to the motor driver outputs, and the ESP8266 controls the motor driver inputs to regulate the speed and direction of the motors. An inductive sensor is interfaced with the ESP8266 to provide feedback, possibly for position or speed sensing, which can be used to adjust the motor control dynamically.
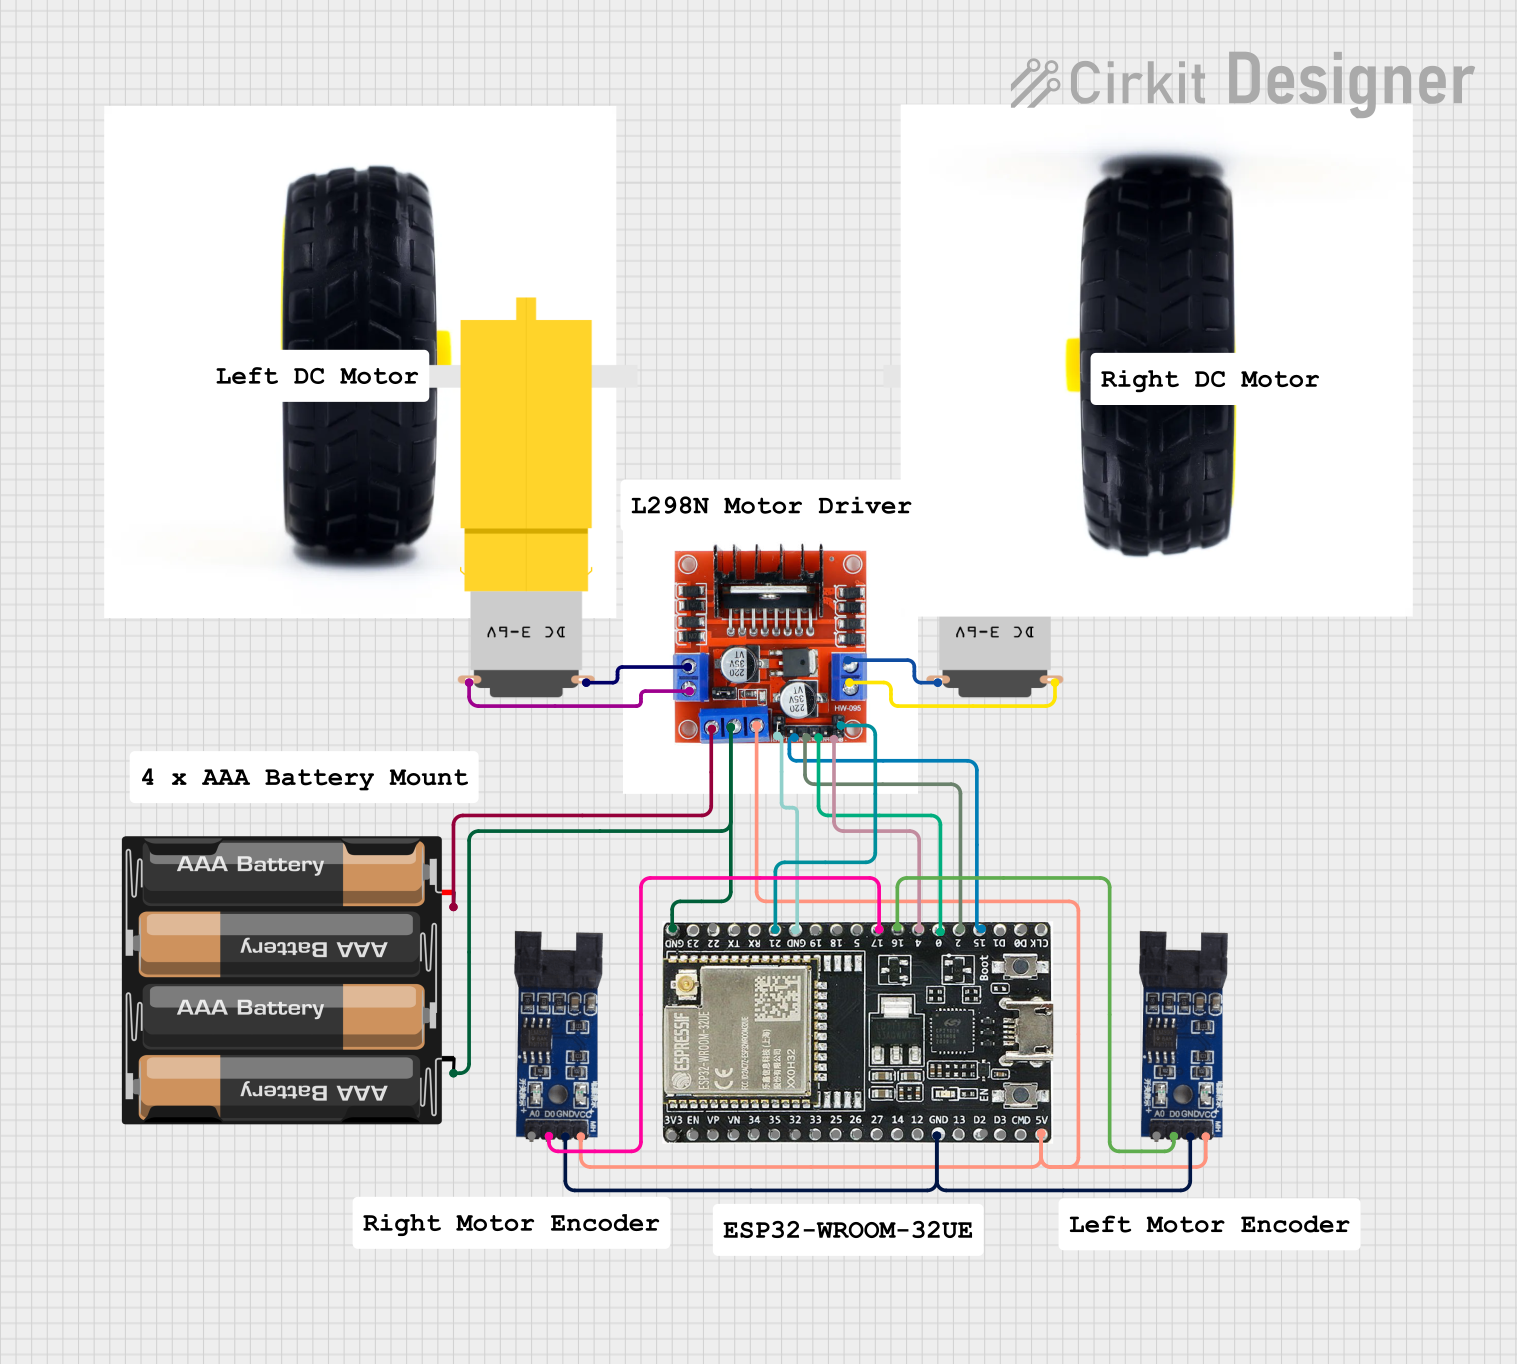
This circuit is designed to control two DC motors using an L298N Dual Motor Driver Module, which receives PWM control signals from an ESP32 microcontroller. The motors' rotational movement can be monitored by two Optical Encoder Sensor Modules connected to the ESP32. Power is supplied by a 4 x AAA battery mount, with the battery's positive terminal connected to the motor driver's 12V input and the negative terminal to the common ground.
Robotics: Driving wheels, arms, or other moving parts.
Industrial machinery: Conveyor belts, pumps, and fans.
Consumer electronics: Toys, small appliances, and electric tools.
Automotive: Windshield wipers, power windows, and seat adjustments.
Technical Specifications
Below are the general technical specifications for a typical DC motor. Note that actual values may vary depending on the specific model of the DC motor.
Parameter
Specification
Operating Voltage
3V to 12V DC
Rated Current
100mA to 2A (depending on load)
Stall Current
Up to 5A (varies by model)
Speed
1000 to 5000 RPM (no load)
Torque
0.1 to 1.5 Nm (varies by model)
Shaft Diameter
2mm to 6mm
Dimensions
Varies (e.g., 25mm x 20mm x 15mm)
Weight
20g to 200g
Pin Configuration and Descriptions
DC motors typically have two terminals or wires for connection. These are:
Pin/Wire Name
Description
Positive (+)
Connects to the positive terminal of the power supply.
Negative (-)
Connects to the negative terminal of the power supply or ground (GND).
Some DC motors may include additional features, such as an encoder for speed and position feedback, which would have extra pins or wires.
Usage Instructions
How to Use the Component in a Circuit
Power Supply: Ensure the DC motor is powered within its specified voltage range. Exceeding the voltage may damage the motor.
Motor Driver: Use a motor driver (e.g., L298N, L293D, or an H-bridge circuit) to control the motor. Directly connecting the motor to a microcontroller is not recommended due to high current requirements.
Polarity: Reversing the polarity of the power supply will reverse the direction of the motor's rotation.
PWM Control: Use Pulse Width Modulation (PWM) to control the motor's speed. This can be achieved using a microcontroller like an Arduino.
Important Considerations and Best Practices
Current Limiting: Use a current-limiting resistor or a motor driver with built-in current protection to prevent damage.
Heat Dissipation: Ensure proper ventilation or heat sinks if the motor operates under heavy load for extended periods.
Noise Suppression: Add capacitors (e.g., 0.1µF) across the motor terminals to reduce electrical noise.
Load Matching: Avoid overloading the motor beyond its rated torque to prevent stalling or overheating.
Example: Connecting a DC Motor to an Arduino UNO
Below is an example of controlling a DC motor using an Arduino UNO and an L298N motor driver.
Circuit Connections
Connect the motor's positive and negative terminals to the OUT1 and OUT2 pins of the L298N driver.
Connect the IN1 and IN2 pins of the L298N to Arduino digital pins 9 and 10, respectively.
Connect the ENA pin of the L298N to Arduino digital pin 3 (for PWM speed control).
Provide a separate power supply for the motor (e.g., 9V battery) to the L298N's VCC and GND pins.
Arduino Code
// Define motor control pins
const int IN1 = 9;  // Motor direction control pin 1
const int IN2 = 10; // Motor direction control pin 2
const int ENA = 3;  // Motor speed control (PWM) pin

void setup() {
  // Set motor control pins as outputs
  pinMode(IN1, OUTPUT);
  pinMode(IN2, OUTPUT);
  pinMode(ENA, OUTPUT);
}

void loop() {
  // Rotate motor forward at 50% speed
  digitalWrite(IN1, HIGH);  // Set IN1 high
  digitalWrite(IN2, LOW);   // Set IN2 low
  analogWrite(ENA, 128);    // Set PWM duty cycle to 50% (128/255)

  delay(2000); // Run motor for 2 seconds

  // Rotate motor backward at 75% speed
  digitalWrite(IN1, LOW);   // Set IN1 low
  digitalWrite(IN2, HIGH);  // Set IN2 high
  analogWrite(ENA, 192);    // Set PWM duty cycle to 75% (192/255)

  delay(2000); // Run motor for 2 seconds

  // Stop the motor
  digitalWrite(IN1, LOW);   // Set IN1 low
  digitalWrite(IN2, LOW);   // Set IN2 low
  analogWrite(ENA, 0);      // Set PWM duty cycle to 0%

  delay(2000); // Wait for 2 seconds before repeating
}
Troubleshooting and FAQs
Common Issues and Solutions
Motor Not Spinning:
Check the power supply voltage and current. Ensure it meets the motor's requirements.
Verify the connections to the motor driver and ensure the driver is functioning correctly.
Test the motor with a direct power supply to rule out motor failure.
Motor Spins in the Wrong Direction:
Reverse the polarity of the motor's connections or swap the IN1 and IN2 signals in the code.
Motor Overheating:
Reduce the load on the motor or lower the operating voltage.
Ensure proper ventilation or add a heat sink to the motor.
Excessive Noise or Interference:
Add capacitors across the motor terminals to suppress electrical noise.
Use shielded cables for connections to reduce electromagnetic interference.
FAQs
Can I connect a DC motor directly to an Arduino?
No, the Arduino cannot supply the high current required by the motor. Always use a motor driver or an H-bridge circuit.
How do I control the speed of a DC motor?
Use PWM (Pulse Width Modulation) to vary the average voltage supplied to the motor, which controls its speed.
What happens if I exceed the motor's rated voltage?
Exceeding the rated voltage can cause overheating, reduced lifespan, or permanent damage to the motor.
Can I use a single power supply for both the motor and the Arduino?
Yes, but ensure the power supply can handle the combined current requirements of both the motor and the Arduino. Use proper decoupling to prevent voltage drops or noise affecting the Arduino.

 Open Project in Cirkit Designer