Introduction
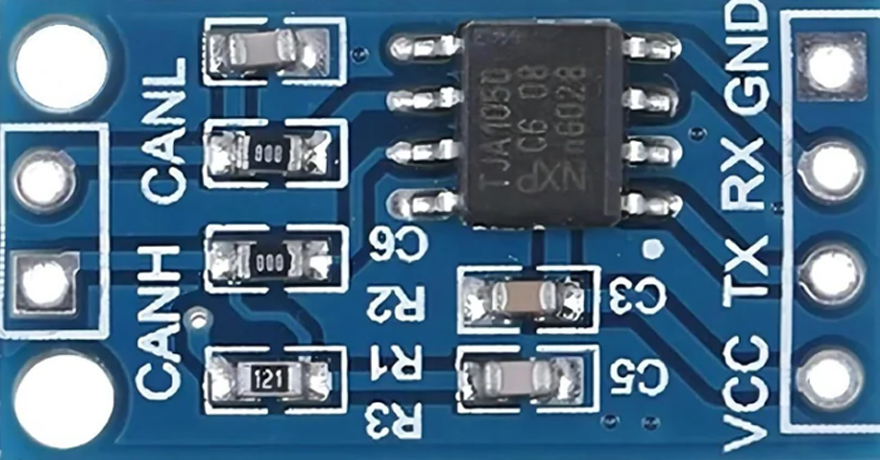
The TJA1050 is a high-speed CAN (Controller Area Network) transceiver designed for reliable communication in automotive and industrial applications. Manufactured by NXP Semiconductors, this component acts as an interface between the CAN protocol controller and the physical CAN bus. It supports data rates of up to 1 Mbps and is optimized for low power consumption and robust performance, even in electrically noisy environments.
Common Applications and Use Cases
- Automotive systems (e.g., engine control units, body control modules)
- Industrial automation and control systems
- Medical equipment
- Building automation
- Robotics and embedded systems requiring CAN communication
Technical Specifications
The TJA1050 is designed to meet the requirements of ISO 11898-2 for high-speed CAN transceivers. Below are its key technical details:
Key Technical Details
- Supply Voltage (Vcc): 4.5 V to 5.5 V
- Data Rate: Up to 1 Mbps
- Bus Voltage Range: -27 V to +40 V
- Input Voltage (CANH, CANL): -27 V to +40 V
- Standby Current: < 10 µA (in standby mode)
- Operating Temperature Range: -40°C to +125°C
- ESD Protection: ±6 kV (HBM) on CANH and CANL pins
- Package Options: SO-8, DIP-8
Pin Configuration and Descriptions
The TJA1050 is typically available in an 8-pin package. Below is the pinout and description:
Usage Instructions
The TJA1050 is straightforward to use in a CAN-based communication system. Below are the steps and considerations for integrating it into a circuit:
How to Use the TJA1050 in a Circuit
Power Supply:
- Connect the Vcc pin to a regulated 5 V power supply.
- Connect the GND pin to the system ground.
CAN Bus Connection:
- Connect the CANH and CANL pins to the corresponding lines of the CAN bus.
- Use a 120-ohm termination resistor between CANH and CANL at each end of the bus.
Controller Interface:
- Connect the TXD pin to the CAN controller's transmit data output.
- Connect the RXD pin to the CAN controller's receive data input.
Standby Mode:
- To enable normal operation, pull the S pin low.
- To enter standby mode, pull the S pin high.
Reference Voltage:
- The Vref pin provides a reference voltage (typically 2.5 V) for optional use in the circuit.
Important Considerations and Best Practices
- Ensure proper decoupling by placing a 100 nF ceramic capacitor close to the Vcc pin.
- Use twisted-pair cables for the CAN bus to minimize electromagnetic interference (EMI).
- Avoid exceeding the maximum voltage ratings on any pin to prevent damage to the transceiver.
- Place the TJA1050 as close as possible to the CAN controller to reduce signal degradation.
Example: Connecting the TJA1050 to an Arduino UNO
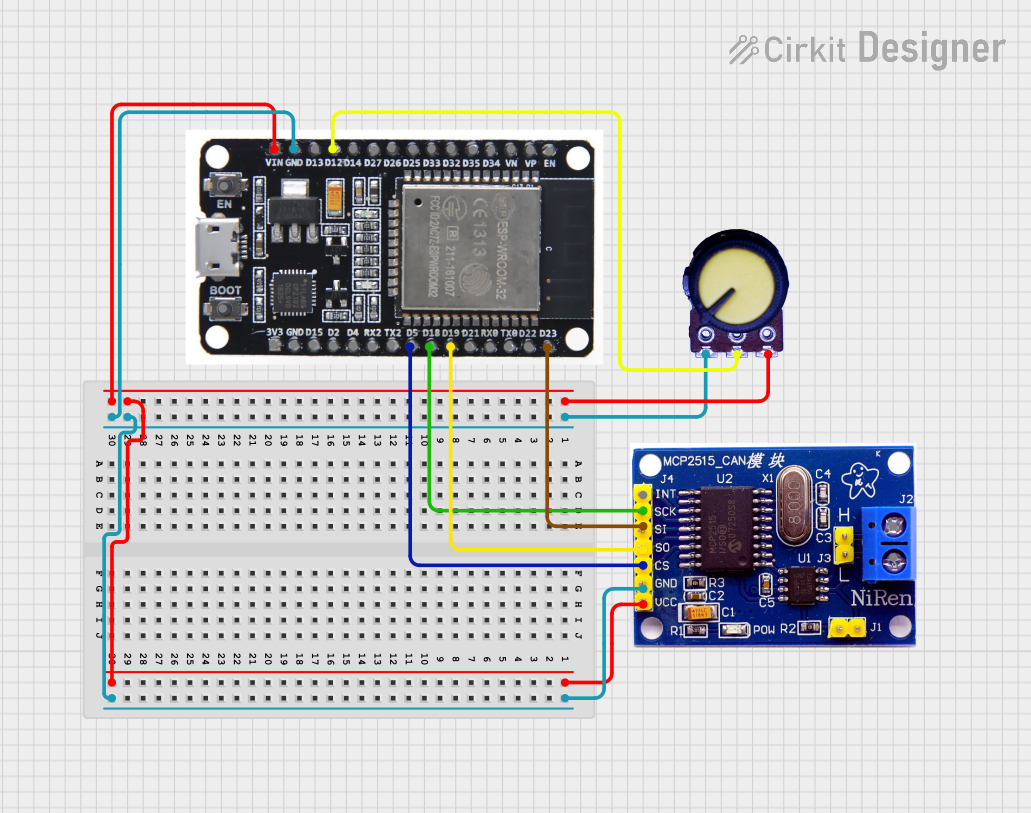
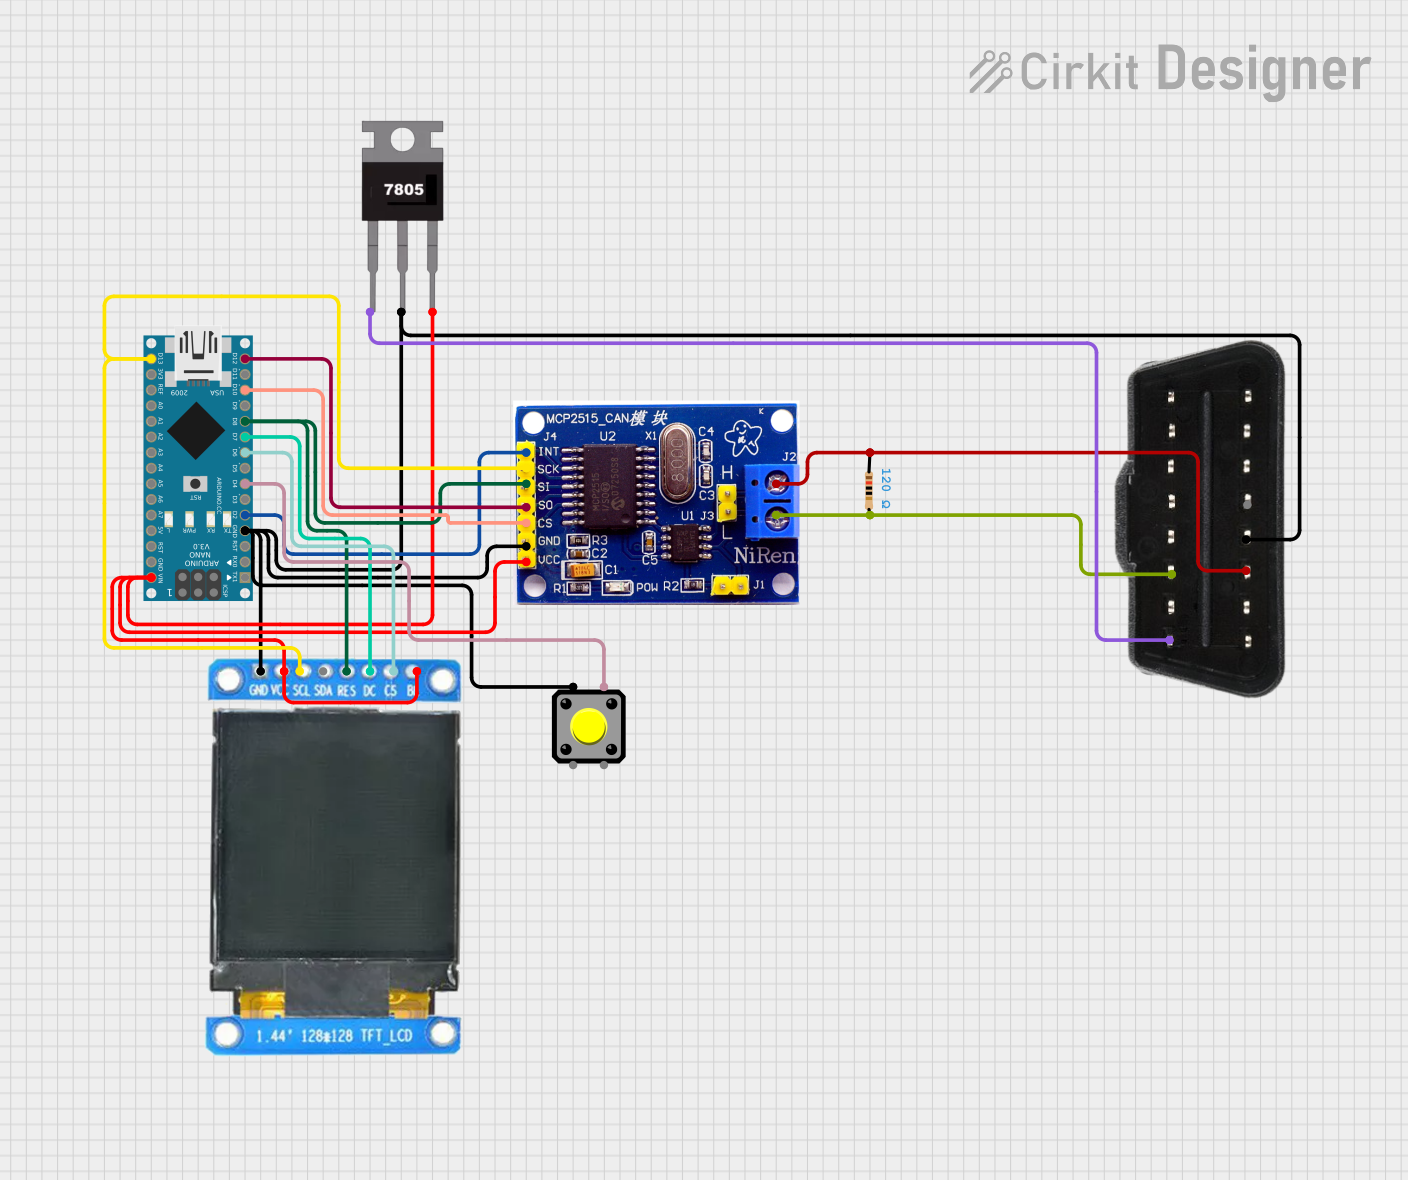
The TJA1050 can be used with an Arduino UNO for CAN communication. Below is an example of how to connect and use it:
Circuit Connections
- TJA1050 TXD → Arduino Digital Pin 10
- TJA1050 RXD → Arduino Digital Pin 11
- TJA1050 Vcc → Arduino 5V
- TJA1050 GND → Arduino GND
- TJA1050 CANH → CAN Bus High Line
- TJA1050 CANL → CAN Bus Low Line
Example Code
#include <SPI.h>
#include <mcp_can.h>

// Define the SPI CS pin for the MCP2515 CAN controller
#define CAN_CS_PIN 10

// Initialize the CAN controller
MCP_CAN CAN(CAN_CS_PIN);

void setup() {
  Serial.begin(115200);
  while (!Serial);

  // Initialize the CAN bus at 500 kbps
  if (CAN.begin(MCP_ANY, CAN_500KBPS, MCP_8MHZ) == CAN_OK) {
    Serial.println("CAN bus initialized successfully!");
  } else {
    Serial.println("Error initializing CAN bus.");
    while (1);
  }

  // Set the CAN controller to normal mode
  CAN.setMode(MCP_NORMAL);
  Serial.println("CAN controller set to normal mode.");
}

void loop() {
  // Send a test message
  byte data[8] = {0x01, 0x02, 0x03, 0x04, 0x05, 0x06, 0x07, 0x08};
  if (CAN.sendMsgBuf(0x100, 0, 8, data) == CAN_OK) {
    Serial.println("Message sent successfully!");
  } else {
    Serial.println("Error sending message.");
  }

  delay(1000); // Wait 1 second before sending the next message
}
Troubleshooting and FAQs
Common Issues and Solutions
No Communication on the CAN Bus:
- Ensure the CANH and CANL lines are properly connected and terminated with 120-ohm resistors.
- Verify that the S pin is pulled low for normal operation.
High Power Consumption:
- Check for short circuits or incorrect wiring.
- Ensure the TJA1050 is in standby mode when not in use.
Data Corruption or Noise:
- Use twisted-pair cables for the CAN bus.
- Place decoupling capacitors close to the Vcc pin.
Arduino Code Not Working:
- Verify the SPI connections between the Arduino and the MCP2515 CAN controller.
- Ensure the correct CAN speed is configured in the code.
FAQs
Q: Can the TJA1050 operate at 3.3 V?
A: No, the TJA1050 requires a supply voltage between 4.5 V and 5.5 V. It is not compatible with 3.3 V systems without level shifting.
Q: Is the TJA1050 compatible with ISO 11898-2?
A: Yes, the TJA1050 is fully compliant with the ISO 11898-2 standard for high-speed CAN transceivers.
Q: Can I use the TJA1050 for low-speed CAN applications?
A: The TJA1050 is optimized for high-speed CAN (up to 1 Mbps). For low-speed applications, consider using a transceiver designed specifically for that purpose.

 Open Project in Cirkit Designer