An Electronic Speed Controller (ESC) for Brushless DC (BLDC) motors is a critical component in modern motor control systems. It regulates the motor's speed, direction, and start/stop functions by varying the voltage and current supplied to the motor. ESCs are widely used in applications requiring precise motor control, such as drones, electric vehicles, robotics, and RC (radio-controlled) devices.
Explore Projects Built with ESC BLDC
Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
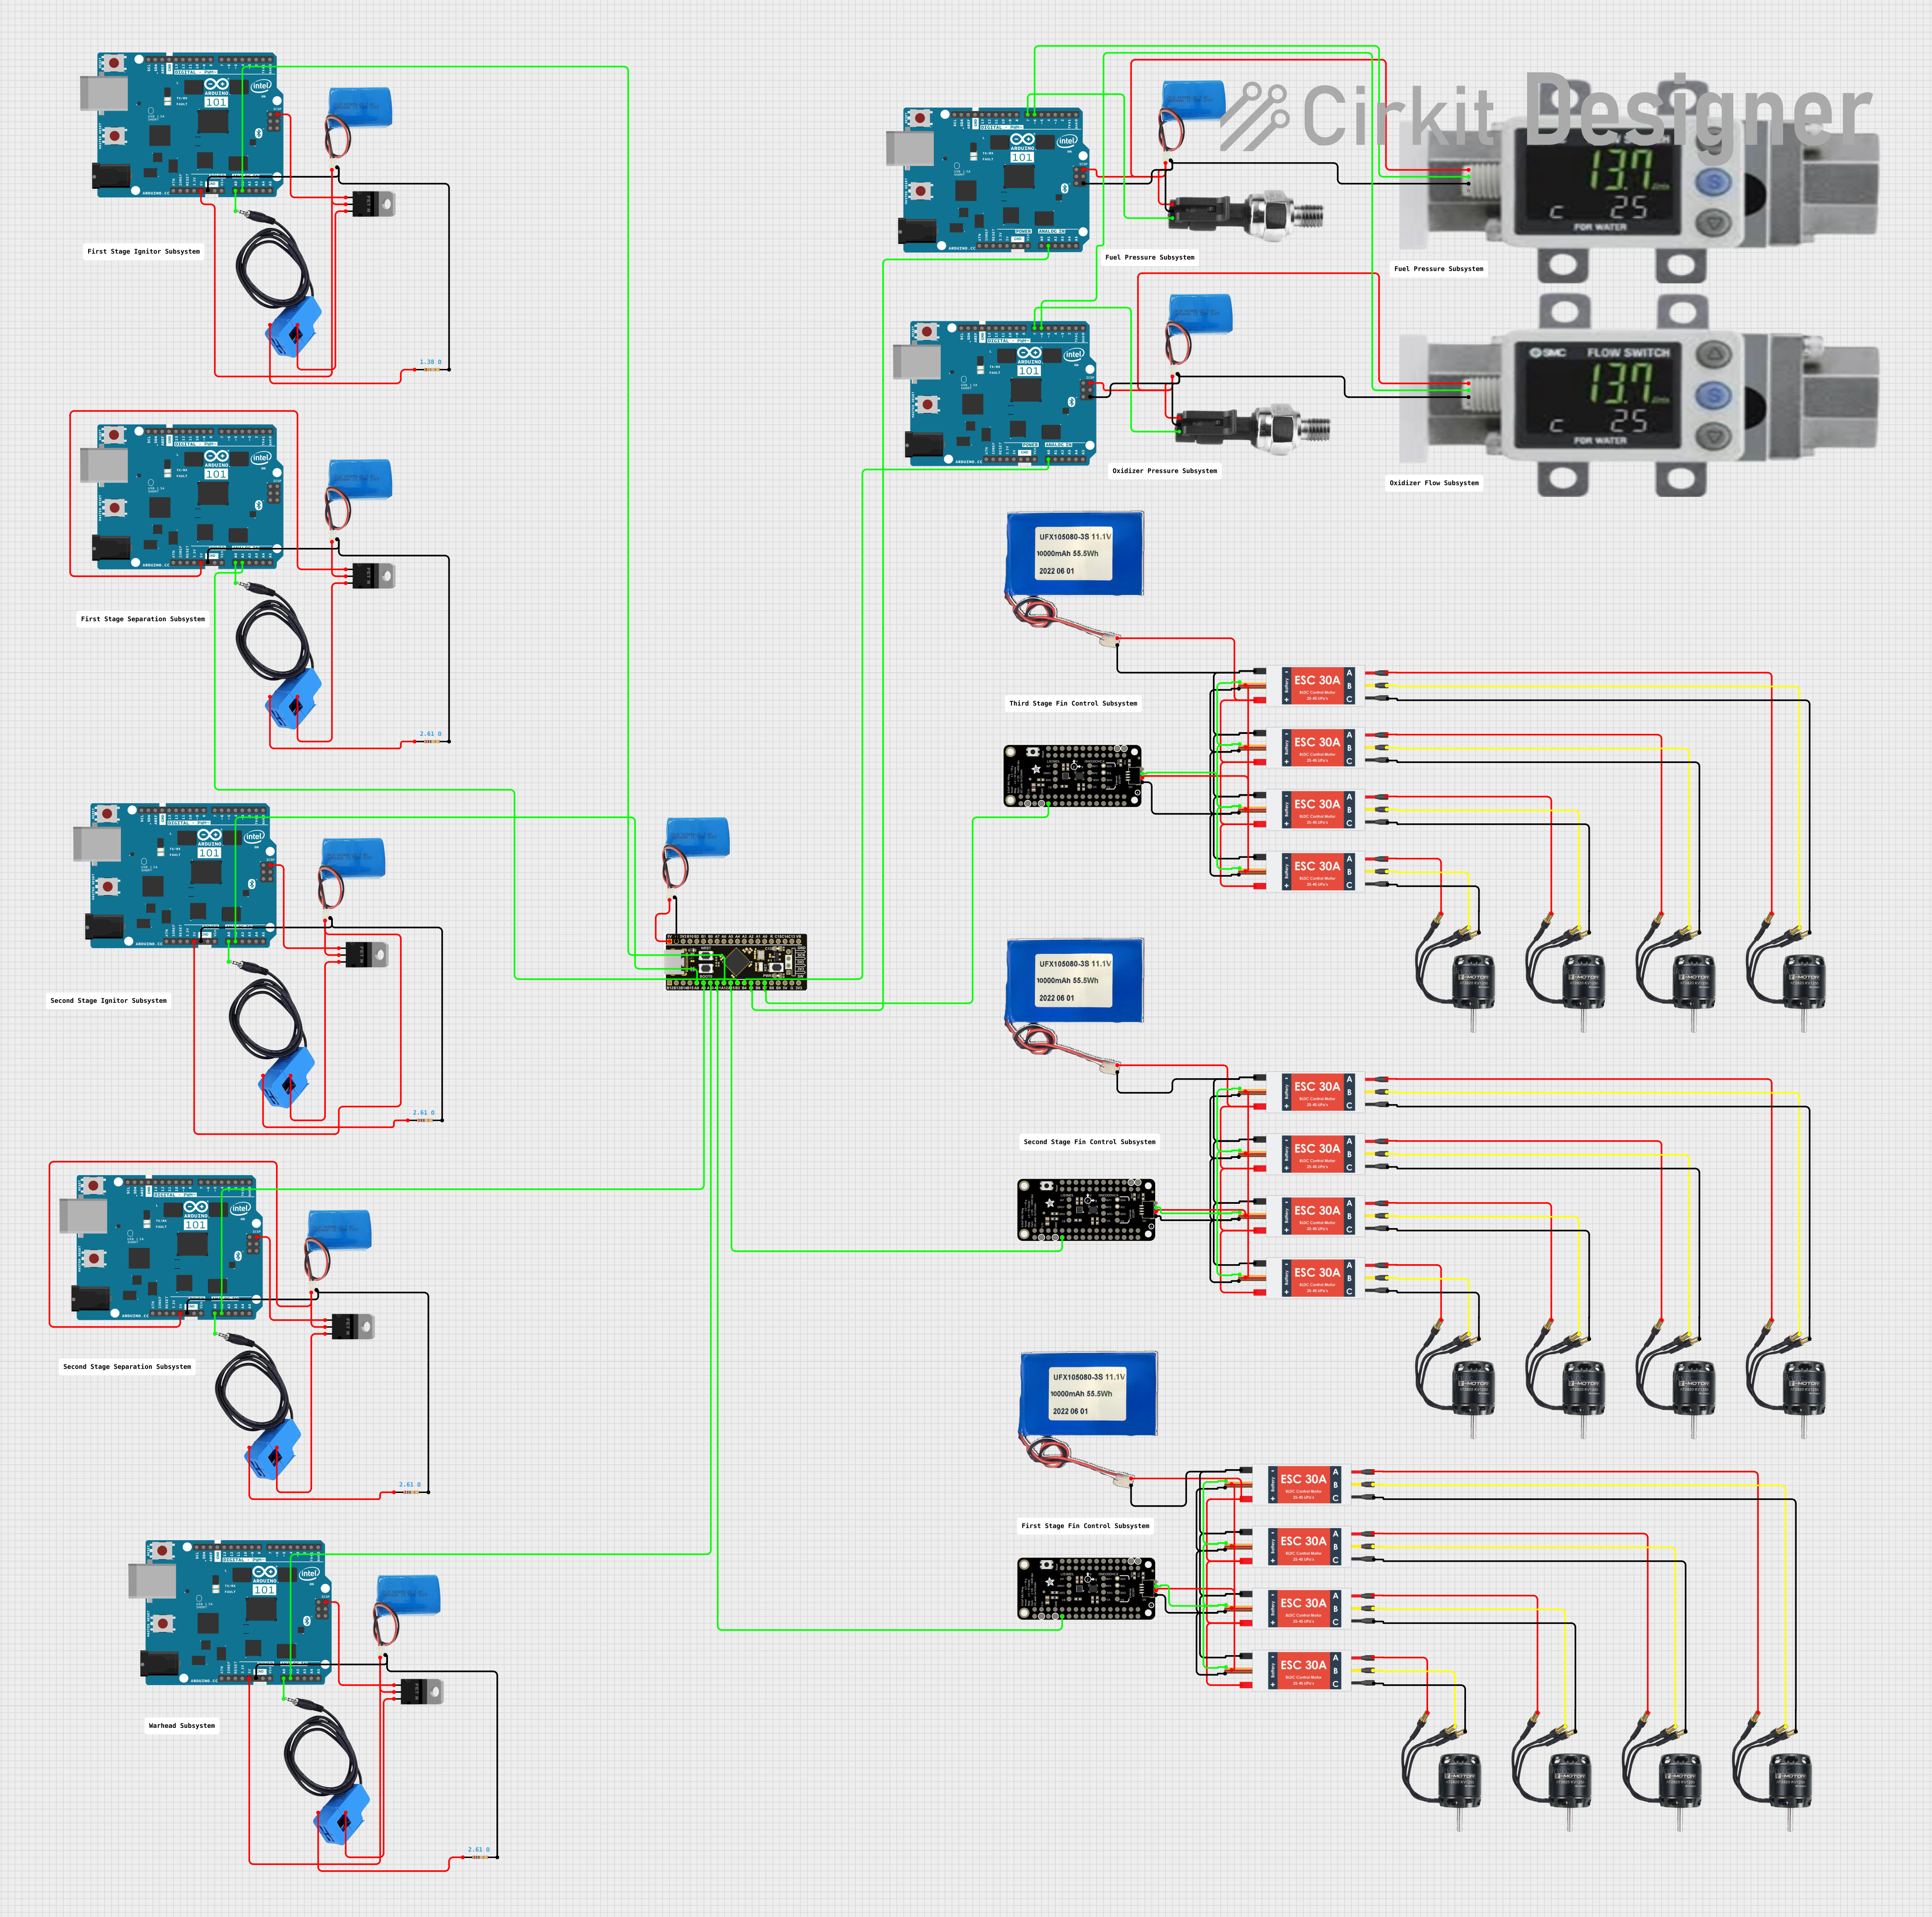
This circuit consists of multiple Electronic Speed Controllers (ESCs) connected to Brushless DC (BLDC) motors and powered by Lithium-ion batteries. The ESCs receive control signals from Adafruit Precision 9-DoF ISM330DHCX + LIS3MDL FeatherWings, which are likely used for motion sensing and control. Additionally, the circuit includes an STM32F4 BlackPill microcontroller, current sensors, MOSFETs, resistors, and other sensors, indicating a complex control system possibly for a drone or a robotic application.
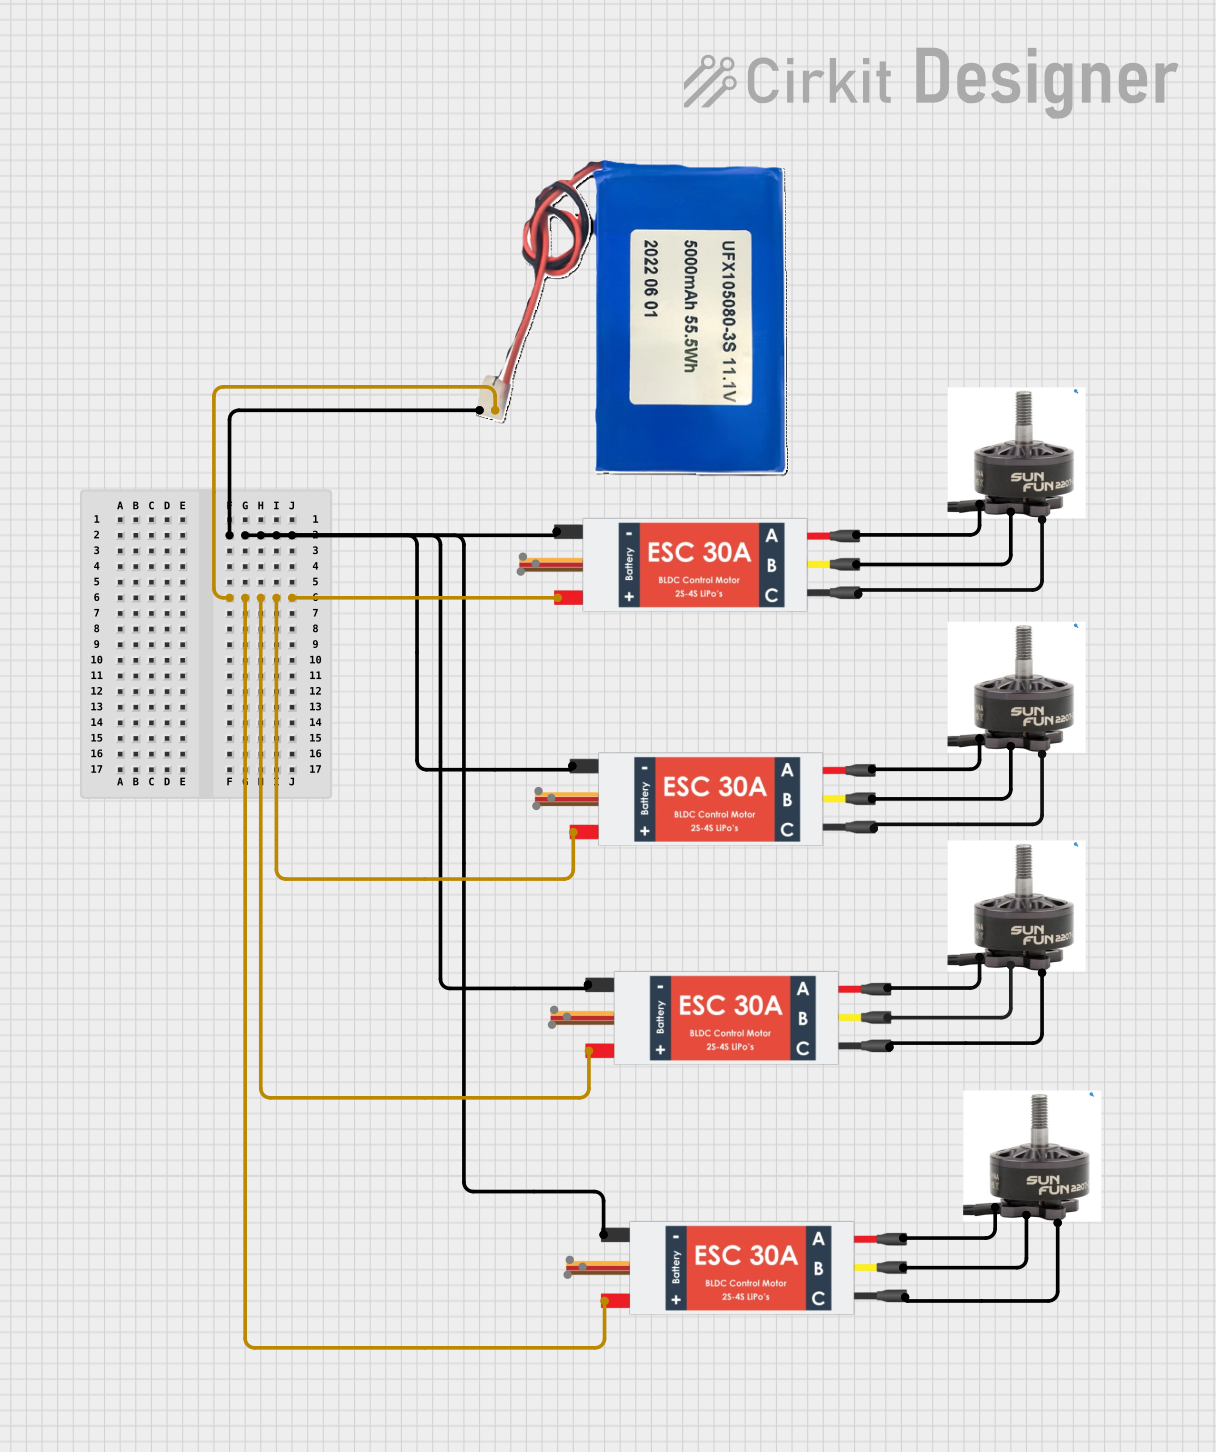
This circuit is designed to control four brushless DC (BLDC) motors using four corresponding Electronic Speed Controllers (ESCs). Each ESC receives power from a shared Li-ion battery and is responsible for driving one of the BLDC motors by controlling the phases to the motor windings. The circuit is likely part of a multirotor drone or a similar application requiring precise control of multiple motors.
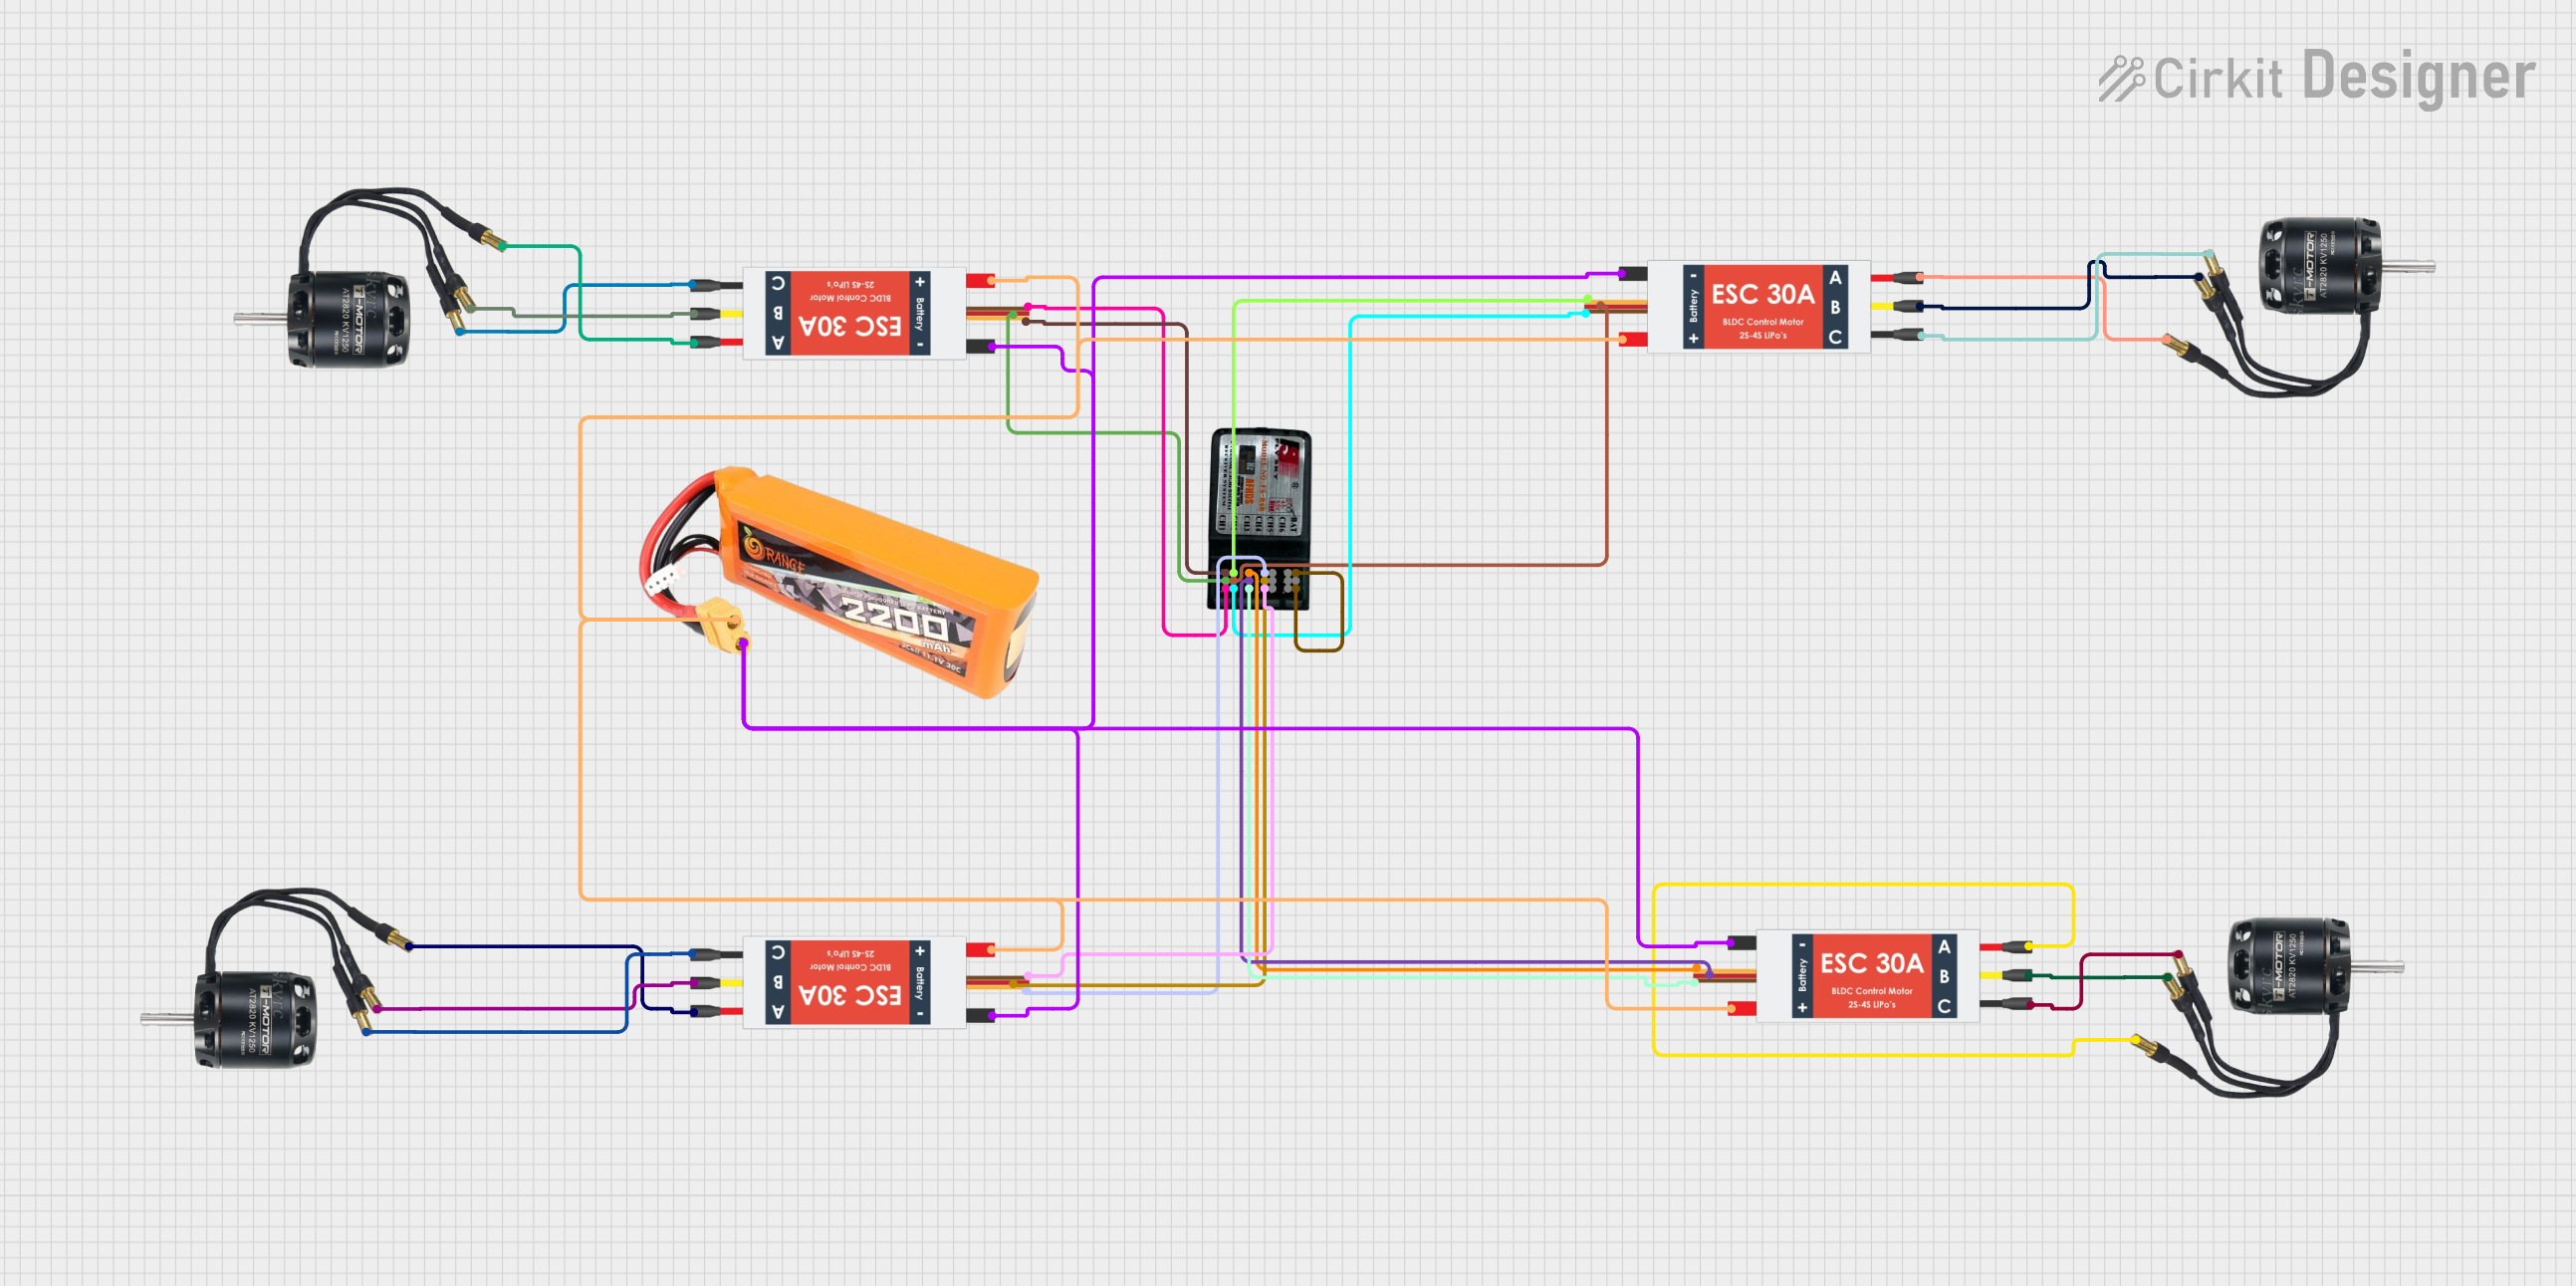
This circuit is designed to control four Brushless DC (BLDC) motors using corresponding Electronic Speed Controllers (ESCs). Each ESC receives power from a shared LiPo battery and control signals from an FS-CT6B receiver, which likely receives input from a remote transmitter for wireless control. The ESCs regulate the power supplied to the motors based on the received signals, enabling precise speed and direction control of the motors, typically used in applications such as drones or remote-controlled vehicles.
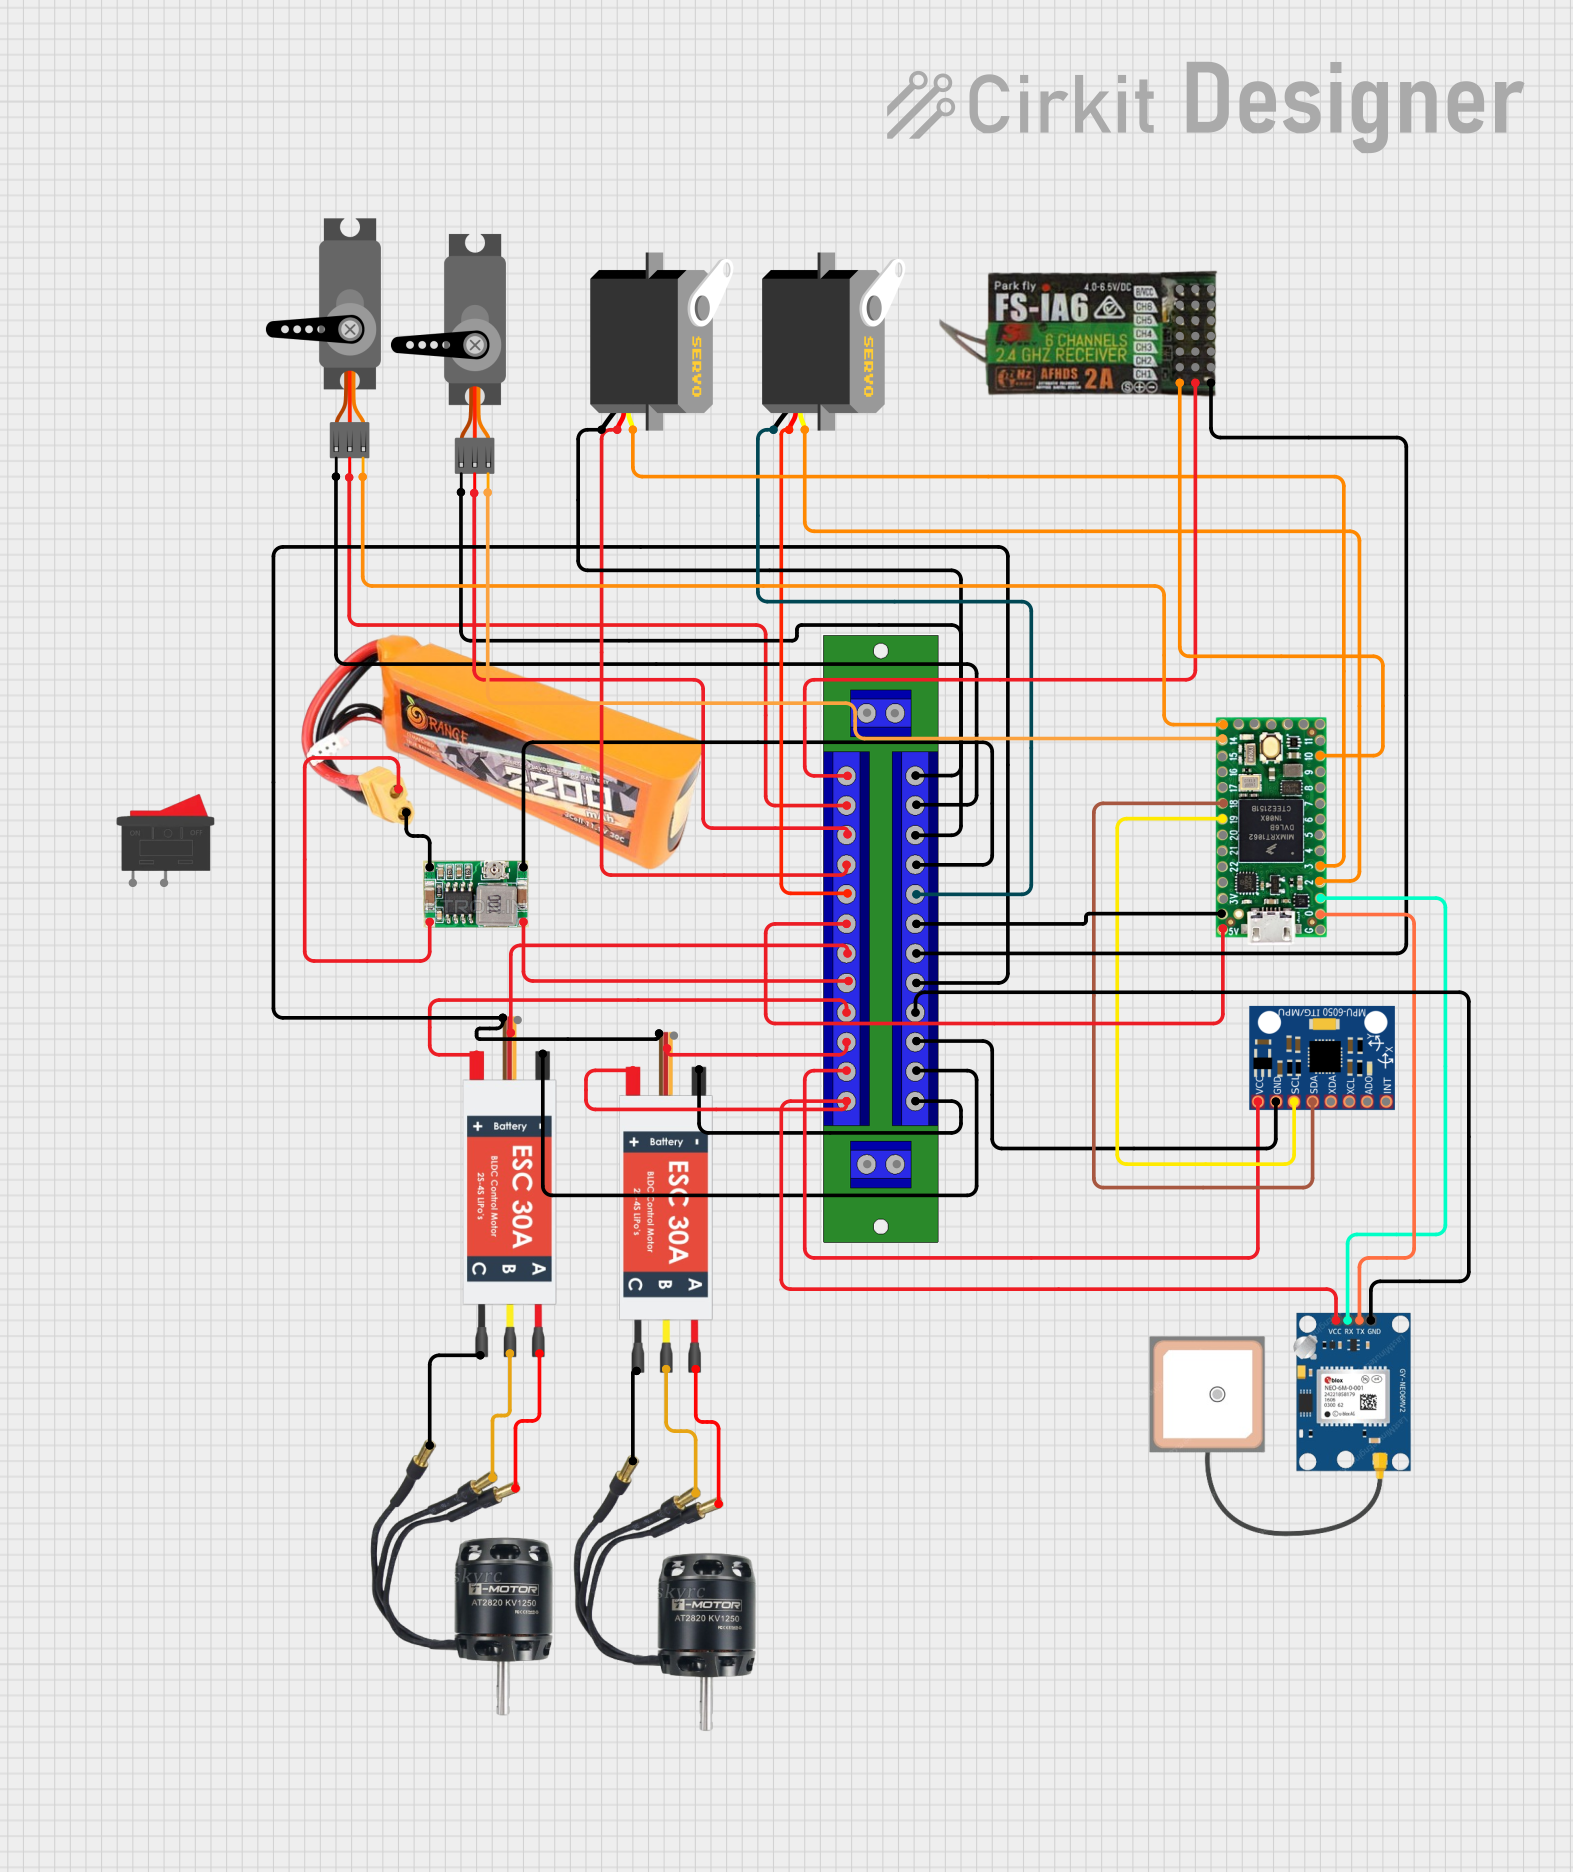
This circuit is designed to control a pair of brushless DC (BLDC) motors via electronic speed controllers (ESCs), which are connected to a distribution board that distributes power from a LiPo battery. The circuit includes a Teensy 4.0 microcontroller interfaced with a GPS module and an MPU-6050 for navigation and orientation, as well as multiple servos for additional actuation, all powered through a distribution board. A Mini 360 Buck Converter is used to step down the battery voltage, and a FLYSKY FS-IA6 receiver is included for remote control capabilities.
Drones and UAVs: For controlling the speed of propeller motors.
Electric Vehicles: To manage motor speed and torque.
Robotics: For precise movement and control of robotic arms or wheels.
RC Devices: In cars, boats, and planes for speed and direction control.
Technical Specifications
Below are the general technical specifications for a typical ESC designed for BLDC motors. Always refer to the datasheet of your specific ESC model for exact details.
Key Technical Details
Input Voltage Range: 6V to 24V (2S to 6S LiPo batteries)
Continuous Current Rating: 20A to 60A (varies by model)
Peak Current Rating: 30A to 80A (for short durations)
Supported Motor Types: Brushless DC (BLDC) motors
Control Signal Input: PWM (Pulse Width Modulation) signal, typically 1ms to 2ms pulse width
BEC (Battery Eliminator Circuit): 5V or 6V output for powering external devices (optional, depending on model)
Operating Temperature: -10°C to 85°C
Weight: 10g to 50g (varies by model)
Pin Configuration and Descriptions
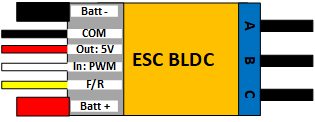
The ESC typically has three main sets of connections: motor wires, power input, and control signal input. Below is a table describing these connections:
Pin/Connection
Description
Motor Wires (A, B, C)
Three wires connected to the BLDC motor for phase control.
Power Input (+, -)
Connects to the battery or power source. "+" is positive, "-" is ground.
Signal Input (PWM)
Receives the PWM signal from a microcontroller or receiver for speed control.
BEC Output (optional)
Provides regulated 5V or 6V power for external devices like a microcontroller.
Usage Instructions
How to Use the ESC in a Circuit
Connect the Motor: Attach the three motor wires (A, B, C) from the ESC to the corresponding wires of the BLDC motor. The order of connection determines the motor's rotation direction. Swap any two wires to reverse the direction.
Connect the Power Source: Attach the ESC's power input terminals to a compatible battery or power supply. Ensure the voltage and current ratings match the ESC's specifications.
Connect the Signal Input: Use a PWM-capable microcontroller (e.g., Arduino UNO) or an RC receiver to send control signals to the ESC's signal input pin.
Calibrate the ESC: Many ESCs require calibration to match the PWM signal range. Follow the manufacturer's instructions for calibration.
Test the Setup: Gradually increase the PWM signal to test motor speed control. Ensure all connections are secure and the motor operates smoothly.
Important Considerations and Best Practices
Power Ratings: Ensure the ESC's voltage and current ratings are compatible with your motor and power source.
Cooling: High-current ESCs may require additional cooling (e.g., heatsinks or fans) to prevent overheating.
Signal Grounding: Connect the ground of the ESC to the ground of the microcontroller to ensure proper signal transmission.
Startup Safety: Always test the ESC and motor in a safe environment to avoid accidents caused by sudden motor starts.
Example Code for Arduino UNO
Below is an example of how to control an ESC for a BLDC motor using an Arduino UNO:
#include <Servo.h> // Include the Servo library to generate PWM signals

Servo esc; // Create a Servo object to control the ESC

void setup() {
  esc.attach(9); // Attach the ESC signal wire to pin 9 on the Arduino
  esc.writeMicroseconds(1000); // Send minimum throttle signal (1ms pulse)
  delay(2000); // Wait for 2 seconds to allow the ESC to initialize
}

void loop() {
  esc.writeMicroseconds(1500); // Send a mid-throttle signal (1.5ms pulse)
  delay(5000); // Run the motor at mid-speed for 5 seconds

  esc.writeMicroseconds(2000); // Send maximum throttle signal (2ms pulse)
  delay(5000); // Run the motor at full speed for 5 seconds

  esc.writeMicroseconds(1000); // Send minimum throttle signal to stop the motor
  delay(5000); // Wait for 5 seconds before repeating
}
Notes:
Replace 9 in esc.attach(9) with the appropriate pin number if using a different pin.
Ensure the ESC is properly calibrated before running the code.
Troubleshooting and FAQs
Common Issues and Solutions
Motor Does Not Spin:
Cause: Incorrect wiring or no PWM signal.
Solution: Verify motor wire connections and ensure the ESC receives a valid PWM signal.
Motor Spins in the Wrong Direction:
Cause: Incorrect phase wiring.
Solution: Swap any two motor wires to reverse the direction.
ESC Overheats:
Cause: Excessive current draw or poor ventilation.
Solution: Use a higher-rated ESC or improve cooling with a heatsink or fan.
No Response from ESC:
Cause: Calibration not performed or incorrect signal range.
Solution: Calibrate the ESC according to the manufacturer's instructions.
Motor Stutters or Vibrates:
Cause: Poor connections or incompatible motor.
Solution: Check all connections and ensure the motor is compatible with the ESC.
FAQs
Q: Can I use an ESC with a brushed DC motor? A: No, ESCs for BLDC motors are specifically designed for brushless motors. Use a brushed motor controller instead.
Q: How do I know if my ESC has a BEC? A: Check the ESC's specifications or look for a 5V/6V output wire labeled as BEC.
Q: Can I control multiple ESCs with one Arduino? A: Yes, you can control multiple ESCs by connecting their signal wires to different PWM-capable pins on the Arduino.
Q: What happens if I exceed the ESC's current rating? A: Exceeding the current rating can damage the ESC or cause it to shut down. Always use an ESC with a sufficient current margin.
This documentation provides a comprehensive guide to understanding, using, and troubleshooting an ESC for BLDC motors. Always refer to the specific ESC's datasheet for additional details.

 Open Project in Cirkit Designer